
掌握机器人劳动力:对单人多人机器人系统的审查及其对职业安全和健康及其系统性能影响
Estefany Rey-Becerra1, Sascha Wischniewski1
1Federal Institute for Occupational Safety and Health (BAuA), Unit Human Factors, Ergonomics, Dortmund, Germany.
Ergonomics
|July 11, 2025

概括
单人多机器人 (SHMR) 系统提高了工作场所的效率,但也带来了注意力挑战. 本研究为设计有效的SHMR系统提供了一个检查清单,以增强人机交互.
科学领域:
- 机器人和人机交互的人机交互
- 自动化中的人工智能
- 认知工程和人体工程学
背景情况:
- 高度自主移动机器人越来越多地用于工作场所,需要人类监督.
- 单人多机器人 (SHMR) 系统允许一个操作员管理多个机器人,优化资源和安全.
- 在管理操作员注意力和认知负载方面,SHMR系统存在挑战.
研究的目的:
- 系统地扩大对SHMR系统特征的理解.
- 解决关键问题:机器人构成,人机角色,界面设计和性能结果.
- 为设计和评估SHMR系统制定实用的检查清单.
主要方法:
- 进行了探索性文献搜索,确定了658个记录.
- 选择了44项研究进行详细分析.
- 将结合的发现整合到一个实用的检查清单中.
主要成果:
- 确定了机器人组成,人机器人角色和SHMR系统接口设计中的关键因素.
- 证明了这些因素对绩效结果的影响.
- 制定了一份全面的检查清单,以指导SHMR系统的设计和评估.
结论:
- 有效的SHMR系统设计需要仔细考虑机器人配置,角色分配和界面可用性.
- 开发的检查清单促进了复杂的机器人系统中高效的人机交互 (HRI).
- 进一步的研究可以完善SHMR的设计原则,以提高操作人员的性能和安全.

相关概念视频
 01:10
Control Systems
1.4K
Control systems are everywhere in contemporary society, influencing diverse applications from aerospace to automated manufacturing. These systems can be found naturally within biological processes, such as blood sugar regulation and heart rate adjustment in response to stress, as well as in man-made systems like elevators and automated vehicles. A control system is essentially a network of subsystems and processes that collaboratively convert specific inputs into desired outputs.
At the heart...
At the heart...
1.4K
 01:22
Mechanical Systems
293
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
293
 01:23
Simplification of a Force and Couple System: II
343
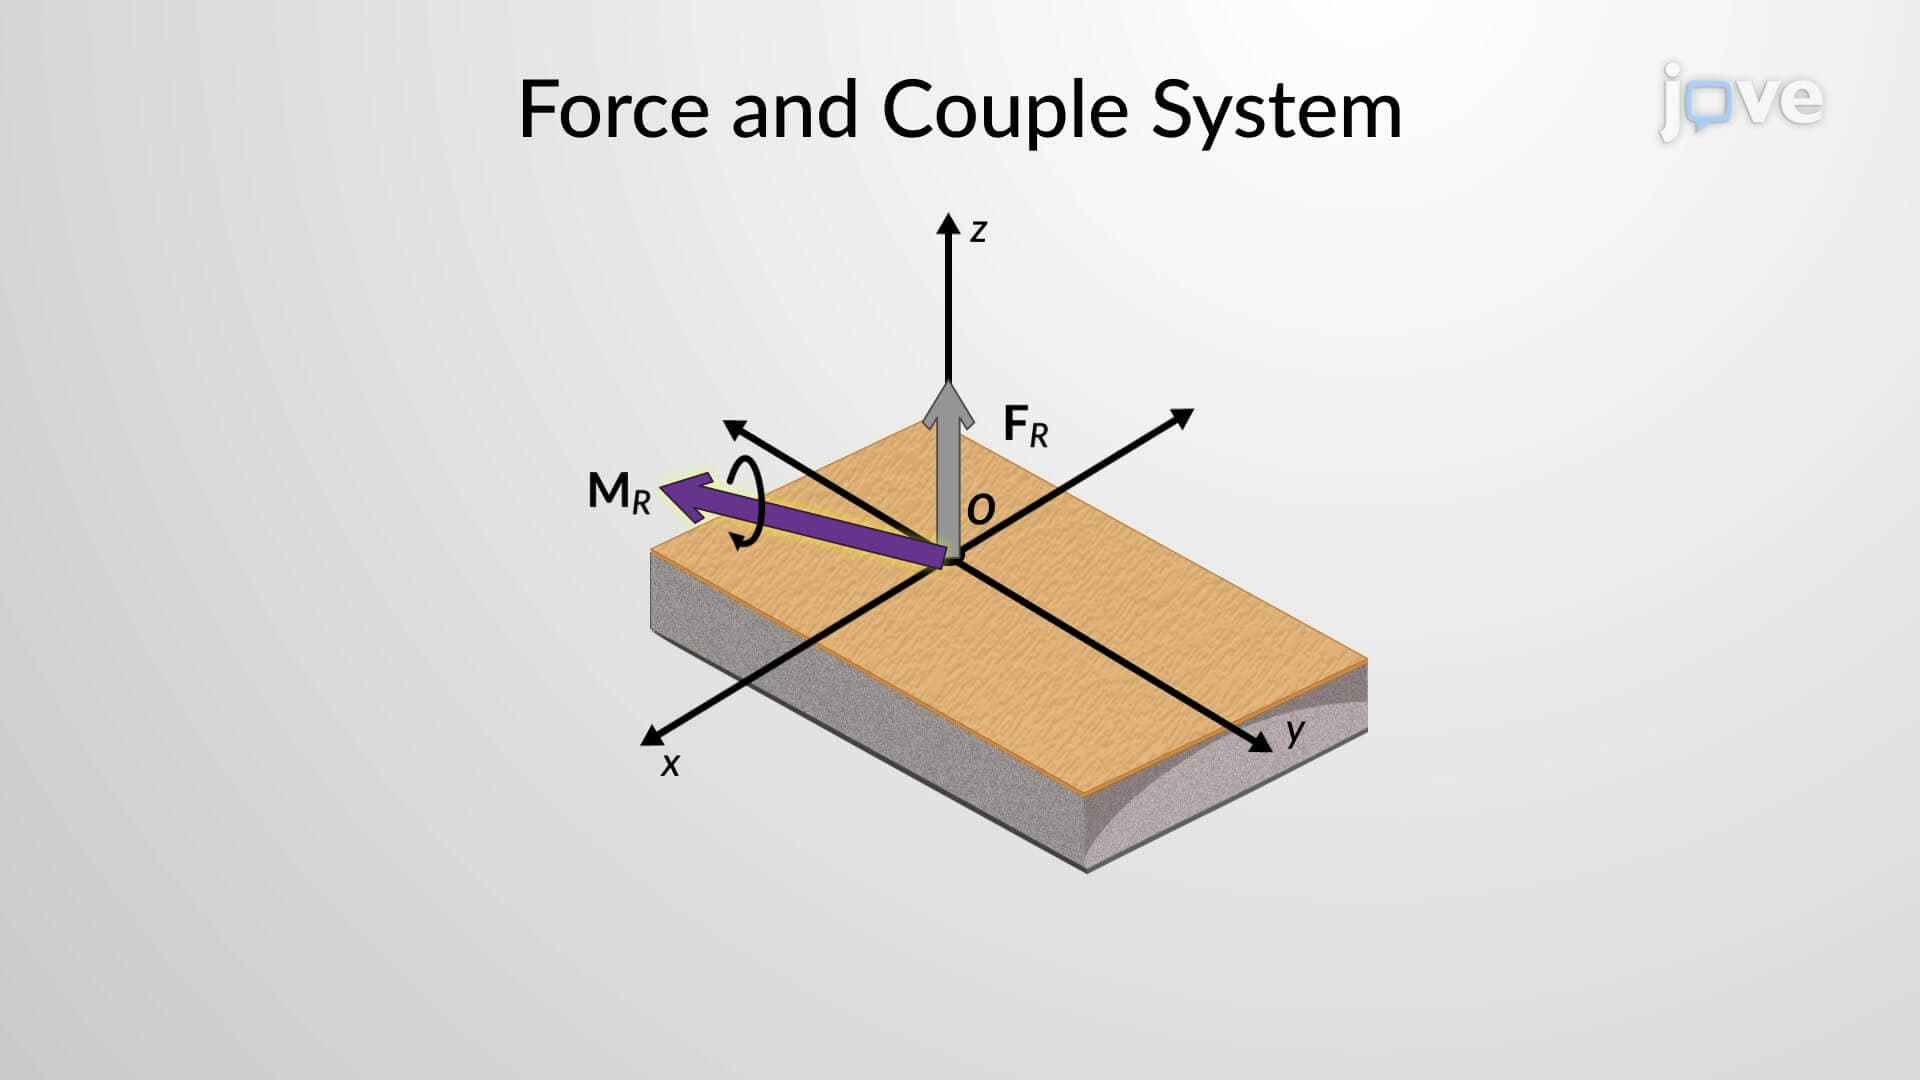
In a three-dimensional system, multiple forces can act on an object. These forces can be combined into a single equivalent force, known as the resultant force. Similarly, the moments generated by these forces can be combined into a single equivalent moment, the resultant couple moment. In certain situations, these two entities may not be mutually perpendicular, meaning they do not have a 90-degree angle between them. This unique condition requires a deeper understanding of the interplay between...
343