

一个主动吊链悬挂机器人的设计,用于上肢的适应性重力补偿

概括
这项研究引入了一种新的机器人吊带系统,用于康复中上肢重力补偿. 这种新型机器人有效地协助手臂运动,并在任务中以最小的误差跟踪位置.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 康复工程 康复工程 康复工程
- 辅助技术 辅助技术 辅助技术
背景情况:
- 上肢损伤会影响移动和独立.
- 现有的辅助设备往往缺乏动态重力补偿.
- 机器人解决方案为增强康复和援助提供了潜力.
研究的目的:
- 设计,原型,并评估一个新型的活悬挂机器人.
- 为了实现有效的重力补偿,用于上肢康复和辅助应用.
- 为了确保精确的手臂运动跟踪和一致的拉力.
主要方法:
- 开发一个模块化,可扩展的机器人,具有低惯性和优化的重量分布.
- 实现一个接入控制器和一个比例控制器用于重力补偿.
- 使用选择和放置任务来评估绩效的初步评估.
主要成果:
- 机器人展示了有效的绳电缆张力跟踪.
- 在任务中实现了精确的位置跟踪,错误最小.
- 该系统为上肢支提供了一致的拉力.
结论:
- 这种新型的活跃吊链悬挂机器人显示了对上肢重力补偿的承诺.
- 该设计为各种应用程序提供了模块化和可扩展性.
- 初步结果表明,在辅助和康复场景中有效的表现.


相关概念视频
 01:27
Support Reactions in Three Dimensions
Support reactions in three dimensions help maintain the stability and equilibrium of various structures and systems. These reactions prevent the system from translating and rotating, ensuring the design can withstand external forces and perform its intended function efficiently and safely. Some of the supports providing support reactions in three dimensions are discussed below:
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:24
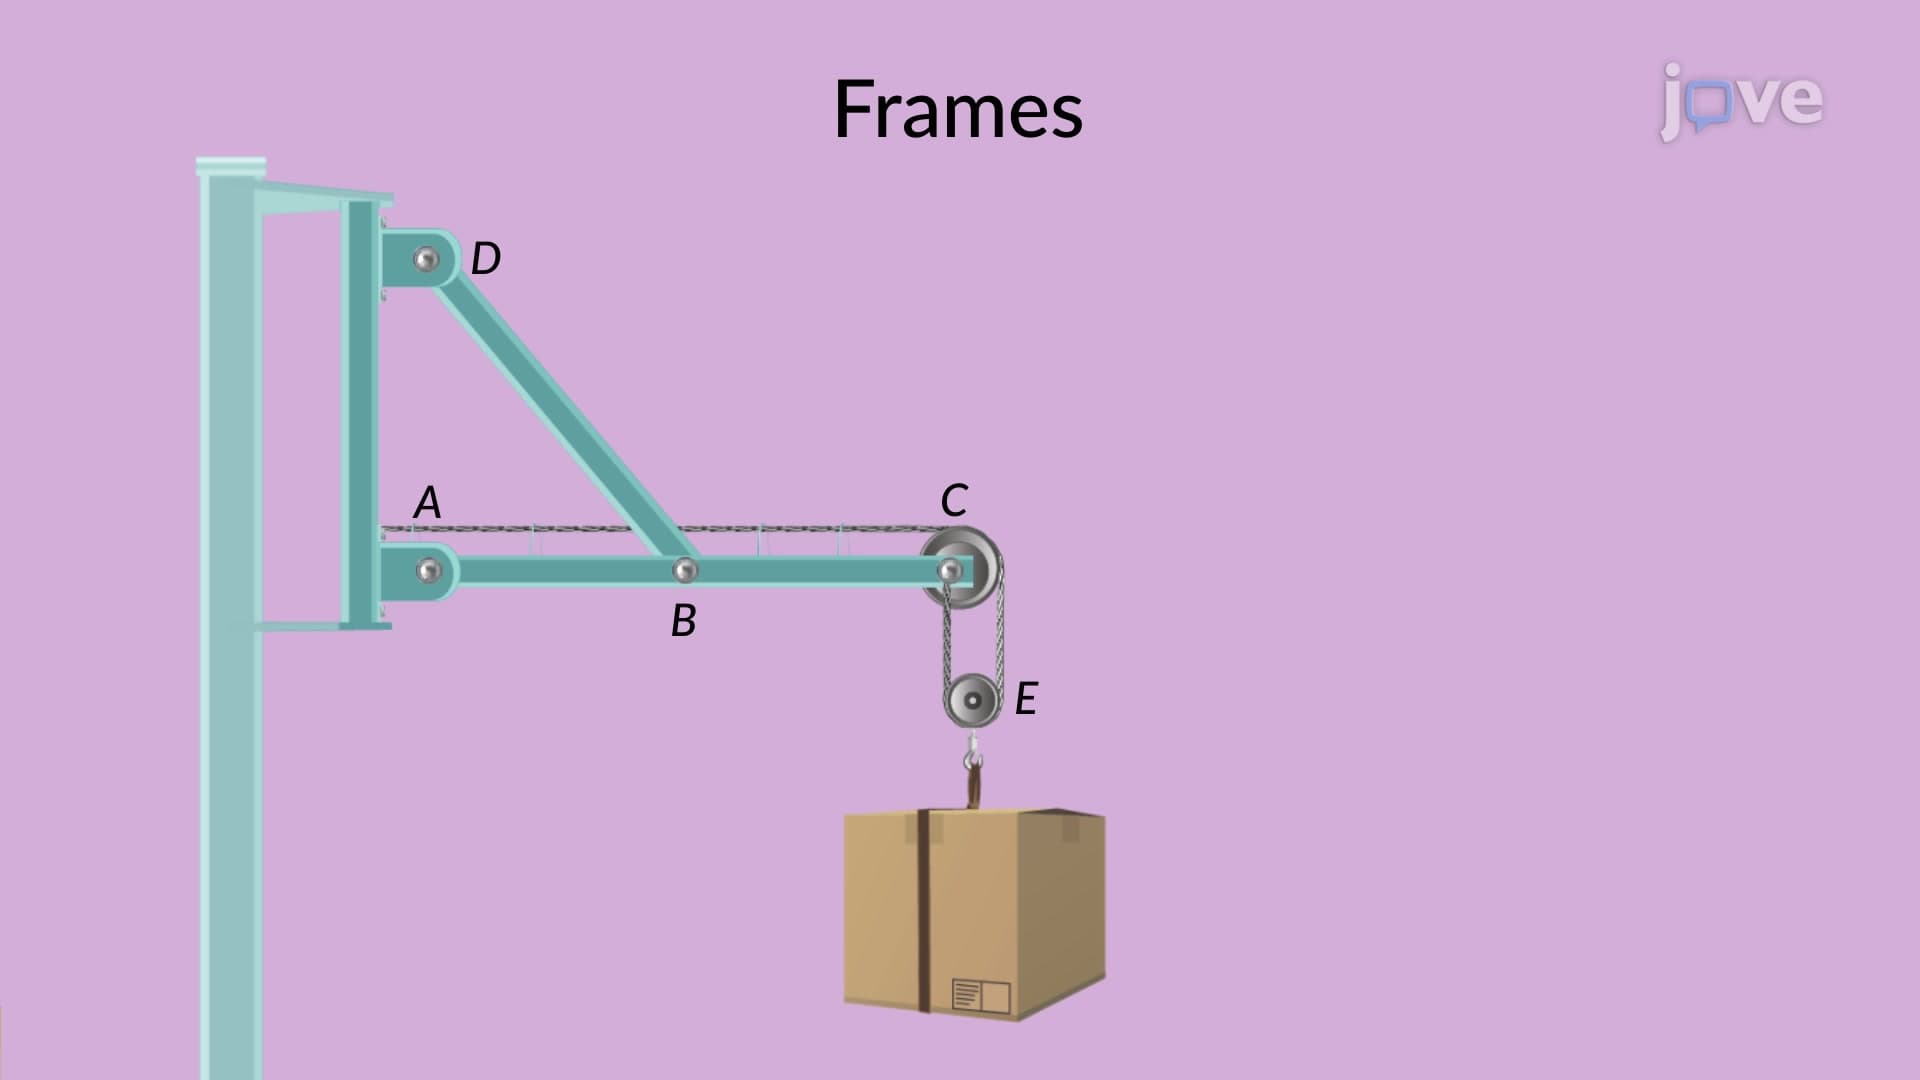
Frames: Problem Solving I
Consider a jib crane with an external load suspended from the pulley. The dimensions of the crane members are shown in the figure. A systematic analysis of the frame structure is required to determine the reaction forces at the pin joints, assuming that the pulleys are frictionless.
 01:30
Machines: Problem Solving II
Machines are complex structures consisting of movable, pin-connected multi-force members that work together to transmit forces. Consider a lifting tong carrying a 100 kg load. It comprises movable sections DAF and CBG linked together with member AB.