

基于机器人总站的分散式多传感器系统使用UAS轨迹估计的审查
Lucas Dammert1, Tomas Thalmann1, David Monetti2
1Research Units Engineering Geodesy and Photogrammetry, Department Geodesy and Geoinformation, TU Wien, 1040 Vienna, Austria.
Sensors (Basel, Switzerland)
|July 12, 2025

概括
本综述探讨了使用机器人总站 (RTS) 进行无人机系统 (UAS) 的精确轨迹估计. 将RTS与内置传感器相结合,可以实现亚厘米精度,这对于GNSS被拒绝的环境至关重要.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 地理学工程 工程地质学
- 航空航天工程 航空航天工程
背景情况:
- 在全球导航卫星系统 (GNSS) 不可靠的情况下,机器人总站 (RTS) 对于精确的轨道估计至关重要.
- 无人机飞行系统 (UAS) 的轨迹估计通常依赖于GNSS,但为了准确性和可用性,需要使用其他方法.
- 尽管RTS具有高精度定位的潜力,但其在UAS轨迹估计中未得到充分利用.
研究的目的:
- 对使用RTS的去中心化多传感器系统进行UAS轨迹估计的专题文献综述.
- 探索RTS与UAS机载传感器 (IMU,激光扫描) 的集成,以提高姿势估计.
- 为了确定挑战和必要的进步,以实现UAS轨迹估计的次厘米准确度,使用RTS.
主要方法:
- 对RTS测量过程现有研究的专题文献综述.
- 对RTS与UAS机载测量 (IMU,激光扫描) 集成的分析.
- 基于RTS的UAS的评估,包括时间同步,大气折射,镜相互作用和图像评估.
主要成果:
- 现有的研究通常涉及基于RTS的UAS轨迹估计的单个组件,但缺乏整合.
- 为了达到亚厘米和亚0.01的准确性,需要结合UAS轨迹估计和RTS校准技术.
- 目前用于无人机的RTS应用程序在现实的动力场景 (距离和速度) 中是有限的.
结论:
- 为了实现高精度定位,需要采用综合方法,将UAS轨迹估计和RTS校准的现有工作结合起来.
- 未来的研究必须解决集成相机成像的时间同步问题,并通过现场测试验证模拟结果.
- 适应现有的综合轨迹估计方法以最佳地纳入RTS数据对于推进UAS导航至关重要.


相关概念视频
 01:30
Types of Global Positioning System Surveys
122
GPS surveying methods vary in application, accuracy, and data collection techniques, catering to diverse surveying and mapping needs. Static GPS, kinematic GPS, and real-time kinematic (RTK) surveying are widely used. Each technique offers distinct advantages.Static GPS involves placing one receiver at a known reference point and another at the target point. It collects exact positional data by observing multiple satellite ranges over an extended period, achieving centimeter-level accuracy for...
122
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
171
Surveyors use Global Positioning System (GPS) technology to measure the precise location and elevation of points on Earth. In a recent survey, GPS receivers were used to determine the coordinates and elevations of two park monuments. The process involved careful mission planning, data collection, and correction to ensure accuracy. The survey began with mission planning to identify optimal satellite visibility and minimize Position Dilution of Precision (PDOP). A geodetic control point...
171
 01:28
Field Application of Global Positioning System
92
The Global Positioning System (GPS) has become an indispensable tool in fieldwork, offering unparalleled precision and efficiency for surveying, navigation, and infrastructure development. By harnessing signals from a constellation of satellites, GPS receivers determine the location of objects with remarkable speed and accuracy, often completing calculations within a second.Advantages of Modern GPS TechnologyContemporary GPS receivers are designed to meet the practical demands of field...
92
 01:26
Errors in Global Positioning System
115
Global Positioning System (GPS) technology has revolutionized navigation and positioning, but its accuracy is often compromised by various errors. These errors, stemming from environmental, satellite, and receiver-related factors, require careful mitigation to ensure reliable performance across applications.Atmospheric ErrorsGPS signals travel through the Earth’s ionosphere and troposphere, introducing delays which affect accuracy. The ionosphere is strongly influenced by charged particles,...
115
 01:17
Common Leveling Mistakes and Errors
128
A survey team is tasked with determining the elevation difference between points Point A and Point B, separated by uneven terrain. They use a leveling instrument and a leveling rod.Common MistakesMisreading the Rod: During a backsight reading at Point A, the instrumentman observes the rod partially obscured by tall grass. Instead of reading 1.135 m, they mistakenly record 1.735 m due to the misalignment of the crosshair with the wrong graduation. This error adds 0.600 m to all subsequent...
128
 01:26
Impact: Problem Solving
261
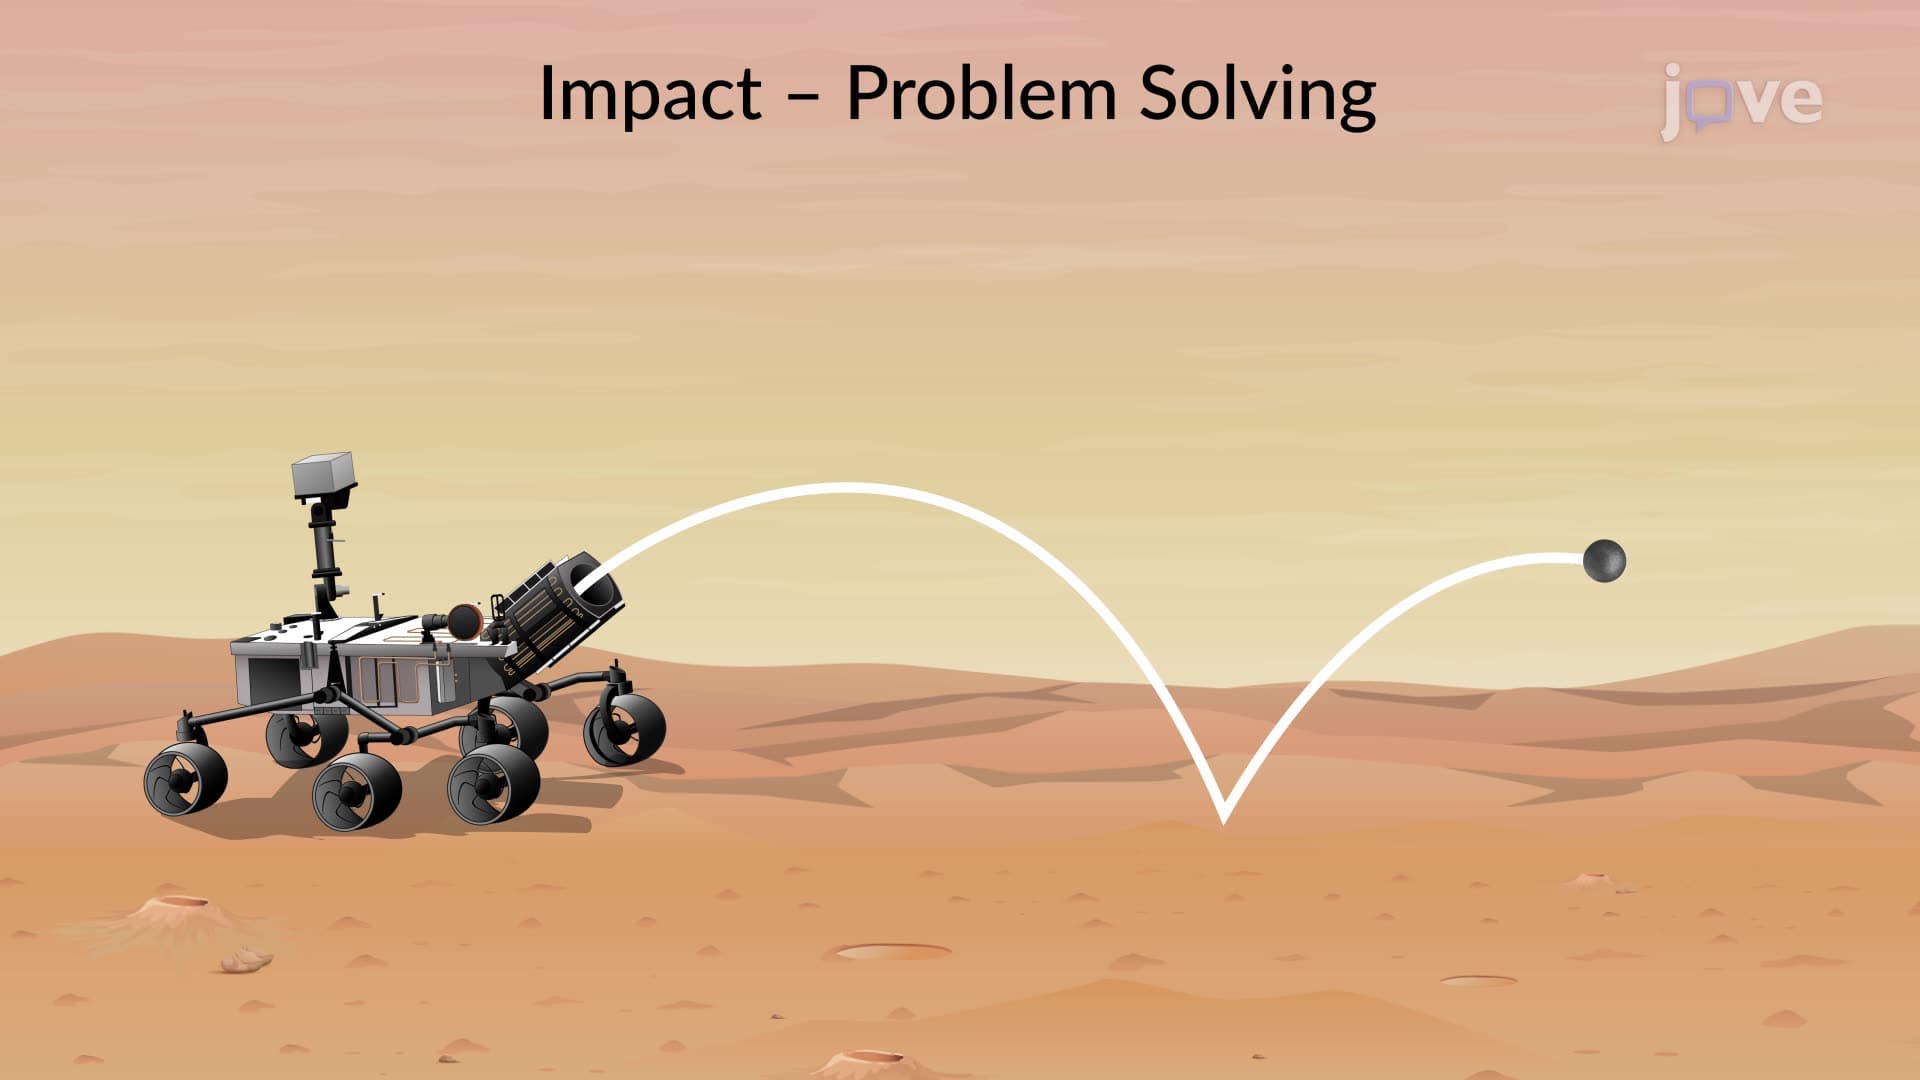
In an experiment conducted during a Mars mission, a rover propels a projectile with an initial velocity, and the projectile rebounds after colliding with the Martian surface. To ascertain the maximum height attained by the projectile after this collision, the known restitution coefficient and acceleration due to gravity are employed.
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
261