相关实验视频
Updated: Sep 16, 2025

10:09
Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
6.7K
双机器人协作研磨抛光系统的动力学校准和轨迹跟踪研究
Wenduan Yan1,2, Luwei Xu1,2, Yifang Sun1
1School of Optoelectronic and Mechanical Engineering, Minnan University of Science and Technology, Quanzhou 362700, China.
Sensors (Basel, Switzerland)
|July 12, 2025

概括
本研究介绍了一种用于双机器人系统的新校准方法,提高了协同研磨和抛光中的运动规划准确性. 经过验证的方法增强了空间绘图,用于精确的机器人操作.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 制造业 工程 制造工程
- 控制系统 控制系统
背景情况:
- 双机器人协作系统面临着运动规划的挑战.
- 准确的空间映射对于精密任务,如研磨和抛光至关重要.
- 现有的校准方法可能缺乏复杂的协作操作所需的准确性.
研究的目的:
- 开发和验证一个系统的解决方案,用于运动规划在双机器人协同研磨和抛光.
- 为了提高机器人基地和工具坐标系统之间的空间绘图精度.
- 提高制造业中双机器人系统的可靠性和实用性.
主要方法:
- 建立了一个双机器人姿势约束模型.
- 整合了"握手"方法与七点校准方法.
- 在MATLAB上使用修改的Denavit-Hartenberg (DH) 方法开发了EPSON C4-A901S机器人的动力建模.
- 构建并模拟了一种双机器人协作研磨模型.
主要成果:
- 实现了增强的空间绘图准确性.
- 通过模拟验证了双机器人协作研磨模型的可靠性.
- 实验验证表明,在重复试验中,平均误差低于8毫米.
- 证实了集成校准方法的实际应用.
结论:
- 提出的系统解决方案有效地解决了双机器人协同研磨和抛光的运动规划挑战.
- 集成的"握手"和七点校准方法显著提高了空间绘图的准确性.
- 经过验证的模型和实验设置证实了系统的准确性和工业应用的准备.

相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
451
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
451
 01:24
One-Degree-of-Freedom System
559
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
559
 01:25
Relative Motion Analysis using Rotating Axes
539
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
539
 01:15
Torque Free Motion
568
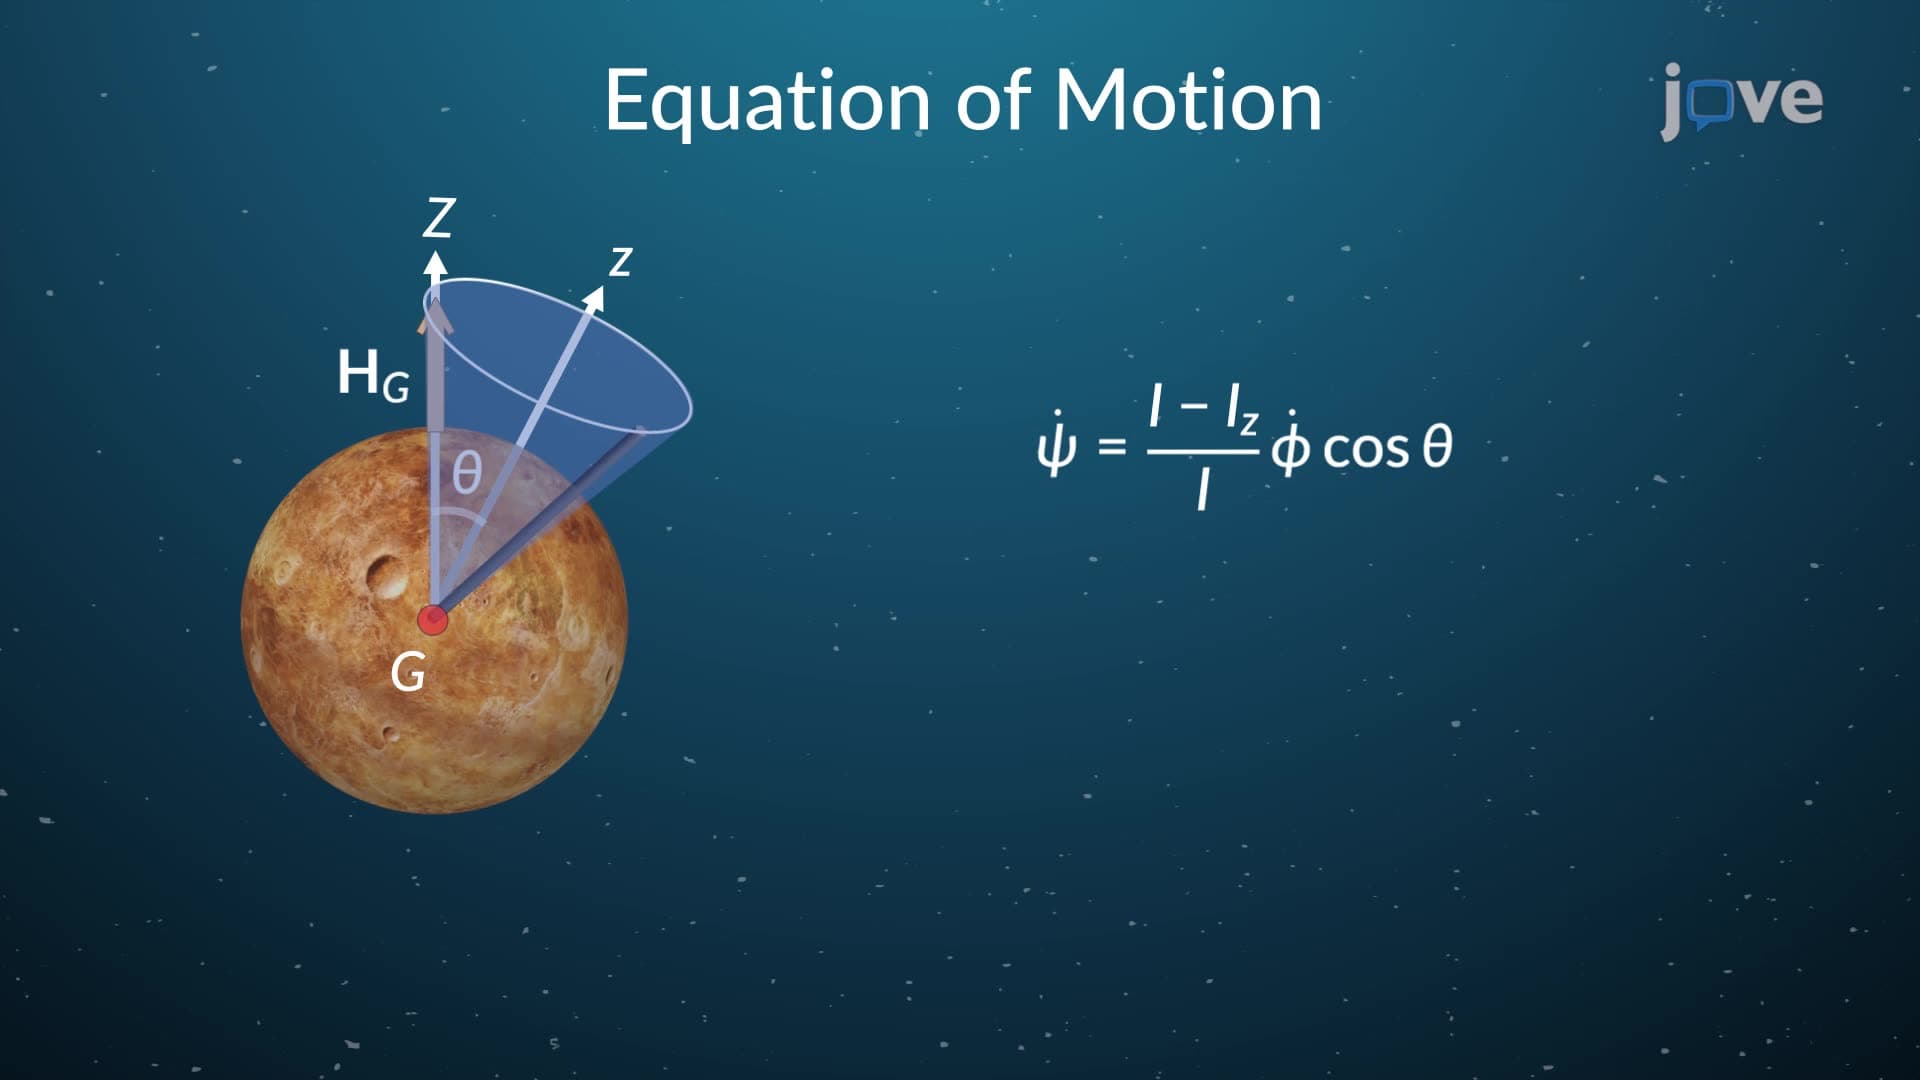
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
568
 01:30
Kinematic Equations for Rotation
378
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
378
 01:11
Glassware Calibration
624
Accurate calibration of glassware, such as volumetric flasks, pipettes, and burettes, is essential to ensure accurate measurements in the analytical laboratory. Calibration helps maintain consistency across measurements and prevents errors arising from inaccurate volumes.
Volumetric flasks: Volumetric flasks are designed to prepare aqueous solutions of precise volumes accurately with a calibration line on the neck. To calibrate a volumetric flask, it is important to fill it with distilled...
Volumetric flasks: Volumetric flasks are designed to prepare aqueous solutions of precise volumes accurately with a calibration line on the neck. To calibrate a volumetric flask, it is important to fill it with distilled...
624