

基于旋转电位计的新型电阻角度传感器的设计和歇斯底里补偿
Ruiqi Liu1, Min Li1,2, Jiahong Zhang1,2
1School of Integrated Circuits, Nanjing University of Information Science and Technology, Nanjing 210044, China.
Sensors (Basel, Switzerland)
|July 12, 2025

概括
本研究介绍了用于工业自动化的一种经济高效的电阻角度传感器. 软件补偿显著减少了非线性和歇斯底里错误,提高了敏感应用程序的精度.
科学领域:
- 电气工程 电气工程
- 传感器技术 传感器技术
- 机械电子学是什么意思 机械电子学
背景情况:
- 电阻角度传感器因其简单的信号调节和成本效益而受到重视.
- 由于机械因素,现有的传感器面临着线性和歇斯底里的挑战.
- 在工业自动化和EMI敏感环境中,需要精确,低成本的角度测量.
研究的目的:
- 开发和验证使用旋转电位计的高精度电阻角度传感器.
- 通过先进的软件补偿技术来解决非线性和歇斯底里错误.
- 为了在苛刻的应用中为180°角测量提供一个具有成本效益的解决方案.
主要方法:
- 设计了一种具有专门信号调节电路和机械外的新型电阻角度传感器.
- 实现一种自适应线性神经元 (ADALINE) 技术,利用α-最小平均平方 (α-LMS) 算法进行软件补偿.
- 对传感器性能进行实验性评估,包括线性,温度稳定性和误差减少.
主要成果:
- 传感器表现出极好的线性和温度稳定性 (-20°C至60°C),最小的零温度漂移 (0.004°/°C).
- 软件补偿有效地将非线性误差从4.413%降至0.182%.
- 在补偿后,歇斯底里斯误差从4.061%显著降低到0.404%.
结论:
- 开发的电阻角度传感器通过有效的软件补偿实现了高精度.
- 基于ADALINE的补偿方法成功地减轻了非线性和hysteresis错误.
- 这项研究为设计用于工业自动化的高性能,低成本电阻角度传感器提供了宝贵的见解.

相关概念视频
 01:30
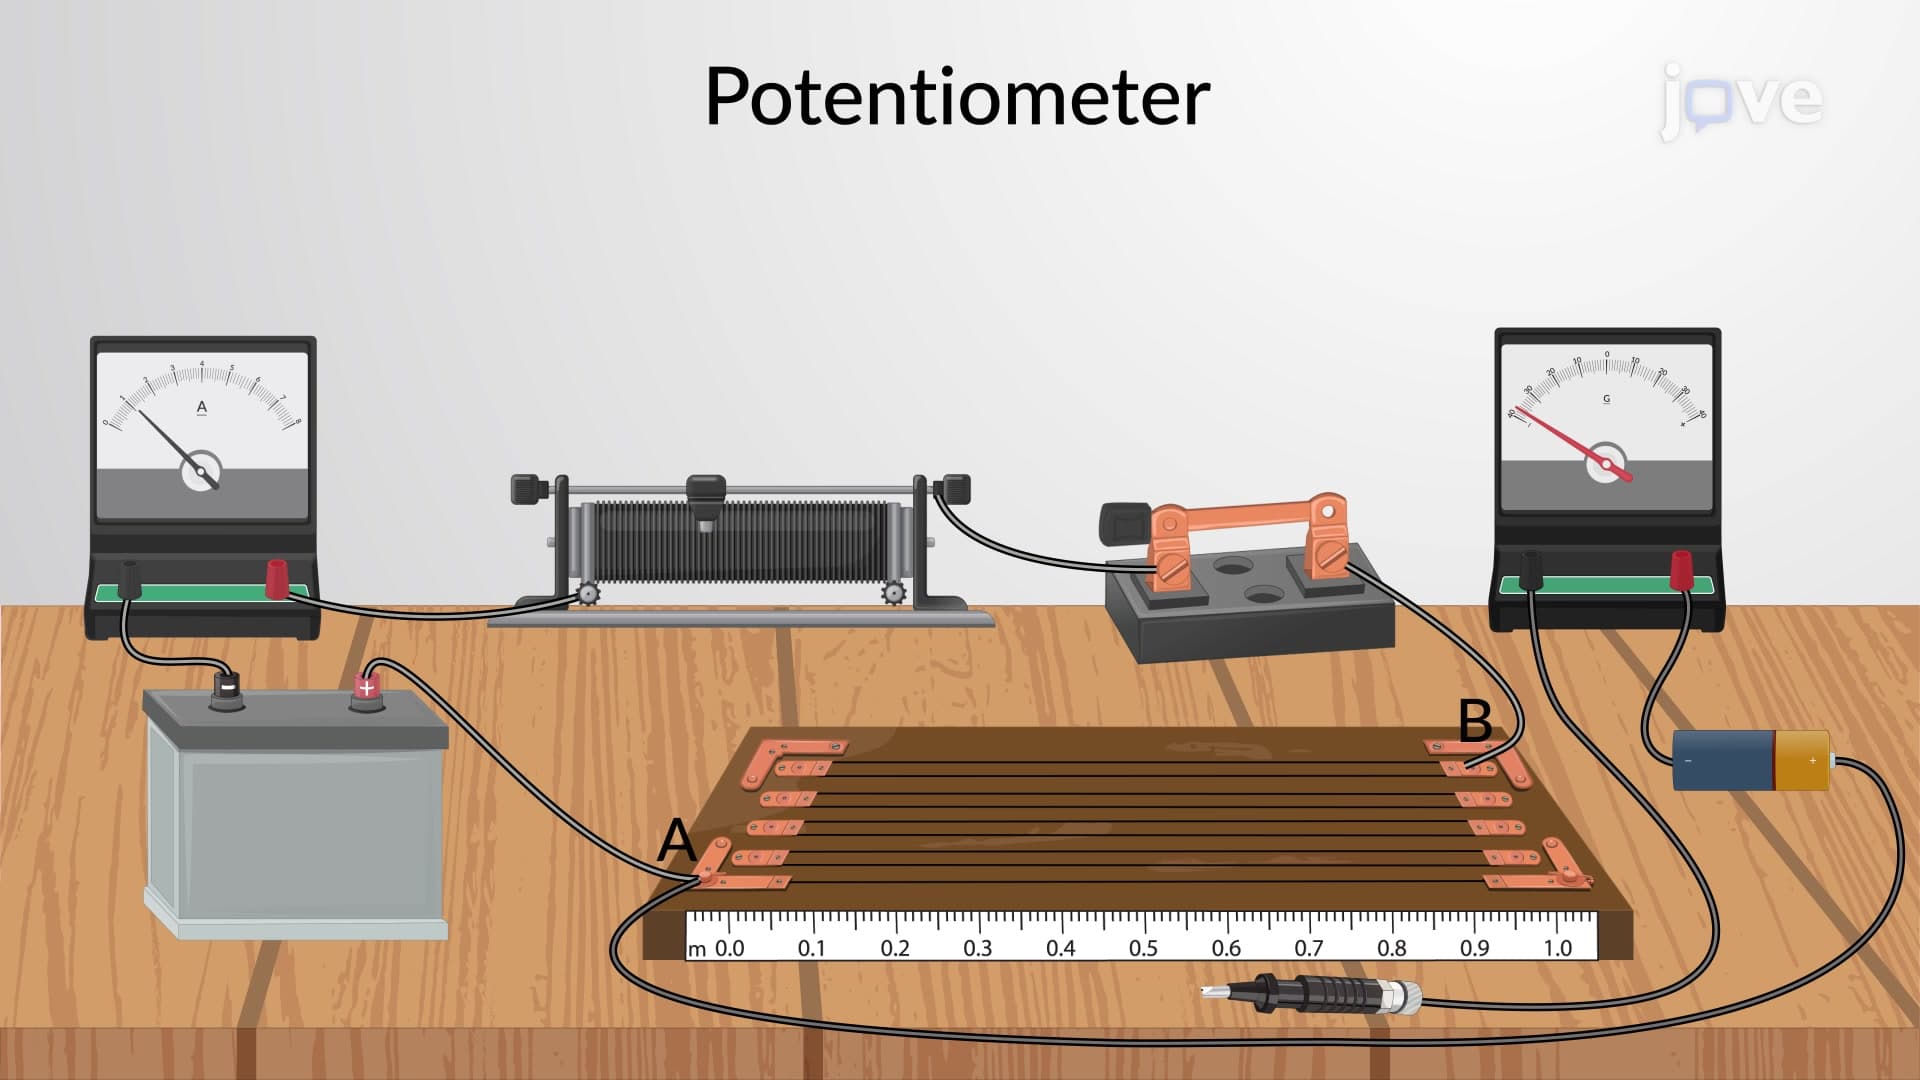
Potentiometer
1.1K
Voltage and current measurements using a standard voltmeter and ammeter alter the circuit being measured either by drawing or resisting the current flow, which introduces uncertainties in the measurements. Null measurements balance the voltages so that no current flows through the measuring device and, therefore, no alterations occur in the measured circuit.
Suppose the emf of a battery needs to be measured. If the battery is directly connected to a standard voltmeter, the measured quantity is...
Suppose the emf of a battery needs to be measured. If the battery is directly connected to a standard voltmeter, the measured quantity is...
1.1K
 01:24
PI Controller: Design
504
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
504
 01:26
PD Controller: Design
356
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
356
 01:14
Design Example: Resistive Touchscreen
435
A device engineer plays a crucial role in designing user interfaces for mobile devices. One such interface is the resistive touchscreen, which fundamentally consists of two metallic layers: a flexible upper layer and a rigid lower layer, separated by a narrow gap. The high resistance between these two layers is a key characteristic of this design.
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
435
 01:15
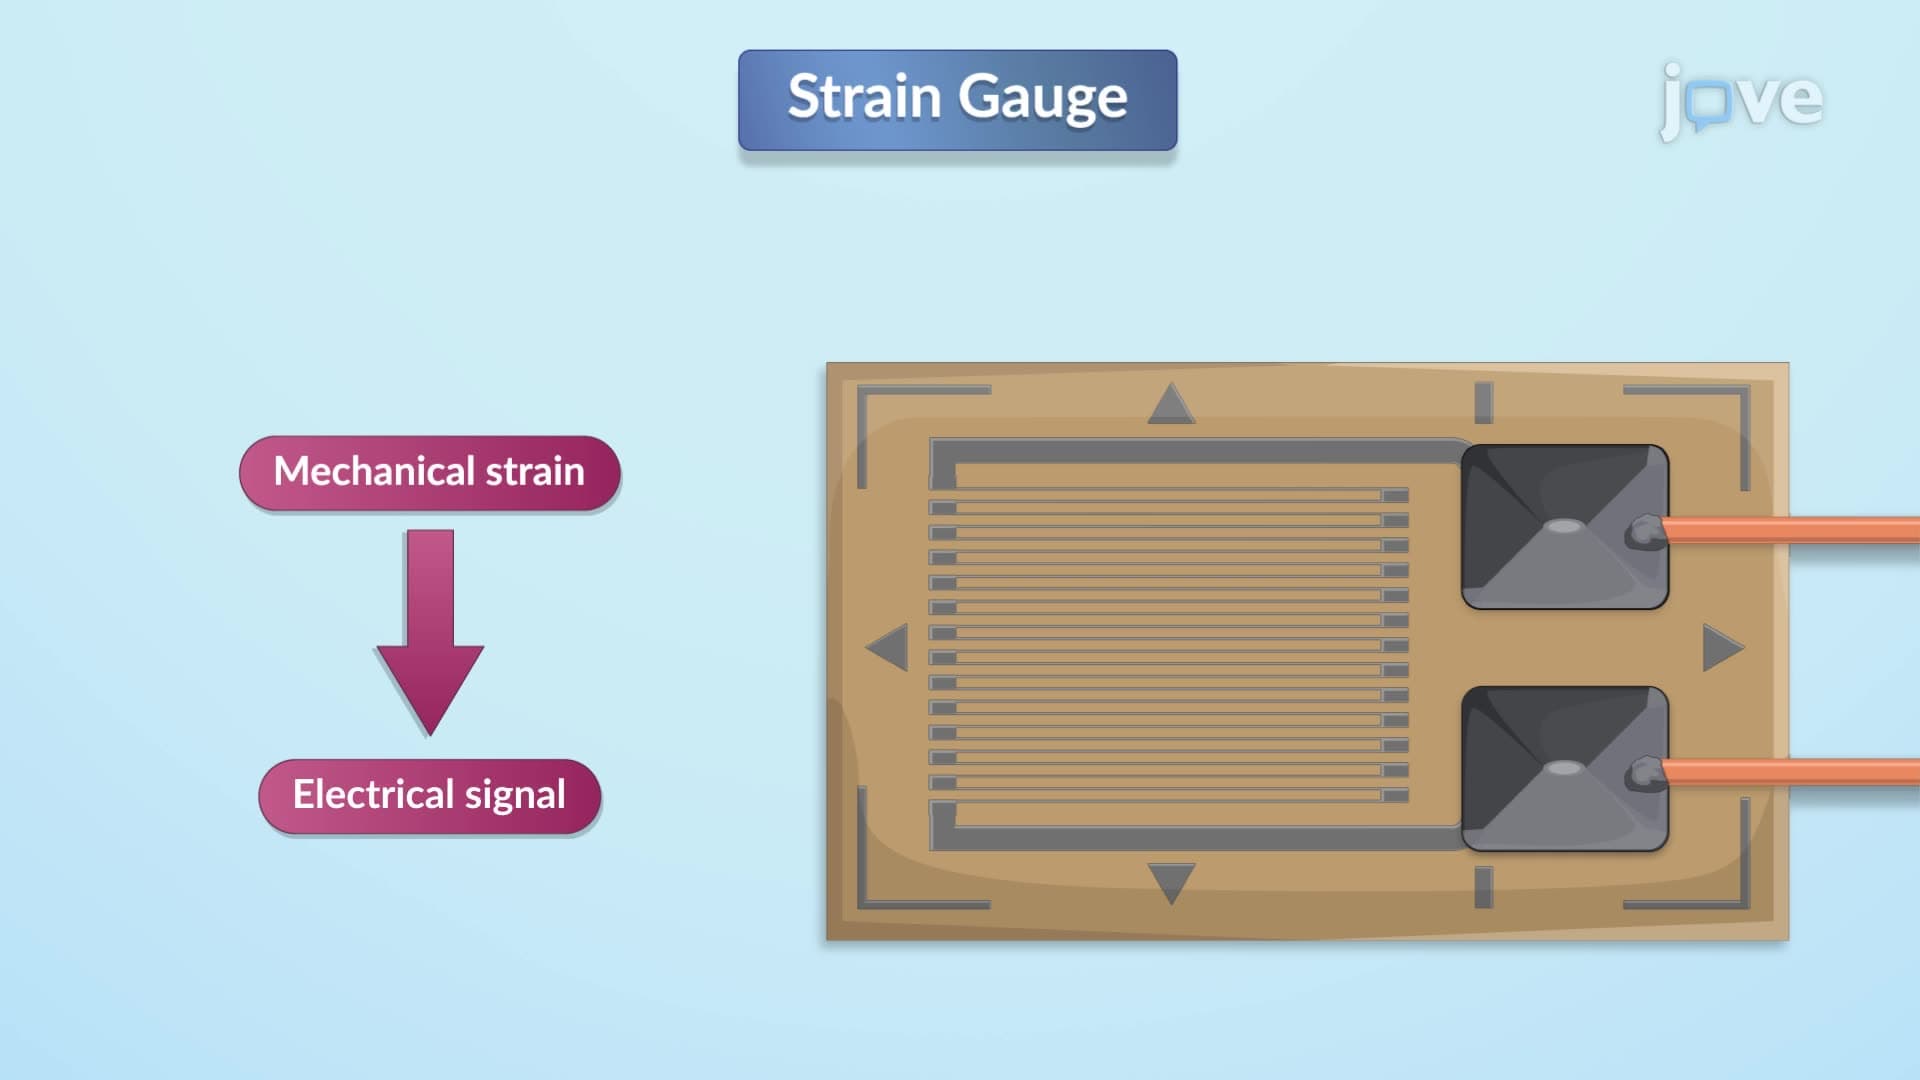
Design Example: Strain Gauge Bridge or Wheatstone Bridge
538
The utilization of strain gauges as transducers for converting mechanical strain into electrical signals is a common practice in various engineering applications. These strain gauges are frequently integrated into Wheatstone bridge circuits to accurately measure parameters such as force or pressure. Within this context, each element within the circuit exhibits a resistance that undergoes subtle variations when subjected to mechanical strain. The primary objective is to convert minuscule...
538
 01:07
Time-Domain Interpretation of PD Control
182
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
182