相关实验视频
Updated: May 8, 2026
12:18

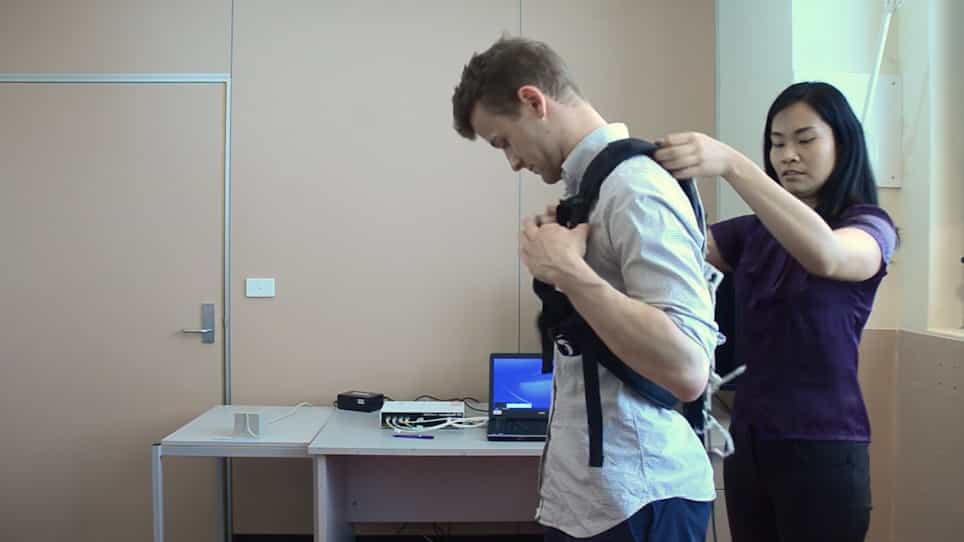
An Instrumented Pull Test to Characterize Postural Responses
Published on: April 6, 2019
10.9K
对视觉和姿势威胁对直立姿势的影响的非线性分析
Sara E Weinberg1, Stephen Palmisano2, Robert S Allison3
1School of Kinesiology and Health Science, York University, 4700 Keele St, Toronto, ON M3J 1P3, Canada; Centre for Vision Research, York University, 4700 Keele St, Toronto, ON M3J 1P3, Canada.
Gait & posture
|July 12, 2025

概括
静静地站立的非线性分析揭示了身高和视力如何影响平衡控制. 复发量化分析 (RQA) 为评估姿势摇摆动态提供了更强大的方法.
科学领域:
- 生物力学和电机控制
- 人的姿势稳定性 人的姿势稳定性
- 非线性动力学是一种非线性动力学.
背景情况:
- 直立姿势对于人类互动至关重要.
- 对姿势摆动的线性分析是有限的.
- 非线性动力学为姿势控制提供了更深入的见解.
研究的目的:
- 调查非线性方法是否可以更好地识别因身高和视力而导致的静止站立的变化.
- 分析姿势威胁和视觉输入对姿势摇摆的影响.
主要方法:
- 对20名健康年轻成年人的现有数据进行二次分析.
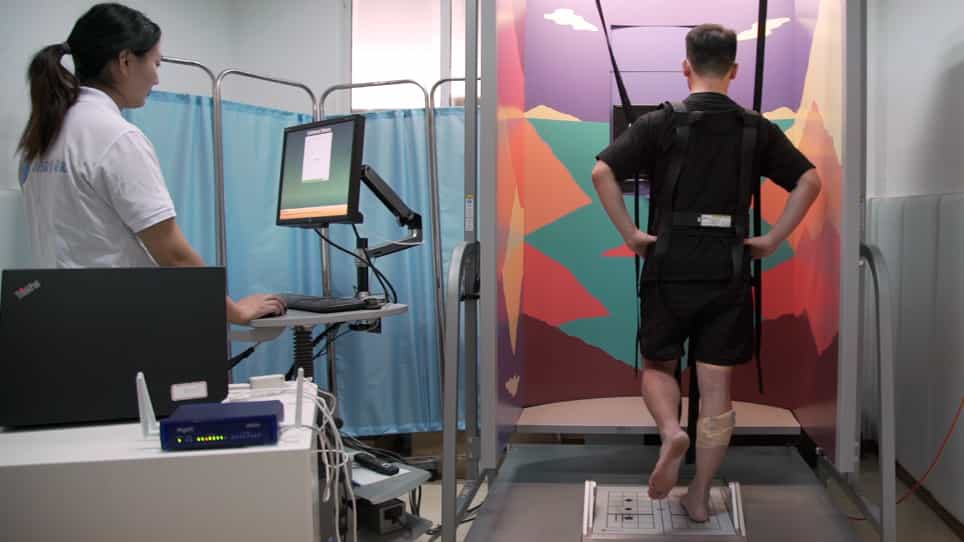
- 在不同的高度 (地面与3.2米) 和视力 (眼睛打开与眼睛关闭) 条件下,静静的站立任务.
- 重复量化分析 (RQA) 应用于压力中心 (COP) 和质量中心 (COM) 数据.
主要成果:
- RQA测量 (%DET,ENT,LINE) 显示身高和视力对COP影响有显著的影响.
- COM sway还显示了视力和身高对%DET,ENT和LINE的显著影响.
- 摇摆动态中最显著的变化是在高度,闭眼的情况下观察到的.
结论:
- 非线性RQA检测了线性方法错过的摇摆动态差异.
- 结果表明,在增加姿势威胁或减少感官输入的条件下,随机性和适应性增加.
- 非线性分析提供了一个更强大的工具,以了解在具有挑战性的条件下的姿势控制.

相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
Curvilinear Motion: Normal and Tangential Components
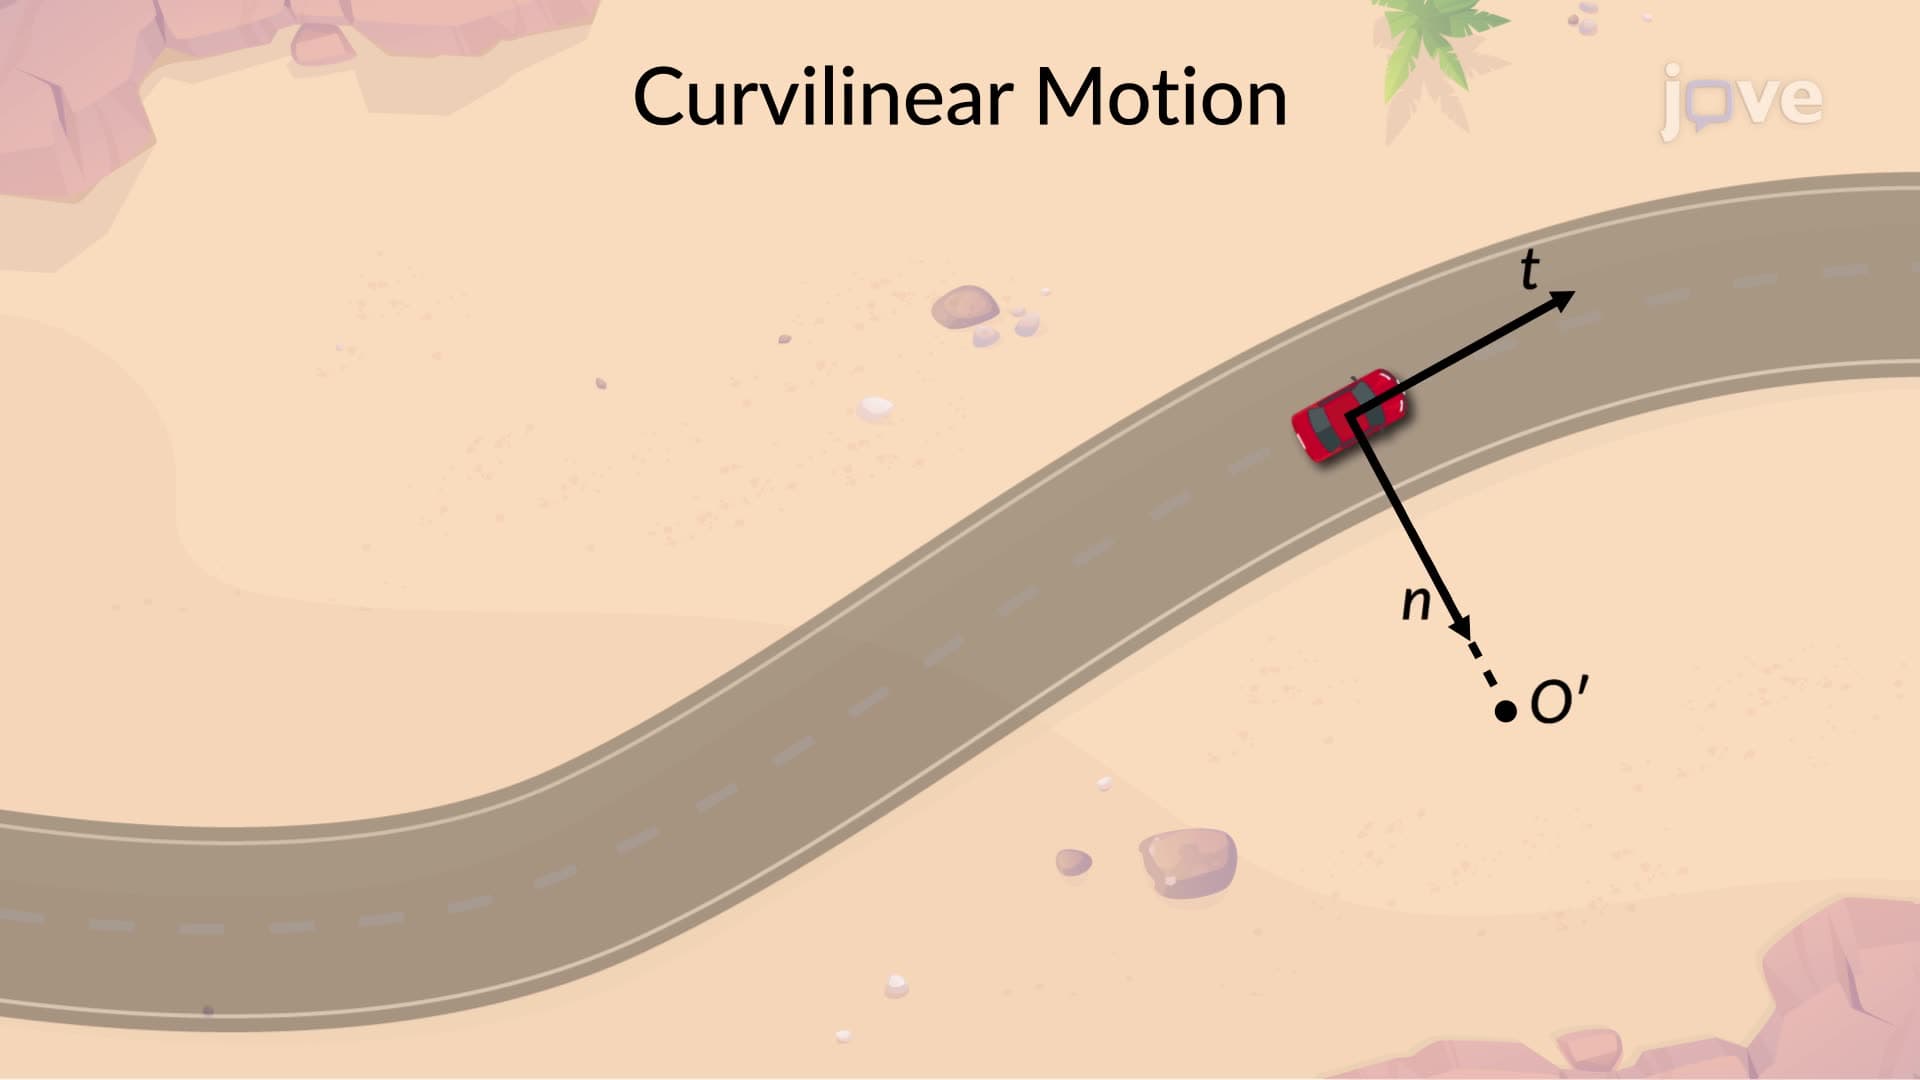
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Actor-Observer Effect
The actor-observer effect, a cognitive bias closely linked to the fundamental attribution error, refers to the tendency for individuals to attribute their behavior to external, situational factors while explaining others’ behavior in terms of internal, dispositional traits. This asymmetry in attribution significantly influences social perception and judgment.Cognitive Mechanisms Behind the EffectTwo primary psychological mechanisms contribute to the actor-observer effect: differences in visual...