

平均平方指数 l2-l∞ 控制交换-马科夫式跳跃系统的控制与边缘依赖的过渡概率
IEEE transactions on cybernetics
|July 15, 2025

概括
本研究引入了交换式马科夫跳跃系统 (SMJS) 的新控制方法,以确保稳定性和性能. 新的过渡概率和停留时间策略保证了平均平方指数稳定性.
科学领域:
- 控制系统工程 控制系统工程
- 随机系统分析 随机系统分析
- 应用数学 应用数学 应用数学
背景情况:
- 交换-马科夫跳跃系统 (SMJSs) 结合了决定性和随机动态.
- 现有的控制方法在SMJS中难以处理复杂的切换行为.
- 在混合开关下确保稳定性和性能是一个关键的挑战.
研究的目的:
- 为了研究SMJS的平均平方指数l2-l∞控制.
- 开发用于处理决定性和随机切换的新方法.
- 用先进的控制技术来保证系统的稳定性和性能.
主要方法:
- 引入模式依赖转换概率 (MDTP) 和边缘依赖转换概率 (EDTP).
- 模式依赖平均停留时间 (MDADT) 适用于确定性切换.
- 使用多重不连续的利亚普诺夫函数技术.
- 导出可解决的足够条件用于控制器设计.
主要成果:
- 拟议的MDADT方法,MDTP和EDTP保证了SMJS的平均平方指数稳定性与l2-l∞性能.
- 成功获得了用于控制器合成的可解决的充分条件.
- 开发方法的有效性通过数值和实践示例来验证.
结论:
- 该研究成功地解决了SMJS的平均平方指数l2-l∞控制问题.
- 拟议的控制策略有效地管理混合切换动态.
- 这些发现为控制复杂的SMJS在现实应用中提供了强大的框架.

相关概念视频
 01:24
BIBO stability of continuous and discrete -time systems
523
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
523
 01:10
Entropy Change in Reversible Processes
2.7K
In the Carnot engine, which achieves the maximum efficiency between two reservoirs of fixed temperatures, the total change in entropy is zero. The observation can be generalized by considering any reversible cyclic process consisting of many Carnot cycles. Thus, it can be stated that the total entropy change of any ideal reversible cycle is zero.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
2.7K
 01:18
Second Order systems II
173
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
173
 01:23
Linear time-invariant Systems
436
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
436
 01:30
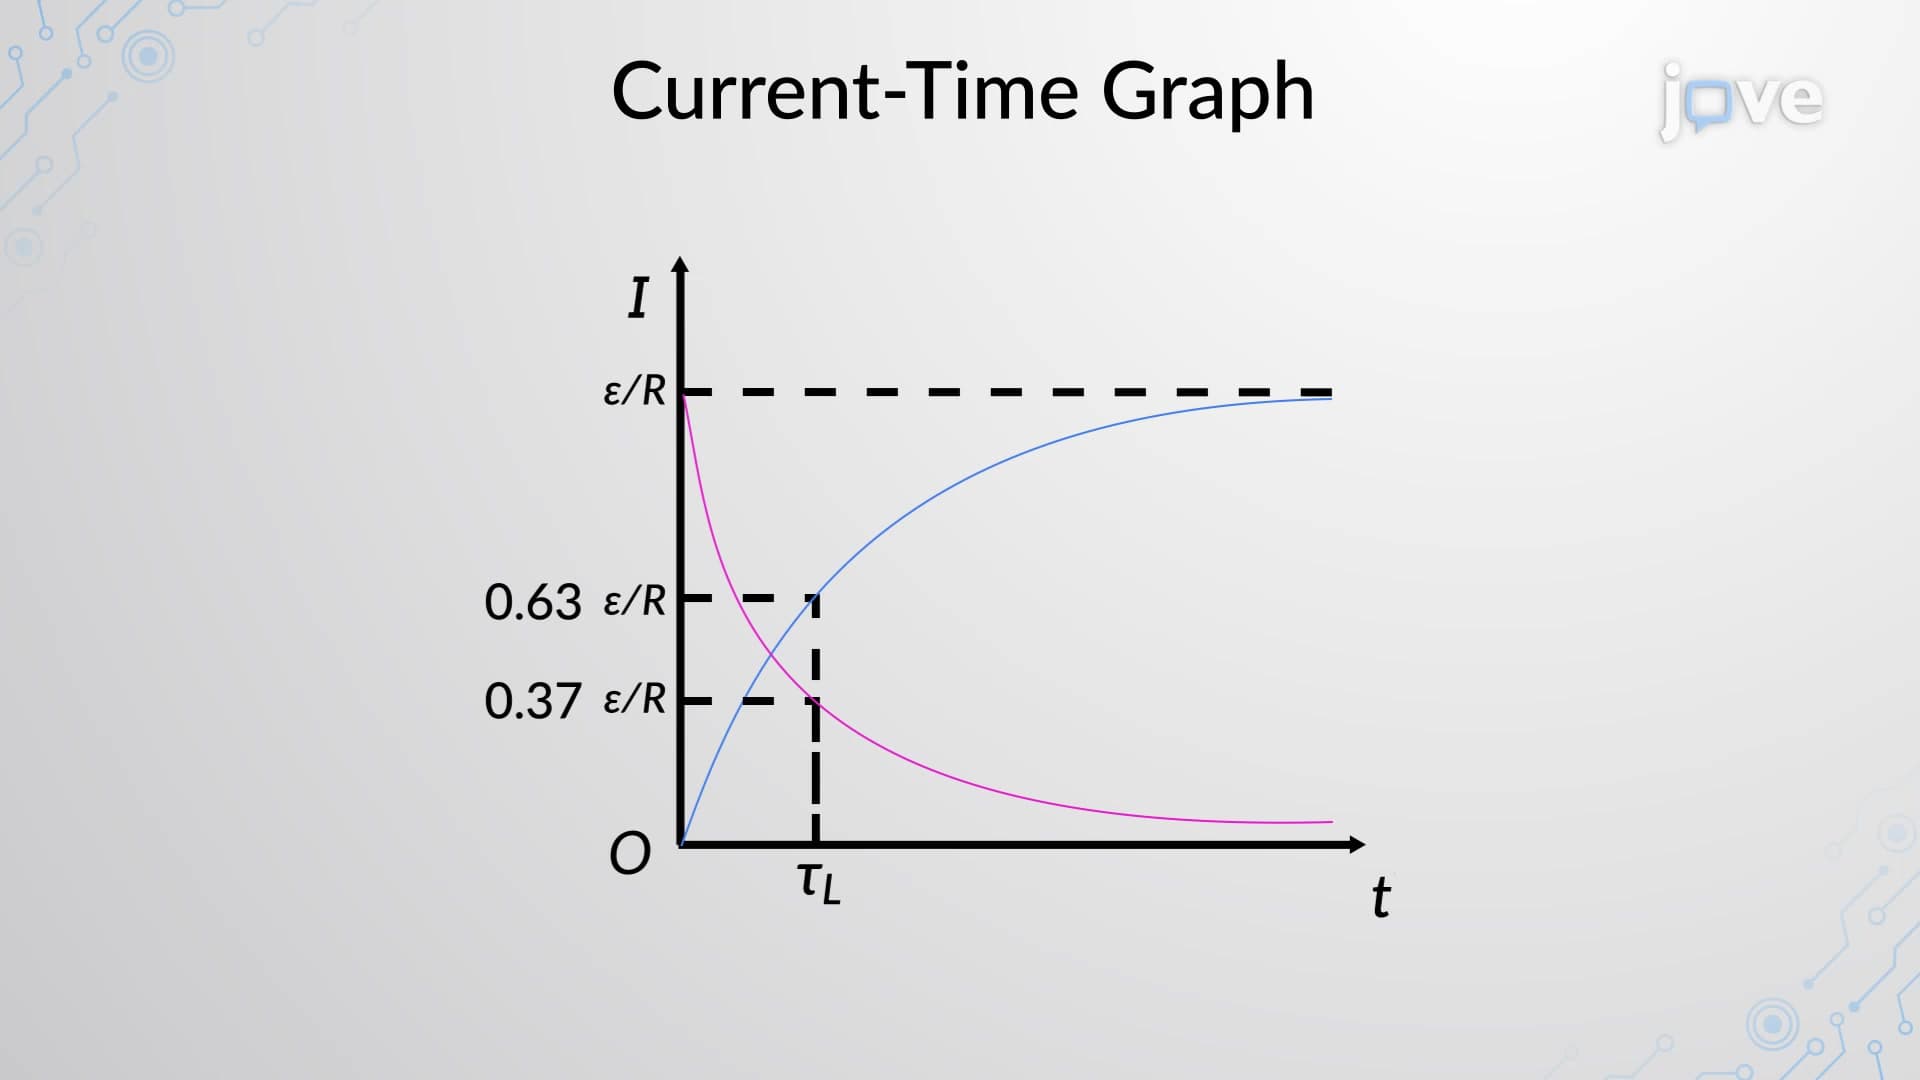
Current Growth And Decay In RL Circuits
4.0K
The current growth and decay in RL circuits can be understood by considering a series RL circuit consisting of a resistor, an inductor, a constant source of emf, and two switches. When the first switch is closed, the circuit is equivalent to a single-loop circuit consisting of a resistor and an inductor connected to a source of emf. In this case, the source of emf produces a current in the circuit. If there were no self-inductance in the circuit, the current would rise immediately to a steady...
4.0K
 01:21
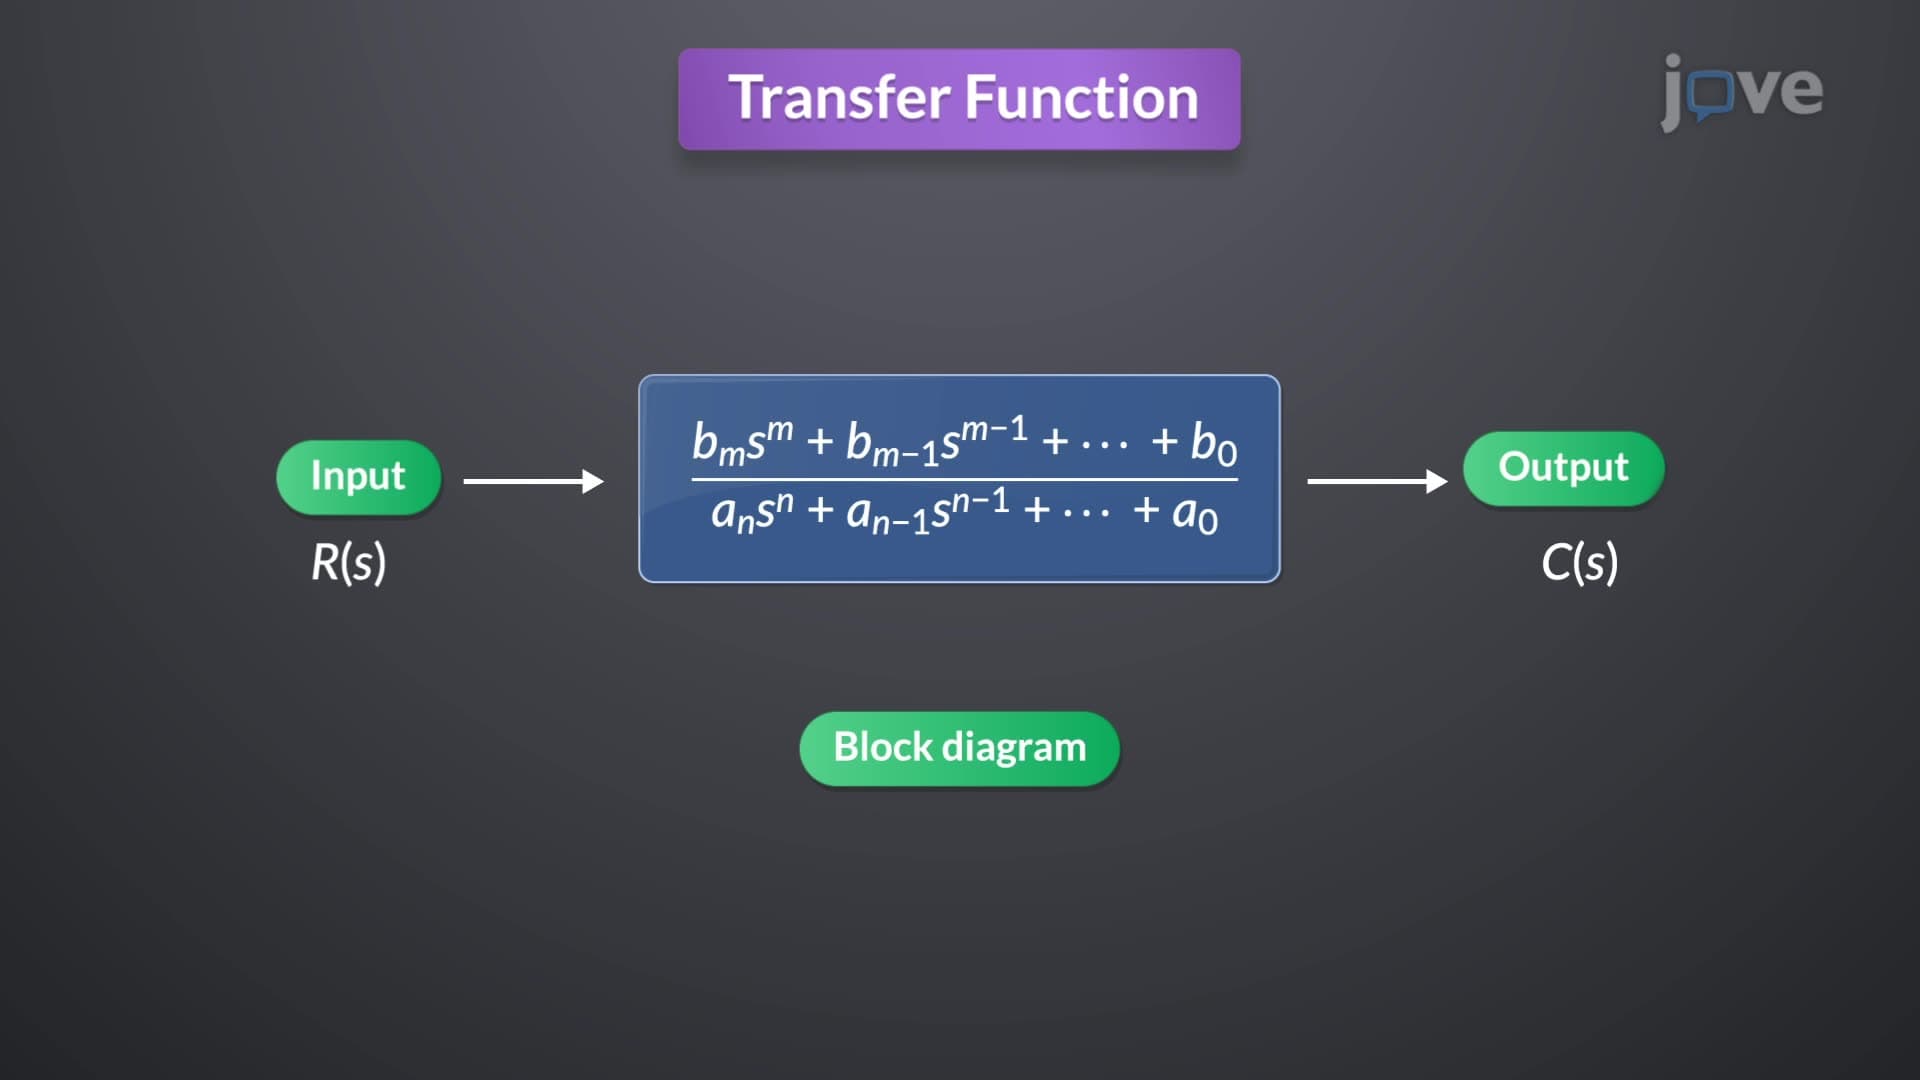
Transfer Function in Control Systems
879
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
879