
一个新的基于回退的轨迹跟踪控制与零动态稳定性,用于未经调节的头部起重机
Ning Li1, Xiaoping Liu2, Cungen Liu3
1College of Information Science and Technology, Donghua University, Shanghai, 201620, China.
ISA transactions
|July 20, 2025

概括
这项研究引入了一种新的后退控制方案,用于2DOF头部起重机,以抑制负载摆动. 新方法实现了快速沉降时间和最小的稳定状态误差,提高了起重机控制性能.
科学领域:
- 机器人和控制系统 机器人和控制系统
- 机械工程 机械工程
背景情况:
- 由于未经调节的负载摆动,未经调节的头部起重机存在重大控制挑战.
- 现有的反摇摆控制方法有局限性,并且这些系统以前没有应用后退控制.
研究的目的:
- 为2-DOF高头起重机提出第一个基于倒退的轨迹跟踪控制方案.
- 为了实现有效的负载摆动抑制,并提高过渡和稳定状态性能.
主要方法:
- 一个具有状态合函数的新型变量转换被设计用于摆动抑制.
- 为了提高稳定状态的性能,一个整体状态被纳入了Lyapunov候选函数.
- 一个轨迹跟踪控制器是使用后退开发的,使用一个新的参数调方法,利用杆位.
主要成果:
- 通过零动态分析和利亚普诺夫稳定性定理,拟议方案被严格证明是稳定的.
- 实验结果显示,车沉降时间约为5秒,稳定状态误差在0.5%以内.
- 负载摆动角度在约4秒内有效控制在[-0.5度,0.5度]内.
结论:
- 块后退控制方案提供了一个强大的和有效的解决方案,用于轨迹跟踪和反摆控制在2-DOF头部起重机.
- 新的参数调整方法简化了控制参数的调整.
- 拟议的方法在性能和稳定性方面优于现有技术.

相关概念视频
 01:14
Stability of structures
254
In mechanical engineering, the stability of systems under various forces is critical for designing durable and efficient structures. One fundamental way to explore these concepts is by analyzing systems like two rods connected at a pivot point, O, with a torsional spring of spring constant k at the pivot point. This system is similar in appearance to a scissor jack used to change tires on a car. In this case, the arms of the linkage (equivalent to the rods in this system) are entirely vertical,...
254
 01:15
Kinematic Equations: Problem Solving
14.7K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
14.7K
 01:24
One-Degree-of-Freedom System
558
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
558
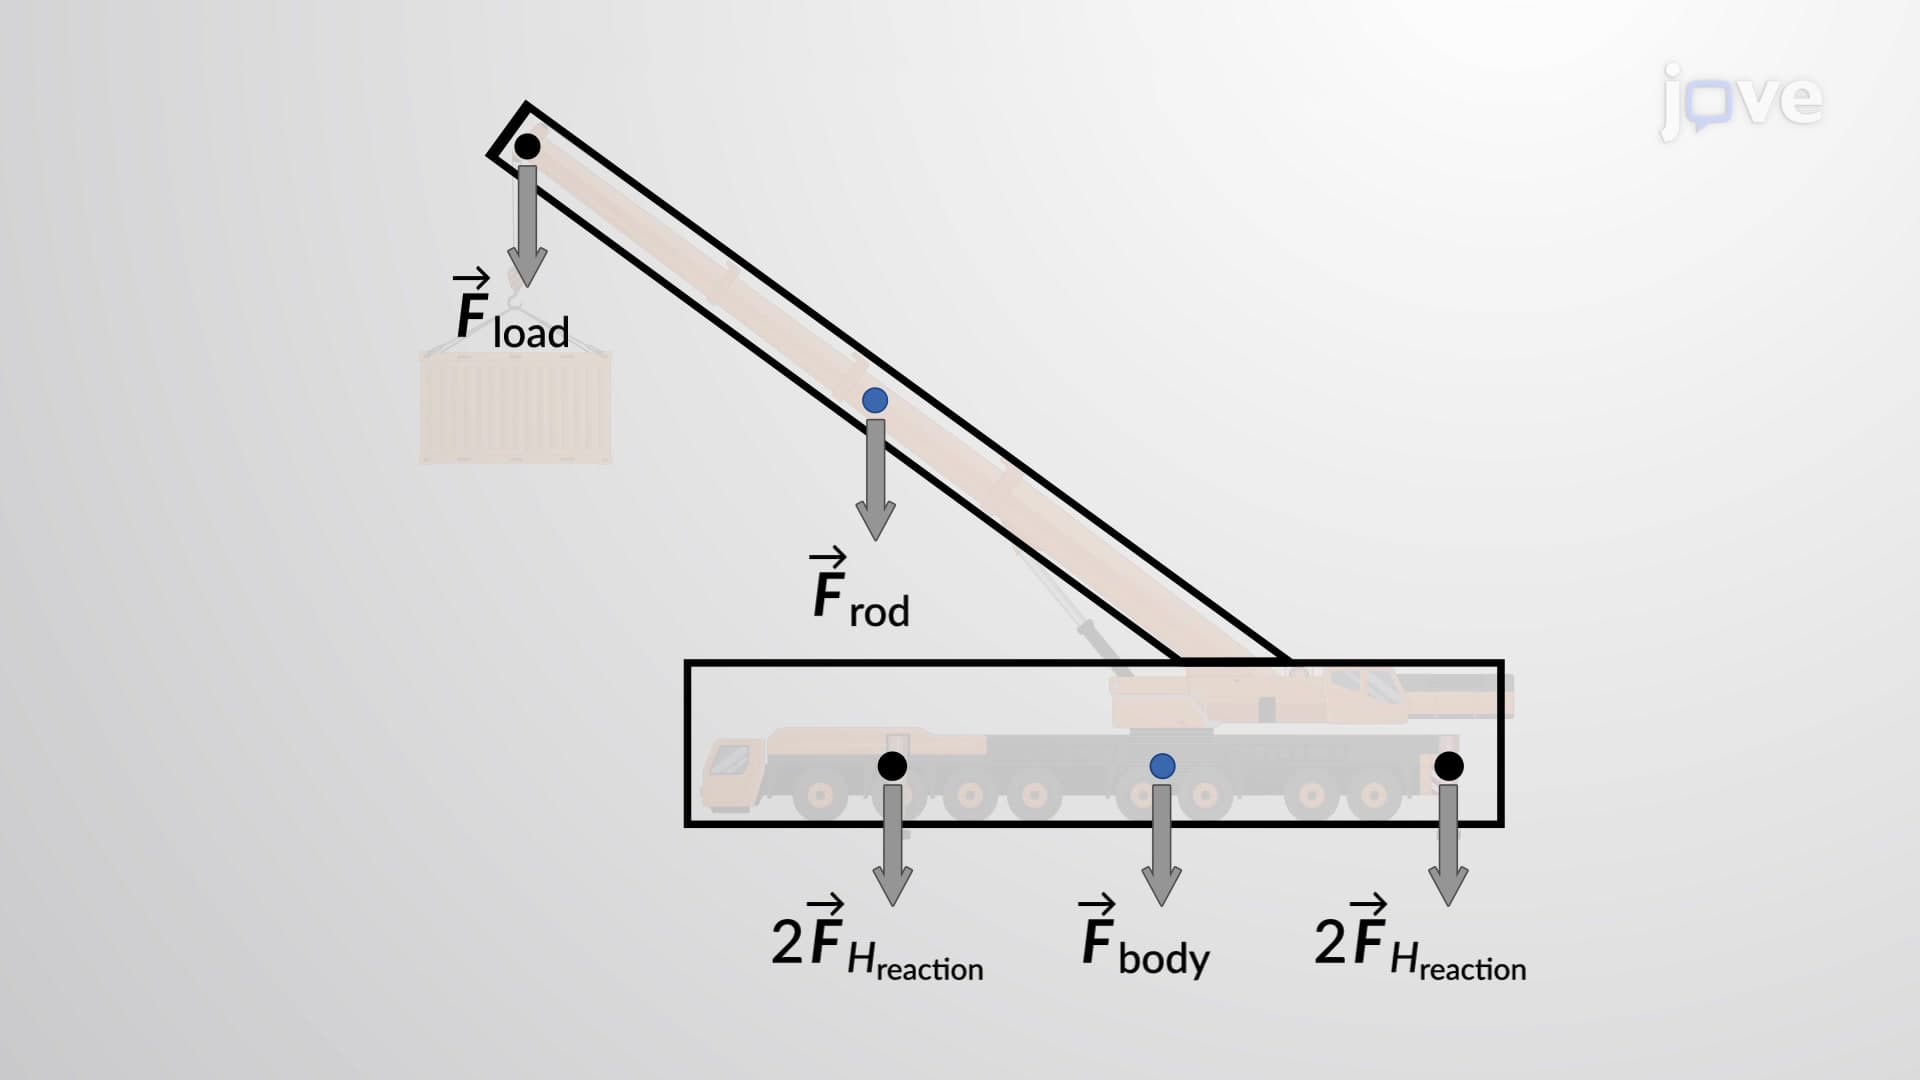 00:49
Rigid Body Equilibrium Problems - I
4.8K
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
4.8K
 01:22
Controller Configurations
151
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
151
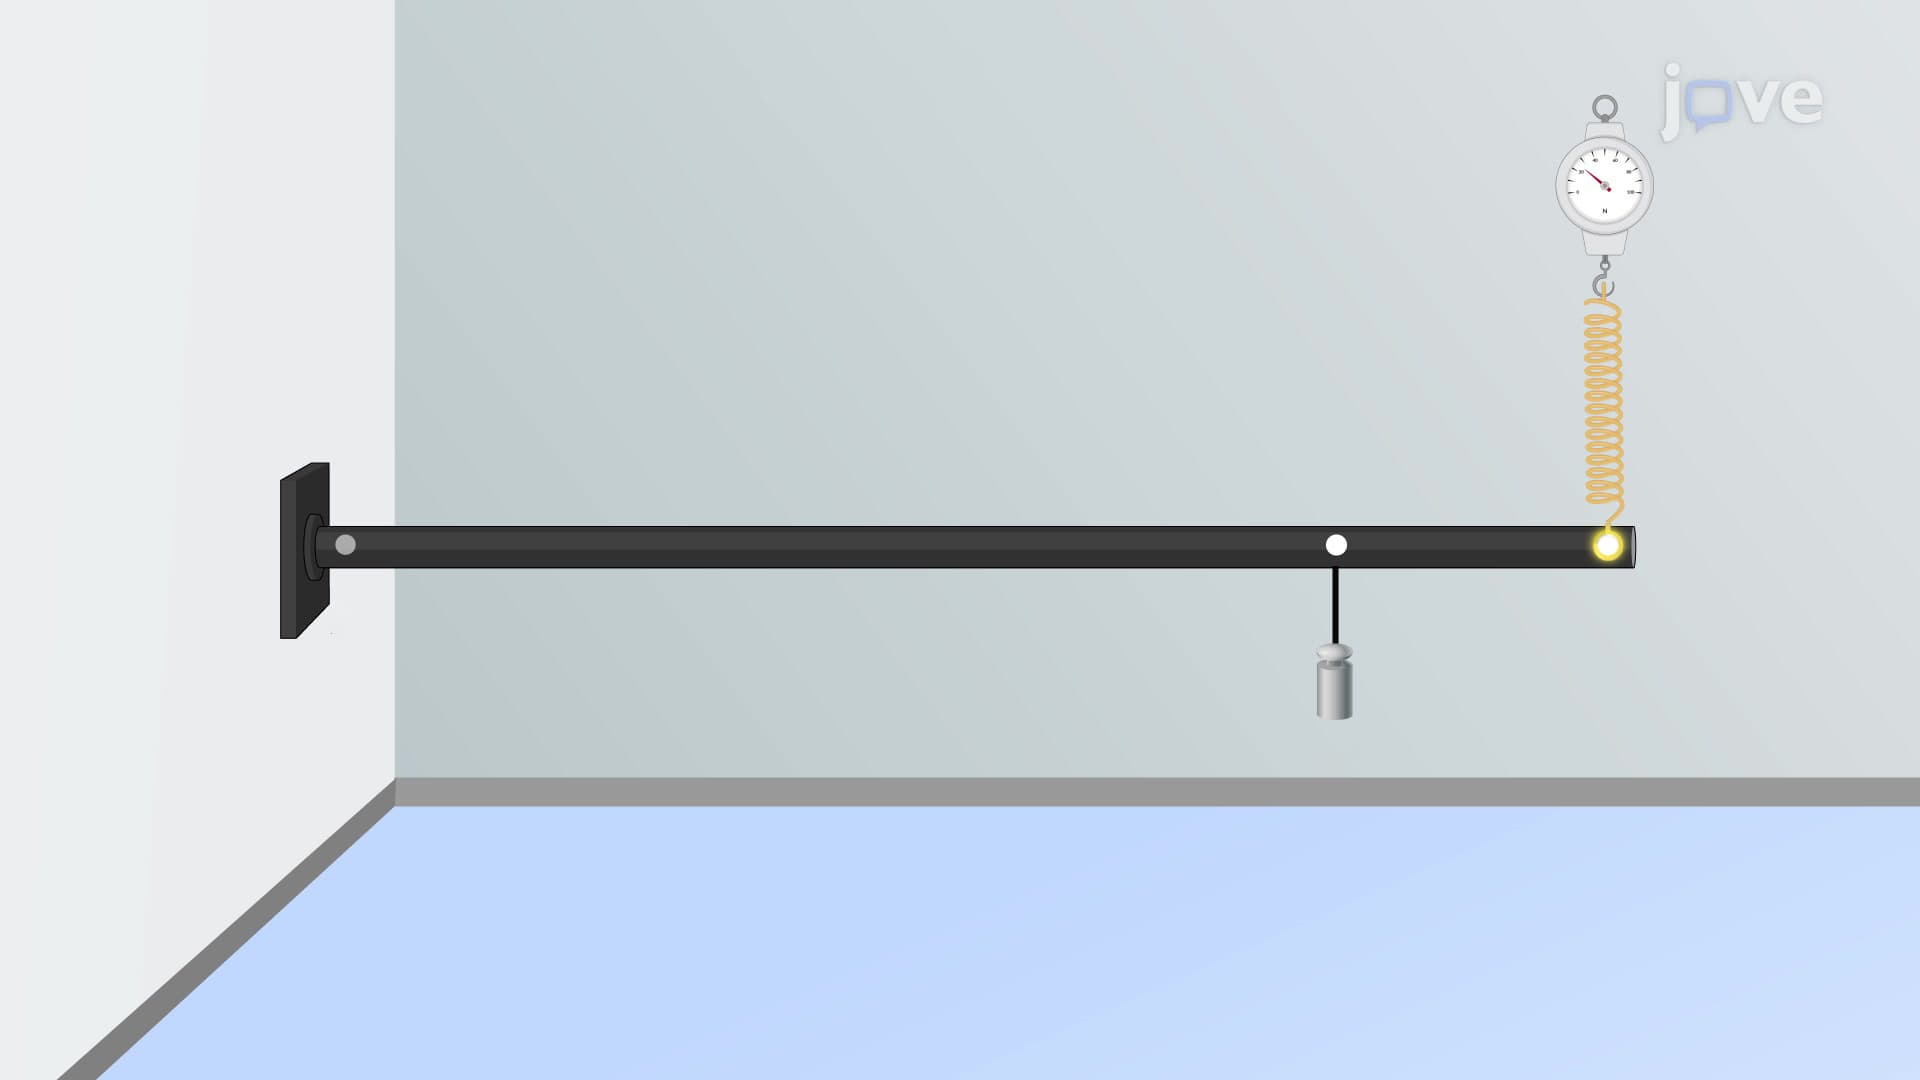 01:21
Rigid Body Equilibrium Problems - II
7.5K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.5K