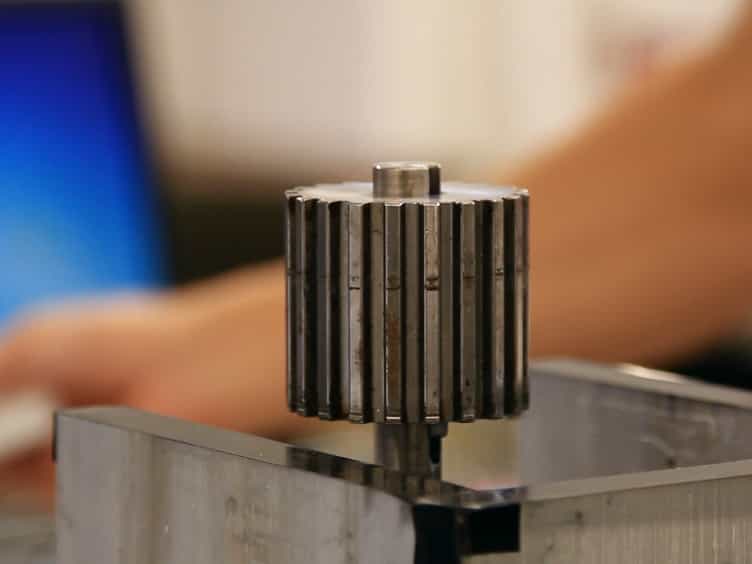
通过惯性驱动提高多层压电线性电机的低速稳定性
Mingsen Guo1, Zhi Xu2,3, Liang Wang1
1College of Aerospace Engineering, Nanjing University of Aeronautics and Astronautics, Nanjing 210016, China.

这项研究介绍了一种新的多层压电电机,它结合了共振和非共振模式. 这种双机制设计实现了高速运动和稳定的超低速控制,用于先进的超声波电机应用.
科学领域:
- 材料科学 材料科学 材料科学
- 机械工程 机械工程
- 机器人技术 机器人技术 机器人技术
背景情况:
- 压电超声波电机 (USM) 在高速时表现出色,但缺乏稳定的低速控制.
- 现有的USM在精确,缓慢的运动方面扎,这对于高级应用至关重要.
- 弥合USM性能中的速度差距是一个重大的工程挑战.
研究的目的:
- 开发一种具有双机制操作的压电超声波电机,用于高速和超低速控制.
- 克服传统USM在保持稳定的低速运动方面的局限性.
- 为了提高压电电机的精度和多功能性,用于各种应用.
主要方法:
- 一个多层压电陶电机设计,集成共振和非共振压电变形.
- 在共振模式中利用合的纵向和曲变形来实现高速和停机力.
- 在非共振模式中采用一个粘滑机制,以实现光滑,可控的超低速度运动.
主要成果:
- 在共振模式下以4.5N的停止力 (30Vpp在47kHz) 实现高速度线性运动,速度高达290mm/s.
- 在没有闭环控制的情况下,在非共振模式下从10微米/秒到10毫米/秒的超低速运行表现为平滑,稳定.
- 成功地将双机制功能集成到单个压电电机中.
结论:
- 拟议的双机制压电电机有效地弥合了高速和超低速操作之间的性能差距.
- 这种创新的设计为高精度超声波电机应用提供了有前途的解决方案.
- 电机在无需复杂的控制系统的情况下能够在广泛的速度范围内运行,这提高了它的实用性.
更多相关视频
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 10:39
Preparation of ZnO Nanorod/Graphene/ZnO Nanorod Epitaxial Double Heterostructure for Piezoelectrical Nanogenerator by Using Preheating Hydrothermal
Published on: January 15, 2016
相关概念视频
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:24
PI Controller: Design
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...