
在机器人操纵中,生物启发的轨迹调制可用于有效的滑动控制
Kiyanoush Nazari1, Willow Mandil1,2, Marco Santello3
1School of Computer Science and LIAT, University of Lincoln, Lincoln, UK.
Nature machine intelligence
|July 25, 2025

概括
机器人抓地稳定性可以通过轨迹调制而不是传统的抓地力控制来提高. 这种新方法通过预测控制框架进行了优化,提高了机器人在具有挑战性的环境中的机器人适应能力.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 人工智能的人工智能
背景情况:
- 稳定的机器人抓取对于熟练的操纵至关重要.
- 传统的滑动控制依赖于抓地力调制.
- 对于某些任务,握力控制存在限制.
研究的目的:
- 研究轨迹调制作为机器人操纵的替代滑动控制策略.
- 为了比较轨迹调制与握力控制的有效性.
- 使用预测控制框架开发一个优化的轨迹调节政策.
主要方法:
- 基于轨道调制的滑动控制政策的制定.
- 与传统的基于抓地力控制方法的比较.
- 在模型预测控制 (MPC) 框架中整合数据驱动的动作条件期货模型.
主要成果:
- 在特定的机器人操纵场景中,轨迹调制显著优于抓地力控制.
- 包含前模型的预测控制框架是优化轨迹调节的关键.
- 拟议的方法增强了动态和非结构化的环境中的掌握稳定性.
结论:
- 轨道调制为机器人操纵中防滑提供了一个强大而有效的替代方案.
- 用数据驱动的前模型进行模型预测控制对于优化这一策略至关重要.
- 这种方法提高了机器人系统在具有挑战性的条件下的适应性和性能.


相关概念视频
 01:14
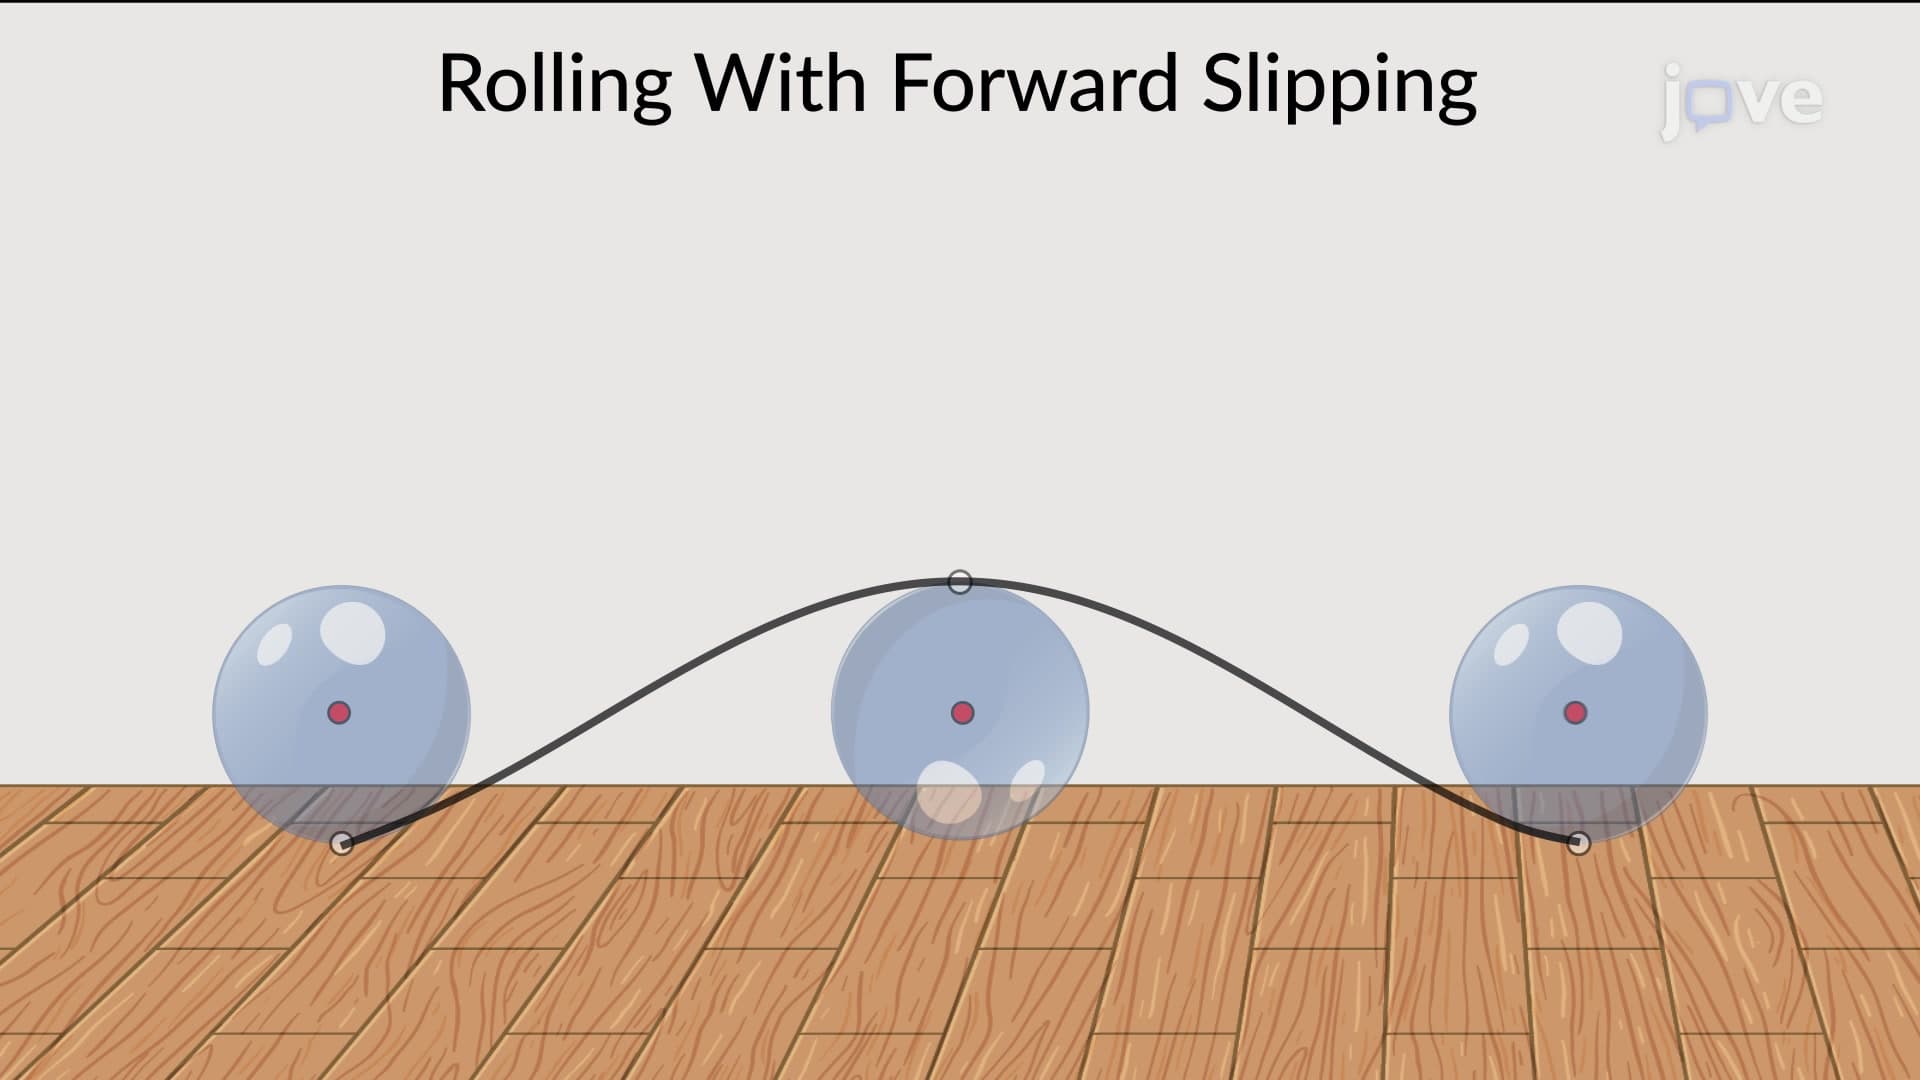
Rolling With Slipping
5.7K
Rolling with slipping is a physical phenomenon that occurs when a rolling object experiences both rotational and linear motion but also experiences frictional forces that cause slipping. This phenomenon can occur in various situations, such as when a tire rolls on a wet road or a ball rolls on a rough surface.
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
5.7K
 01:09
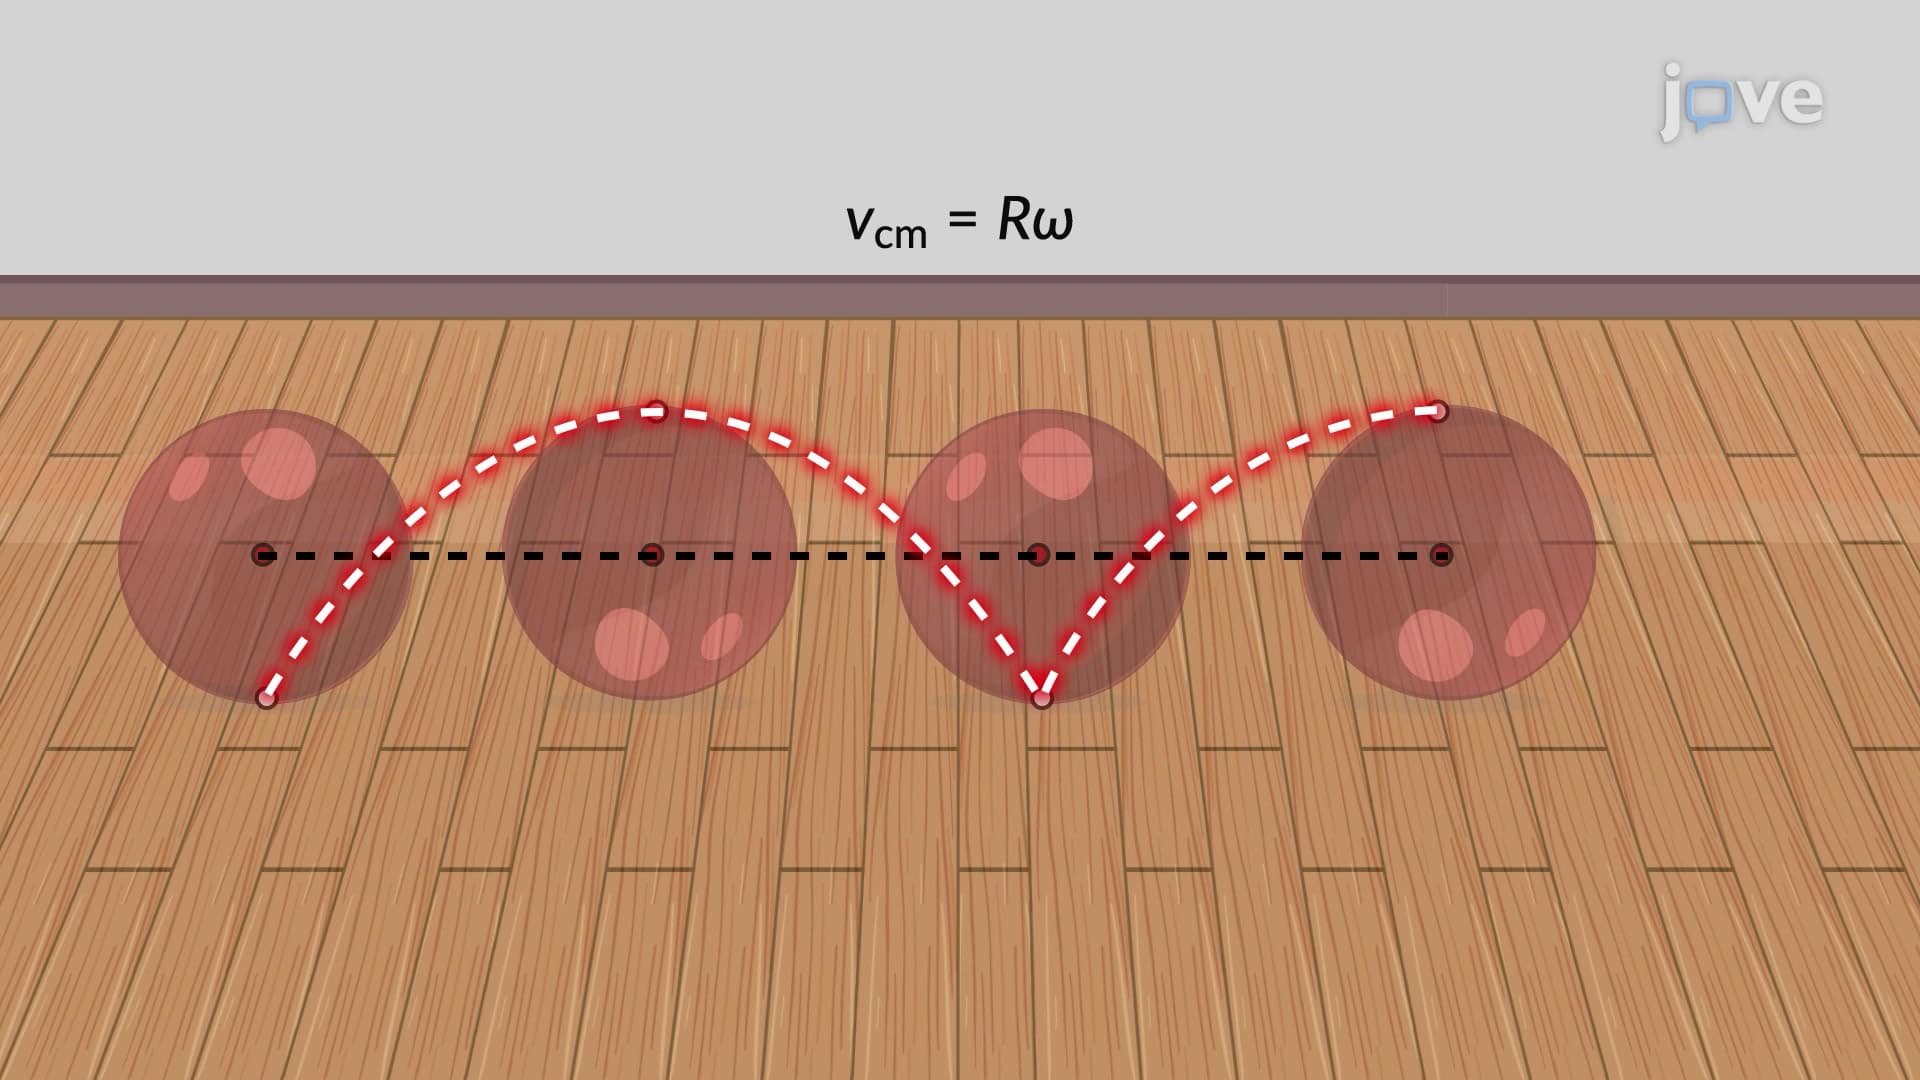
Rolling Without Slipping
4.2K
People have observed the rolling motion without slipping ever since the invention of the wheel. For example, one can look at the interaction between a car's tires and the surface of the road. If the driver presses the accelerator to the floor so that the tires spin without the car moving forward, there must be kinetic friction between the wheels and the road's surface. If the driver slowly presses the accelerator, causing the car to move forward, the tires roll without slipping. It is...
4.2K
 01:13
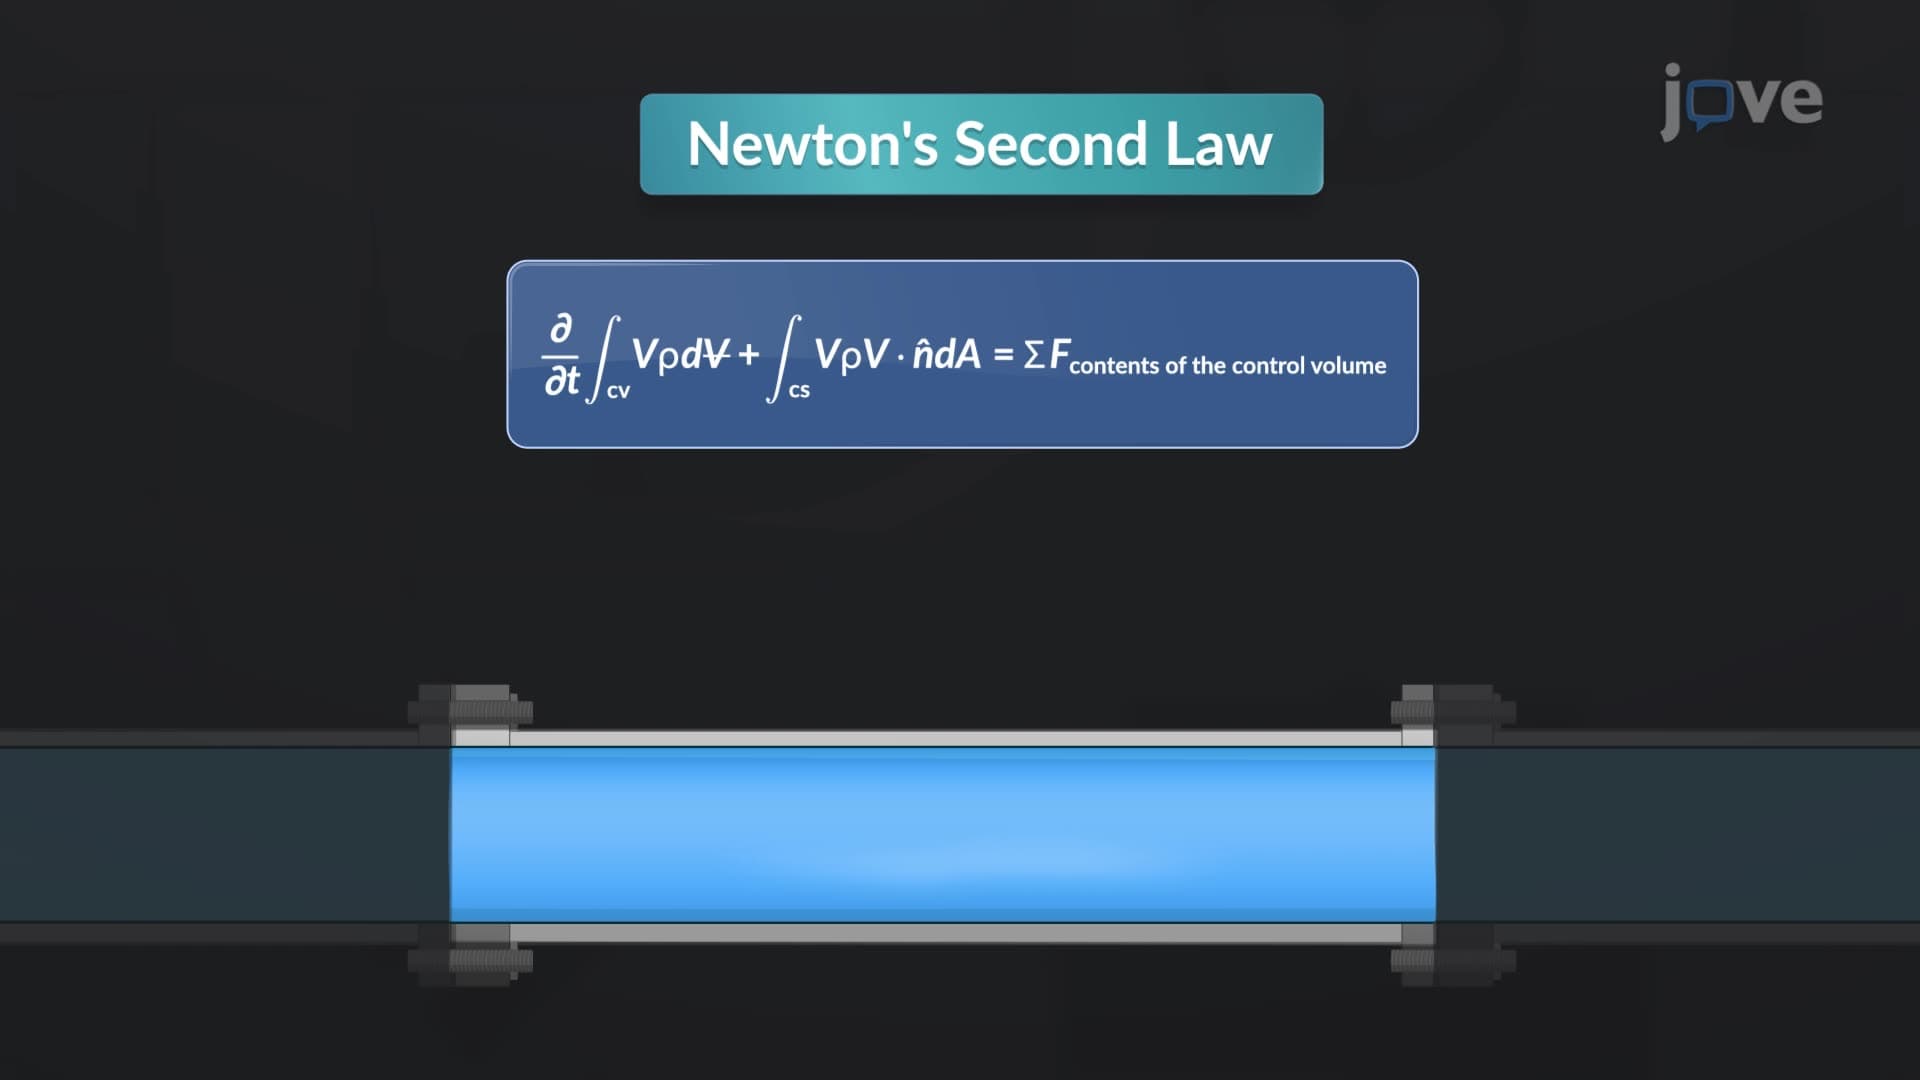
Linear Momentum in Control Volume
1.1K
Newton's second law is applied to obtain the linear momentum in a control volume in a fluid system. According to this law, the rate of change of linear momentum is equal to the sum of external forces acting on the system. When a control volume matches the fluid system at a specific moment, the forces acting on both are identical. Reynolds transport theorem helps explain this by breaking down the system's linear momentum into two components: the rate of change of linear momentum within...
1.1K
 01:17
Rolling Resistance: Problem Solving
451
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
451
 01:26
Kinetic Friction
1.0K
Consider a truck trying to pull a stationary car. As the truck exerts a force on the car, static friction is created at the point of contact between the two surfaces. This frictional force resists the car's movement and keeps it at rest. However, when the applied force by the truck surpasses the limiting static frictional force, an interesting phenomenon occurs. The frictional force at the interface reduces to a lower value, known as the kinetic frictional force. At this point, the car...
1.0K
 01:17
Open and closed-loop control systems
1000
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1000