相关实验视频
Updated: Sep 13, 2025

10:09
Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
6.7K
一个空间平行机制的增强动态模型,在两个点接触的高动力对上接收从基点直接约束的空间平行机制
Chen Cheng1, Xiaojing Yuan1, Yenan Li1
1Lab of Mechatronics, Rocket Force University of Engineering, Xi'an 710025, China.
Biomimetics (Basel, Switzerland)
|July 25, 2025

概括
一个新的并行机制模仿人类的,以实现3D运动. 使用欧勒参数的高效反向动态模型提高了准确性,并考虑了摩擦,增强了控制能力.
科学领域:
- 机器人和生物力学
- 机械工程 机械工程
背景情况:
- 人类的系统为复杂的3D运动提供了灵感.
- 具有更高动力对 (HKPs) 的并行机制 (PM) 提供了先进的功能,但面临着挑战.
- 在HKP和执行器中的摩擦会降低运动精度,并导致磨损.
研究的目的:
- 提出一个生物学上一致的并行机制 (PM) 以模拟人类的3D.
- 为拟议的PM开发一个高效和准确的反向动态模型.
- 为了实现实时运动和/或力控制机制.
主要方法:
- 设计了一种平行机制 (PM),在两个更高的动力对 (HKPs) 上从底部 (DCFB) 到终端效应器直接制约.
- 使用欧勒参数来进行端效应器运动表示,制定了一个反向动态模型.
- 牛顿-欧勒定律被应用于结合HKPs和执行器的摩擦效应.
主要成果:
- 基于欧勒参数的模型显示,与欧勒角相比,计算时间减少了77%.
- 摩擦效应被证明可以显著增加模型的非线性.
- 从底部直接制约 (DCFB) 增加了建模复杂性和计算成本.
结论:
- 拟议的反向动态模型提高了PM的计算效率和可靠性.
- 该模型有效地结合了摩擦,这对于精确控制机制至关重要.
- 该研究强调了机制复杂性 (通过DCFB) 和计算需求之间的权衡.
相关概念视频
 01:29
Space Trusses: Problem Solving
640
A space truss is a three-dimensional counterpart of a planar truss. These structures consist of members connected at their ends, often utilizing ball-and-socket joints to create a stable and versatile framework. Due to its adaptability and capacity to withstand complex loads, the space truss is widely used in various construction projects.
Consider a tripod consisting of a tetrahedral space truss with a ball-and-socket joint at C. Suppose the height and lengths of the horizontal and vertical...
Consider a tripod consisting of a tetrahedral space truss with a ball-and-socket joint at C. Suppose the height and lengths of the horizontal and vertical...
640
 01:30
Machines: Problem Solving II
373
Machines are complex structures consisting of movable, pin-connected multi-force members that work together to transmit forces. Consider a lifting tong carrying a 100 kg load. It comprises movable sections DAF and CBG linked together with member AB.
373
 01:26
Constraints and Statical Determinacy
697
In structural engineering, the equilibrium of a system is not only determined by its equations of equilibrium but also with the help of constraints. Constraints refer to restrictions on the motion of a system. The proper combinations of constraints can minimize the total number of constraints needed to maintain a system in mechanical equilibrium. When this happens, the system is said to be statically determinate. For such systems, the unknown reaction supports can be estimated using equilibrium...
697
 01:30
Method of Joints: Problem Solving II
677
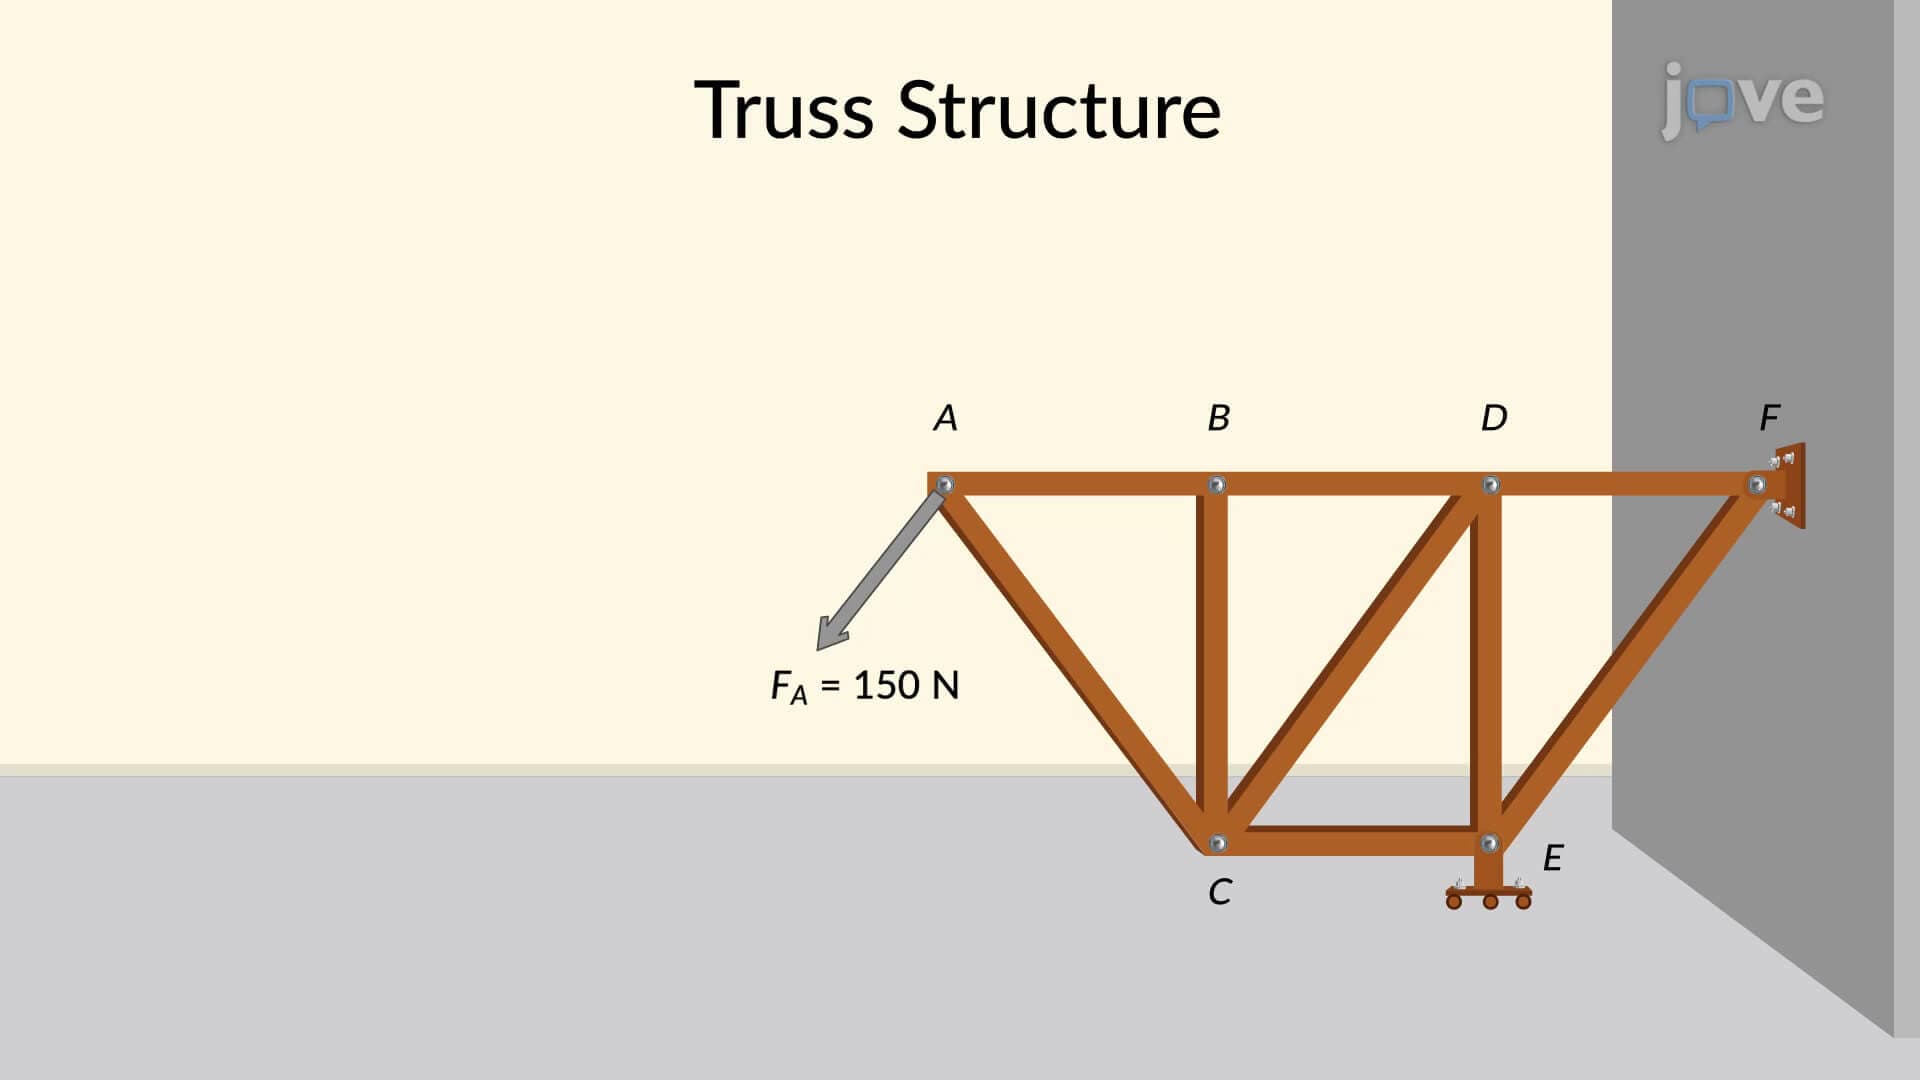
Consider a truss structure with frictionless joints fixed to a wall and roller support. If a force of 150 N is applied to joint A, the forces in each member of the truss can be determined using the method of joints.
677
 01:22
Machines: Problem Solving I
410
A toggle clamp is a mechanical device commonly used for holding and clamping objects in various applications, such as woodworking, metalworking, and assembly operations. Consider a toggle clamp subjected to a force of 200 N at the handle. The vertical clamping force can be calculated, provided the dimensions of the toggle clamp are known.
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
410
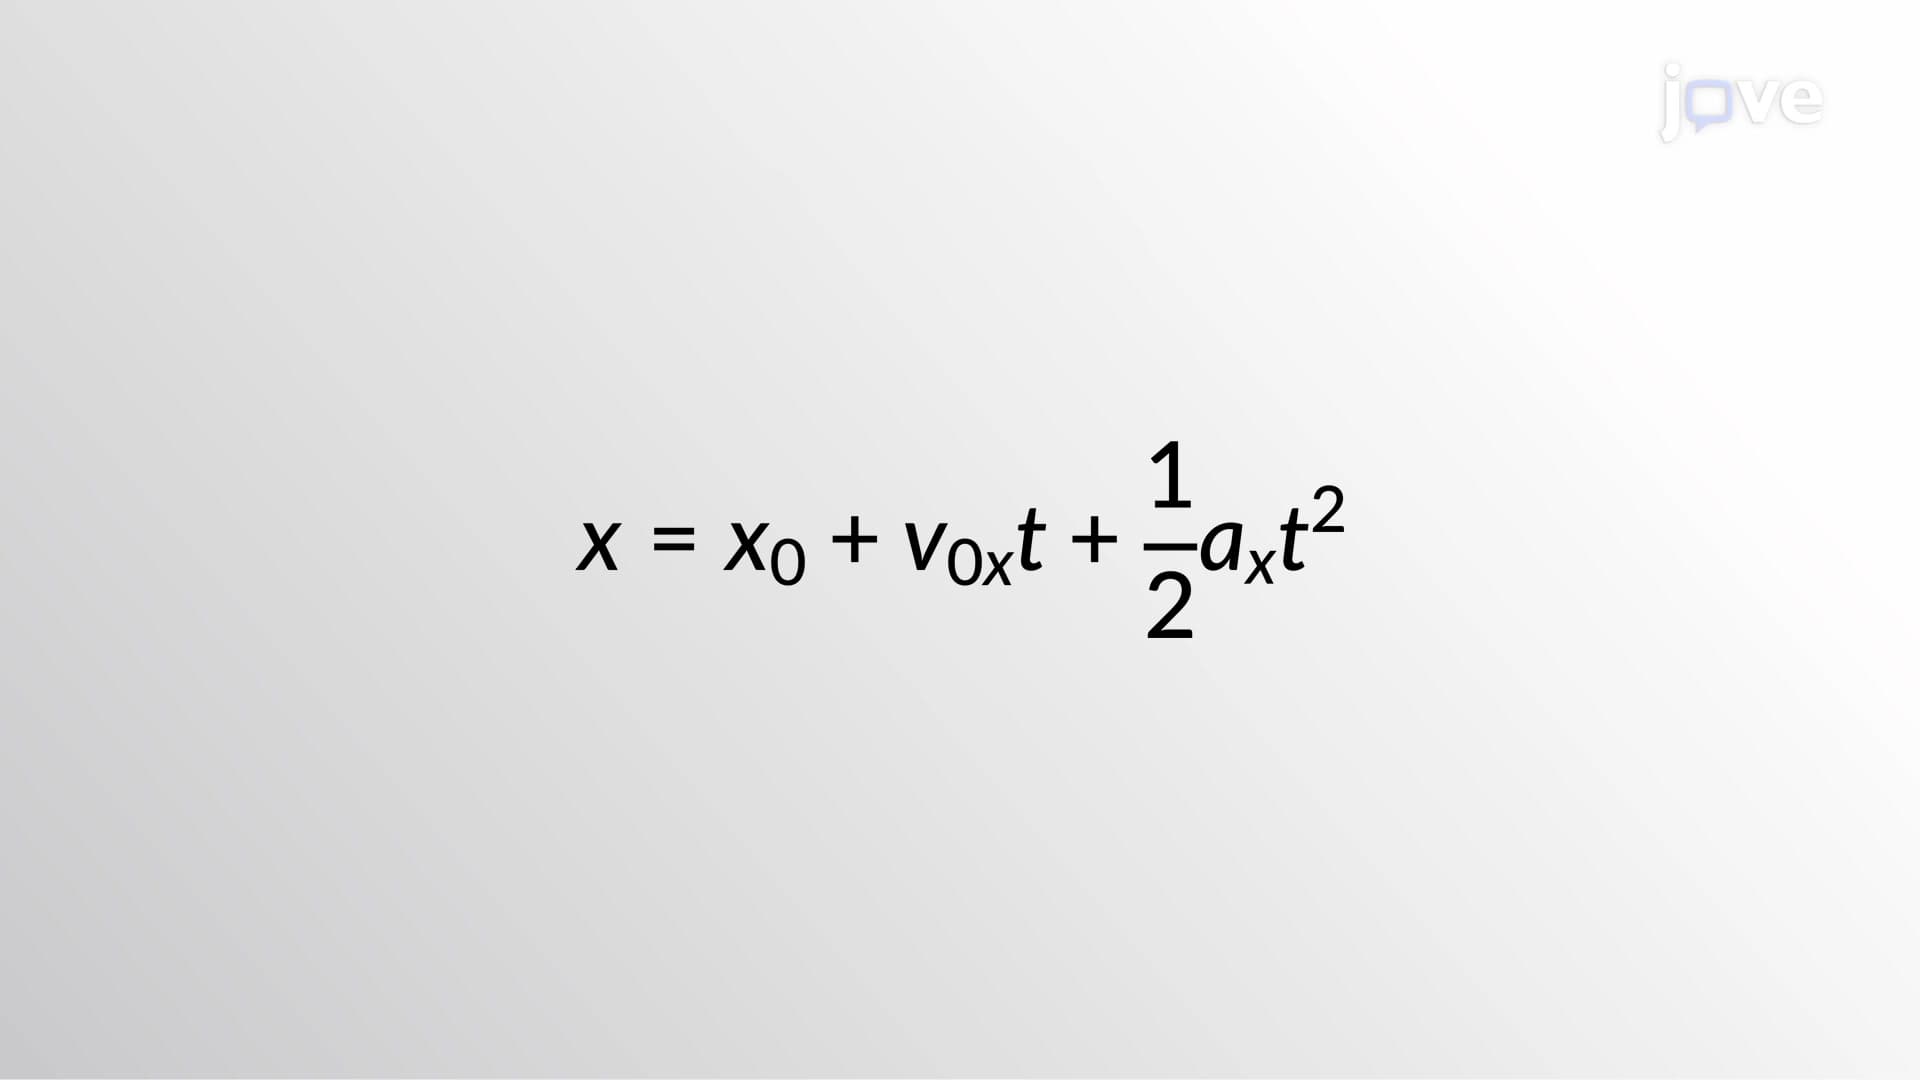 01:17
Kinematic Equations - II
10.8K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
10.8K