多式融合图像稳定算法用于生物灵感的飞翼飞机
Zhikai Wang1,2, Sen Wang1, Yiwen Hu3,4
1College of Information Engineering, Henan University of Science and Technology, Luoyang 471023, China.
Biomimetics (Basel, Switzerland)
|July 25, 2025

概括
这项研究介绍了FWStab,这是一个用于翼视频稳定的新数据集. 它介绍了一种使用图像和惯性数据创建更流的空中视频,减少振动和扭曲的多式模式框架.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 航空航天工程 航空航天工程
背景情况:
- 飞行器,特别是飞翼平台,会受到严重的振动,影响图像质量.
- 现有的视频稳定方法经常与强烈的动态动和滚动快门扭曲作斗争.
研究的目的:
- 介绍FWStab,一个专门的数据集,用于翼视频稳定.
- 提出一个多式联通信号融合框架,以提高空中飞行器的视频稳定性.
- 为了解决严重的振动引起的图像采集质量差的问题.
主要方法:
- 开发了一个多式联通信号融合框架,集成图像和惯性测量单元 (IMU) 传感器数据.
- 使用长短期记忆 (LSTM) 网络进行时间建模和顺的轨迹预测.
- 使用无监督学习与关节损失函数,结合姿势光滑性和光流残余.
- 实施了多阶段培训战略,以实现广泛的场景适应性.
主要成果:
- 拟议的框架通过融合多式联络数据,有效地预测平滑的摄像头姿势.
- 通过将传感器估计的运动扭曲到网络预测的轨迹,实现了优化的跨稳定性.
- 保持了全局场景运动刚性,并纠正了滚动快门扭曲.
- 在各种飞行场景中表现出了显著的稳定适应性.
结论:
- 多式联动融合框架显著改善了飞翼平台的视频稳定性.
- FWStab数据集为开发和评估先进稳定技术提供了宝贵的资源.
- 无监督学习方法为复杂的空中视频摄影挑战提供了有效的解决方案.

相关概念视频
 01:24
One-Degree-of-Freedom System
557
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
557
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
2.0K
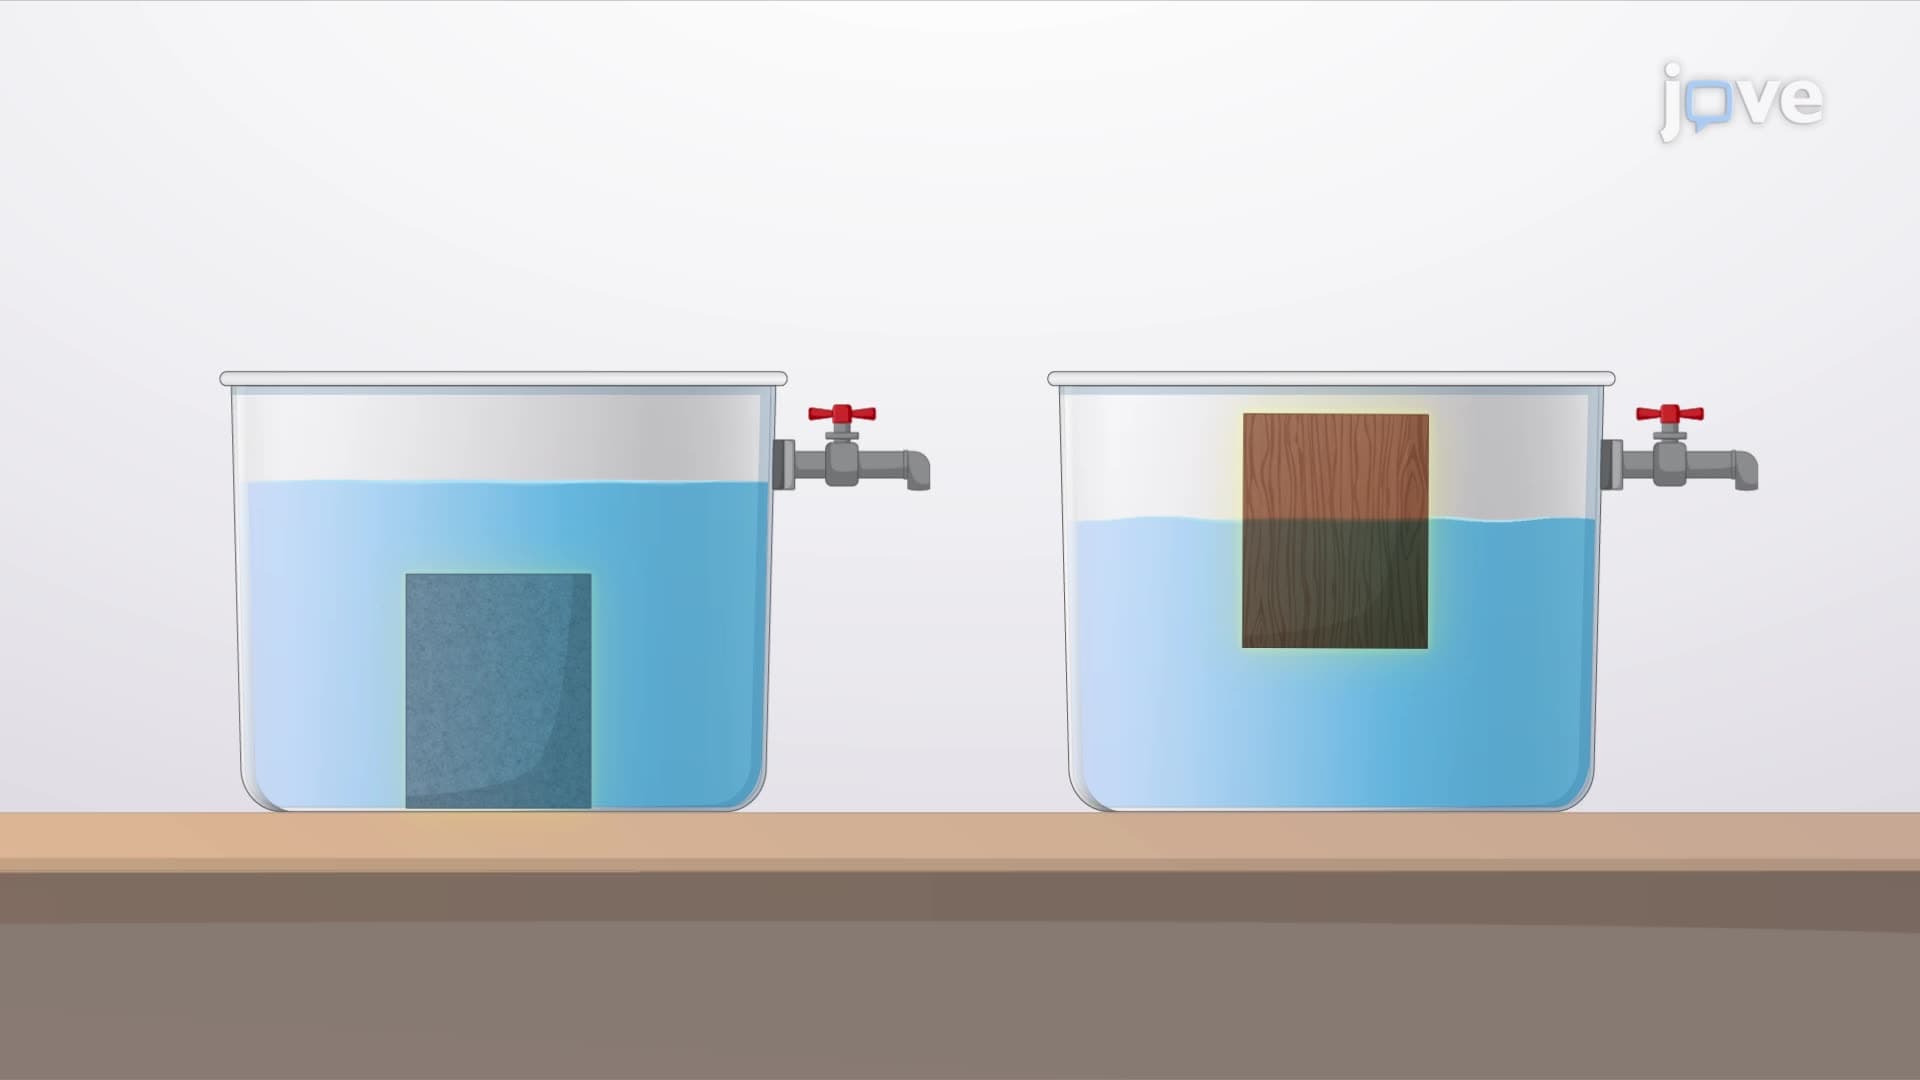
In fluid mechanics, buoyancy and stability are key concepts for understanding the behavior of submerged and floating bodies. When a stationary body is fully or partially submerged in a fluid, the fluid exerts a force on the body known as the buoyant force. This force acts vertically upward through a point called the center of buoyancy, which is the center of the displaced fluid volume. According to Archimedes' principle, the magnitude of the buoyant force is equal to the weight of the fluid...
2.0K
 01:25
Relative Motion Analysis using Rotating Axes
536
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
536
 01:17
Steady, Laminar Flow Between Parallel Plates
336
Understanding steady, laminar flow between parallel plates is essential for analyzing and designing flow in narrow rectangular channels, commonly found in various water conveyance and drainage systems. The Navier-Stokes equations govern fluid motion and are generally challenging to solve due to their nonlinearity. However, simplifications are possible in certain cases, like the steady laminar flow between parallel plates. For this scenario, we assume steady, incompressible, laminar flow.
336
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
451
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
451
 01:24
Absolute Motion Analysis- General Plane Motion
273
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
273