
在弹性带训练中感知到的努力的心理和物理预测:基于速度的方法
Juan C Colado1, Javier Gene-Morales1, Pablo Jiménez-Martínez1,2
1Research Group in Prevention and Health in Exercise and Sports (PHES), Department of Physical Education and Sports, University of Valencia, Valencia, Spain.
International journal of sports physical therapy
|August 4, 2025

概括
弹性带的OMNI-RES运动量表 (OMNI-RES EB) 可靠地监测了以弹性带为基础的速度训练 (VBT) 的强度. 这种具有成本效益的工具可与用于跟踪运动强度的线性速度传感器相提并论.
科学领域:
- 运动生理学 运动生理学
- 运动科学 运动科学 运动科学
- 生物力学 生物力学
背景情况:
- 在基于速度的训练 (VBT) 框架内,在弹性阻力训练期间监测运动强度,由于缺乏经过验证的实用工具,因此存在挑战.
- 弹性带 (EB) 在VBT中越来越多地使用,需要可靠的强度评估方法.
研究的目的:
- 评估弹性带的OMNI-RES运动量表 (OMNI-RES EB) 作为监测运动强度的工具.
- 评估OMNI-RES EB适合在VBT环境中以最大预期速度进行坐,速度损失为10%.
主要方法:
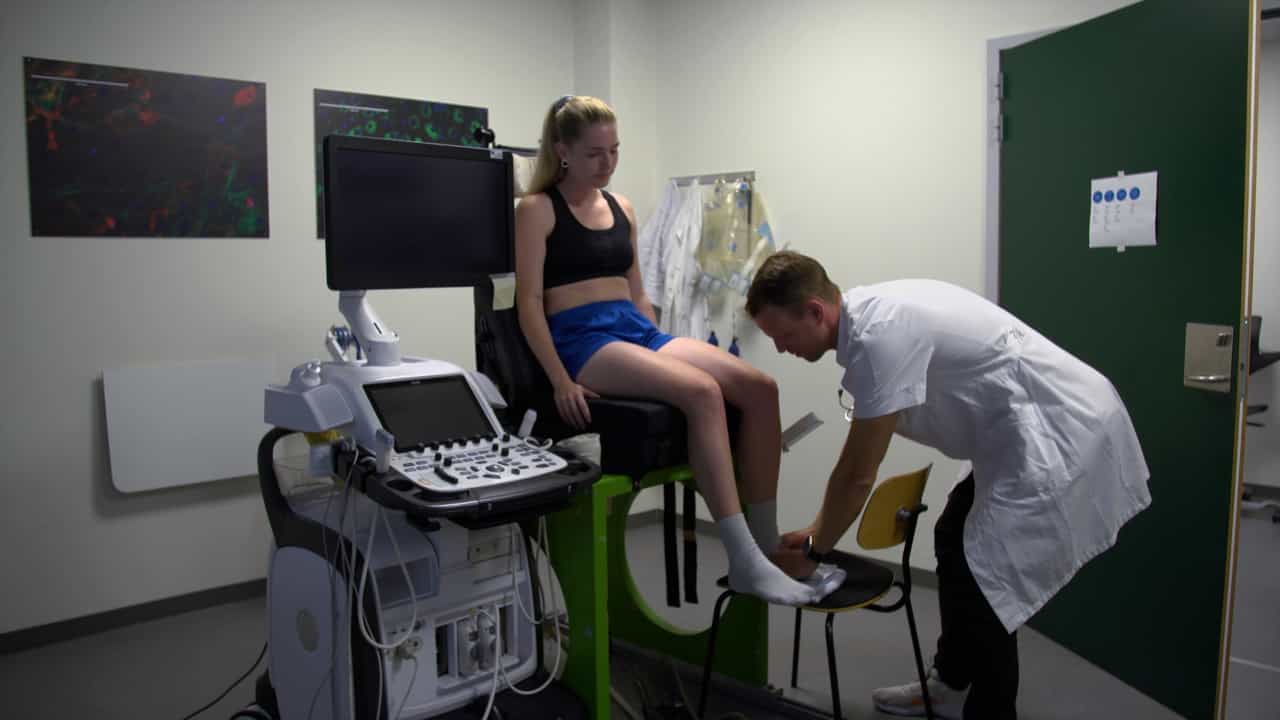
- 这是一项准实验性队列研究,涉及24名身体活跃的个人.
- 参与者使用EB以不同百分比的1重复最大 (1RM) 执行了式组,并指示最大速度和10%的速度损失.
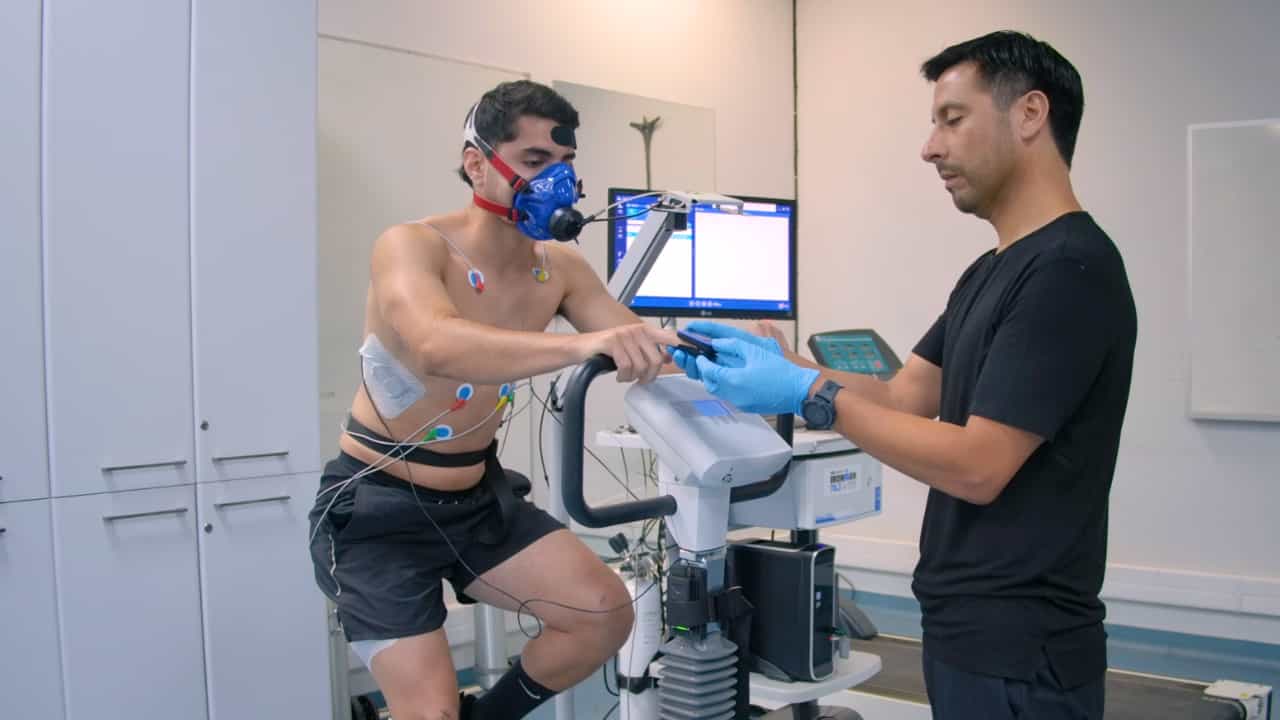
- 测量包括平均推进速度 (MPV),通过OMNI-RES EB,负载,心率和重复的感知劳动力 (RPE) 评级.
主要成果:
- 感知劳动力 (RPE) 的评级在1RM的不同百分比之间有显著的差异.
- 没有观察到身体活动水平或性别对RPE的显著影响.
- 在MPV和RPE之间发现了强烈的负相关性 (r = -0.76),表明良好的并发有效性.
结论:
- 在VBT框架内,OMNI-RES EB提供了一种可靠且具有成本效益的方法,用于在弹性带阻力训练期间监测运动强度.
- 在这种情况下,OMNI-RES EB在强度监测方面表现出与线性速度传感器相匹配的有效性.
相关概念视频
 01:34
Velocity and Position by Graphical Method
Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to calculate...
 01:23
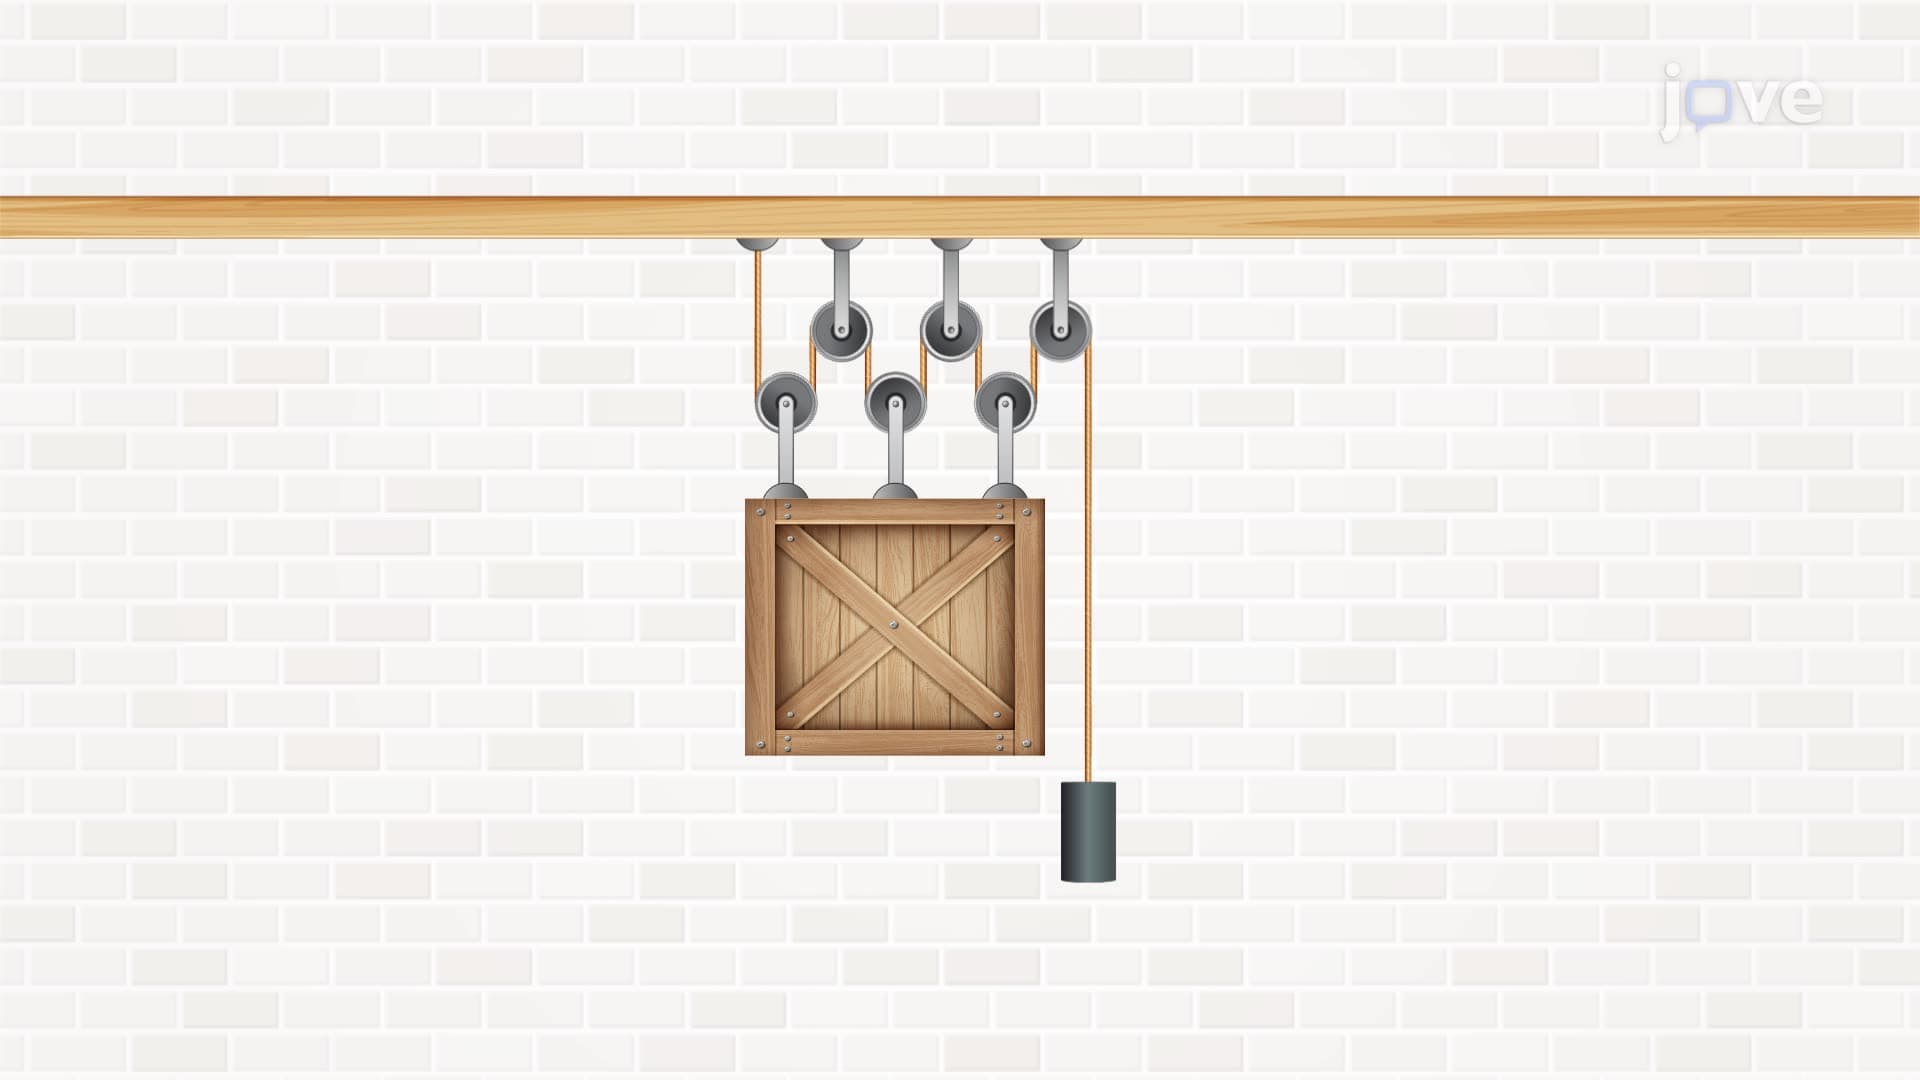
Principle of Linear Impulse and Momentum for a Single Particle: Problem Solving
Consider a wooden box and a cylinder of known masses m1 and m2, respectively, hanging from a ceiling with the help of a massless pulley system.
 01:24
Relative Motion Analysis - Velocity
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
 01:29
Distance Problem
When an object's velocity changes over time, the total distance traveled can be determined by summing small displacement intervals over short increments. This approach approximates the true distance through numerical summation and the use of integral calculus. An estimate of the total displacement can be obtained by measuring velocity at regular intervals and multiplying each value by the corresponding time step.If a runner accelerates over the first three seconds of a race, speed measurements...
 01:30
Vector Functions and Motion: Problem Solving
Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...