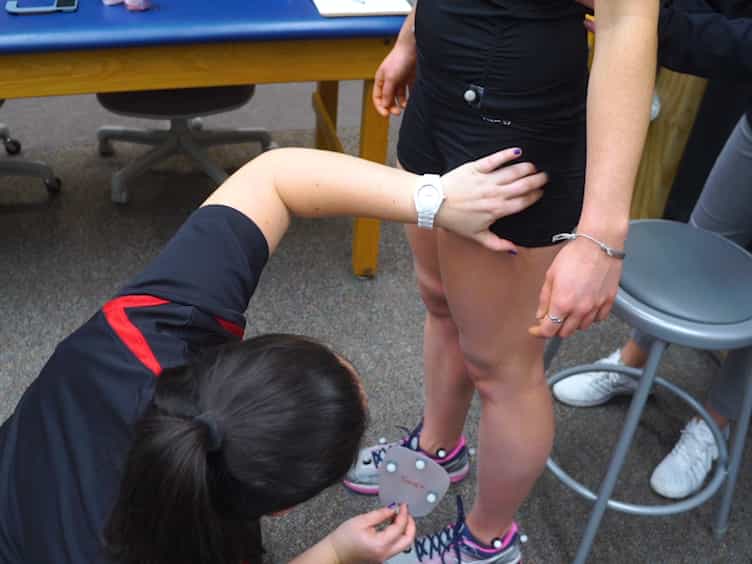
向负载-坚固的运动估计使用EMG驱动的状态空间模型与可变刚性的肌肉骨模型

概括
这项研究引入了一种新的电肌图 (EMG) 模型,用于准确估计人类运动. 该模型可以提高神经机器接口在不同重量负载的性能,而无需重新训练.
科学领域:
- 生物医学工程 生物医学工程
- 神经科学是一个神经科学.
- 康复工程 康复工程 康复工程
背景情况:
- 精确的人类运动估计对于电肌图 (EMG) 信号驱动的神经机器接口 (NMI) 至关重要.
- 不同的外部负荷显著影响基于EMG的NMI的性能,通常是由于肌肉协同收缩的未解决的变化.
- 现有的EMG驱动的肌肉骨模型 (MMs) 在不同的负载条件下显示出强度的限制.
研究的目的:
- 开发一个强大的EMG驱动的状态空间模型来估计手和手腕的运动.
- 在不同负载条件下提高NMI的性能,而不需要再培训.
- 为了应对影响基于EMG的运动估计的肌肉合收缩的负载诱导变化的挑战.
主要方法:
- 提出了一个EMG驱动的状态空间模型,将肌肉骨模型 (MM) 与可变关节刚度作为状态模型.
- 利用反向传播的神经网络作为观察模型,将状态变量映射到EMG特征中.
- 仅在零负载数据上训练模型,并在四个不同的负载条件下验证其性能.
主要成果:
- 在零负载数据上训练的拟议模型实现了与在负载特定数据上训练的传统MM相比的性能.
- 显著优于传统的MMs,这些MMs仅在不同负载的零负载数据上进行训练.
- 在不同的负载条件下证明了基于EMG的接口的强度和精度的提高.
结论:
- 开发的EMG驱动状态空间模型有效地提高了NMI人类运动估计的稳定性和准确性.
- 该方法为NMI在日常活动中使用可变外部负载的NMI提供了有前途的解决方案.
- 验证了状态空间建模和神经网络的潜力,用于基于EMG的自适应运动跟踪.
更多相关视频
 08:09
Multifunctional Setup for Studying Human Motor Control Using Transcranial Magnetic Stimulation, Electromyography, Motion Capture, and Virtual Reality
Published on: September 3, 2015
11.0K
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
9.6K
相关概念视频
 01:21
Linear Approximation in Time Domain
125
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
125
 01:20
Excitation-Contraction Coupling in Skeletal Muscles
9.6K
Excitation-contraction coupling is a series of events that occur between generating an action potential and initiating a muscle contraction. It occurs at the triad, a structure found in skeletal muscle fibers that comprise a T-tubule and terminal cisternae of the sarcoplasmic reticulum on each side. These triads are visible in longitudinally sectioned muscle fibers. They are typically located at the A-I junction — the junction between the A and I bands of the sarcomere.
When an action...
When an action...
9.6K
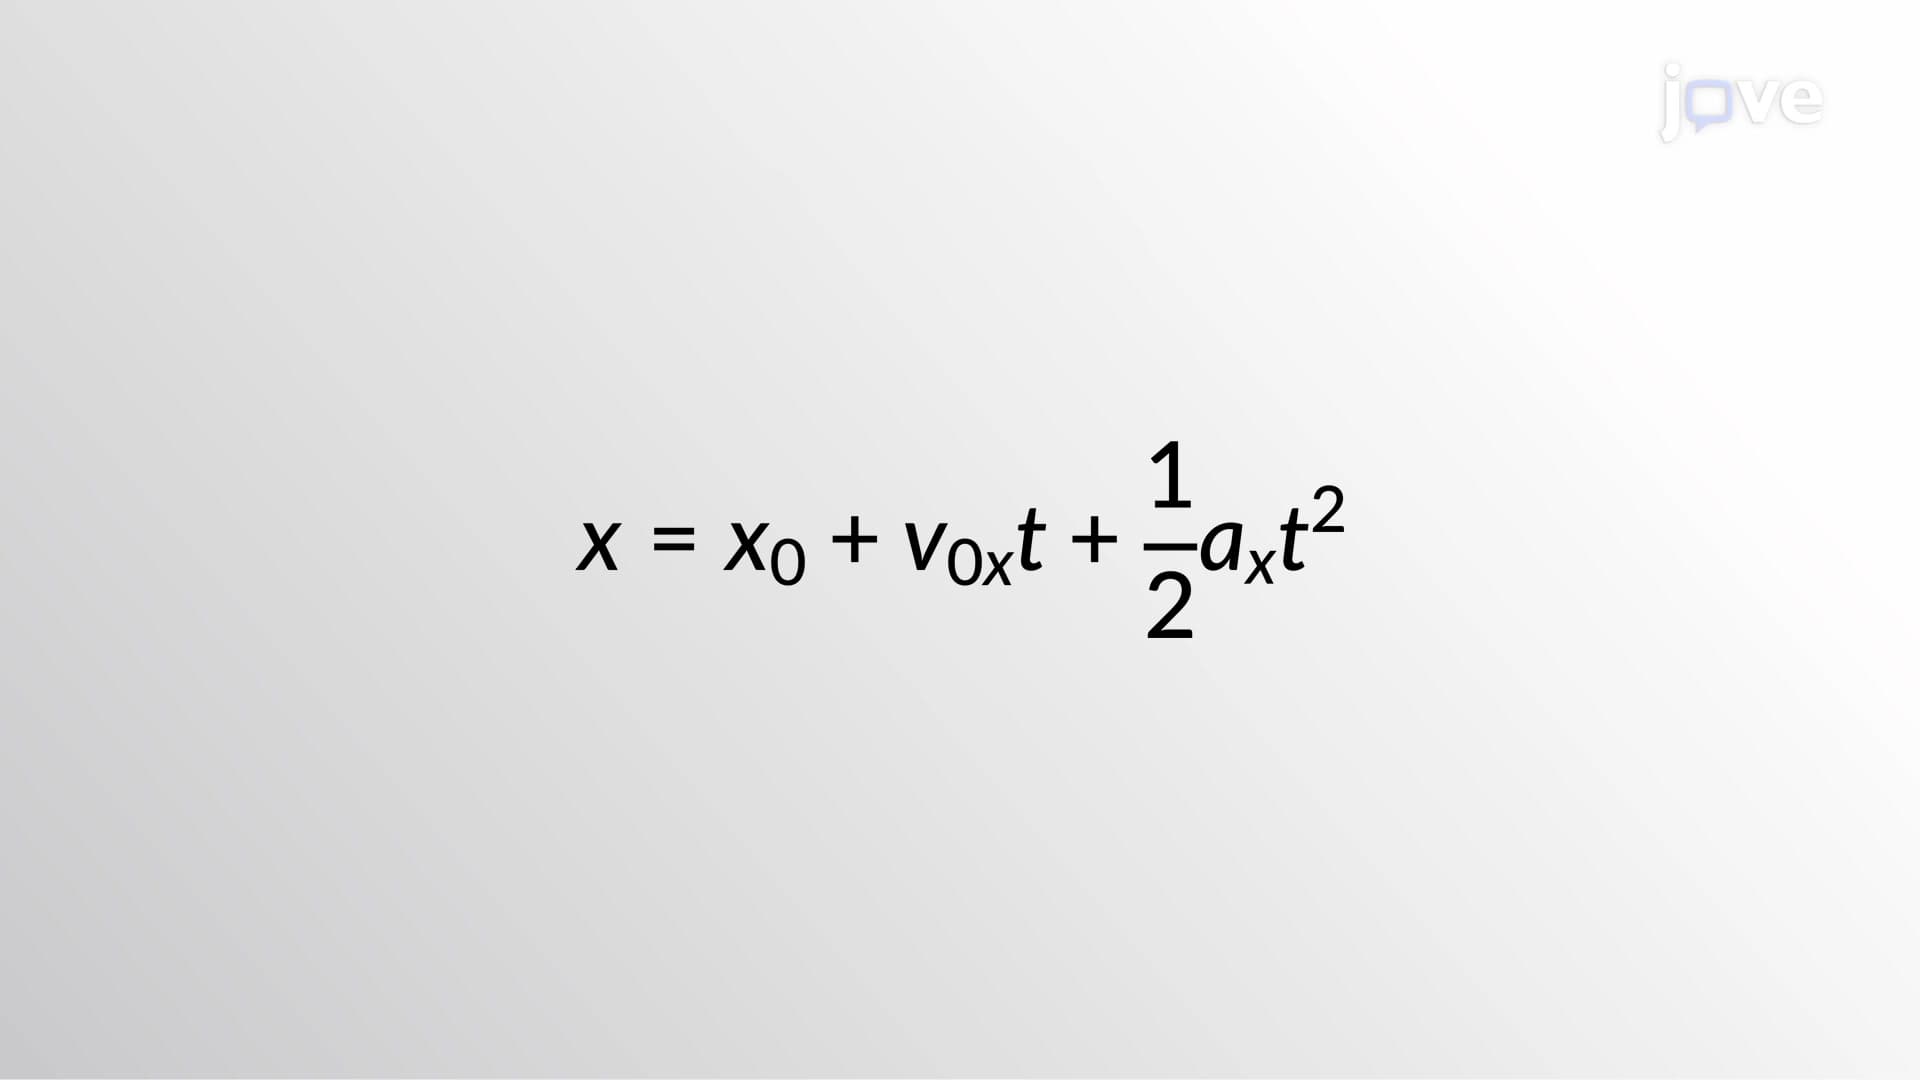 01:17
Kinematic Equations - II
10.7K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
10.7K
 01:18
Kinematic Equations - III
8.5K
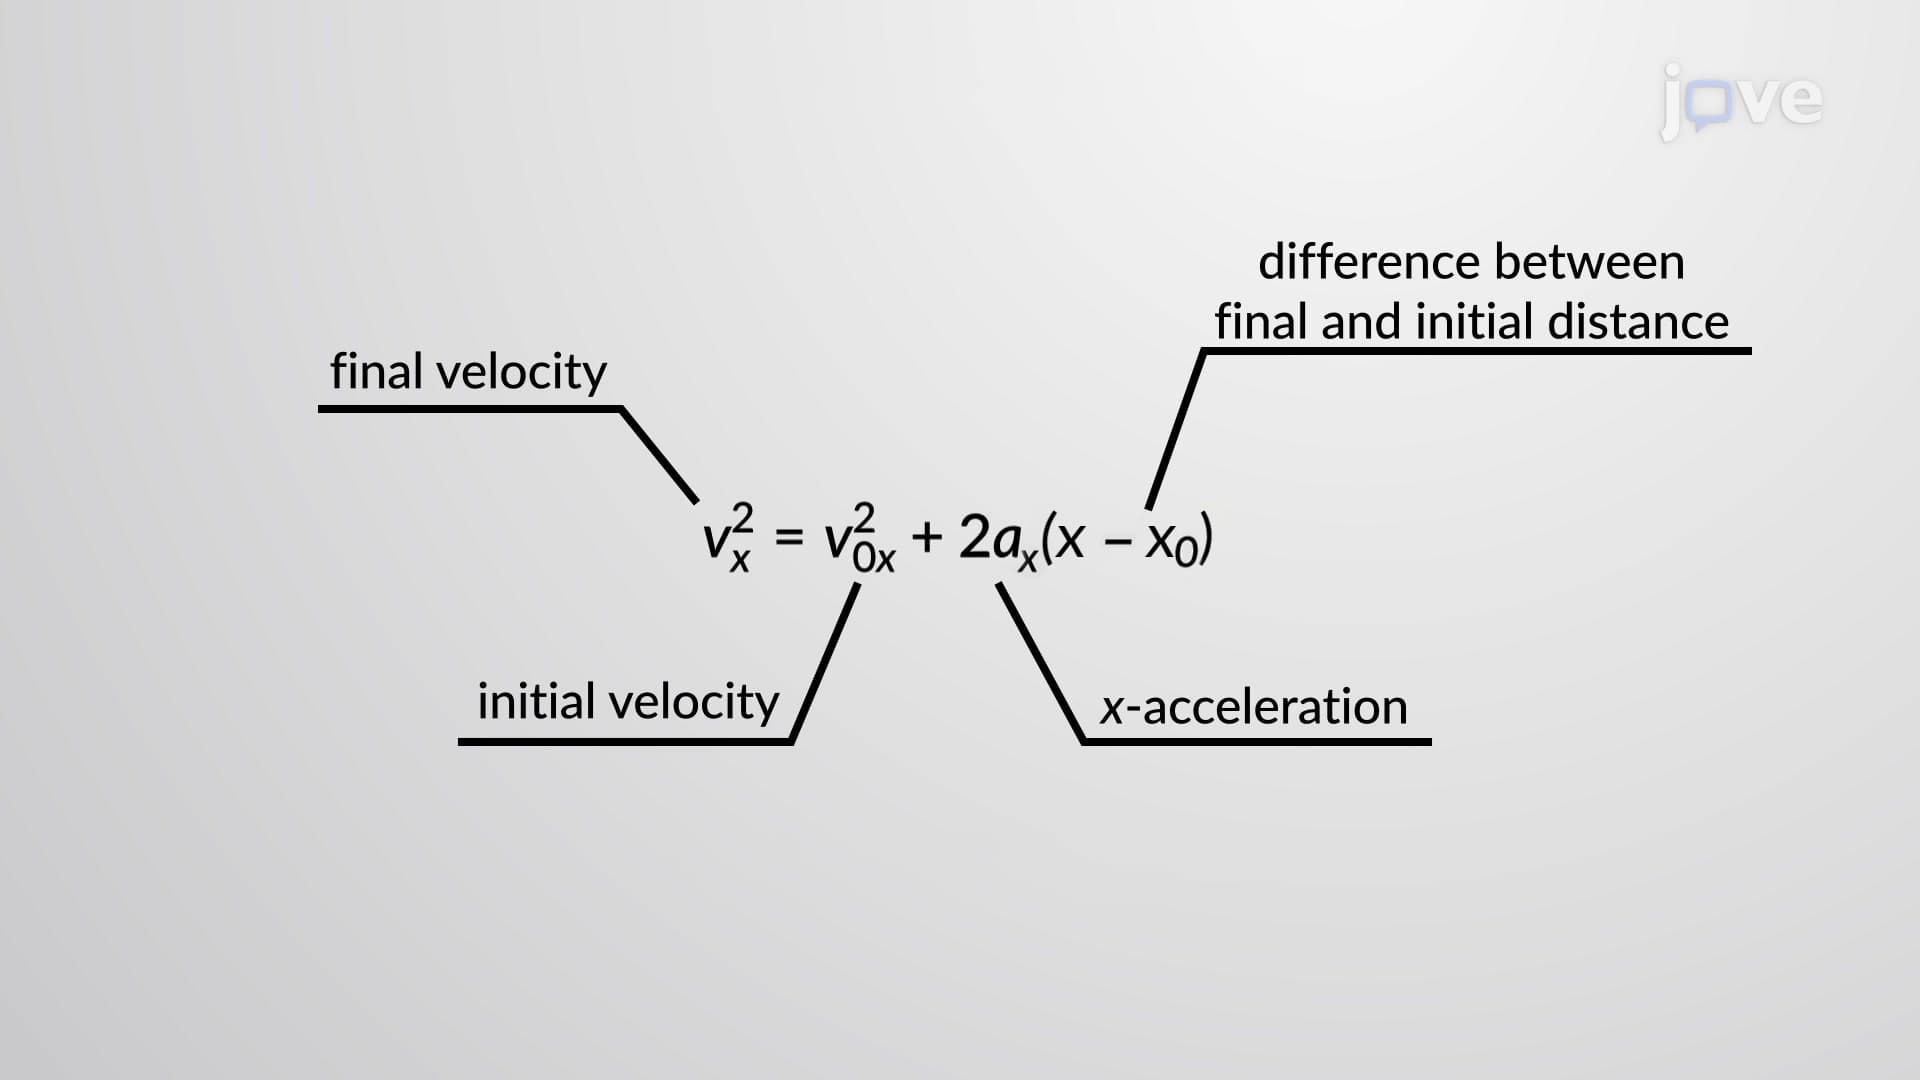
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
8.5K
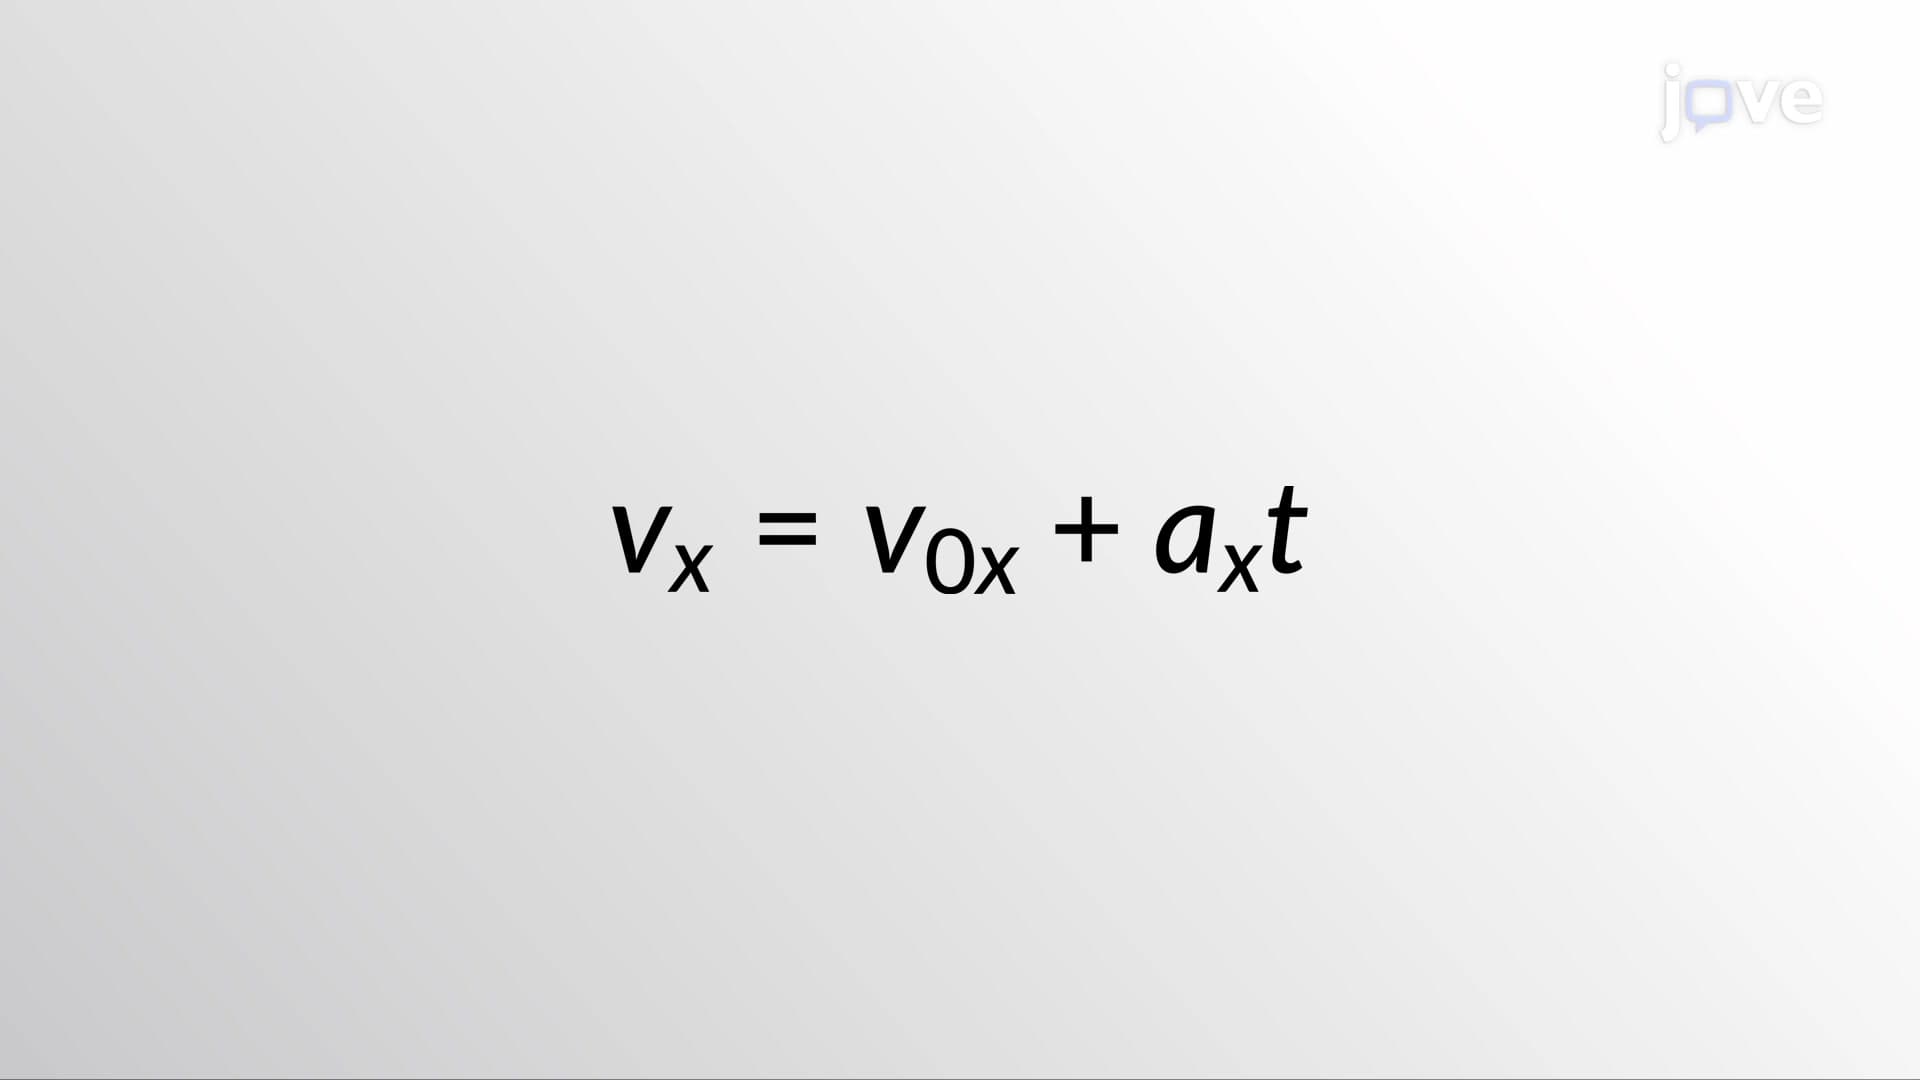 01:26
Kinematic Equations - I
12.0K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
12.0K
 01:15
Kinematic Equations: Problem Solving
14.4K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
14.4K