DiffCap:基于扩散的实时人类运动捕捉,使用稀缺的IMU和单眼相机
IEEE transactions on visualization and computer graphics
|August 6, 2025

概括
这项研究引入了一种基于扩散的新方法,用于实时捕捉人类运动,有效地融合惯性测量单元 (IMU) 和单眼相机数据,以准确地估计姿势.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 人与计算机的交互
背景情况:
- 人类运动捕捉对于各种应用至关重要.
- 现有的方法经常与实时性能和数据融合挑战作斗争.
- 整合稀疏的惯性测量单元 (IMU) 和单眼相机提供了一个有希望但复杂的方法.
研究的目的:
- 开发一个统一的框架,将IMU和单眼相机数据用于人类运动捕捉.
- 利用扩散模型来学习人类运动先验和处理多模式传感器数据.
- 为了实现强大而准确的实时人类姿势估计.
主要方法:
- 提出一种基于扩散的解决方案,以学习人类运动先验.
- 连续的视觉信息作为一个整体被处理成一种条件嵌入来处理闭塞.
- 惯性测量数据与扩散模型的噪音姿势数据相连接.
主要成果:
- 拟议的方法证明了在姿势估计方面最先进的性能.
- 实验结果验证了系统设计在融合稀疏的IMU和单眼相机方面的有效性.
- 该方法显示了对偶尔的视觉信息退化的稳定性.
结论:
- 基于扩散的框架有效地融合了IMU和单眼相机数据,以捕捉人类运动.
- 与以前的方法相比,该方法实现了更高的准确性和稳定性.
- 这项工作推动了实时人类运动分析领域的发展.
相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
273
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
273
 01:25
Relative Motion Analysis using Rotating Axes
533
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
533
 01:22
Planar Rigid-Body Motion
552
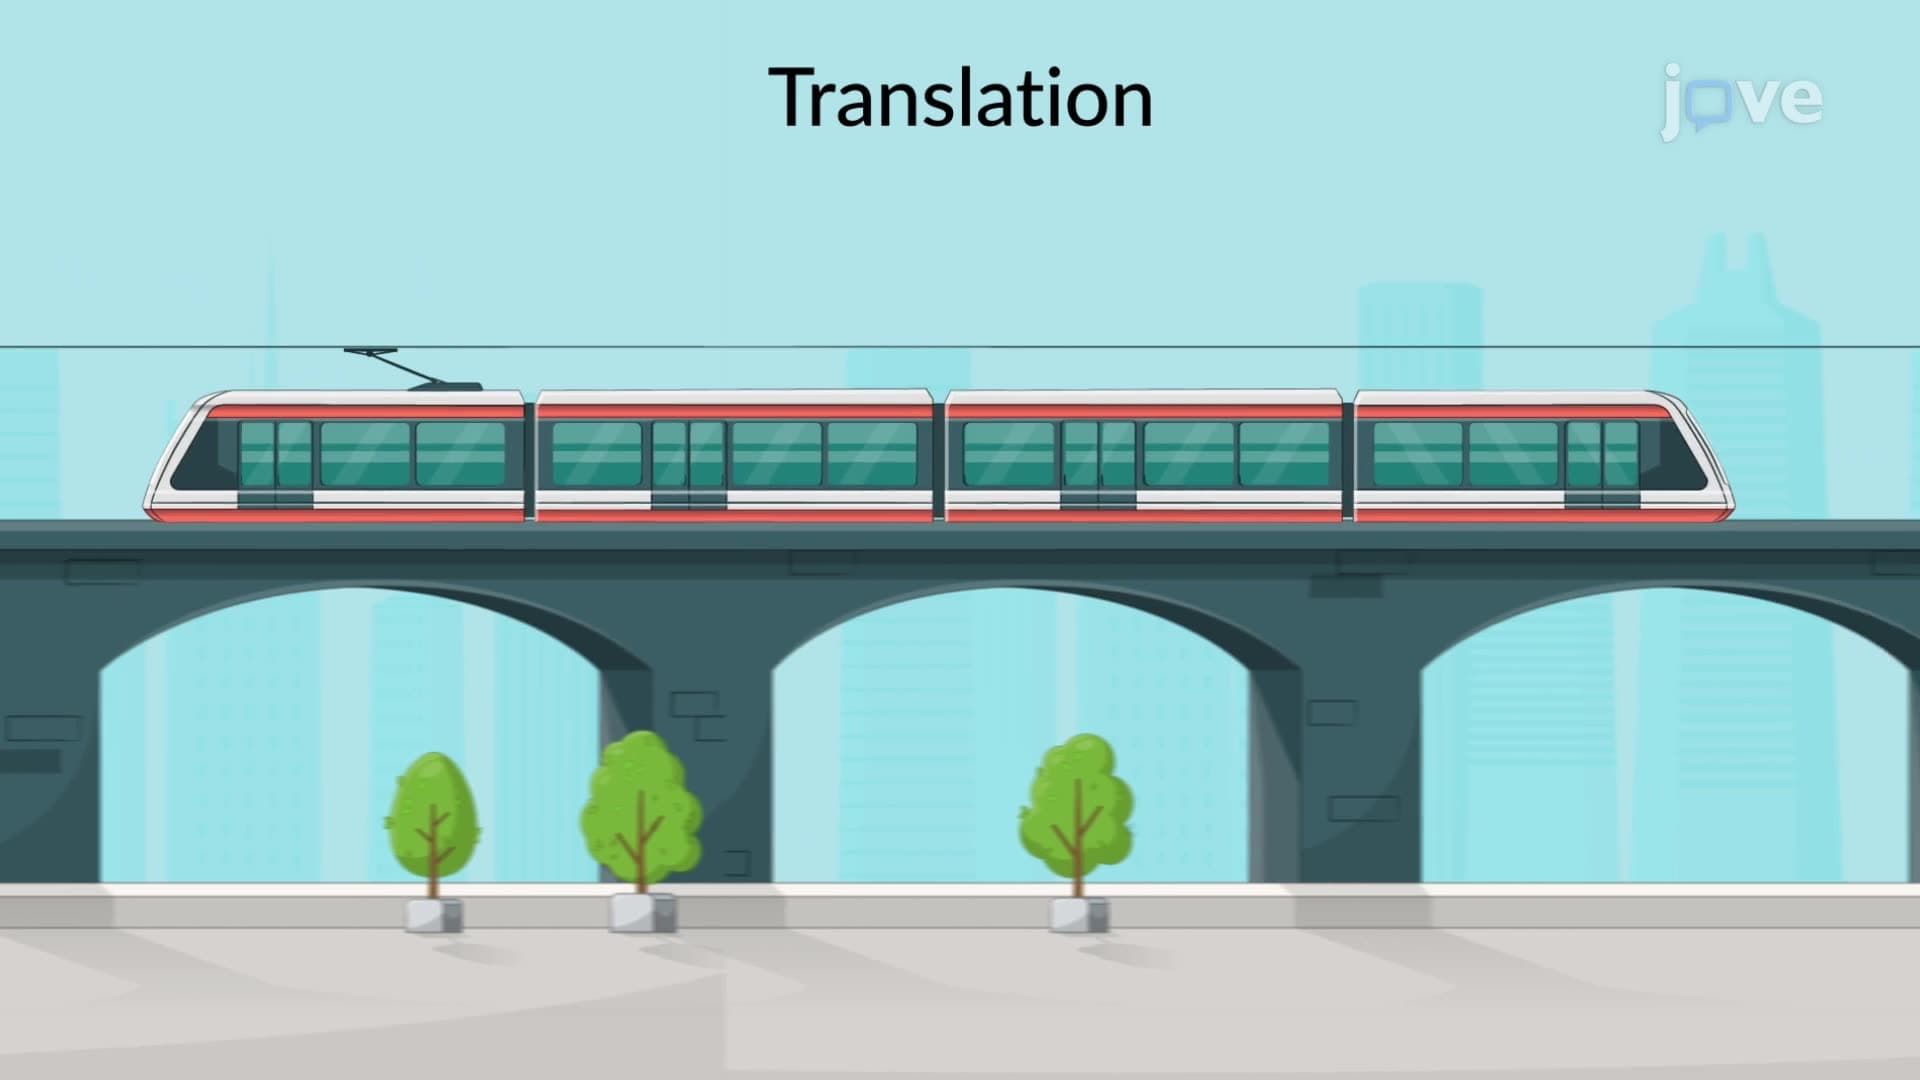
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
552
 01:24
Relative Motion Analysis - Velocity
430
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
430
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
449
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
449
 01:18
Distance Measurements by Taping
100
Tapes are essential in surveying for accurate, durable, and short-distance measurements. Made from lightweight, nylon-coated steel, they offer flexibility and strength for rugged outdoor use. The nylon coating protects against rust and wear, extending the tape's life. Standard lengths, around 30 meters, are marked in meters and millimeters for precision.Surveyors select tapes based on site conditions and accuracy needs. Lightweight, nylon-coated tapes are commonly used for ease of handling and...
100