
适应性调节一个非逆转的buck boost转换器与莱文伯格Marquardt基于滑动模式预测控制方案的调节
Omid Asvadi-Kermani1, Hoda Sorouri2, Arman Oshnoei2
1Faculty of Electrical and Computer Engineering, University of Tabriz, Tabriz, Iran. o.asvadikermani@modares.ac.ir.
Scientific reports
|August 6, 2025

概括
本研究介绍了一种自适应滑动模式模型预测控制 (ASMPC),用于精确调节逆转器电压. ASMPC提供更快的融合和更好的稳定性,提高能源效率.
科学领域:
- 电气工程 电气工程
- 控制系统 控制系统
- 电力电子 电力电子 电力电子
背景情况:
- 精确的输出电压调节对于直流/直流转换器至关重要,特别是在可再生能源系统中.
- 像PI控制器这样的传统控制器在转换器中与非线性和动态变化作斗争.
- 模型预测控制 (MPC) 提供了一个处理约束的框架,但可以在计算上密集,对模型不准确性敏感.
研究的目的:
- 提出一个自适应滑动模式模型预测控制 (ASMPC) 方案,用于准确调节低压,非逆转的buck-boost转换器的输出电压.
- 通过在受约束的MPC框架中整合一个滑动模式项来提高控制器融合速度和闭环稳定性.
- 通过在线模型更新,提高控制系统的适应性,以转换非线性和操作条件变化.
主要方法:
- 开发了一个ASMPC控制器,将滑动模式术语嵌入到一个有限制的MPC框架中,并具有明确的稳定性标准.
- 实现了在线线性状态空间模型更新,使用基于梯度的Levenberg-Marquardt算法来适应转换器动态.
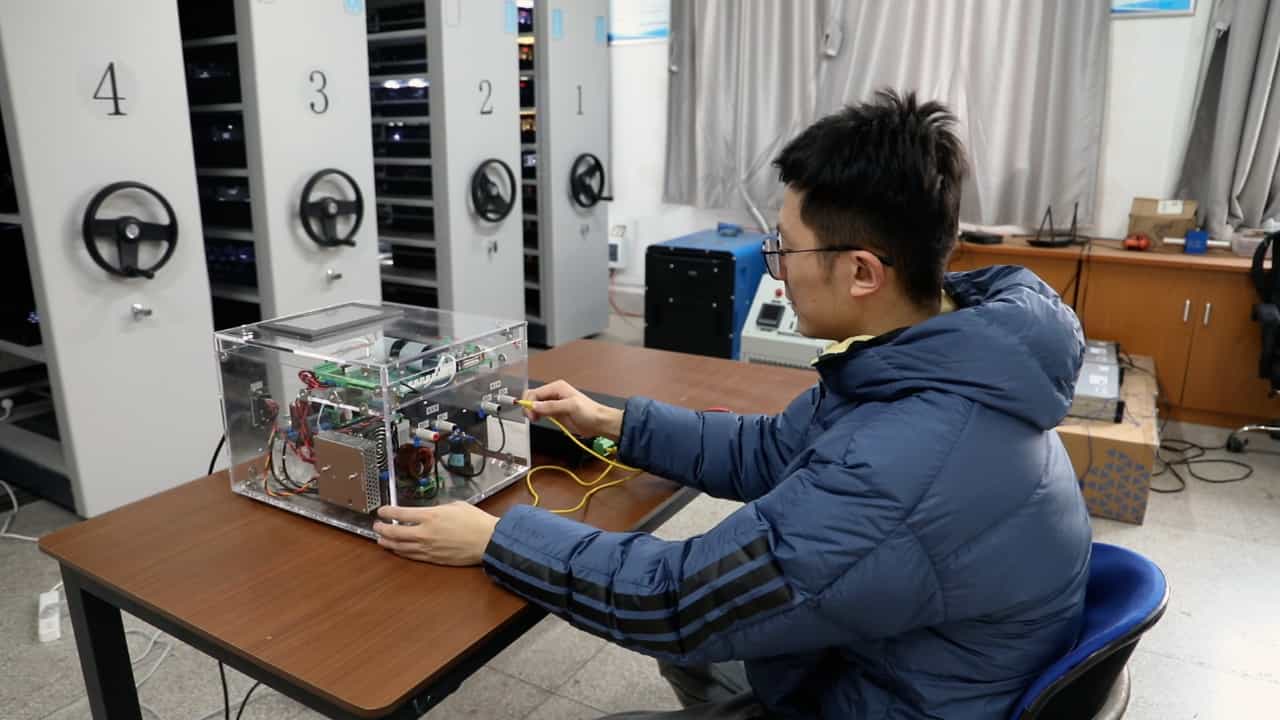
- 通过在光伏系统中的模拟和DC/DC转换器上的实验测试验证了ASMPC方案.
主要成果:
- 在不同的参考电压,负载条件和输入电压波动下,ASMPC证明了精确的输出电压跟踪.
- 与基线自适应MPC和传统PI控制相比,拟议的控制器实现了更快的沉降时间和减少电压波动.
- 在各种运行场景中观察到大约3%-6%的能源效率提高.
结论:
- 该ASMPC方案提供了一个强大的和高效的解决方案,用于精确的电压调节在buck-boost转换器.
- 在线模型更新显著提高了控制器处理非线性和动态变化的能力.
- 与传统方法相比,ASMPC提供了更高的性能,使其适合光伏系统等应用.
更多相关视频
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
11.8K
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
1.8K
相关概念视频
 01:26
PD Controller: Design
352
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
352
 01:07
Time-Domain Interpretation of PD Control
178
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
178
 01:24
PI Controller: Design
496
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
496
 01:28
Load-frequency control
259
Load-frequency control (LFC) is vital for maintaining power system stability, ensuring that frequency and power flows remain within acceptable limits during load changes. Turbine-governor control eliminates rotor accelerations and decelerations following load changes. However, a steady-state frequency error persists when the change in the turbine-governor reference setting is zero. In an interconnected power system, each area agrees to export or import a scheduled amount of power through...
259
 01:22
Controller Configurations
149
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
149
 01:26
Feedback control systems
427
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
427