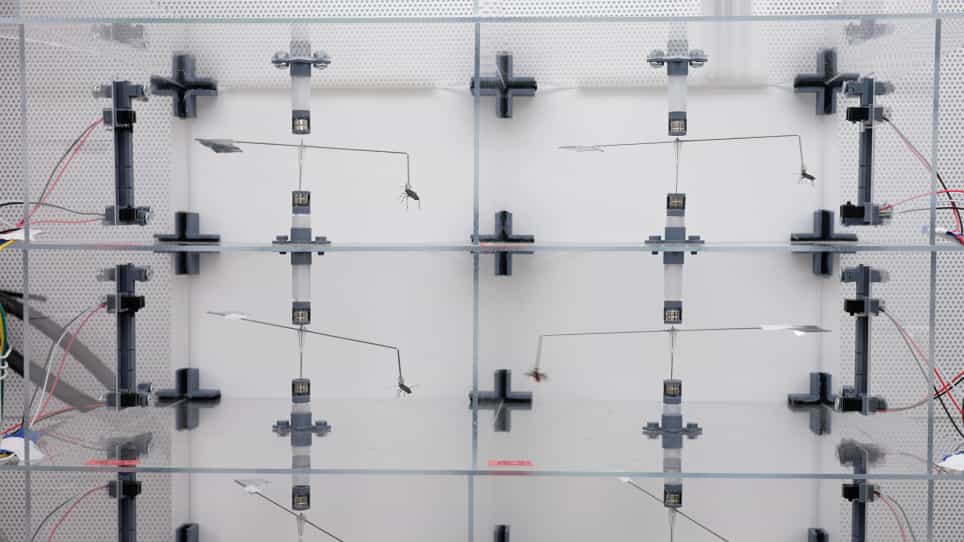

多用途FPV无人机的设计,组装和调整:灵活和低成本的替代方案
Franco Alessandro Arenas Mamani1, Gustavo Bryam Capira Malcoaccha1, Marco Antonio Blanco Quicaño1
1School of Electronics Engineering, Universidad Nacional de San Agustin de Arequipa, Peru.
HardwareX
|August 11, 2025

概括
APdrone (全用途无人机) 是一个可定制的,预算友好的无人机 (UAV),提供专业级性能. 开源设计促进了各种应用的可访问性和进一步开发.
科学领域:
- 机器人和控制系统 机器人和控制系统
- 航空航天工程 航空航天工程
- 开源硬件开发开源硬件开发
背景情况:
- 专业级无人机通常很昂贵,缺乏定制选项.
- 需要可访问,可适应和可修复的无人机平台.
- 现有的无人机解决方案可能无法满足特定的研究或娱乐需求.
研究的目的:
- 设计,组装和调整一个多功能,预算友好的FPV (第一人称视图) 无人机.
- 为了创建一个可定制和耐用的无人机替代高端商业型号.
- 提供开源的设计文件,以实现可访问性,可重复性和进一步开发.
主要方法:
- 使用碳纤维框架,无刷电机和APdrone的先进飞行控制器.
- 通过实证调整和受控测试实施了全面的调整过程.
- 优化比例整数导数 (PID) 参数 (Kp,Ki,Kd) 提供稳定的飞行性能.
主要成果:
- 在标准条件下,飞行时间约为8分钟.
- 展示了0.98公斤的最大有效载荷能力.
- 与高端无人机相比,提供了显著的成本节约 (647.09美元),同时保持了可比的功能.
结论:
- APdrone提供了一个可扩展,具有成本效益和可定制的无人机平台.
- 开源设计文件提高了可访问性,并鼓励社区驱动的进步.
- APdrone适用于研究,娱乐用途,以及更广泛的无人机 (UAV) 领域开发.
相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
272
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
272
 01:24
PI Controller: Design
495
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
495
 01:26
PD Controller: Design
352
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
352
 01:22
Controller Configurations
149
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
149