

神经操作员用于对联 PDE-ODE 系统的观察者增益和输出反控制
Malihe Abdolbaghi1, Seyed Amir Hossein Tabatabaei2, Mohammad Keyanpour3
1Department of Applied Mathematics, Faculty of Mathematical Sciences, University of Guilan, Rasht, Iran.
Scientific reports
|August 12, 2025

概括
这项研究引入了一个新的AI框架,用于在复杂的反应扩散系统中设计观察员和控制器. 该方法使用DeepONet准确估计系统状态并优化控制,显示高效率.
科学领域:
- 控制理论 控制理论
- 应用数学 应用数学 应用数学
- 机器学习 机器学习
背景情况:
- 对于相结合的普通微分方程-局部微分方程 (ODE-PDE) 系统,特别是反应-扩散类型的系统,设计观察者和控制器会带来重大分析挑战.
- 传统方法通常需要对核心方程进行复杂的分析解决方案,从而限制了它们的适用性和效率.
研究的目的:
- 开发一种新的数据驱动框架,用于对联ODE-PDE反应-扩散系统中的观察者和控制器设计.
- 利用神经运算器架构直接近似函数空间之间的非线性映射,绕过分析解决方案的需要.
主要方法:
- 拟议的框架使用DeepONet架构,一种神经运算符,来学习输入函数和输出解决方案之间的映射.
- 一个观察者首先被设计成基于可用的测量来估计系统的状态.
- 然后使用这些估计状态来设计控制器,以实现所需的系统行为.
主要成果:
- 与Goursat方程的精确解相比,模拟结果显示了高精度和计算效率.
- 评估了关键绩效指标,包括趋同率,估计错误和控制力度.
- 一项废除研究证实了在拟议框架内单个成分的有效性.
结论:
- 开发的数据驱动框架为设计复杂的ODE-PDE系统中的观察员和控制器提供了准确且计算效率高的解决方案.
- 基于DeepONet的方法有效地处理非线性映射,为传统分析方法提供了强大的替代方案.
- 这项工作推进了神经操作员在动态系统的控制理论中的应用.


相关概念视频
 01:18
Second Order systems II
172
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
172
 01:17
Open and closed-loop control systems
996
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
996
 01:20
Second Order systems I
234
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
By reinterpreting the system, one can derive the closed-loop transfer function, which...
234
 01:23
Root Loci for Positive-Feedback Systems
159
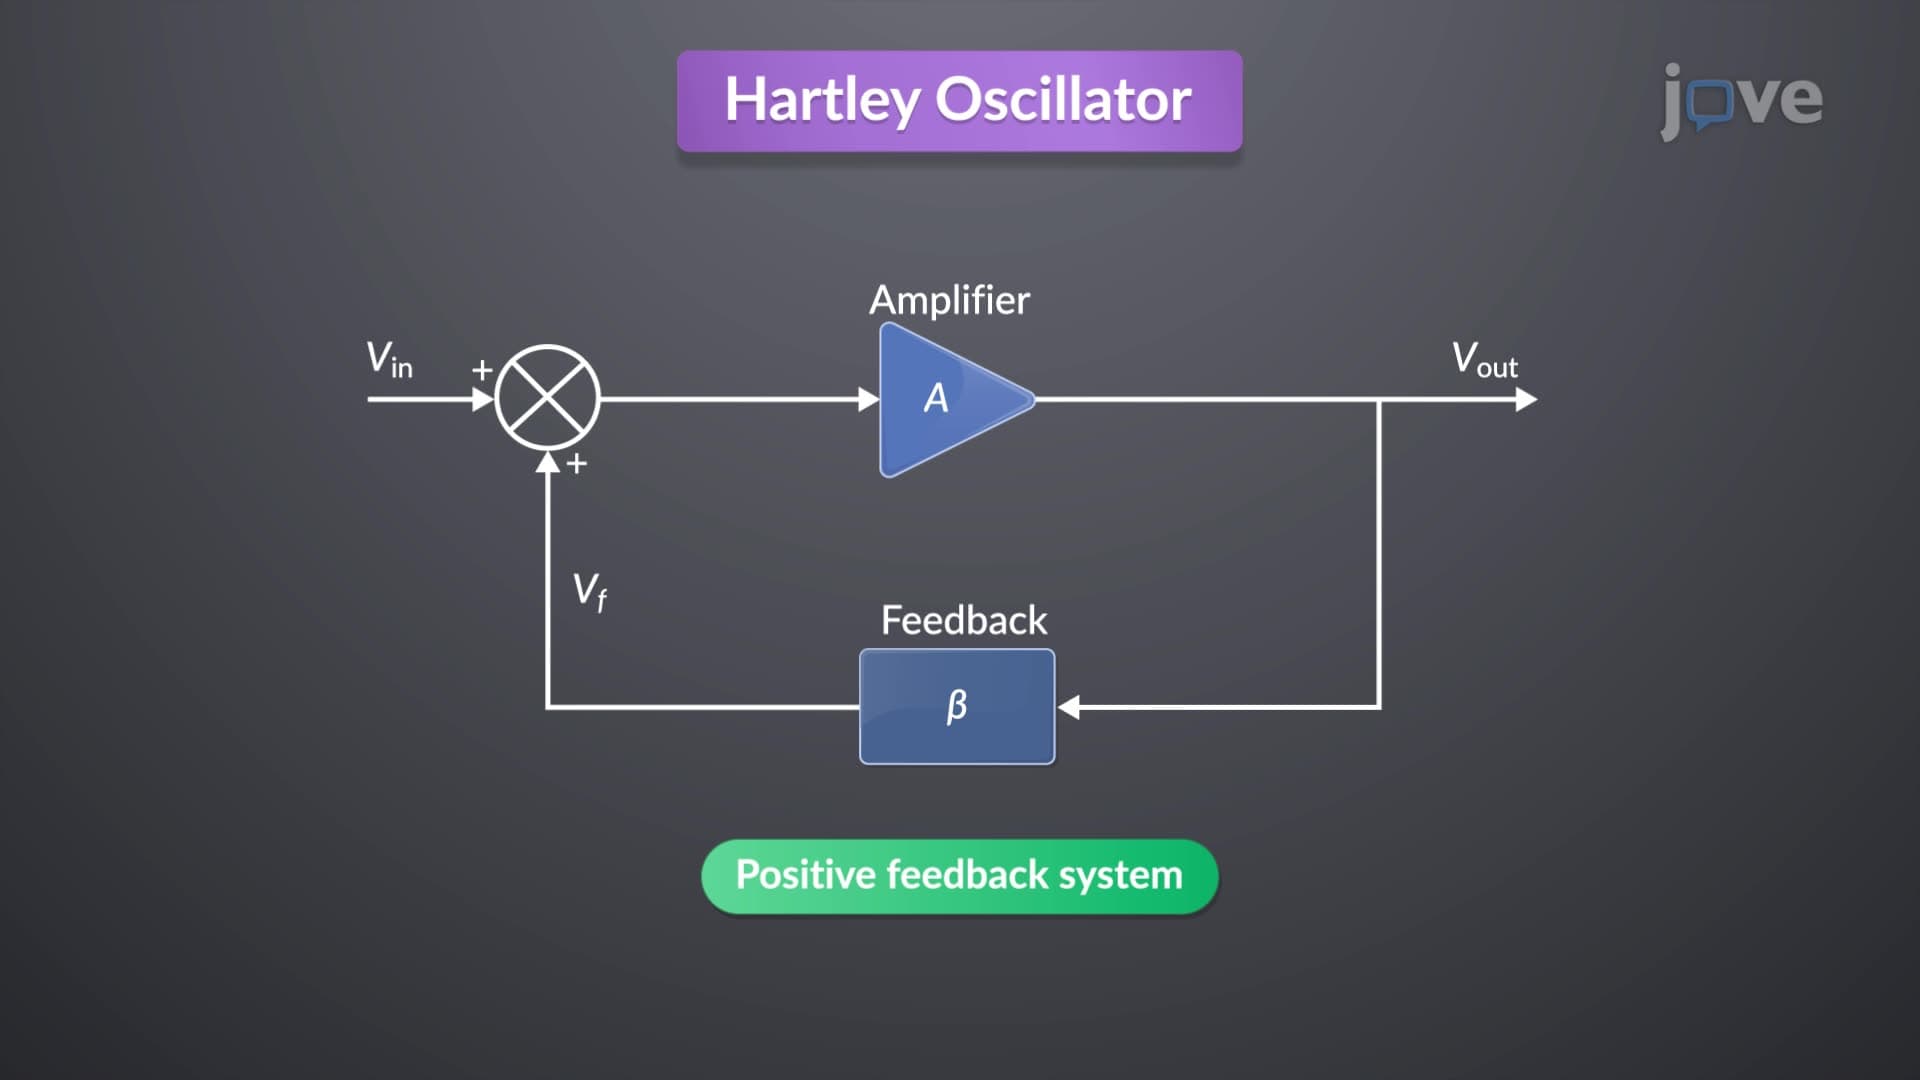
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
159
 01:26
Feedback control systems
427
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
427
 01:21
Control System Problem
175
In an open-loop system, such as a basic thermostat, the poles of the transfer function influence the system's response but do not determine its stability. However, when feedback is introduced to form a closed-loop system, such as an advanced thermostat that adjusts heating based on room temperature, stability is governed by the new poles of the closed-loop transfer function.
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
175