相关实验视频
Updated: May 10, 2026
11:57

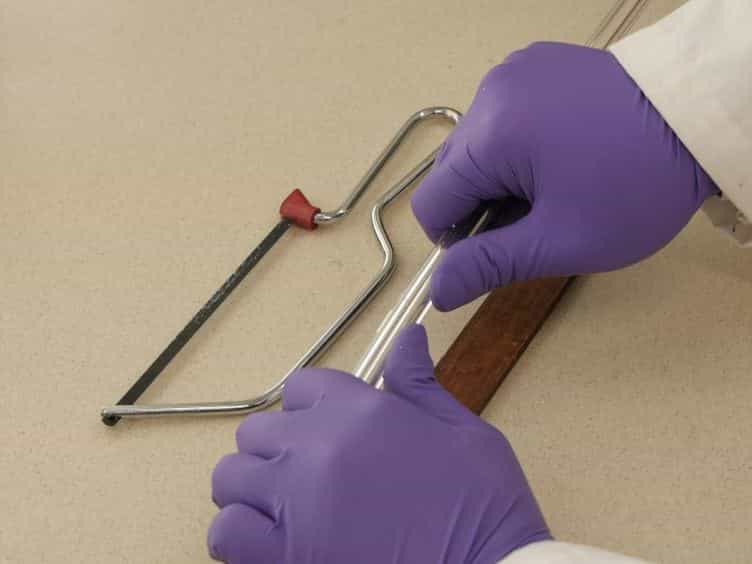
Fabricating Metamaterials Using the Fiber Drawing Method
Published on: October 18, 2012
13.9K

概括
研究人员探索了高效的非线性光学元材料的形状-双断相匹配. 这种方法克服了传统方法的局限性,使可调节的频率转换能够用于红外光产生.
科学领域:
- 非线性光学是非线性光学.
- 材料科学 材料科学 材料科学
- 超材料是指一种超材料.
背景情况:
- 阶段匹配 (PM) 对于高效的非线性光学频率转换至关重要.
- 在异性质晶体中,传统的双折 PM 是由材料特性所限制的.
- 超材料中的形状两重违规性提供了一种克服这些局限性的方法.
研究的目的:
- 从理论和数值上分析层叠的元材料中的角度调整的形状-折叠的PM.
- 证明高效的第二波生成 (SHG) 和差频生成 (DFG).
- 探索超材料在新型非线性光学应用中的潜力.
主要方法:
- 角度调节相匹配的理论分析.
- 非线性光学相互作用的数值模拟.
- 使用GaAs和SiN进行周期性层状元材料的设计.
主要成果:
- 证明了近红外辐射的高效SHG.
- 实现了中红外光的高效DFG.
- 展示了一个八度的角调性,用于中红外线生成 (3.36.7μm).
结论:
- 超材料中的形状-双断相匹配为非线性光学提供了一个多功能平台.
- 这种方法扩展了超越自然双晶晶体的能力.
- 超材料为设计用于频率转换的先进光学设备提供了一个新的途径.
相关概念视频
 01:13
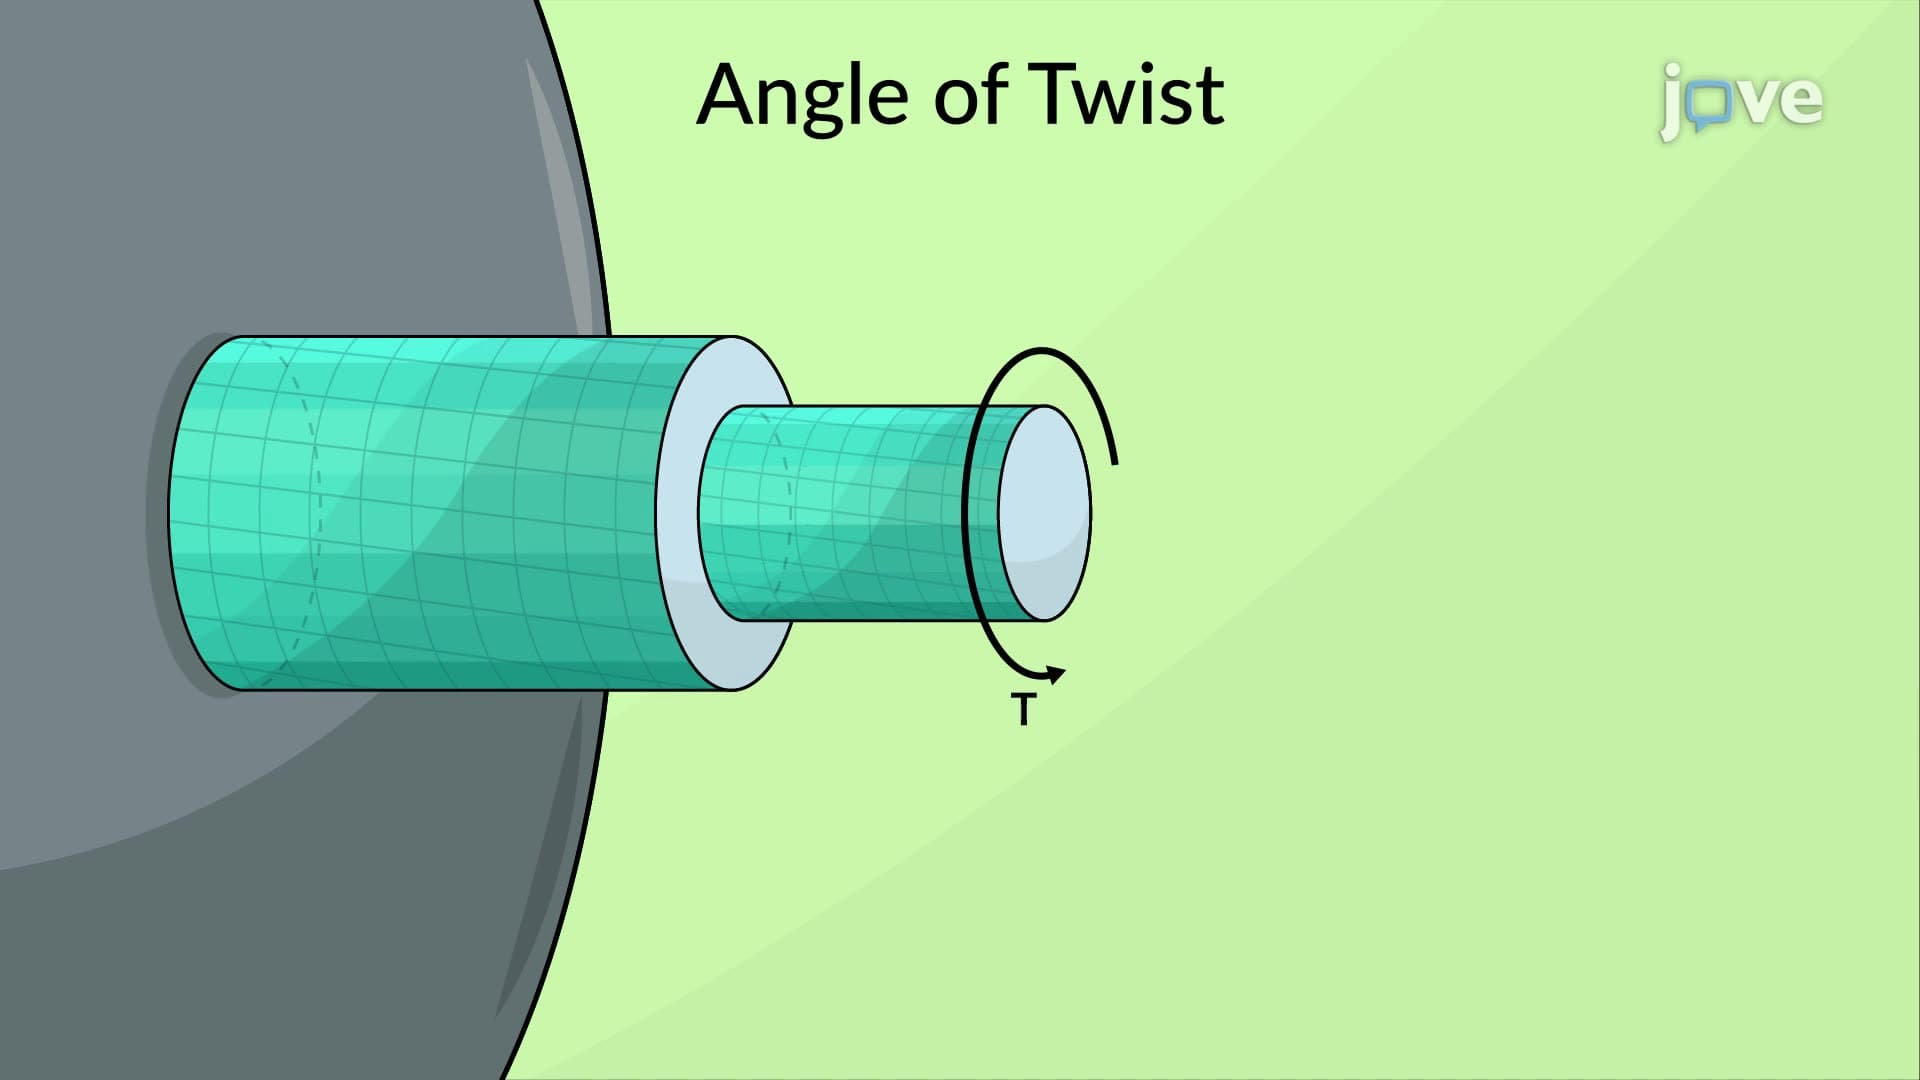
Angle of Twist - Elastic Range
Consider a cylindrical shaft with a length denoted by L and a consistent cross-sectional radius referred to as r. This shaft undergoes a torque at the free end. The highest shearing strain within the shaft is directly proportional to the twist angle and the radial distance from the shaft axis. When the shaft behaves elastically, this shearing strain can be articulated using variables such as the applied torque, radial distance, the polar moment of inertia, and the modulus of rigidity. By...
 01:13
Angle of Twist: Problem Solving
An electric motor applies a torque of 700 N·m to an aluminum shaft, triggering a stable rotation. Two pulleys, B and C, are subjected to torques of 300 N·m and 400 N·m, respectively. The modulus of rigidity is provided as 25 GPa. With the knowledge of the length and diameter of each segment, the twist angle between the two pulleys can be computed. First, a section cut is made between pulleys B and C, and the cut cross-section is analyzed using a free-body diagram. Given that the torque exerted...
 01:15
Unsymmetric Bending - Angle of Neutral Axis
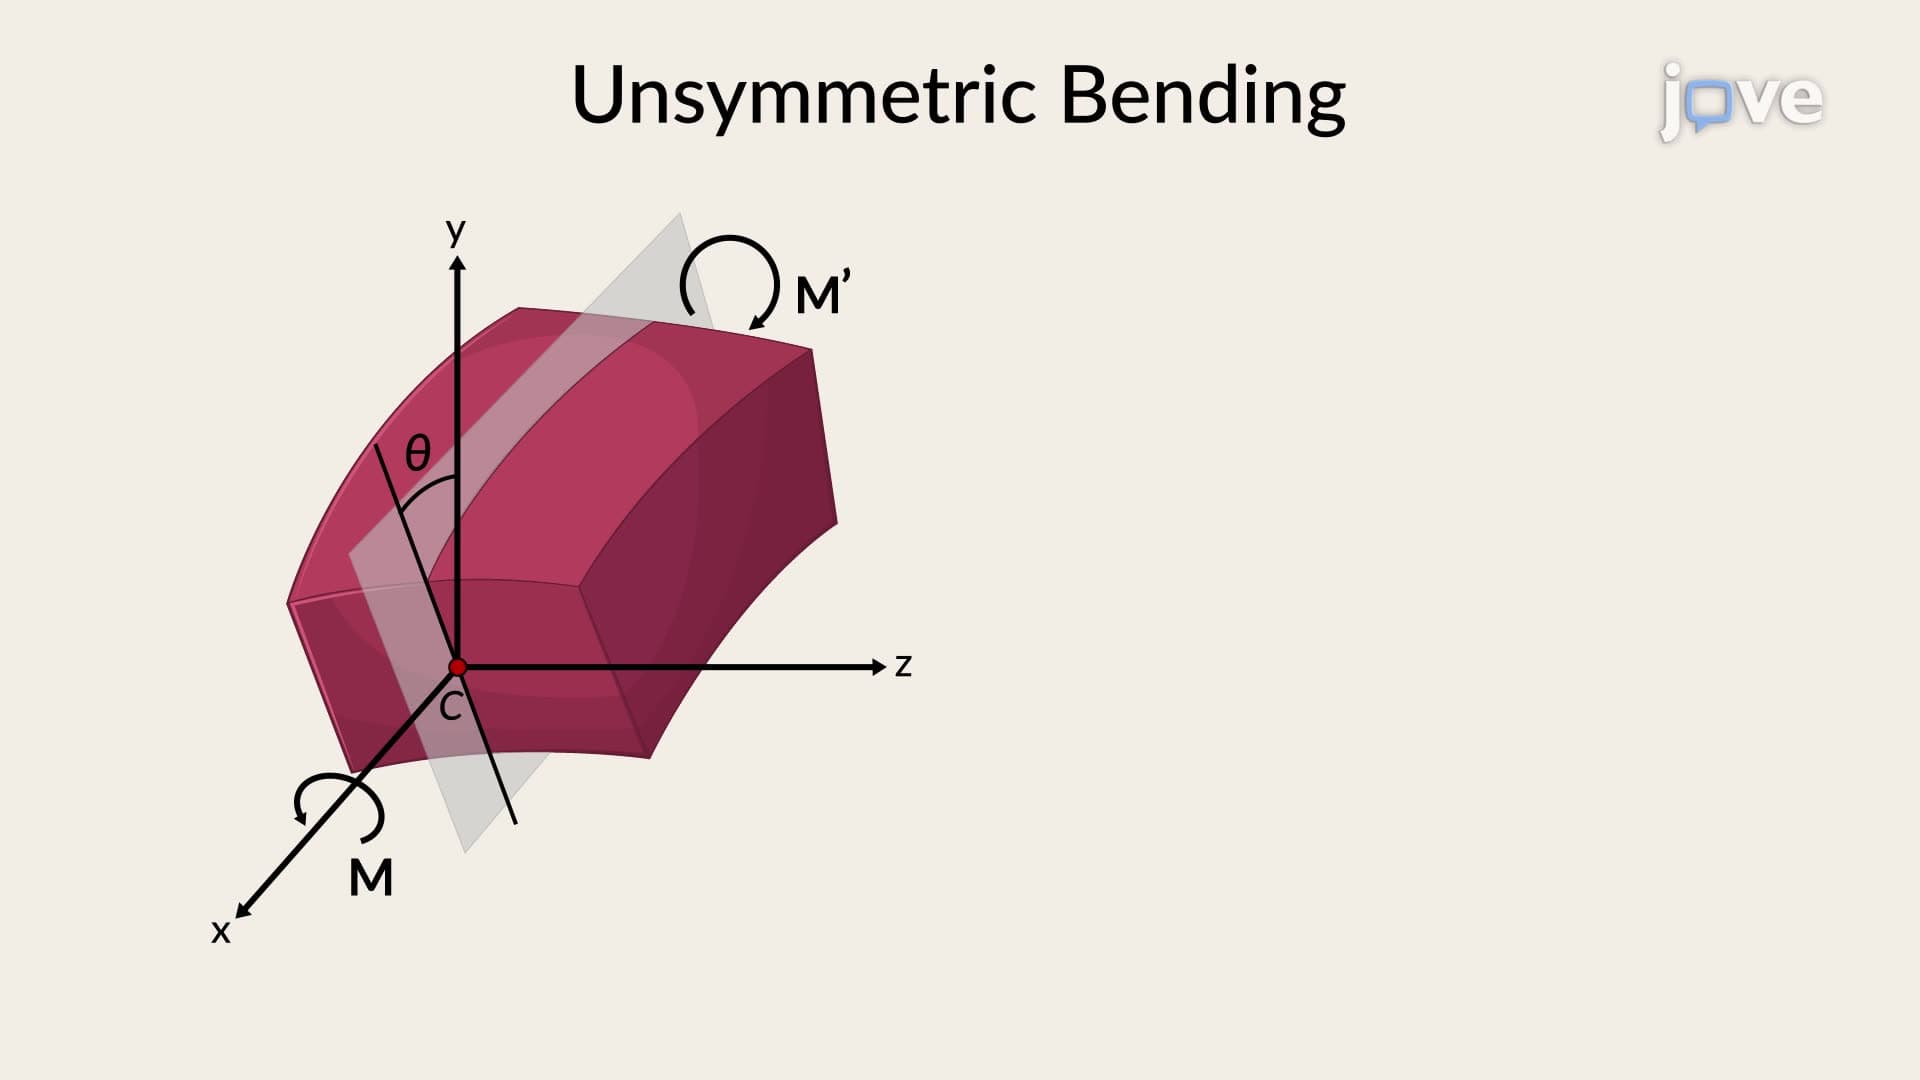
Unsymmetrical bending occurs when a structural member is subjected to bending moments in a plane that does not align with the member's principal axes. This scenario typically arises in beams and other structural components when loads are applied at non-ideal angles, introducing complexities in stress analysis.
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal centroidal axes. The...
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal centroidal axes. The...
 01:26
Linear Approximation in Frequency Domain
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
Phase-lead controllers are commonly used in various control systems to enhance response speed and stability. Adjusting the brightness on a television screen offers a practical example of phase-lead control. When contrast is enhanced, a phase-lead controller is employed. Mathematically, phase-lead control is identified when the first parameter is smaller than the second.
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers are widely used in control systems to improve stability and reduce steady-state errors. A dimmer switch controlling the brightness of a light bulb serves as a practical example of phase-lag control, gradually adjusting the bulb's brightness. Mathematically, phase-lag control or low-pass filtering is represented when the factor 'a' is less than 1.
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...