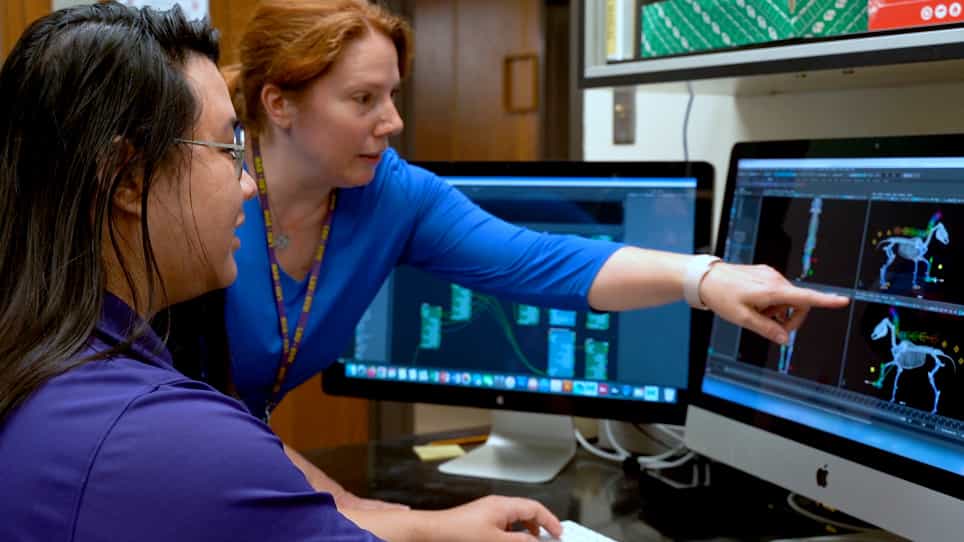

一个没有标记的方法,用于马的全身生物力学
Sarah K Shaffer1, Omar Medjaouri1, Brian Swenson1
1Southwest Research Institute, 6220 Culebra Rd., San Antonio, TX 78238, USA.
Animals : an open access journal from MDPI
|August 14, 2025

概括
这项研究介绍了一种马的无标记运动捕捉系统,可以进行可扩展和高效的3D全身运动分析. 这种新的方法使用神经网络和多摄像头视频,大大改善了临床评估和研究.
科学领域:
- 兽医医学 兽医医学 兽医医学
- 生物力学 生物力学
- 计算机视觉 计算机视觉
背景情况:
- 量化马类动力学对于临床评估,研究和性能分析至关重要.
- 目前用于捕捉马的运动的现有方法通常是复杂和劳动密集型的,限制了它们的广泛采用.
- 需要更容易获得和更有效的技术来分析马的运动.
研究的目的:
- 开发和验证一种新的无标记运动捕获方法,用于计算三维全身马体动力学.
- 为传统的仪器式运动捕捉技术提供可扩展和劳动效率高的替代方案.
- 评估这种用于马类运动分析的新方法的准确性和潜力.
主要方法:
- 使用多摄像头视频数据开发了一种无标记运动捕捉系统.
- 神经网络被用来在3D中识别和三角化骨地标 (标记物).
- 一个马类生物力学模型被缩放,并使用逆动力学 (IK) 来生成动力学轨迹.
- 该方法在三种步态的马上进行了测试,评估了各种神经网络.
主要成果:
- 无标记系统成功计算了全身马体动力学,而无需对动物进行仪器仪表.
- 神经网络预测了超过78%的标记物在半径骨长度的25%以内.
- 连接角度的平方根平均误差在大多数自由度中小于10度,显示出高精度.
- 在不同的数据集上训练神经网络,在联合角度预测中提高了准确性和曲线相似性.
结论:
- 开发的无标记运动捕捉方法显示了准确和高效的全身马动力学分析的巨大潜力.
- 这种方法为传统方法提供了一个可扩展和不那么劳动密集的替代方案,促进了在研究和临床环境中更广泛的应用.
- 这项研究验证了神经网络和多摄像头视频的使用,以推进马类生物力学研究.

相关概念视频
 01:15
Kinematic Equations: Problem Solving
14.2K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
14.2K
 01:17
Kinematic Equations - II
10.7K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
10.7K
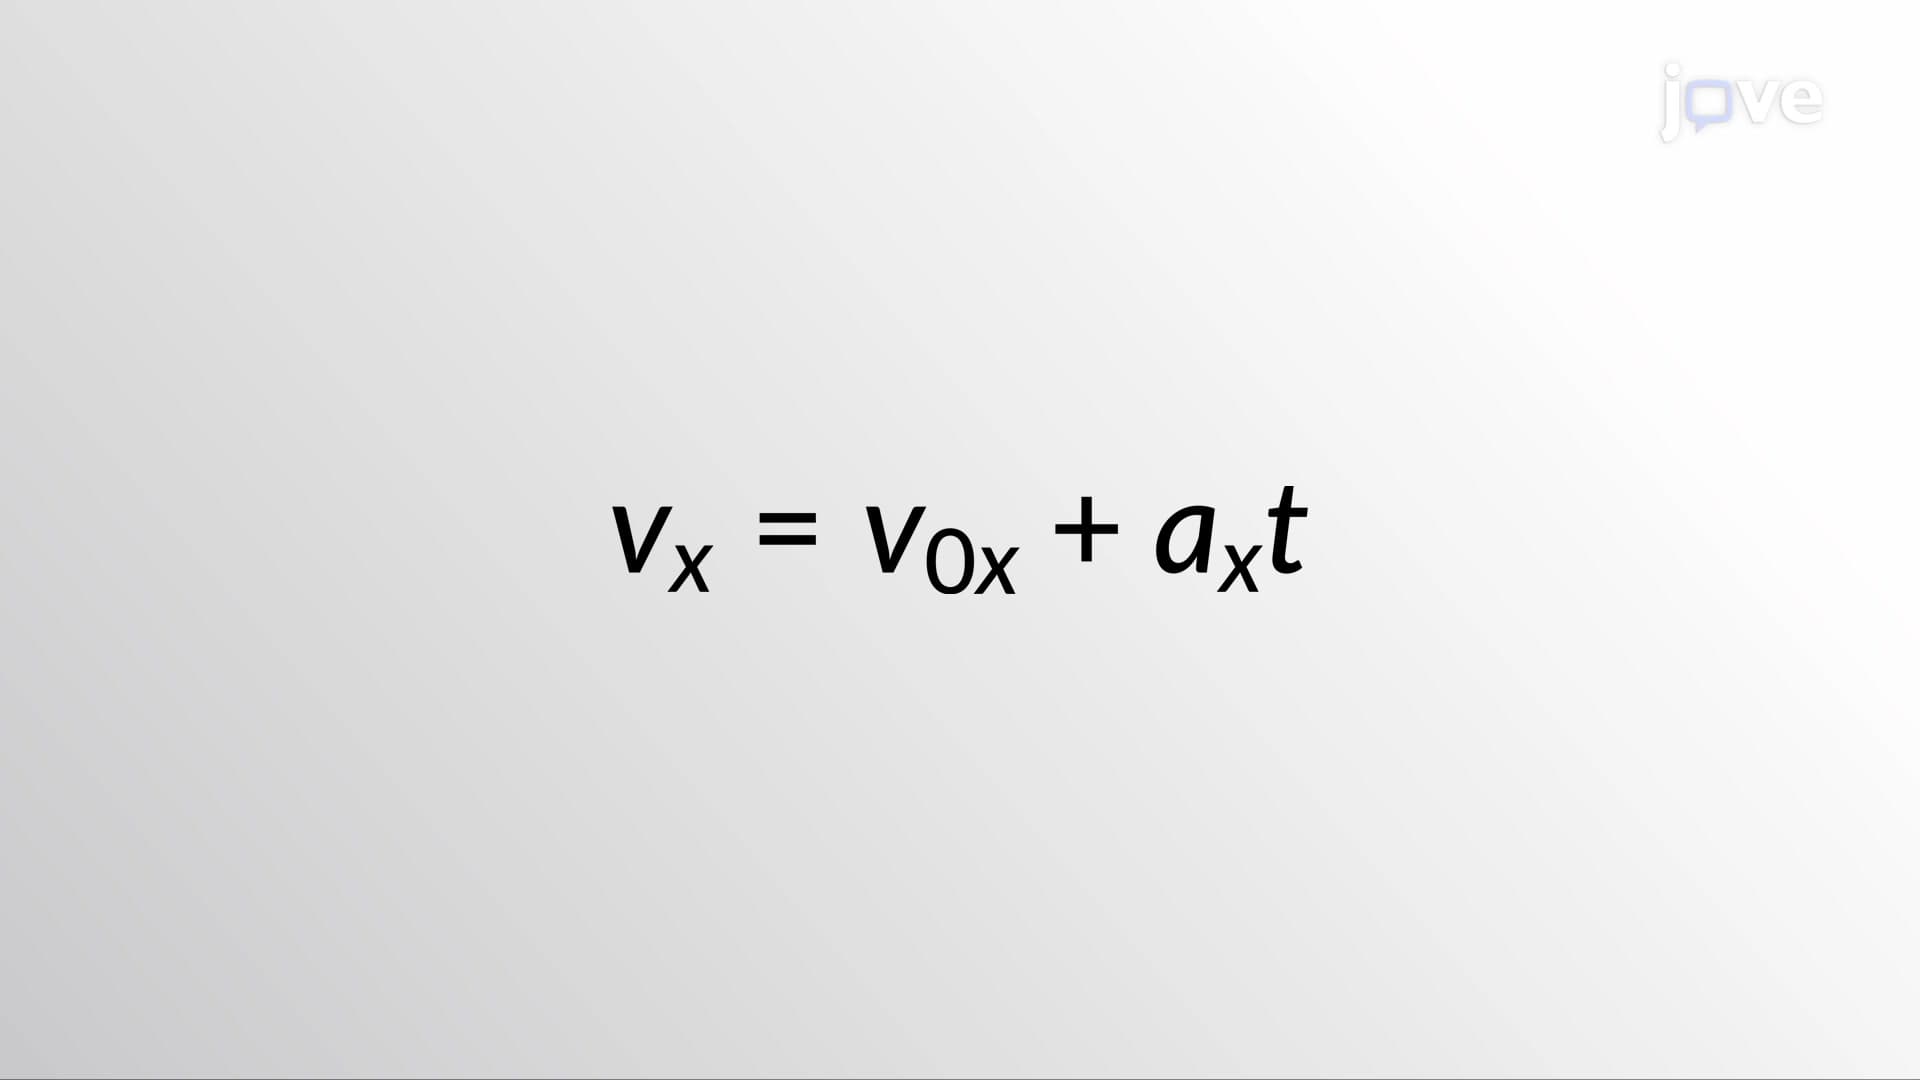 01:26
Kinematic Equations - I
11.9K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
11.9K
 01:18
Kinematic Equations - III
8.5K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
8.5K