面向不变的3D传感器数据的通用向量校准
1School of Electrical Engineering, Korea University, Seoul 02841, Republic of Korea.
Sensors (Basel, Switzerland)
|August 14, 2025

概括
本研究引入了一种通用矢量校准算法,以确保对电子设备的3D传感器测量一致,无论方向如何. 该方法在室内定位和步骤检测等应用中显著提高了准确性.
科学领域:
- 传感器融合和信号处理
- 机器人和人机交互的人机交互
- 地理空间技术是什么
背景情况:
- 现代电子设备依赖于3D传感器来跟踪运动,但测量对设备方向敏感.
- 当前的方法往往忽略方向数据或假定固定姿势,限制现实世界的应用准确性.
- 不一致的传感器数据阻碍了室内定位和活动识别等应用程序的可靠性能.
研究的目的:
- 开发一个通用的矢量校准算法,以实现一致的3D传感器测量,无论设备的方向如何.
- 在基于传感器的应用中实现准确的定向数据利用.
- 为了解决仅使用大小向量和临时姿势假设的局限性.
主要方法:
- 建议采用两阶段的校准过程:首先,通过校准倾斜 (pitch and roll) 将局部坐标转换为全球坐标.
- 其次,通过纠正曲面旋转以实现应用特定的对齐,将全局坐标转换为参考坐标.
- 该算法使用基于地磁场的室内定位和双向步骤检测进行了评估.
主要成果:
- 对于室内定位,矢量校准减少了83.6%的不匹配,定位误差从31.14米降至0.66米.
- 对于步骤检测,精度从67.63%提高到99.25%,前进/后退分类达到100%.
- 这些改进在各种设备定向中是一致的.
结论:
- 提出的通用矢量校准算法可确保可靠和独立于方向的3D矢量测量.
- 这种方法显著提高了基于传感器的应用程序的性能,包括室内定位和活动识别.
- 该算法为使用3D传感器的设备在现实世界中部署提供了强大的解决方案.
更多相关视频
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
10.8K
 10:12
Three Dimensional Vestibular Ocular Reflex Testing Using a Six Degrees of Freedom Motion Platform
Published on: May 23, 2013
16.0K
相关概念视频
 01:16
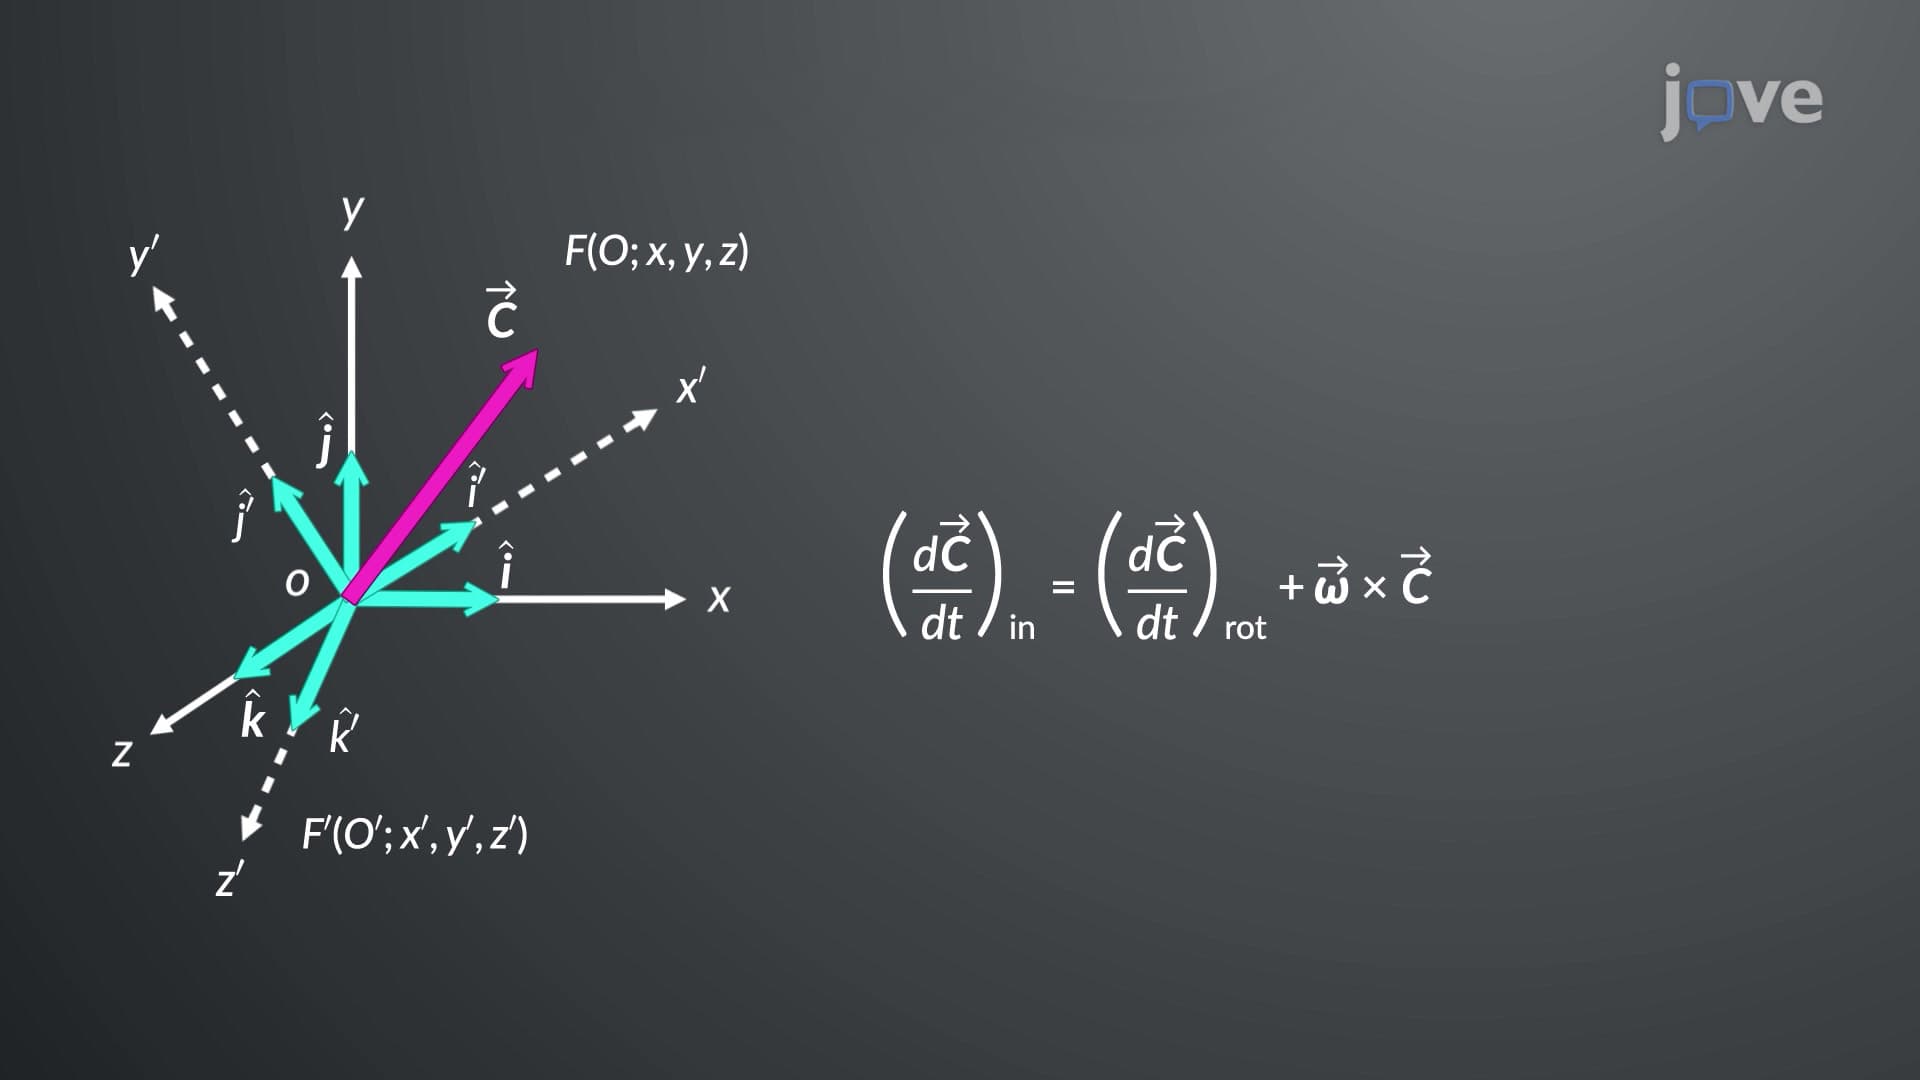
Vector Transformation in Rotating Coordinate Systems
1.8K
Consider a vector rotating about an axis with an angular velocity, such that its tip sweeps a circular path.
1.8K
 01:29
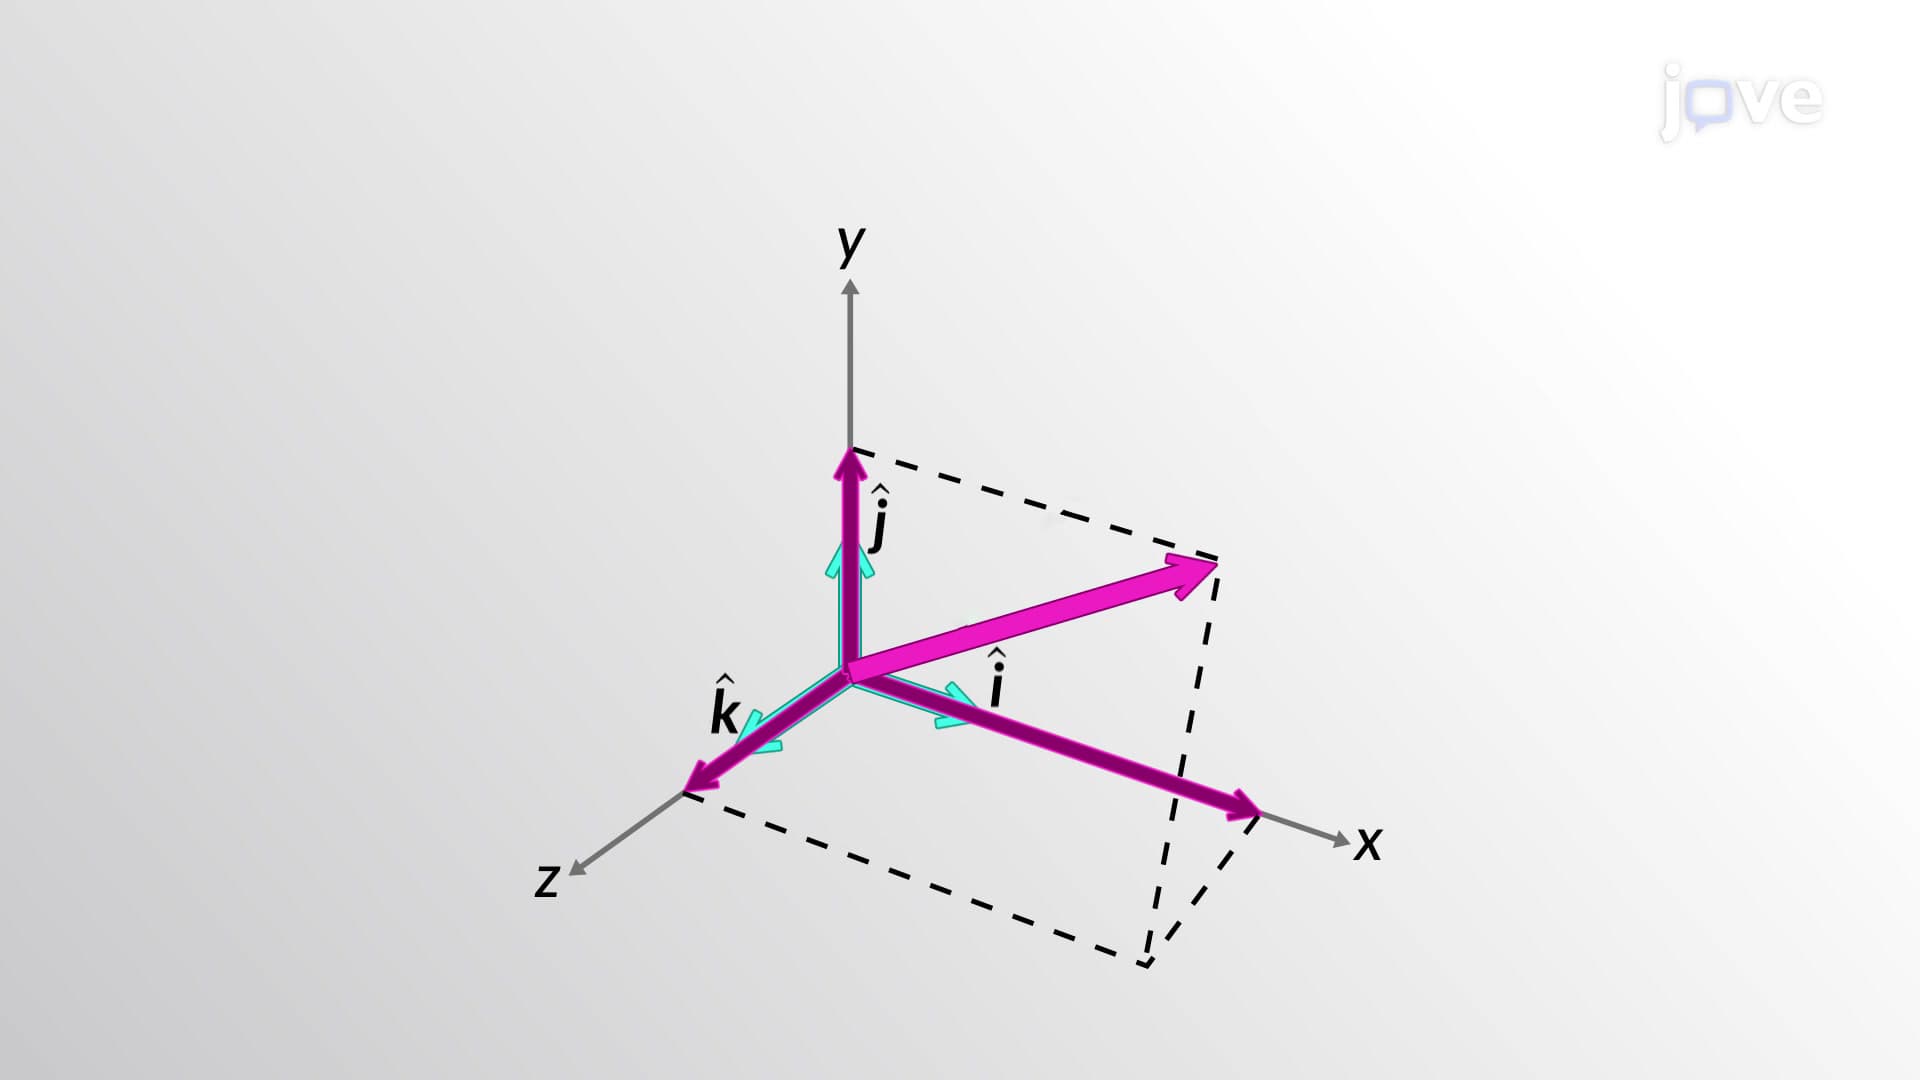
Vector Components in the Cartesian Coordinate System
22.2K
Vectors are usually described in terms of their components in a coordinate system. Even in everyday life, we naturally invoke the concept of orthogonal projections in a rectangular coordinate system. For example, if someone gives you directions for a particular location, you will be told to go a few km in a direction like east, west, north, or south, along with the angle in which you are supposed to move. In a rectangular (Cartesian) xy-coordinate system in a plane, a point in a plane is...
22.2K
 01:20
Calibration Curves: Linear Least Squares
2.2K
A calibration curve is a plot of the instrument's response against a series of known concentrations of a substance. This curve is used to set the instrument response levels, using the substance and its concentrations as standards. Alternatively, or additionally, an equation is fitted to the calibration curve plot and subsequently used to calculate the unknown concentrations of other samples reliably.
For data that follow a straight line, the standard method for fitting is the linear...
For data that follow a straight line, the standard method for fitting is the linear...
2.2K
 01:03
Inertial Frames of Reference
7.4K
Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with...
7.4K
 01:22
Polar and Cylindrical Coordinates
15.6K
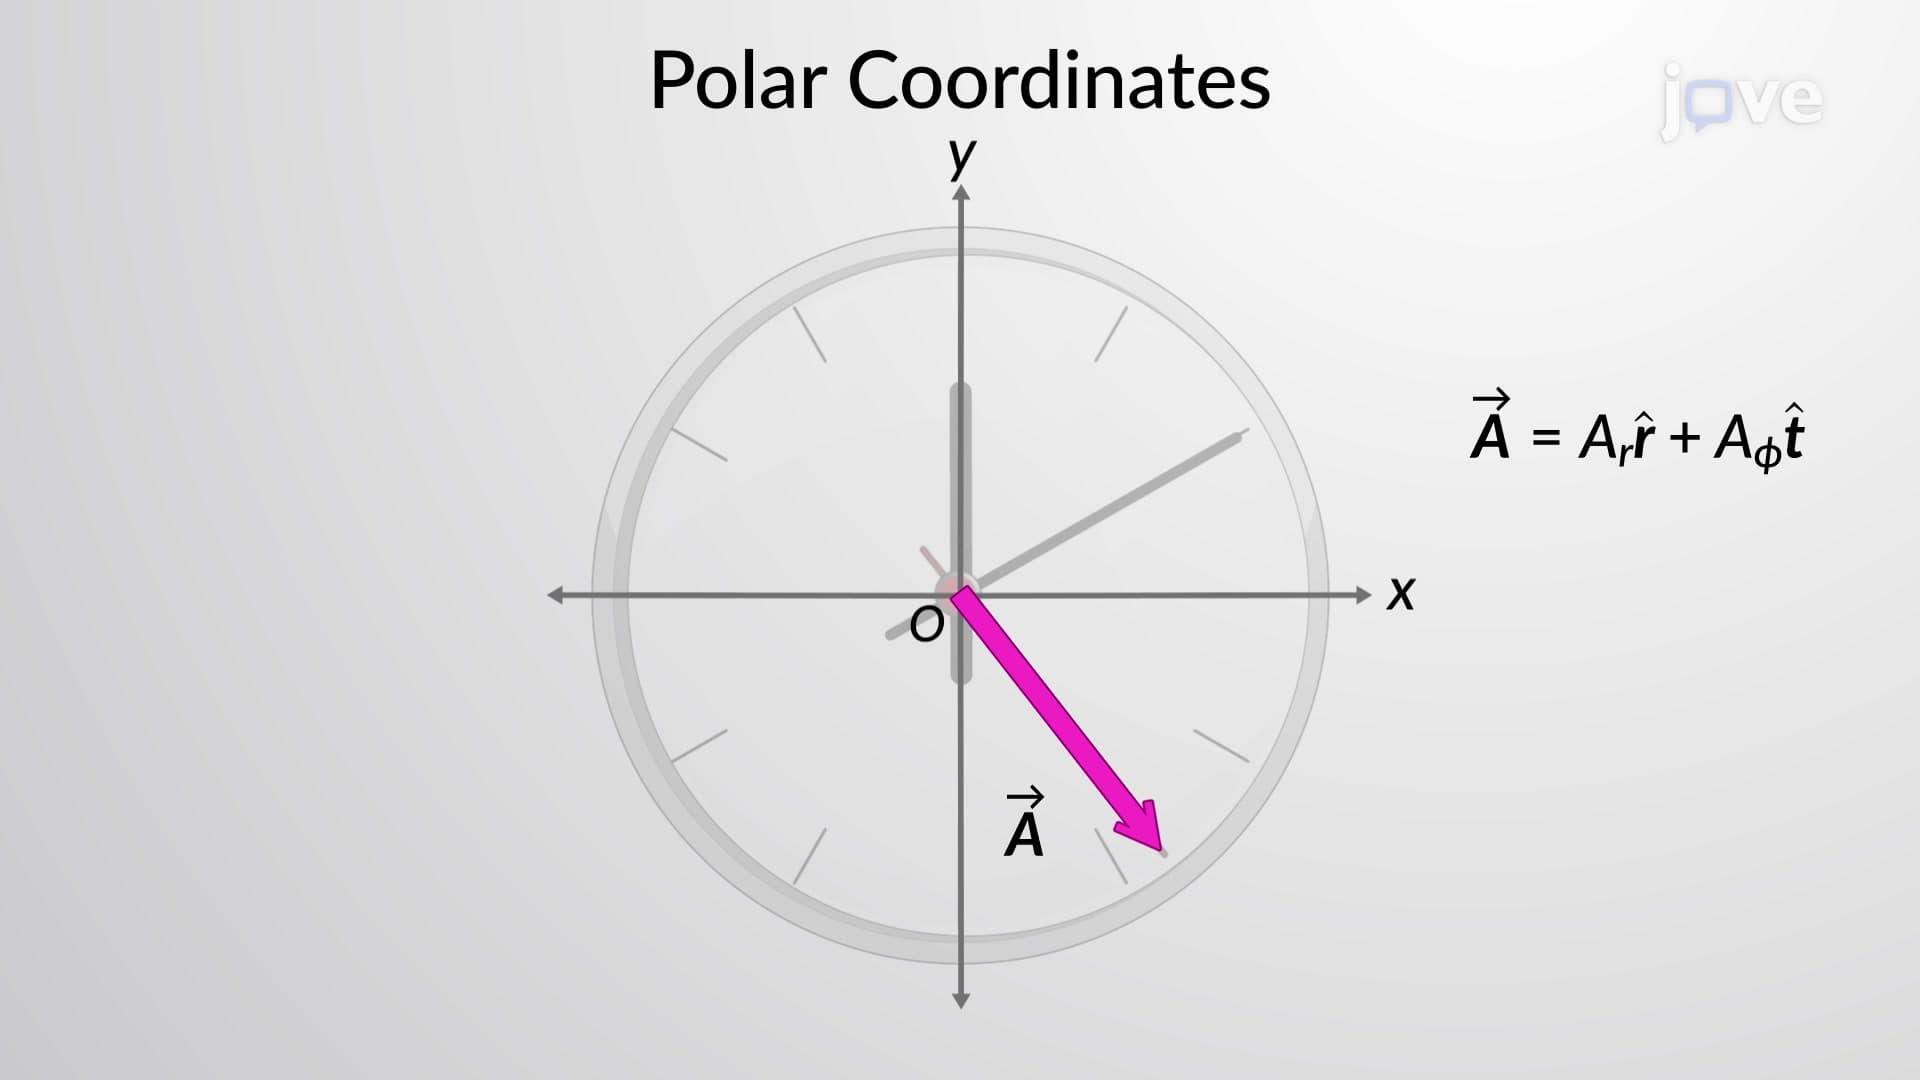
The Cartesian coordinate system is a very convenient tool to use when describing the displacements and velocities of objects and the forces acting on them. However, it becomes cumbersome when we need to describe the rotation of objects. So, when describing rotation, the polar coordinate system is generally used.
15.6K
 01:12
Instrument Calibration
267
Instrument calibration is essential for ensuring that instruments produce accurate and consistent results. It is vital in manufacturing, healthcare, testing laboratories, and scientific research. Calibration processes are specific to each instrument and help enhance data accuracy. Each instrument has a unique calibration process tailored to its design and function to improve data accuracy.
Analytical Balance Calibration
An analytical balance measures mass and requires regular calibration to...
Analytical Balance Calibration
An analytical balance measures mass and requires regular calibration to...
267