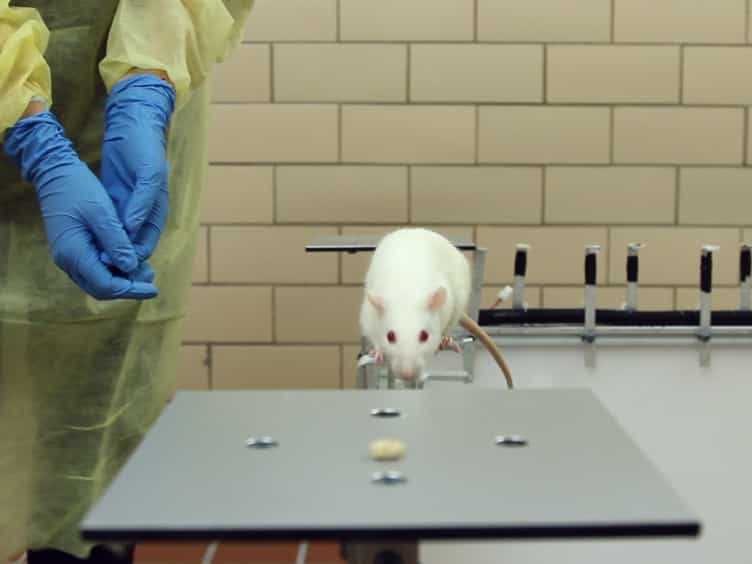
工作犬运动的生物力学I:平稳状态的慢跑
James P Charles1, Eithne J Comerford1,2, Victoria F Ratcliffe3
1Department of Musculoskeletal & Ageing Science, Institute of Life Course and Medical Sciences, University of Liverpool, Liverpool, UK.
The Journal of experimental biology
|August 22, 2025

概括
工作犬品种在稳定状态时表现出明显的生物力学. 了解这些运动差异对于优化狗的健康和福利至关重要.
科学领域:
- 狗的生物力学
- 比较运动分析
- 动物形态
背景情况:
- 工作犬品种中稳定运动的生物力学研究不足.
- 品种之间的动力学和动力学参数的变化及其与形态学的关系是未知的.
研究的目的:
- 为了比较拉布拉多犬,牧羊犬和西班牙犬的总体形态和慢跑运动.
- 研究动力学和动力学参数之间的差异及其与形态学的关系.
主要方法:
- 总体形态和慢跑运动的比较分析.
- 使用运动捕捉,力盘和生物机械建模.
- 我比较了27只拉布拉多犬,牧羊犬和西班牙犬的品种.
主要成果:
- 发现肢体和身体长度有轻微的阳性度变化,牧羊犬的长度比西班牙犬更长.
- 较大的牧羊犬表现出比较小的品种更大的速度,步伐长度和地面反应力.
- 步行周期时间和步伐长度没有与身体大小等比,表明动态不相似.
结论:
- 工作犬品种之间稳定状态运动的生物力学存在显著差异.
- 特定品种的运动数据库和考虑对狗的研究和福利至关重要.
- 根据特定品种的生物力学来定制实践可以最大限度地提高工作狗的健康和福利.
更多相关视频
相关概念视频
 01:17
Kinematic Equations - II
10.6K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
10.6K
 01:16
Bones of the Lower Limb: Femur and Patella
2.9K
The femur is the body's longest and strongest bone spanning the thigh region. Its head articulates with the acetabulum of the hip bone to form the hip joint. A minor indentation on the medial side of the femoral head, called the fovea capitis, serves as the site of attachment for the ligament of the head of the femur. This weak ligament spans the femur and acetabulum and supports the hip joint. The narrowed region below the head is the neck of the femur. The inclination angle between the...
2.9K
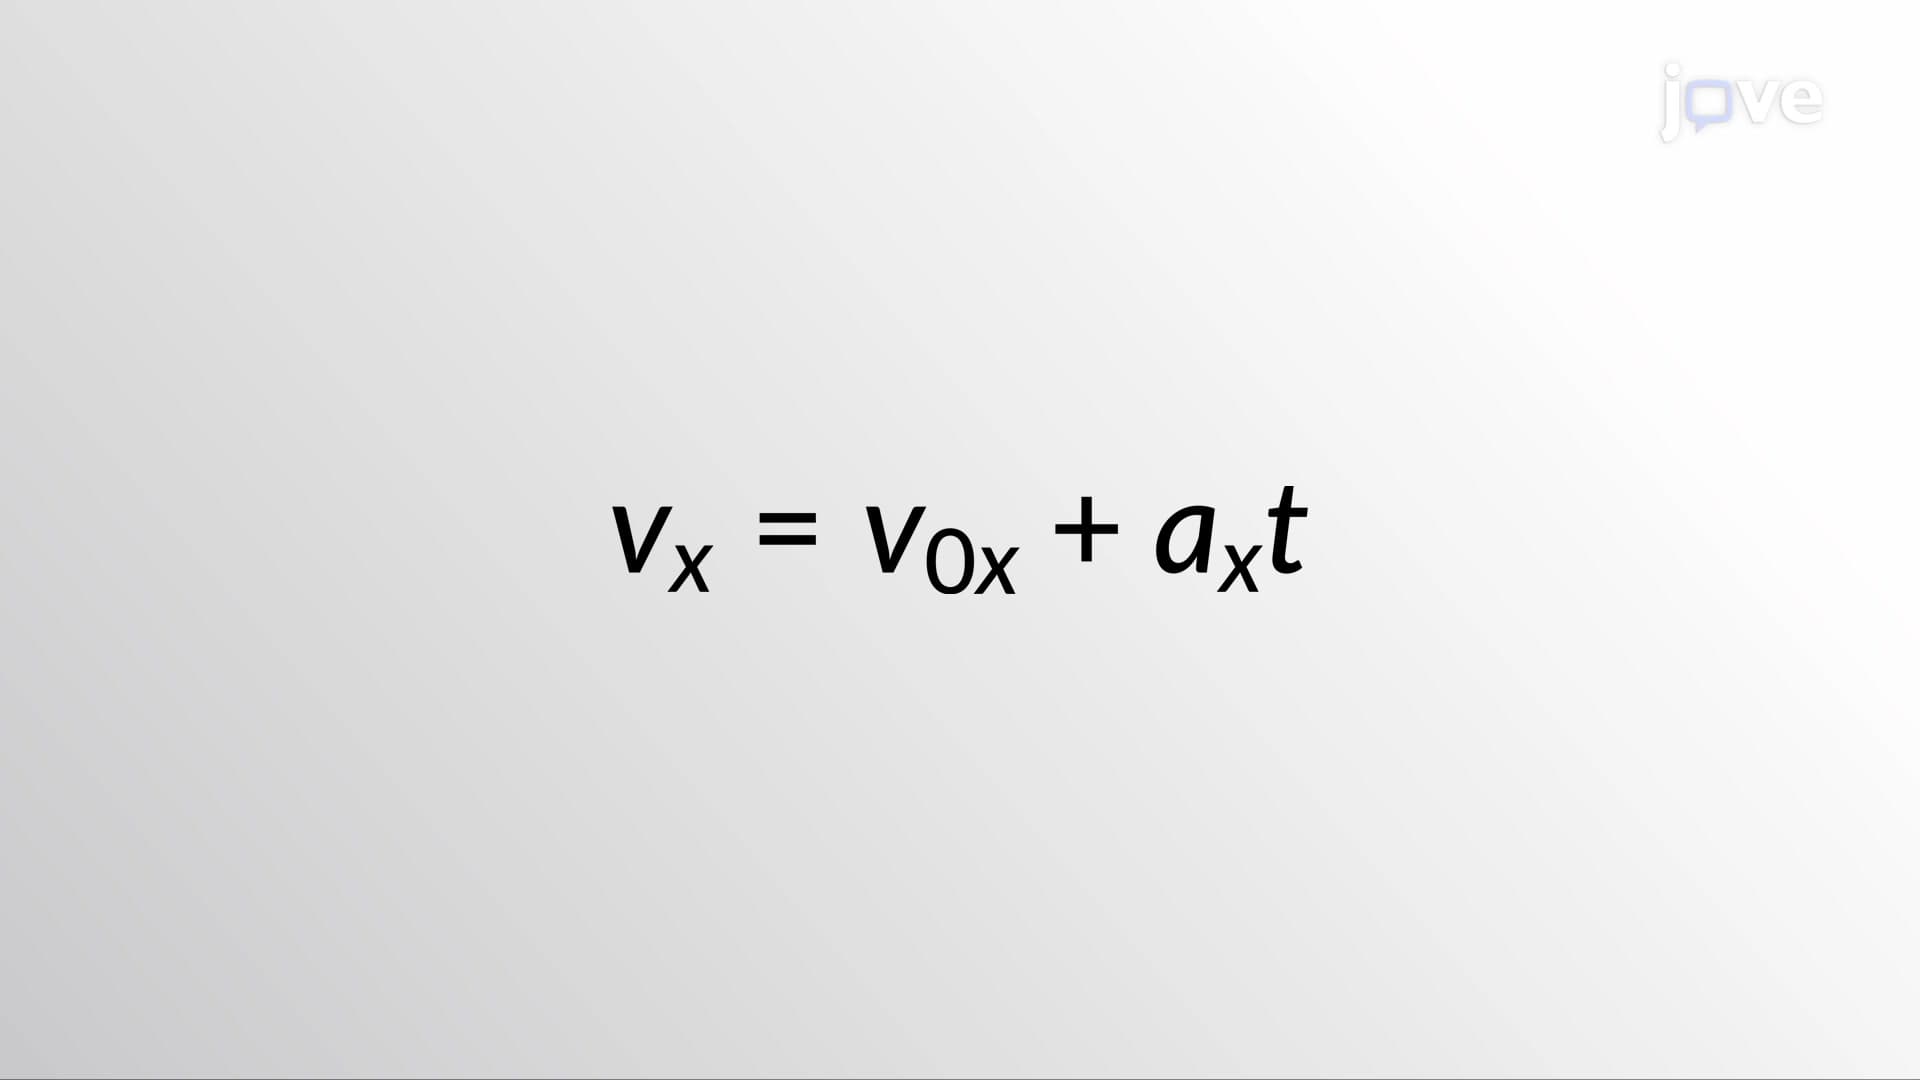 01:26
Kinematic Equations - I
11.9K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
11.9K
 01:18
Kinematic Equations - III
8.4K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
8.4K