

从肌肉作用对基于四边形的肌肉骨模型的力效应的计算
Ondrej Zoufaly1, Edward K Chadwick2, Dimitra Blana3
1Czech Technical University in Prague, Department of Mechanics, Biomechanics and Mechatronic, Technicka 1902/4, Prague 6, 16000, Czech Republic.
Journal of biomechanics
|August 22, 2025

概括
这项研究为肌肉激活的肌肉骨模拟提供了一个基于四边形的框架,克服了欧勒角常见的关锁问题. 它可以为复杂的关节运动提供更准确的动态模型.
科学领域:
- 生物力学
- 肌肉骨模型
- 计算动力学
背景情况:
- 欧勒和卡丹角在生物力学中描述关节旋转是常见的,但受到关锁奇点的影响.
- 四边形避免关锁,但不那么直观,并且在复杂的动态肌肉骨模型中没有广泛采用.
- 现有的动态模型难以直观地表现肌肉动作,特别是在具有复杂动力学的模型中.
研究的目的:
- 引入基于四次数的动态肌肉骨模拟的数学框架.
- 开发一个用于估计肌肉扭矩的方法.
- 为了促进肌肉运动臂从传统的角度系统转变为四边形.
主要方法:
- 开发了一种基于四次数的肌肉动作描述的新数学框架.
- 估计的肌肉扭矩使用拟议的基于四的肌肉骨模型.
- 在3D双摆形系统上演示了该方法,其中包括肌肉元件和转换时刻臂.
主要成果:
- 成功实施基于四次数的动态肌肉骨模拟方法.
- 这种方法有效地估计肌肉扭矩,避免关锁问题.
- 证明了肌肉运动臂从欧勒/卡丹角度转变为四次方.
结论:
- 拟议的基于四次元的方法为动态肌肉骨建模提供了有利的替代方案.
- 这种方法对具有复杂动力学和大关节范围的模型特别有益,例如肩膀.
- 该框架提高了生物力学动态模拟的准确性和适用性.
相关概念视频
 01:13
Kinetic Energy for a Rigid Body
297
Imagine a solid object involved in a general planar movement, with its center of mass pinpointed at a spot labeled G. The object's kinetic energy relative to an arbitrary point A can be quantified for each of its particles - the ith particle in this case. This measurement is achieved through the employment of the relative velocity definition. The position vector, known as rA, extends from point A to the mass element i.
297
 01:12
Equation of Motion for a Rigid Body
358
The movement of a rigid object can be understood through the equations that explain both translational and rotational motion about the center of mass of the object, point G. This center of mass is the point where the equation of motion for translational motion comes into play, as per Newton's Second Law.
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
358
 01:30
Three-Dimensional Force System
2.3K
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
2.3K
 01:26
Frames: Problem Solving II
287
Consider a hydraulic hoist supporting a load of 1 kN. Assuming a simplified schematic representation of this frame structure, the force acting on BD and BF members can be determined.
287
 01:10
Second Law: Motion under Same Force
5.6K
Newton's laws can be applied to bodies at rest and bodies in motion. Newton's first law is applied to bodies in equilibrium, whereas the second law applies to accelerating bodies. To study accelerating bodies, first, the directions and magnitudes of acceleration and the applied forces are determined. Then, the free-body diagram is constructed, and Newton's second law is applied, considering the components of the forces in the x and y directions.
Let's imagine a person is...
Let's imagine a person is...
5.6K
 01:17
Central-Force Motion
333
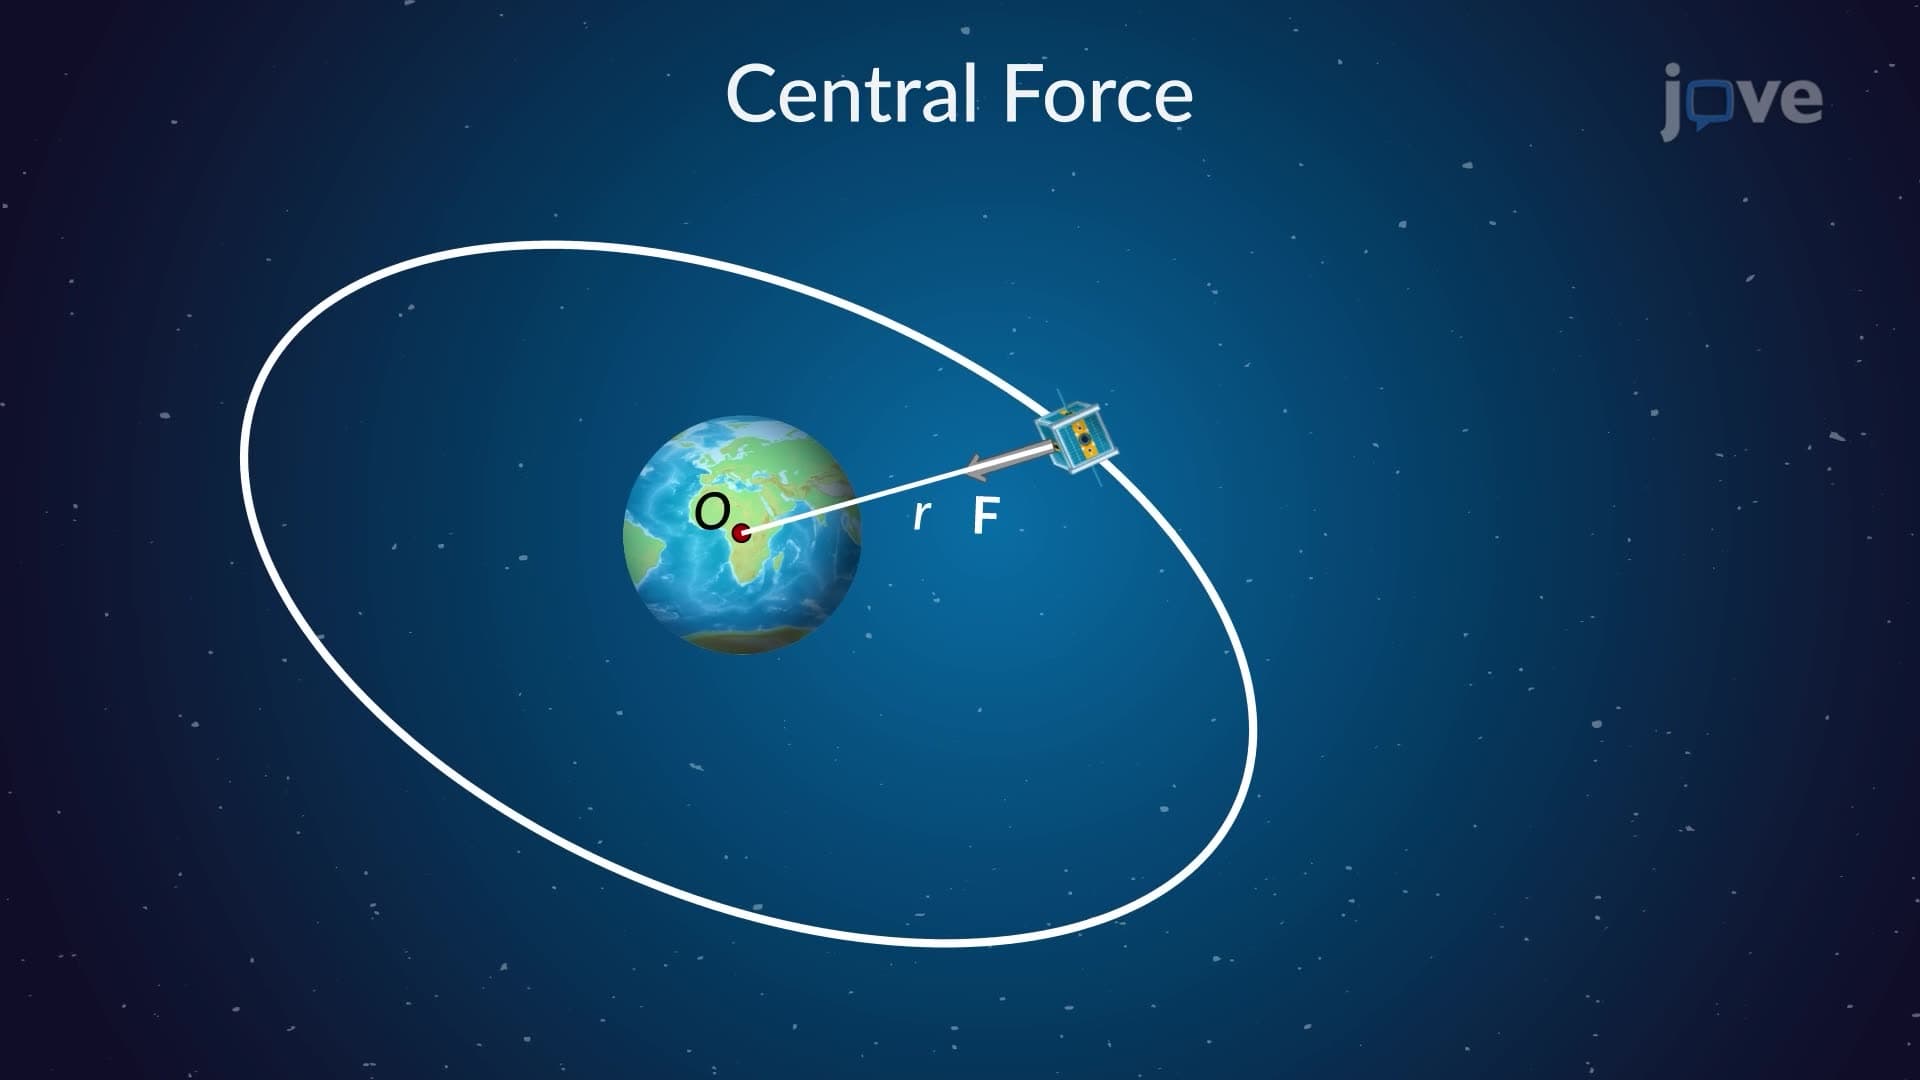
The central force system operates by exerting a force on an object directed towards a fixed point, typically the origin, with the force magnitude determined by the object's distance from this fixed point. In the context of an object with mass 'm,' polar coordinates are employed to express the equation of motion. Notably, the azimuthal component of force is nonexistent in this system. A comprehensive rewrite and integration of this equation reveal that the product of the squared...
333