

基于估计器的非线性系统的第二阶梯滑动模式控制设计,输入延迟不明
IEEE transactions on cybernetics
|August 26, 2025

概括
这项研究引入了一种新型的第二阶滑动模式 (SOSM) 控制器,用于具有未知的输入延迟和不确定性的非线性系统. 新的控制器提高了稳定性和性能,
科学领域:
- 控制系统工程
- 非线性系统动力学
- 机器人和自动化
背景情况:
- 滑动模式控制器 (SMC) 对于非线性系统是有效的,但与输入延迟和不确定性作斗争.
- 现有的二级滑动模式 (SOSM) 控制器在处理未知的输入延迟和功能有限的不确定性方面面临挑战.
- 由于SMC的不连续性使得延迟补偿机制的整合变得复杂.
研究的目的:
- 为未知输入延迟的不确定非线性系统开发基于估计器的二级滑动模式 (SOSM) 控制器.
- 解决现有的SOSM方法在处理未知的输入延迟和功能有限的不确定性方面的局限性.
- 确保闭环控制系统的有限时间稳定性.
主要方法:
- 已确定的SOSM动态包括输入延迟和不确定性.
- 引入了辅助补偿系统和基于凸式优化的输入延迟估计器.
- 使用功率集成器技术设计了一种基于估计器的SOSM控制器,并通过利亚普诺夫分析验证了稳定性.
主要成果:
- 成功设计了一个与不连续控制器兼容的输入延迟估计器.
- 开发了一个新的SOSM控制器,有效地弥补了未知的输入延迟.
- 通过严格的莱普诺夫分析证明了闭环系统的有限时间稳定性.
- 进行比较的模拟证实了SOSM控制器的优越性能.
结论:
- 拟议的基于估计器的SOSM控制器有效处理具有未知的输入延迟的不确定非线性系统.
- 这种新方法提供了可靠的控制,并保证了有限时间的稳定性.
- 这种方法对复杂系统的现有SOSM控制策略提供了显著的进步.
更多相关视频
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
8.7K
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
5.0K
相关概念视频
 01:18
Second Order systems II
171
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
171
 01:20
Second Order systems I
233
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
By reinterpreting the system, one can derive the closed-loop transfer function, which...
233
 01:21
Linear Approximation in Time Domain
124
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
124
 01:21
First Order Systems
162
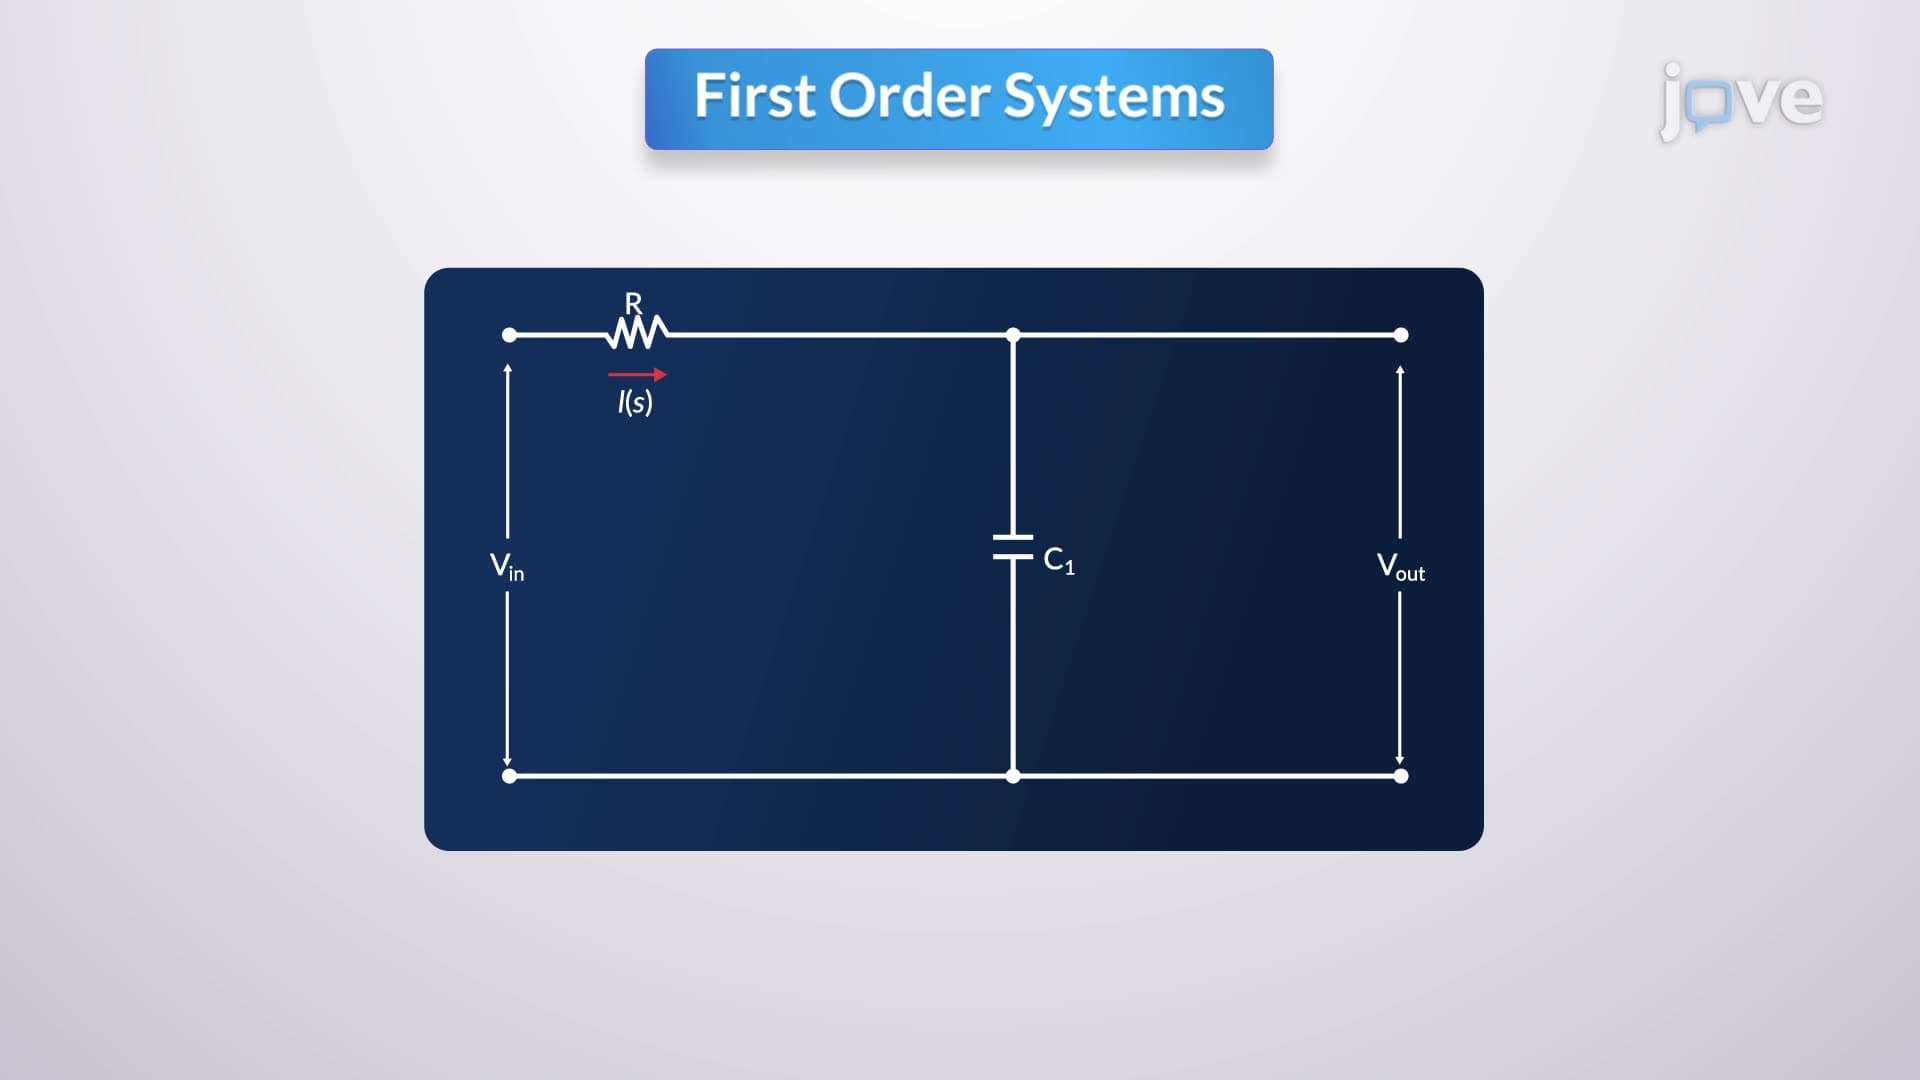
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
162
 01:26
PD Controller: Design
349
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
349
 01:26
Feedback control systems
419
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
419