相关实验视频
Updated: May 3, 2026
07:51

Video Movement Analysis Using Smartphones ViMAS: A Pilot Study
Published on: March 14, 2017
16.9K
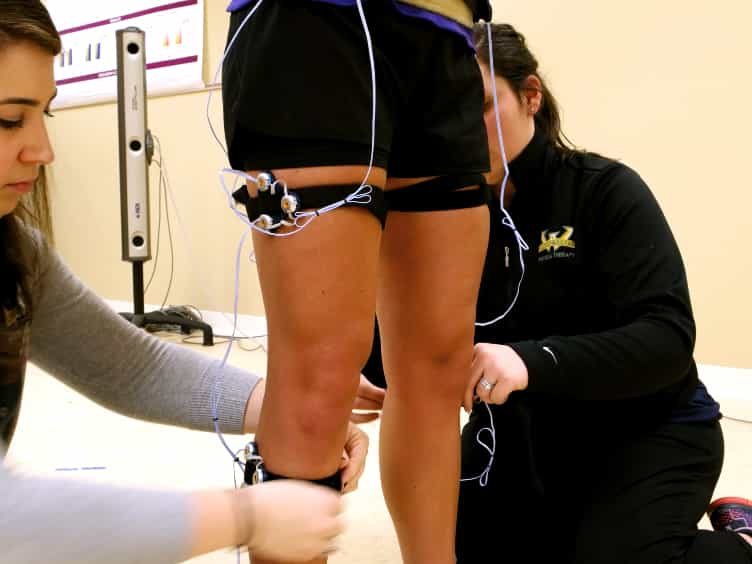
在非特异性慢性腰部疼痛子组中向前曲时基于轨迹的脊柱动力学分析:智能手机2D视频跟踪
Hwa-Ik Yoo1, Il-Kyu Ahn1, Oh-Yun Kwon1
1Department of Physical Therapy, College of Software and Digital Healthcare Convergence, Yonsei University, Wonju-si, Gangwon-do, the Republic of Korea.
Journal of back and musculoskeletal rehabilitation
|August 29, 2025

概括
智能手机视频分析显示非特异性慢性腰部疼痛 (NSCLBP) 亚组中明显的脊柱运动模式. 延伸模式 (EP) 组表现出比曲模式 (FP) 和健康组更大的水平移位.
科学领域:
- 生物力学
- 脊柱运动学
- 数字健康
背景情况:
- 对非特异性慢性腰部疼痛 (NSCLBP) 的传统运动范围测量缺乏详细的方向洞察力.
- 了解胸脊运动模式对于有针对性的NSCLBP评估至关重要.
研究的目的:
- 在向前曲时分析胸 (T12,L2) 的水平和垂直移位.
- 为了比较NSCLBP子组 (屈曲模式[FP],延伸模式[EP]) 和健康对照组之间的脊柱运动.
- 评估基于智能手机的2D视频分析以评估NSCLBP动力学.
主要方法:
- 分析了185名参与者 (58名健康人,87名FP,40名EP).
- 通过智能手机2D视频分析 (Kinovea软件) 追踪T12和L2状过程的标记物.
- 量化了前后 (x轴) 和上下 (y轴) 的位移.
主要成果:
- 与FP组相比,EP组在T12和L2的前部位移显著增加.
- 在EP组的L2前部位移比健康对照组更大.
- 没有观察到垂直移位或FP与健康组之间的显著差异.
结论:
- 横向移动轨迹有效地区分NSCLBP子组,特别是EP组的独特移动策略.
- 基于智能手机的视频分析为特定小组的NSCLBP评估提供了可访问和潜在的临床价值工具.
相关概念视频
 01:24
Relative Motion Analysis - Velocity
975
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
975
 01:25
Relative Motion Analysis using Rotating Axes
1.0K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
1.0K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
839
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
839
 01:10
Relative Motion Analysis - Acceleration
1.1K
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
1.1K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
1.0K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
1.0K