使用追踪图像梯度向量从运动中感知非刚性结构
Hiroshige Takeichi1,2, Wataru Suzuki1,3, Wakayo Yamashita4
1Open Systems Information Science Special Team, Predictive Medicine Special Project (PMSP), RIKEN Center for Integrative Medical Sciences (IMS), RIKEN, Yokohama, Kanagawa, Japan.
Frontiers in psychology
|September 11, 2025

概括
流体运动的伪流 (p-流) 可视化允许比传统方法更可靠的粘度估计. 这种技术增强了从视觉输入中对非刚性运动和物理属性的感知.
科学领域:
- 计算机视觉 计算机视觉 计算机视觉
- 人类的感知人类的感知.
- 流体动力学 流体动力学
背景情况:
- 人类感官系统从视觉运动中感知诸如粘度之类的物理性质的能力尚未完全被理解.
- 伪流 (p-flow) 算法可以表示图像梯度以可视化非刚性运动.
研究的目的:
- 调查人类感官系统是否可以从p流可视化中确定液体粘度.
- 为了比较p-flow的可靠性和效率与Lucas-Kanade方法用于粘度感知.
主要方法:
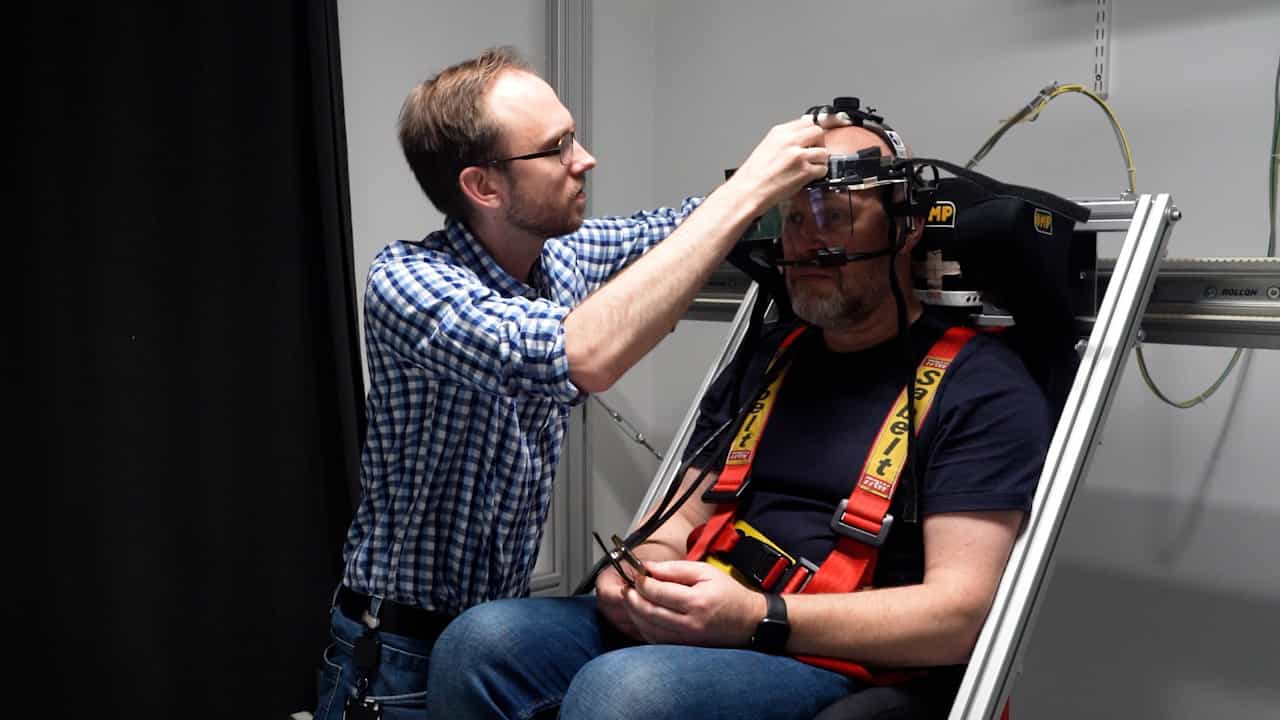
- 使用p-flow和Lucas-Kanade方法生成了具有不同粘度的液体的计算机动画电影.
- 向312名参与者展示了这些点光显示电影,以估计粘度.
主要成果:
- 使用p流的参与者显示响应时间显著缩短,粘度等级的变化较小,与卢卡斯-卡纳德方法相比.
- 在使用p流可视化时,粘度估计的误差减少了.
结论:
- 伪流 (p-flow) 提高了人类从视觉运动感知粘度的可靠性.
- 在p流算法中固有的局部约束可能有助于提高在估计物理流体属性的精度.
相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
883
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
883
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
705
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
705
 01:23
Curvilinear Motion: Rectangular Components
1.1K
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
1.1K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
755
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
755
 01:24
Absolute Motion Analysis- General Plane Motion
540
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
540
 01:27
Curvilinear Motion: Normal and Tangential Components
832
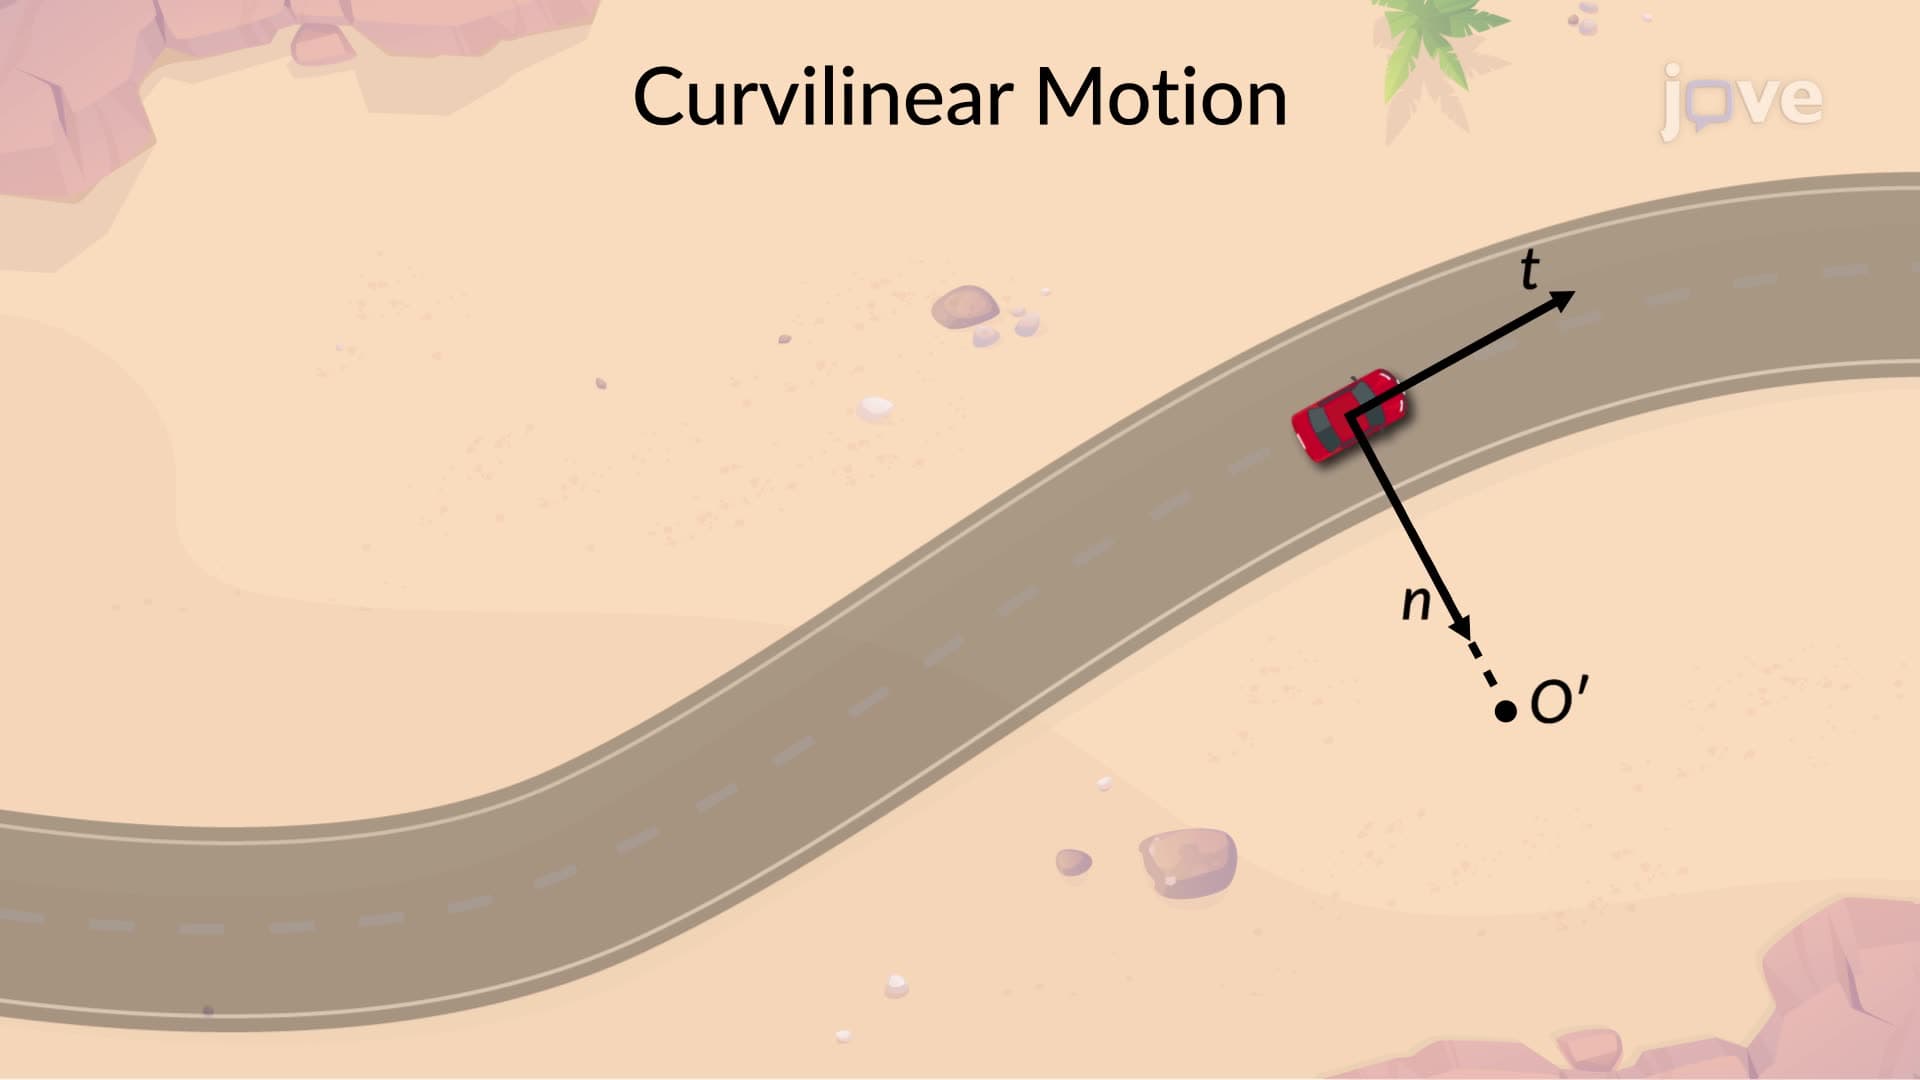
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
832