相关实验视频
Updated: Jan 17, 2026

10:09

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
7.1K
研究基于狗腿和PSONN算法的机器人定位错误补偿算法
1School of Instrument Science and Opto-electronic Engineering, Hefei University of Technology, Hefei, China.
PloS one
|September 16, 2025

概括
本研究介绍了一种工业机器人错误补偿算法,它结合了动力学校准和先进的预测方法. 这种新的方法显著提高了机器人的定位精度,并减少了定位错误.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 机器学习 机器学习
背景情况:
- 与重复任务相比,工业机器人具有较低的绝对定位精度.
- 现有的算法经常受到低准确度或局部最佳问题的影响.
研究的目的:
- 为工业机器人提出一个先进的错误补偿算法.
- 为了提高工业机器人的绝对定位精度.
主要方法:
- 使用增强的狗腿算法对动力参数进行校准.
- 使用粒子集群优化神经网络 (PSONN) 进行奇点错误预测.
- 通过空间网格多点插值 (SGMI) 计算定位错误.
主要成果:
- 动力学校准将定位误差从3.158毫米减少到0.406毫米.
- SGMI补偿进一步降低了定位误差到0.0685毫米.
- 该算法有效校准了动力学参数并降低了不确定性.
结论:
- 拟议的算法将传统的解释性与神经网络非线性相结合.
- 它成功地解决了传统方法和神经网络的局限性.
- SGMI算法显著提高了工业机器人的定位准确度.


相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
704
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
704
 01:03
Centroid of a Body: Problem Solving
1.8K
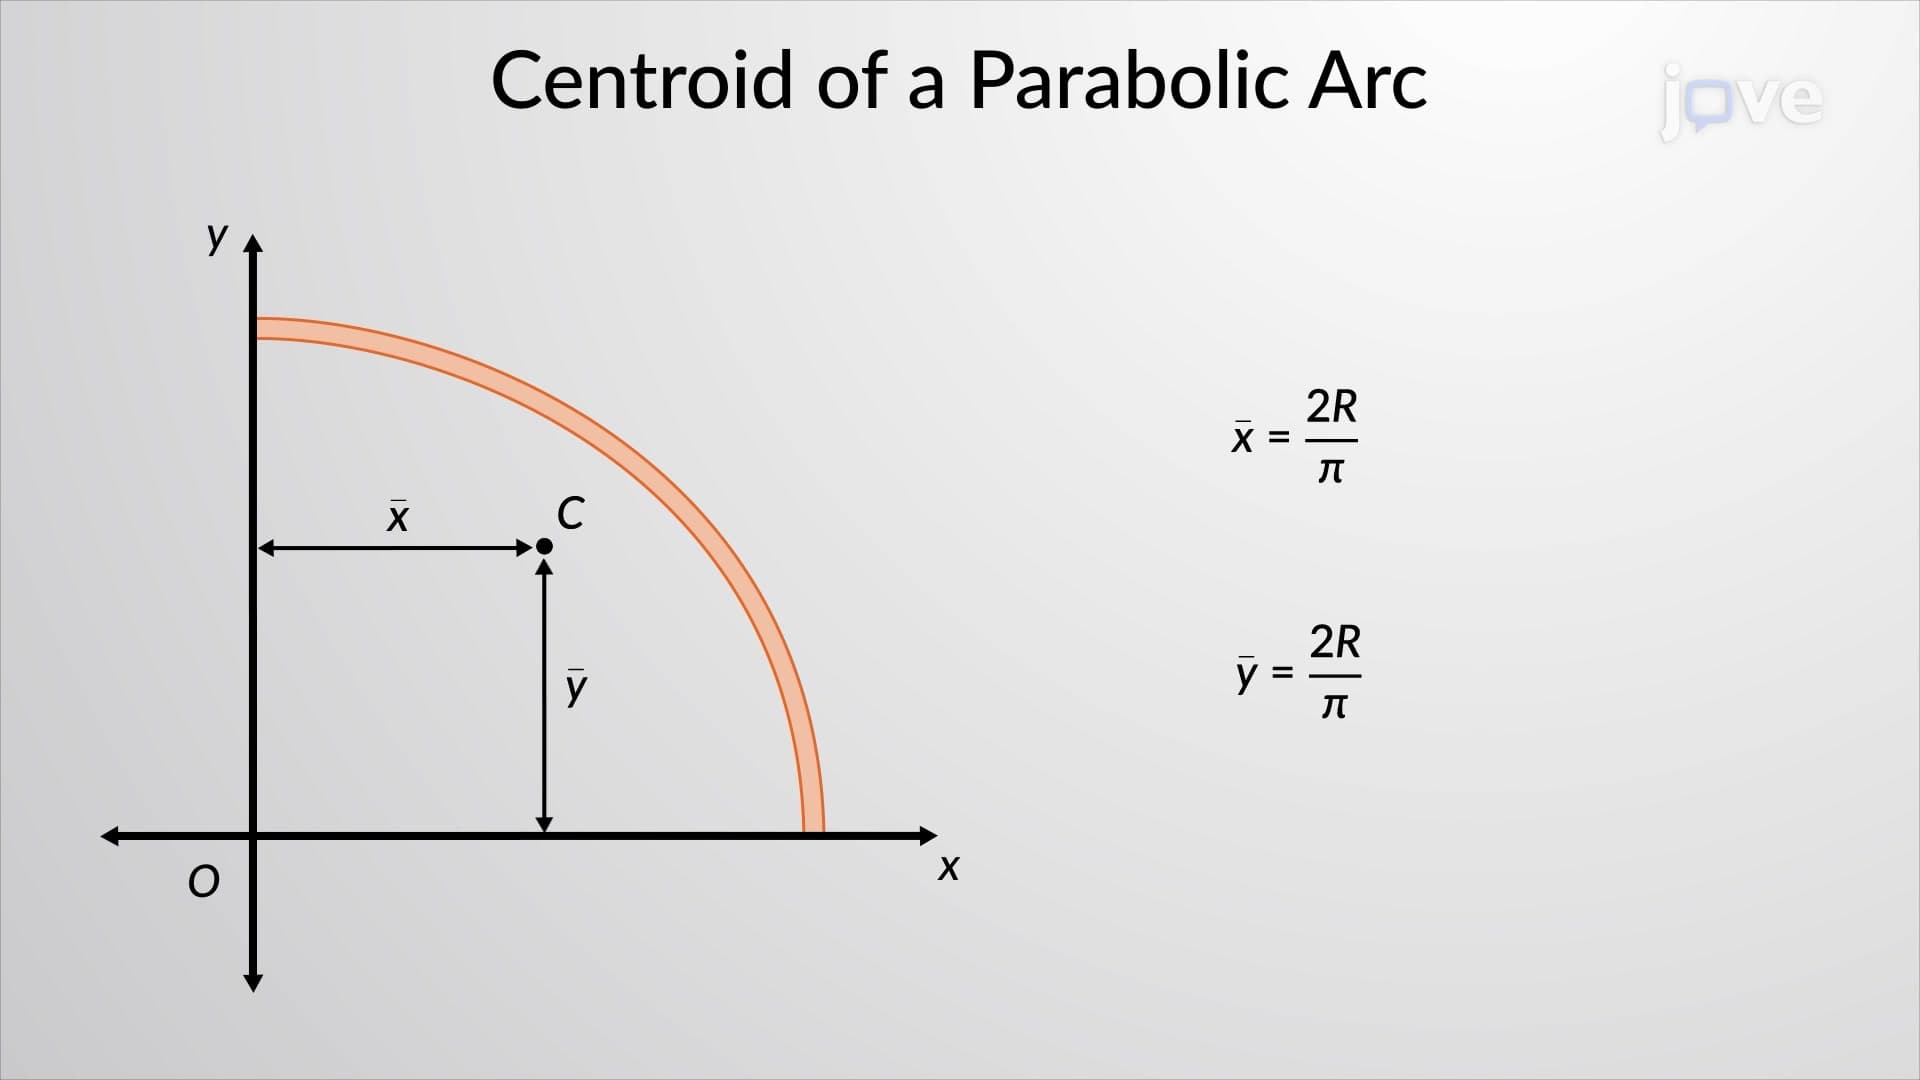
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.8K
 01:15
Kinematic Equations: Problem Solving
27.3K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
27.3K
 01:25
Relative Motion Analysis using Rotating Axes
881
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
881
 01:24
One-Degree-of-Freedom System
808
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
808
 01:07
Time-Domain Interpretation of PD Control
377
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
377