相关实验视频
Updated: Jan 17, 2026

08:12

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
10.0K
在存在系统不确定性的情况下,基于高斯回归器的外骨架关节的自适应控制
Mohamed Abdelhady1, Thomas C Bulea1
1Rehabilitation Medicine Department, National Institutes of Health Clinical Center, Bethesda, MD, USA.
Wearable technologies
|September 19, 2025

概括
基于高斯的自适应控制 (GBAC) 有效地管理下肢外骨架的不确定性. 这种适应性控制方法可以提高跟踪性能和融合速度,这对于临床应用至关重要.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 生物力学 生物力学
背景情况:
- 系统的不确定性给下肢外骨控制带来了挑战,特别是在临床环境中.
- 适应性控制策略可以实时处理未知的系统动态.
- 现有的控制方法可能会与患者群体固有的变异性作斗争.
研究的目的:
- 介绍和评估基于高斯的适应控制 (GBAC) 对于外骨应用.
- 在系统不确定性下,评估GBAC与已建立的控制器的性能.
- 研究GBAC在模拟和实验外骨架设置中的有效性.
主要方法:
- 使用拉格朗日力学开发了一个基于高斯的自适应控制 (GBAC) 算法.
- 进行了2-DOF模拟,比较GBAC与强大的自适应后退,Slotine-Li和PID控制器.
- 在膝关节外骨架上进行了1-DOF模拟和实验测试,以评估在干扰和不确定性下的性能.
主要成果:
- GBAC展示了优越的跟踪性能和在模拟中更快的融合,特别是在增加干扰和参数不确定性的情况下.
- 实验结果显示,GBAC和Slotine-Li提供了稳定的跟踪,GBAC表现出更快的收和更低的跟踪误差.
- 在处理未建模的系统动态和参数变化方面,GBAC被证明是有效的.
结论:
- GBAC是一种有前途的适应性控制策略,用于面临系统不确定性的下肢外骨架.
- 控制器的实时适应能力使其适用于灵活的关节外骨架.
- GBAC需要进一步的研究,以便在儿科和临床群体中应用,系统变异性很高.


相关概念视频
 01:24
One-Degree-of-Freedom System
808
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
808
 01:17
Open and closed-loop control systems
1.6K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.6K
 01:26
Feedback control systems
687
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
687
 01:21
Rigid Body Equilibrium Problems - II
7.9K
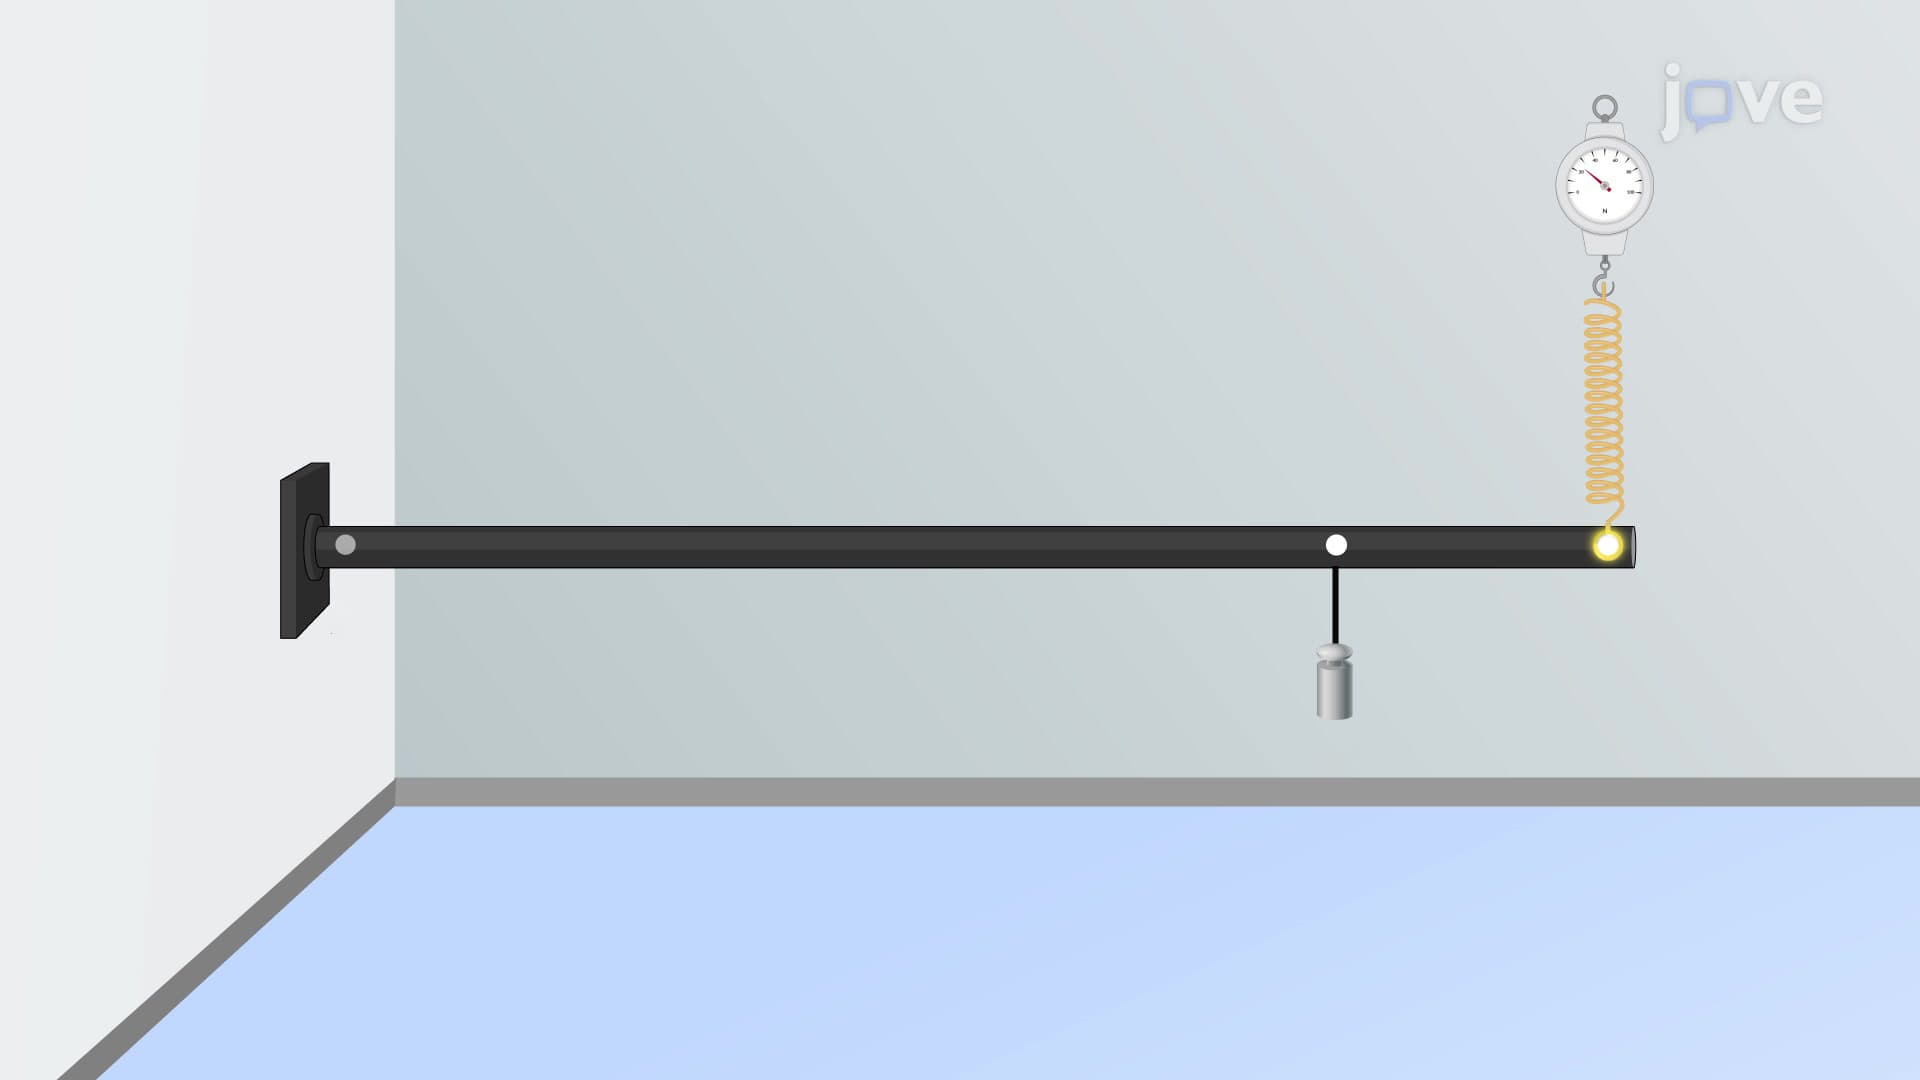
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.9K
 00:49
Rigid Body Equilibrium Problems - I
5.4K
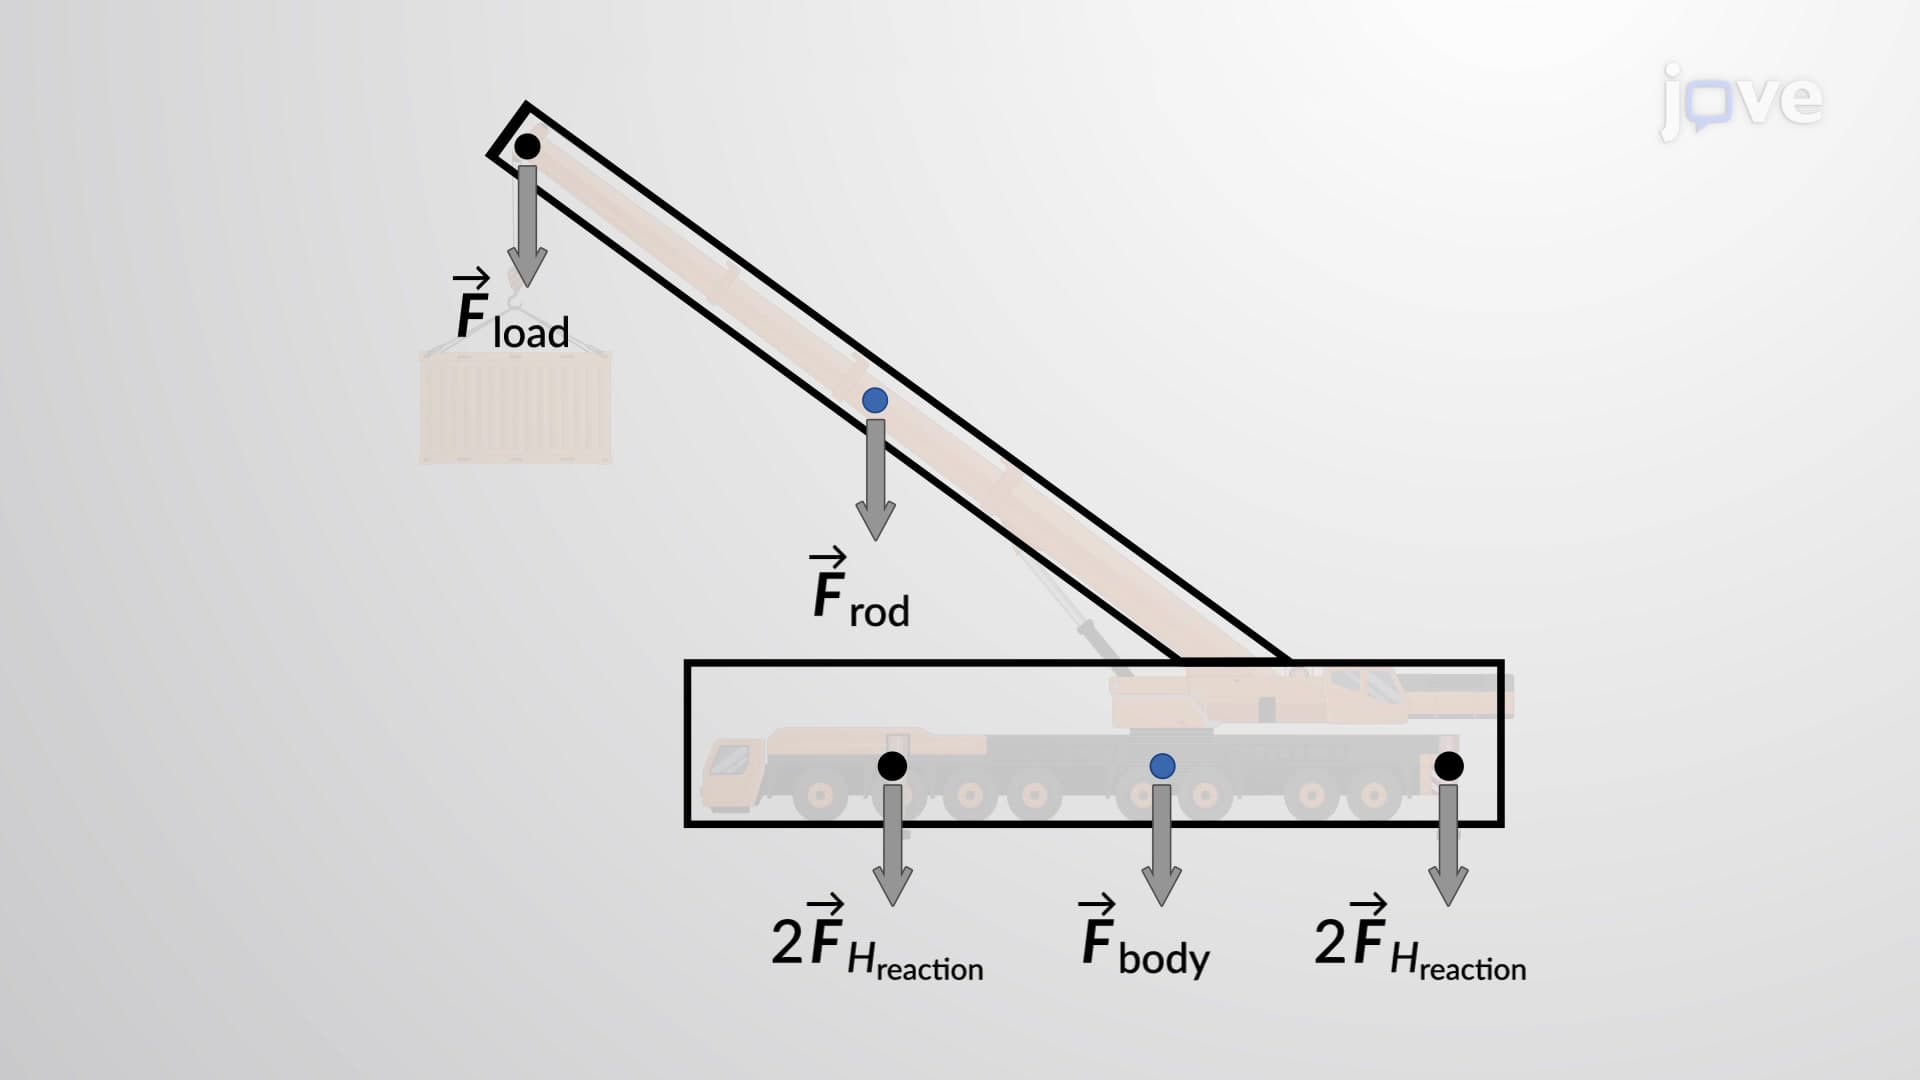
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
5.4K
 01:15
Kinematic Equations: Problem Solving
27.3K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
27.3K