
概括
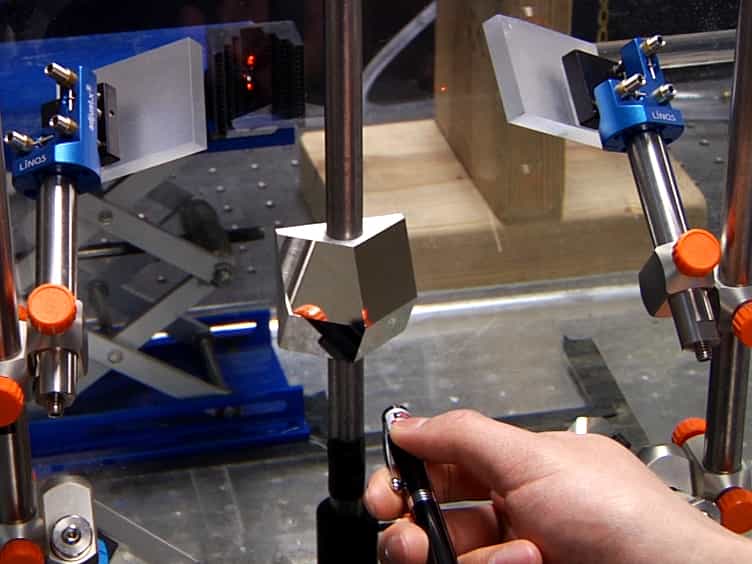
这项研究引入了一种混合方法,用于预测卫星到地面激光通信中的光点位置. 功能匹配的反复预测 (FMRP) 方法提高了指向,采集和跟踪 (PAT) 系统的稳定性,而不需要大量的数据或离线训练.
科学领域:
- 光学工程是指光学工程.
- 激光通信是一种激光通信.
- 大气物理学 大气物理学
背景情况:
- 大气动荡对卫星到地面激光通信 (SGLC) 系统的稳定性和准确性构成重大挑战.
- 指向,获取和跟踪 (PAT) 系统对于保持稳定的联系至关重要,但对大气干扰非常敏感.
- 现有的深度学习方法通常需要大量的数据集和离线培训,这限制了它们的实时适用性.
研究的目的:
- 开发一种新的混合方法,用于预测SGLC中光点的中心位置.
- 为了提高PAT系统在大气流下的准确性和稳定性.
- 为了创建一个有效地实时运行的方法,只使用接收的现场图像.
主要方法:
- 开发了一种名为特征匹配反复预测 (FMRP) 的混合方法.
- FMRP使用一个循环神经网络 (RNN) 架构.
- 用特征匹配来优化对RNN的输入特征和标签的获取.
主要成果:
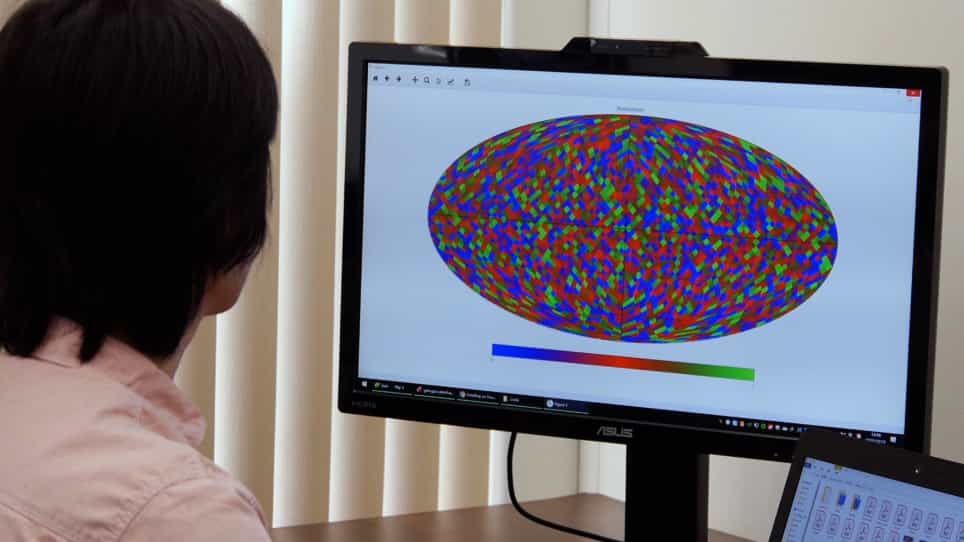
- 该FMRP方法准确地预测光点位置实时使用仅接收的点图像.
- 该方法消除了线下培训和大数据集收集的需要.
- 实验验证证了FMRP在弱大气动荡和强大大气动荡下的有效性,证明了高预测准确性和稳定性.
结论:
- 拟议的FMRP方法为提高SGLC中PAT系统性能提供了一个强大的解决方案.
- 它的实时预测能力不需要广泛的培训,使其对操作系统非常实用.
- FMRP有效地减轻了大气流的影响,提高了通信链路的可靠性.
相关概念视频
 04:08
The Uncertainty Principle
31.3K
Werner Heisenberg considered the limits of how accurately one can measure properties of an electron or other microscopic particles. He determined that there is a fundamental limit to how accurately one can measure both a particle’s position and its momentum simultaneously. The more accurate the measurement of the momentum of a particle is known, the less accurate the position at that time is known and vice versa. This is what is now called the Heisenberg uncertainty principle. He...
31.3K
 01:29
Application of Linearization and Approximation
53
A drone flying through complex terrain often relies on more than one sensing method to estimate small changes in altitude. Along with direct measurements, air pressure provides a useful indirect indicator of vertical movement. Atmospheric pressure decreases as altitude increases, and this relationship is commonly described using an exponential model. Although accurate, converting pressure measurements into altitude values requires calculations that are too complex to perform repeatedly during...
53
 01:20
Maxwell-Boltzmann Distribution: Problem Solving
2.8K
Individual molecules in a gas move in random directions, but a gas containing numerous molecules has a predictable distribution of molecular speeds, which is known as the Maxwell-Boltzmann distribution, f(v).
This distribution function f(v) is defined by saying that the expected number N (v1,v2) of particles with speeds between v1 and v2 is given by
This distribution function f(v) is defined by saying that the expected number N (v1,v2) of particles with speeds between v1 and v2 is given by
2.8K
 01:20
Instantaneous Center of Zero Velocity
809
General plane motion, often observed in a rolling wheel, refers to a type of movement where the wheel is simultaneously rotating and translating. This complex motion can be understood by breaking it down into individual components.
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
809
 01:03
Center of Mass: Introduction
22.0K
Any object that obeys Newton's second law of motion is made up of a large number of infinitesimally small particles. Objects in motion can be as simple as atoms or as complex as gymnasts performing in the Olympics. The motion of such objects is described about a point called the center of mass of the object. The center of mass of an object is a point that acts as if the whole mass is concentrated at that point. The center of mass of an object with a large number of infinitesimally small...
22.0K
 01:26
Influence of Earth's Curvature and Atmospheric Refraction on Leveling
881
During leveling, the Earth's curvature and atmospheric refraction introduce deviations in the line of sight from a true horizontal reference. When the line of sight is leveled, it remains perpendicular to the plumb line only at a single point. Beyond this, it deviates due to the Earth’s curvature, represented by the correction C. For a sight distance D, the deviation can be derived using the relationship:This relationship shows that the deviation increases quadratically with distance. Over a...
881