

弥合惯性传感器和光学运动捕捉之间的方法差距:深度学习作为使用惯性传感器准确联合动力学建模的途径
Vaibhav R Shah1,2, Philippe C Dixon1,2,3
1Institute of Biomedical Engineering, Faculty of Medicine, University of Montreal, Montreal, QC H3T 1J4, Canada.
Sensors (Basel, Switzerland)
|September 27, 2025

概括
本研究引入了一种深度学习方法,用于使用惯性测量单元 (IMU) 数据预测光学运动捕捉标记位置. 这使得传统的生物力学分析能够在实验室外进行准确的运动跟踪.
科学领域:
- 生物力学 生物力学
- 机器学习 机器学习
- 可穿戴技术可穿戴技术
背景情况:
- 光学运动捕捉 (OMC) 拥有数十年的研究经验,但需要控制的环境.
- 惯性测量单元 (IMU) 提供便携式运动分析,但缺乏直接应用OMC方法.
- 弥合这一差距对于将已建立的生物力学模型应用于IMU数据至关重要.
研究的目的:
- 开发一种深度学习方法,从IMU数据中预测标记物位置.
- 为了使传统的基于OMC的联合动力学计算能够使用IMU数据.
- 在外部数据集上验证拟议方法的通用性.
主要方法:
- 使用了一个自动编码器网络,具有自定义的生物机械损失功能.
- 从7个IMU传感器数据中预测了16个标记位置.
- 通过离开一个主体的交叉验证进行验证,并对外部数据集进行了测试.
主要成果:
- 标记器位置预测实现了2-4厘米的根平均平方误差 (RMSE).
- 射手平面关节角度预测产生了4-7°RMSE,没有动态时间扭曲 (DTW) 调整.
- 通过DTW对齐实现了2-4° RMSE,在多个数据集中保持一致.
结论:
- 深度学习方法成功地弥合了IMU和OMC之间的差距.
- 能够使用IMU进行准确的关节动力学估计和运动分析.
- 为便于将已确定的生物力学方法应用于便携式运动分析系统.
相关概念视频
 01:15
Kinematic Equations: Problem Solving
27.3K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
27.3K
 01:17
Kinematic Equations - II
13.0K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
13.0K
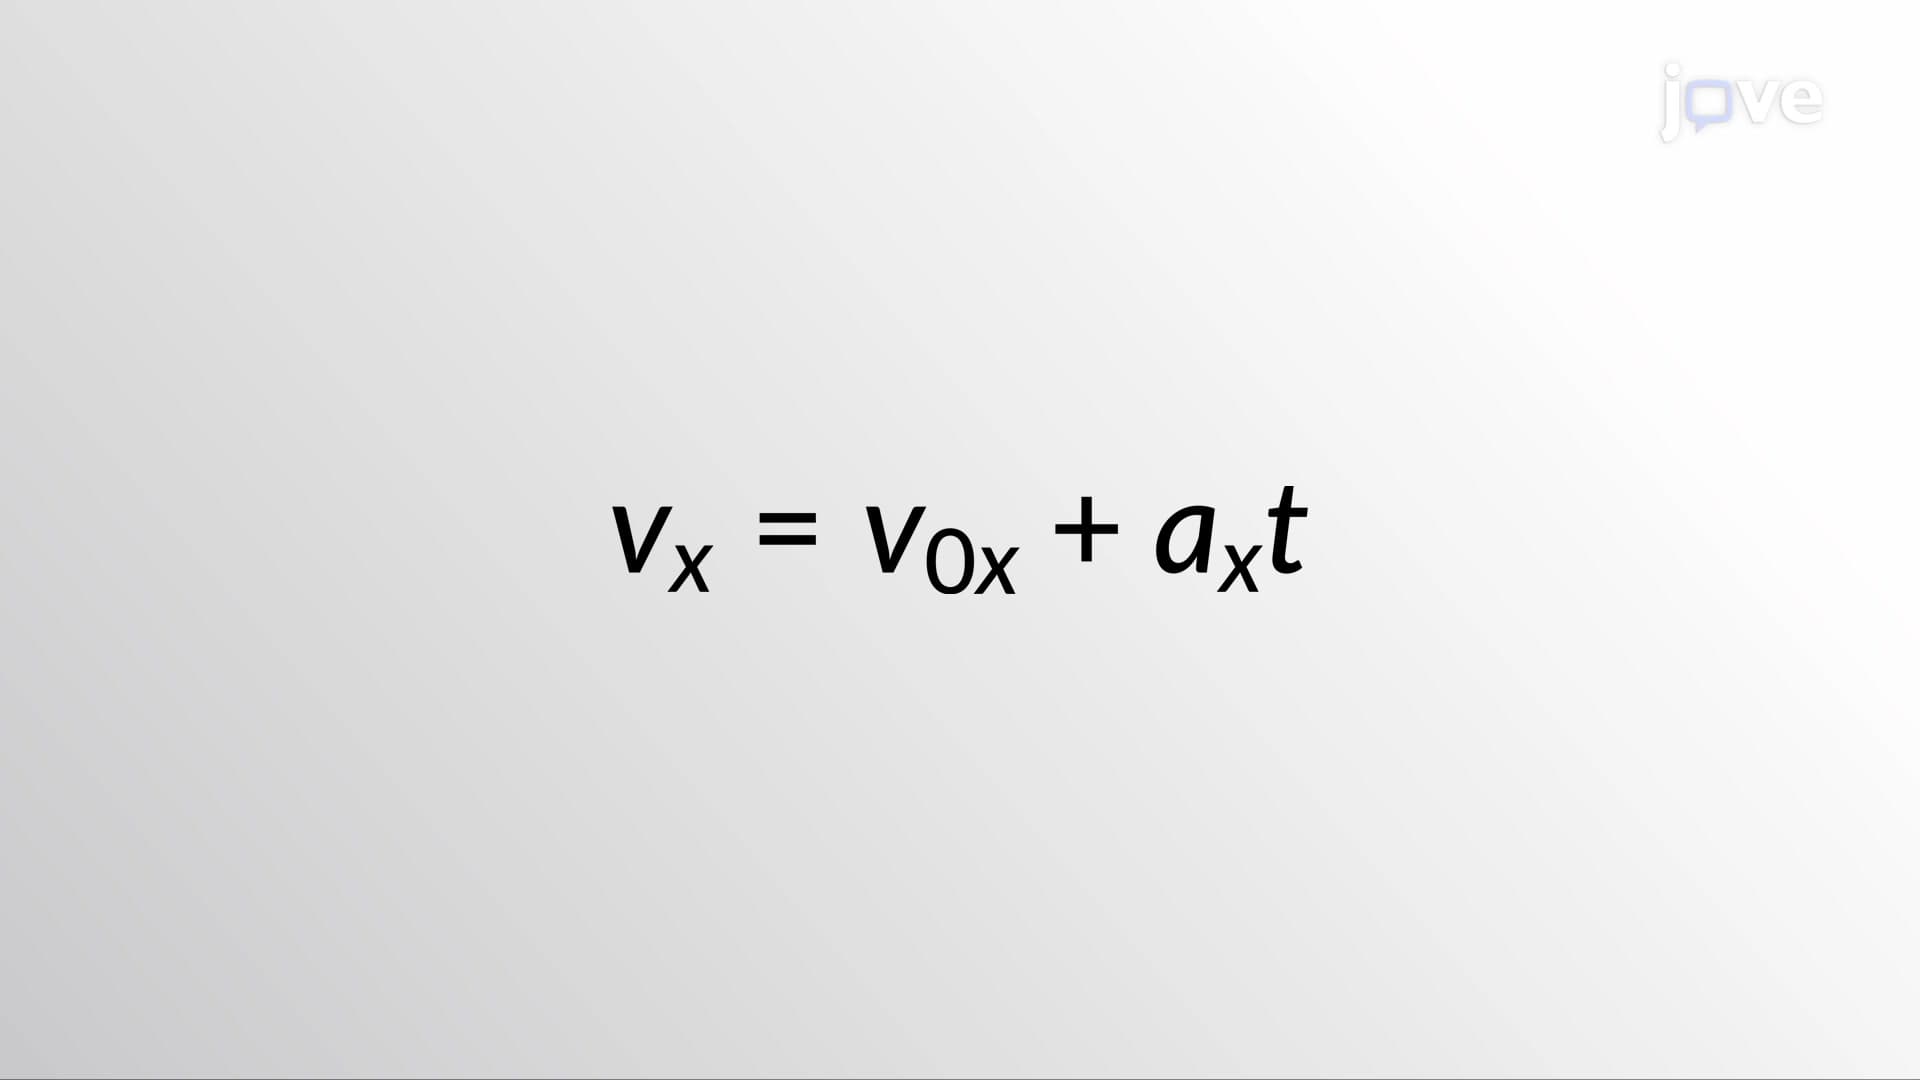 01:26
Kinematic Equations - I
14.3K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
14.3K
 01:18
Kinematic Equations - III
10.3K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
10.3K
 01:30
Kinematic Equations for Rotation
763
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
763
 01:25
Relative Motion Analysis using Rotating Axes
880
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
880