

优化了模块化机器人的用户引导运动控制
Anastasia Bolotnikova1,2, Kevin Holdcroft1, Henry Cerbone1
1Reconfigurable Robotics Lab, Ecole Polytechnique Fédérale de Lausanne (EPFL), Lausanne, Switzerland.
Nature communications
|September 30, 2025

概括
这项研究介绍了一种用于控制自我重新配置模块化机器人的新平台. 它允许用户安全地引导具有不断变化的形状和尺寸的机器人集体,提高复杂任务的适应性.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人与机器人的交互
- 控制系统 控制系统
背景情况:
- 模块化机器人提供了适应性,但在重新配置期间在运动控制方面面临挑战.
- 现有的方法限制了适应性,因为它依赖于预先编程的知识来改变机器人结构.
研究的目的:
- 为可自我重新配置的模块化机器人开发一个用户引导的控制平台.
- 为了能够安全和直观地控制动态变化的机器人集体.
主要方法:
- 实现了用户命令在线处理的优化方案,确保约束满足.
- 引入了联合空间操纵杆,这是一个适应机器人形态的物理接口,用于直接的用户控制.
主要成果:
- 通过物理接口展示了模块化,改变形状的机器人的安全控制.
- 在各种形态 (Mori3,Roombots) 和任务 (接送,移动,工作空间扩展) 中验证了平台的有效性和通用性.
结论:
- 拟议的平台提高了模块化机器人集体的适应性.
- 通过物理接口的用户引导控制可促进动态机器人系统的复杂操作.


相关概念视频
 01:24
One-Degree-of-Freedom System
803
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
803
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
704
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
704
 01:18
Hierarchy of Motor Control
5.9K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
5.9K
 01:15
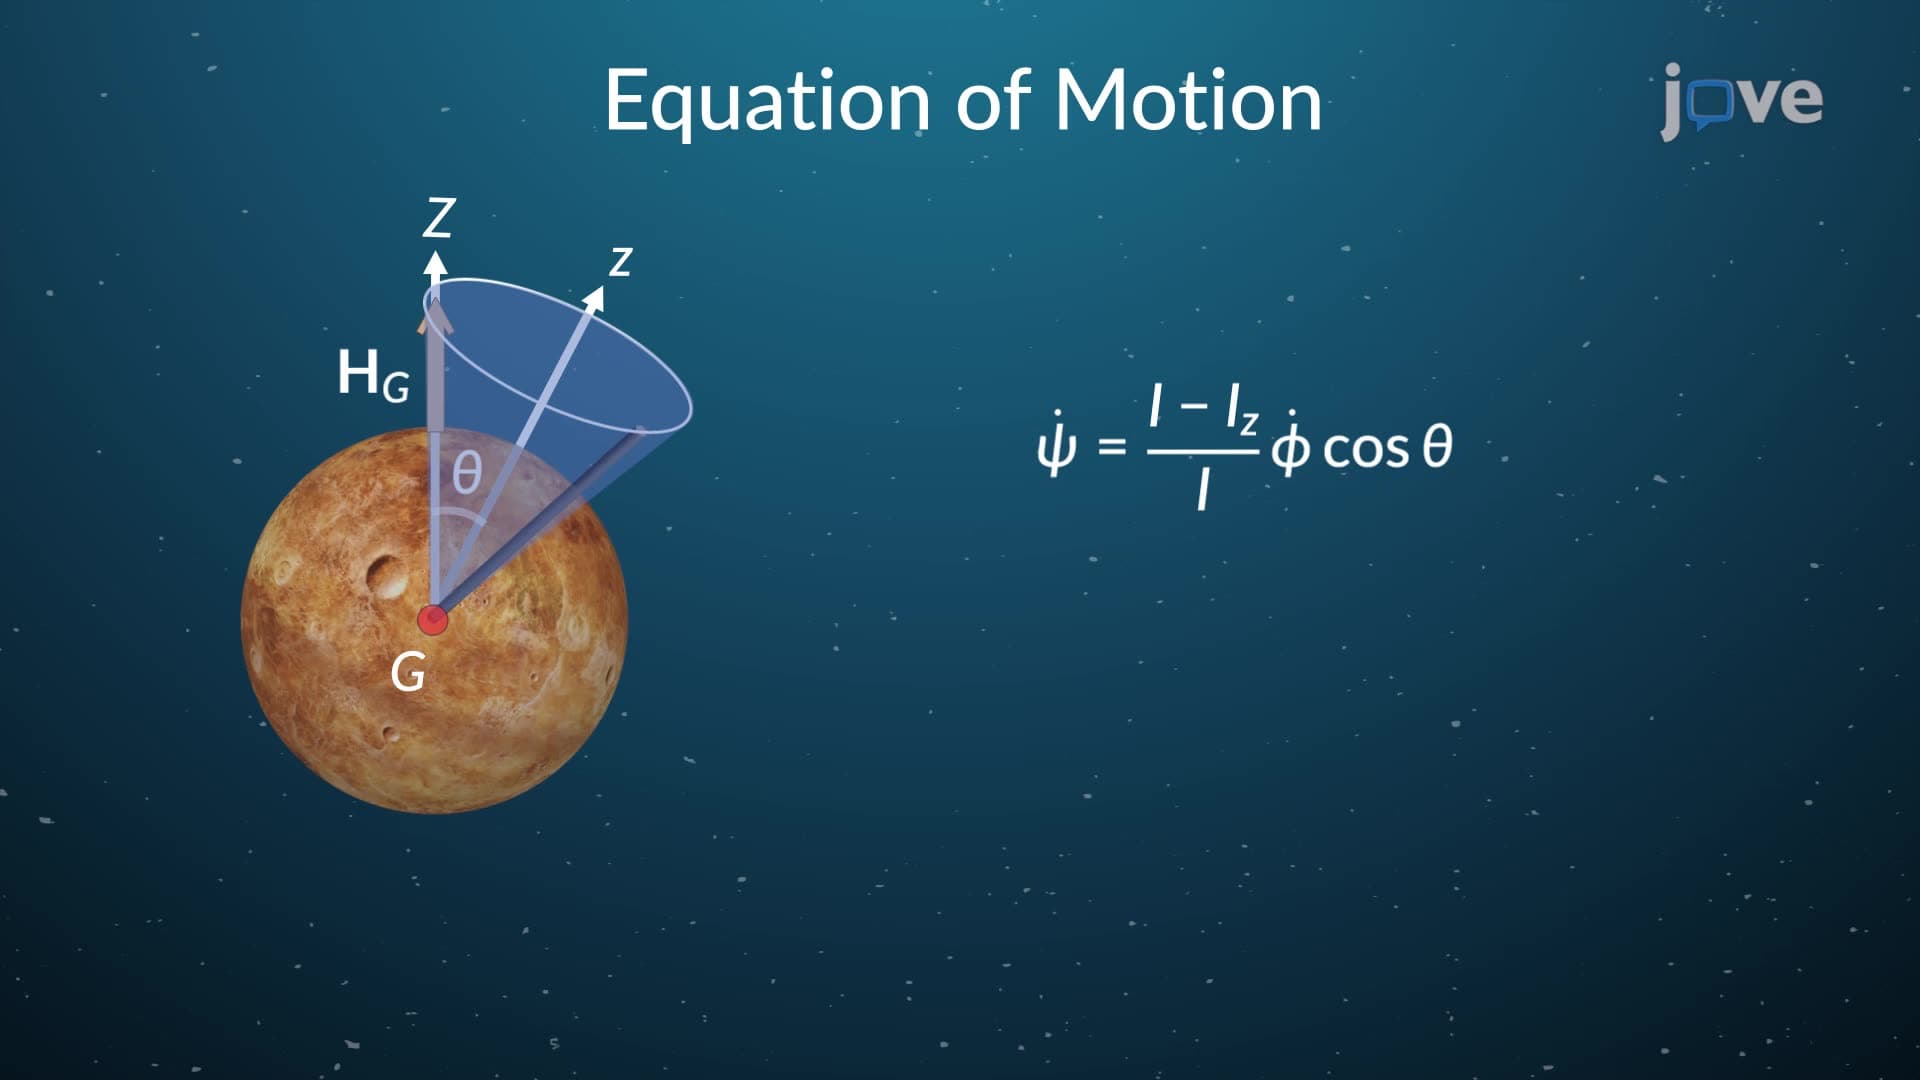
Torque Free Motion
797
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
797
 01:15
Kinematic Equations: Problem Solving
27.3K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
27.3K
 01:17
Open and closed-loop control systems
1.6K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.6K