

增强的多目标图形学习方法,以优化对空间和时间特征的交通速度预测
1PSNA College of Engineering and Technology (PSNACET), Dindigul, Tamil Nadu, India. karthikabm@gmail.com.
Scientific reports
|September 30, 2025

概括
这项研究引入了多目标图形学习 (MOGL) 以准确预测交通速度. MOGL通过改善实时交通管理和减少拥堵来增强智能交通系统.
科学领域:
- 智能运输系统 (ITS) 是一种智能运输系统.
- 机器学习用于时空空间数据分析
- 交通工程和交通管理.
背景情况:
- 交通速度预测 (TSP) 对于智能交通系统 (ITS) 至关重要,它可以实现高效的交通管理和城市移动性.
- 由于时间和空间因素的动态性质,现有的TSP方法面临挑战,导致概括问题和预测不稳定性.
- 道路网络中复杂的时空依赖性为准确的交通速度预测带来了重大障碍.
研究的目的:
- 提出一种新的方法,多目标图形学习 (MOGL),以解决交通速度预测的复杂性.
- 在大型道路网络中提高实时交通速度估计的准确性和可靠性.
- 通过更精确的交通速度预测,提高智能交通系统的性能.
主要方法:
- 开发了一种三相MOGL方法,将自适应图样采集与空间时间图神经网络 (AGS-STGNN) 集成在一起.
- 采用帕雷托高效全球优化 (ParEGO) 在自适应图采样中进行多目标贝叶斯优化,以提取精细的空间和时间特征.
- 采用了增强的注意力门式循环单元 (EAGRU),具有特征融合阶段,用于动态优先确定关键路段和时间间隔.
主要成果:
- MOGL方法在基准数据集 (METR-LA和PeMS-BAY) 上表现出卓越的性能,实现了低的平均绝对误差 (MAE) 和根平均平方误差 (RMSE).
- 在数据集中实现的MAE值为2.09和2.15,RMSE值为3.29和3.22,MAPE值为3.17和3.21.
- 与DSTMAN相比,在METR-LA数据集上显著降低了RMSE,高达28.9%,优于其他最先进的模型,如STGCN变体.
结论:
- 拟议的MOGL方法在实时和大规模的交通速度预测方面取得了重大进展.
- MOGL有效地捕捉了复杂的时空依赖性,从而提高了预测的准确性和可靠性.
- 该模型能够动态优先考虑影响因素,这有助于其在智能运输系统中的性能提高.


相关概念视频
 01:21
Manipulation and Analysis
287
GIS manipulation and analysis functions are vital for decision-making and planning. These activities range from data retrieval tasks, such as selecting information based on specific criteria, to advanced analytical techniques that address complex spatial problems.One critical GIS analysis method is overlaying, which combines multiple data layers to examine impacts. For example, overlaying a river-dammed lake boundary with road networks can identify affected infrastructure. Another common...
287
 01:34
Velocity and Position by Graphical Method
9.5K
Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to...
9.5K
 01:07
End Point Prediction: Gran Plot
1.2K
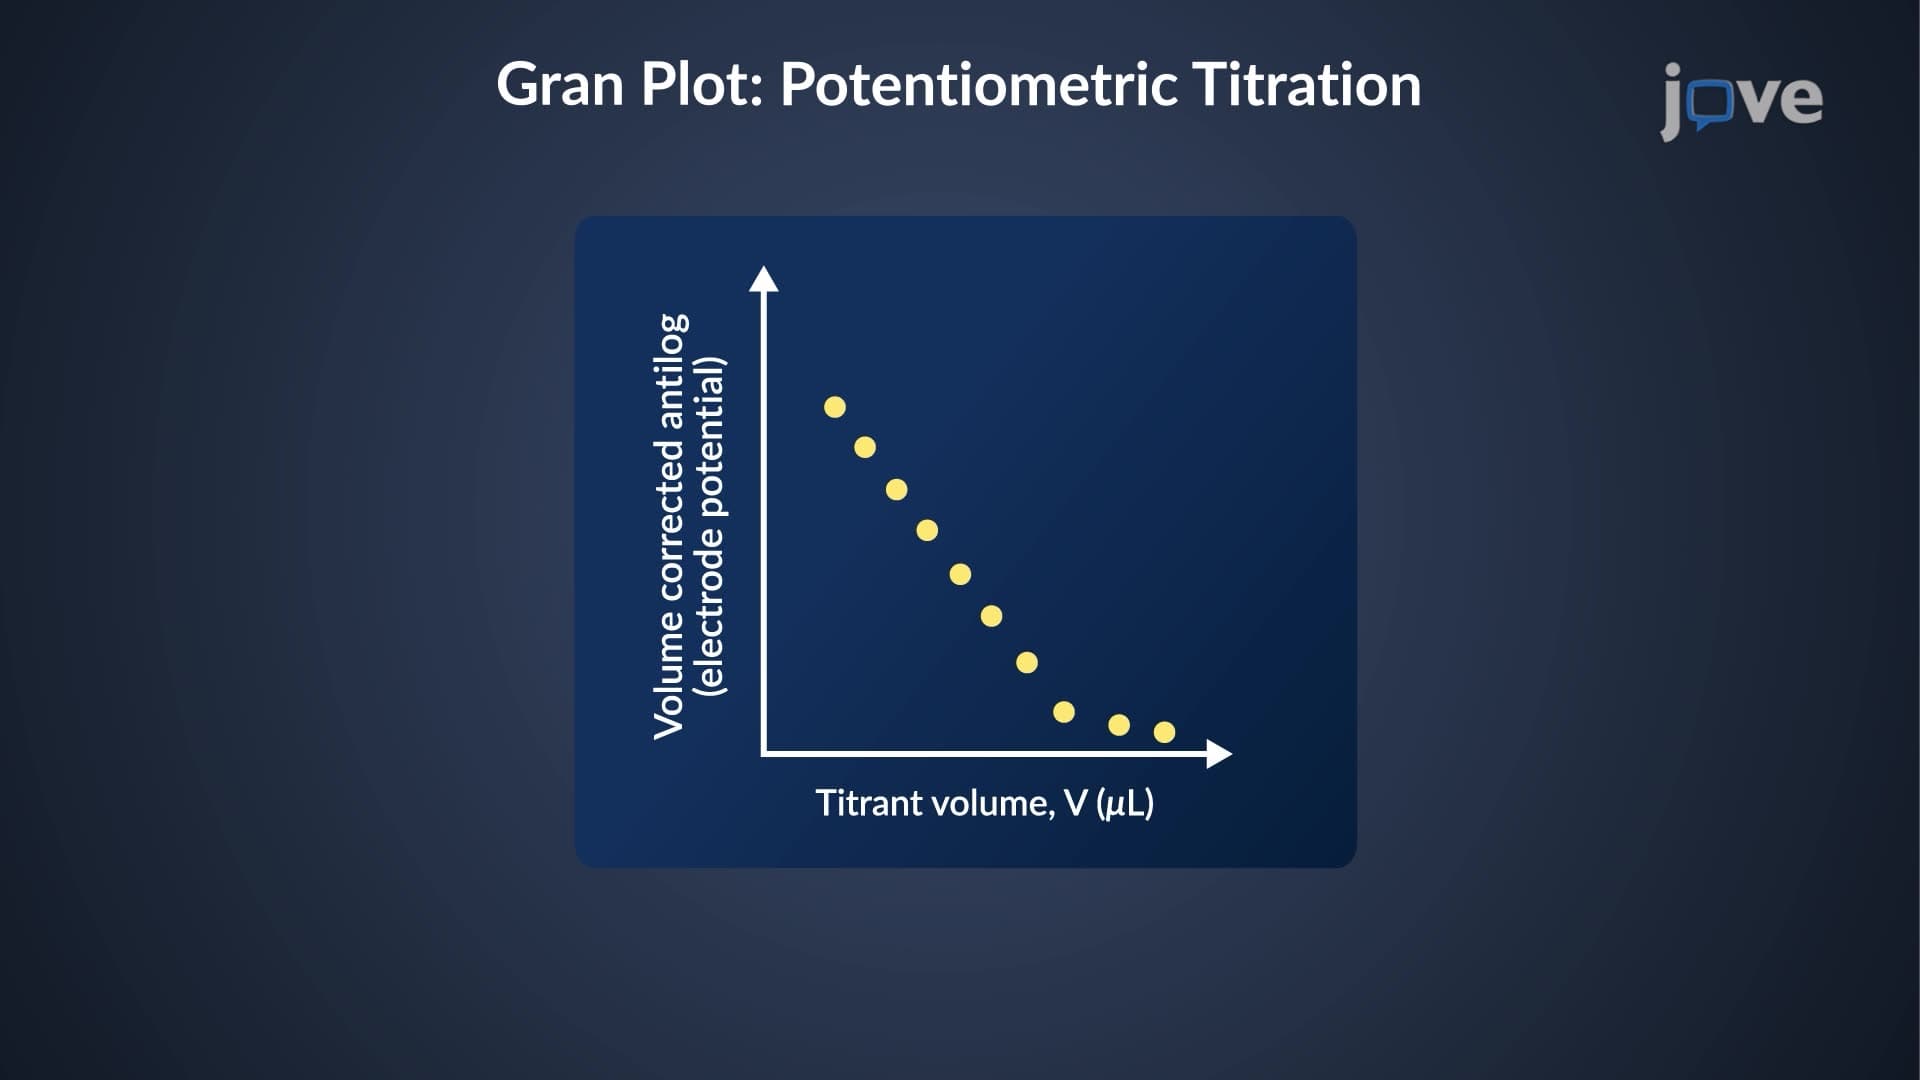
A Gran plot is used to predict the equivalence volume or endpoint of a potentiometric or acid-base titration without reaching the endpoint. Typically, titration data is collected as a function of the titrant's volume up to a point less than the equivalence volume and then transformed into a linear format. The straight line is extended to the x-axis, indicating the necessary titrant volume to achieve the equivalence point.
For potentiometric titration, the Gran plot is created by plotting...
For potentiometric titration, the Gran plot is created by plotting...
1.2K
 00:54
Time-Series Graph
5.0K
A time-series graph is a line graph with repeated measurements taken at successive intervals of time. It is also called a time series chart. To construct a time-series graph, one must look at both pieces of a paired data set. The horizontal axis is used to plot the time increments, and the vertical axis is used to plot the values of the variable that one is measuring. By using the axes in this way, each point on the graph will correspond to time and a measured quantity. The points on the graph...
5.0K
 01:17
Design Example: Alignment of a Road Line Using GIS
333
The alignment of a road line using Geographic Information Systems (GIS) is a critical process in civil engineering, combining advanced technology with practical decision-making. This methodology begins with the collection of geospatial data, including information on land cover, geomorphology, drainage patterns, slope, and contour details. Such data is typically acquired through satellite imagery and GIS tools, offering a comprehensive understanding of the terrain.Once the data is gathered, it...
333
 01:22
Multi-input and Multi-variable systems
392
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence of...
In the absence of...
392