相关实验视频
Updated: Jan 16, 2026
10:41

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
18.0K
大西洋轴旋转固定装置
Peter M Cirrincione1, Jessica H Heyer2
1Department of Orthopaedics, University of Illinois Chicago, Chicago, Illinois.
Current opinion in pediatrics
|October 2, 2025

概括
大西洋轴旋转固定 (AARF) 是一种可治疗的疾病,经常被误认为是. 早期诊断和非侵入性治疗,如休息和药物治疗,导致出色的结果,经常避免手术.
科学领域:
- 整形外科 整形外科 整形外科
- 儿科神经学 儿科神经学
- 运动医学 运动医学
背景情况:
- 大西洋轴旋转固定 (AARF) 是一种复杂的疾病,可以被误诊为扭伤.
- 初级保健医生的及时认可对于有效管理至关重要.
- 了解AARF的病因和表现是及时干预的关键.
研究的目的:
- 提供关于AARF的诊断和治疗的最新审查.
- 强调早期怀疑和非侵入性管理策略的重要性.
- 为了区分AARF与类似的疾病,如结.
主要方法:
- 文献综述,重点关注AARF诊断和治疗的最新进展.
- 重点是临床表现和诊断成像.
- 评估非操作和操作管理结果.
主要成果:
- AARF通常是在上呼吸道病毒感染之后出现的.
- 早期诊断允许成功的非手术治疗,包括休息,宫项圈和药物治疗.
- 非侵入性措施可以导致完全解决,并防止需要手术.
结论:
- AARF是一种可治疗的疾病,通常不需要手术.
- 动态计算机断层扫描 (CT) 是诊断和确认分辨率的首选成像方式.
- 诊断需要证据证明C1和C2脊椎之间存在病理性脱.
相关概念视频
 01:28
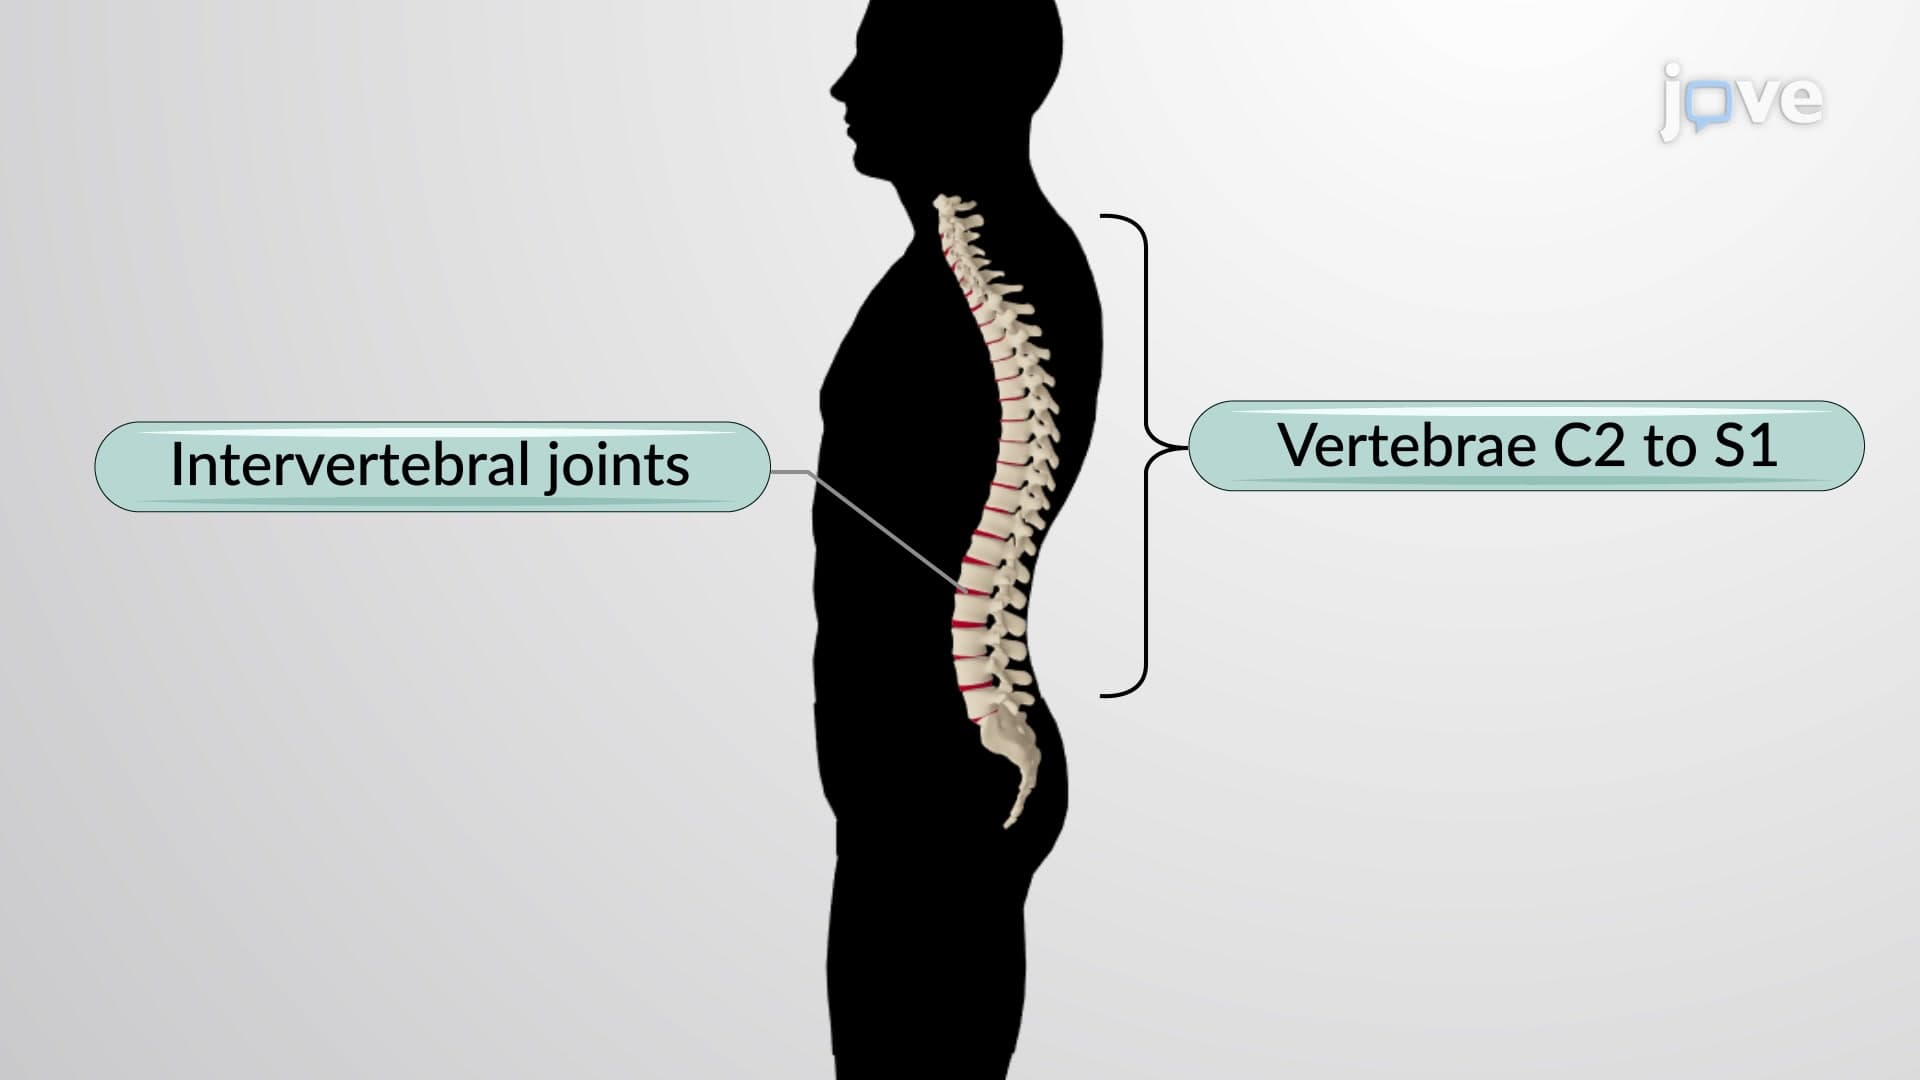
Articulations of the Vertebral Column
3.0K
In addition to being held together by the intervertebral discs, adjacent vertebrae also articulate with each other at synovial joints formed between the superior and inferior articular processes called zygapophysial joints (facet joints). These are plane joints that provide for only limited motions between the vertebrae. The orientation of the articular processes at these joints varies in different regions of the vertebral column and serves to determine the types of motions available in each...
3.0K
 01:26
Rotational Motion about a Fixed Axis
1.3K
A rigid body's rotation around a fixed axis makes every point within it trace a circular path around a specific line or point. The term given to this type of spinning is defined by the angular position, symbolized by the angle θ. This angle is gauged from a static reference line to the revolving object. From this angular position, any variation is referred to as angular displacement, denoted by dθ. The extent of this displacement can be calculated in degrees, radians, or...
1.3K
 00:51
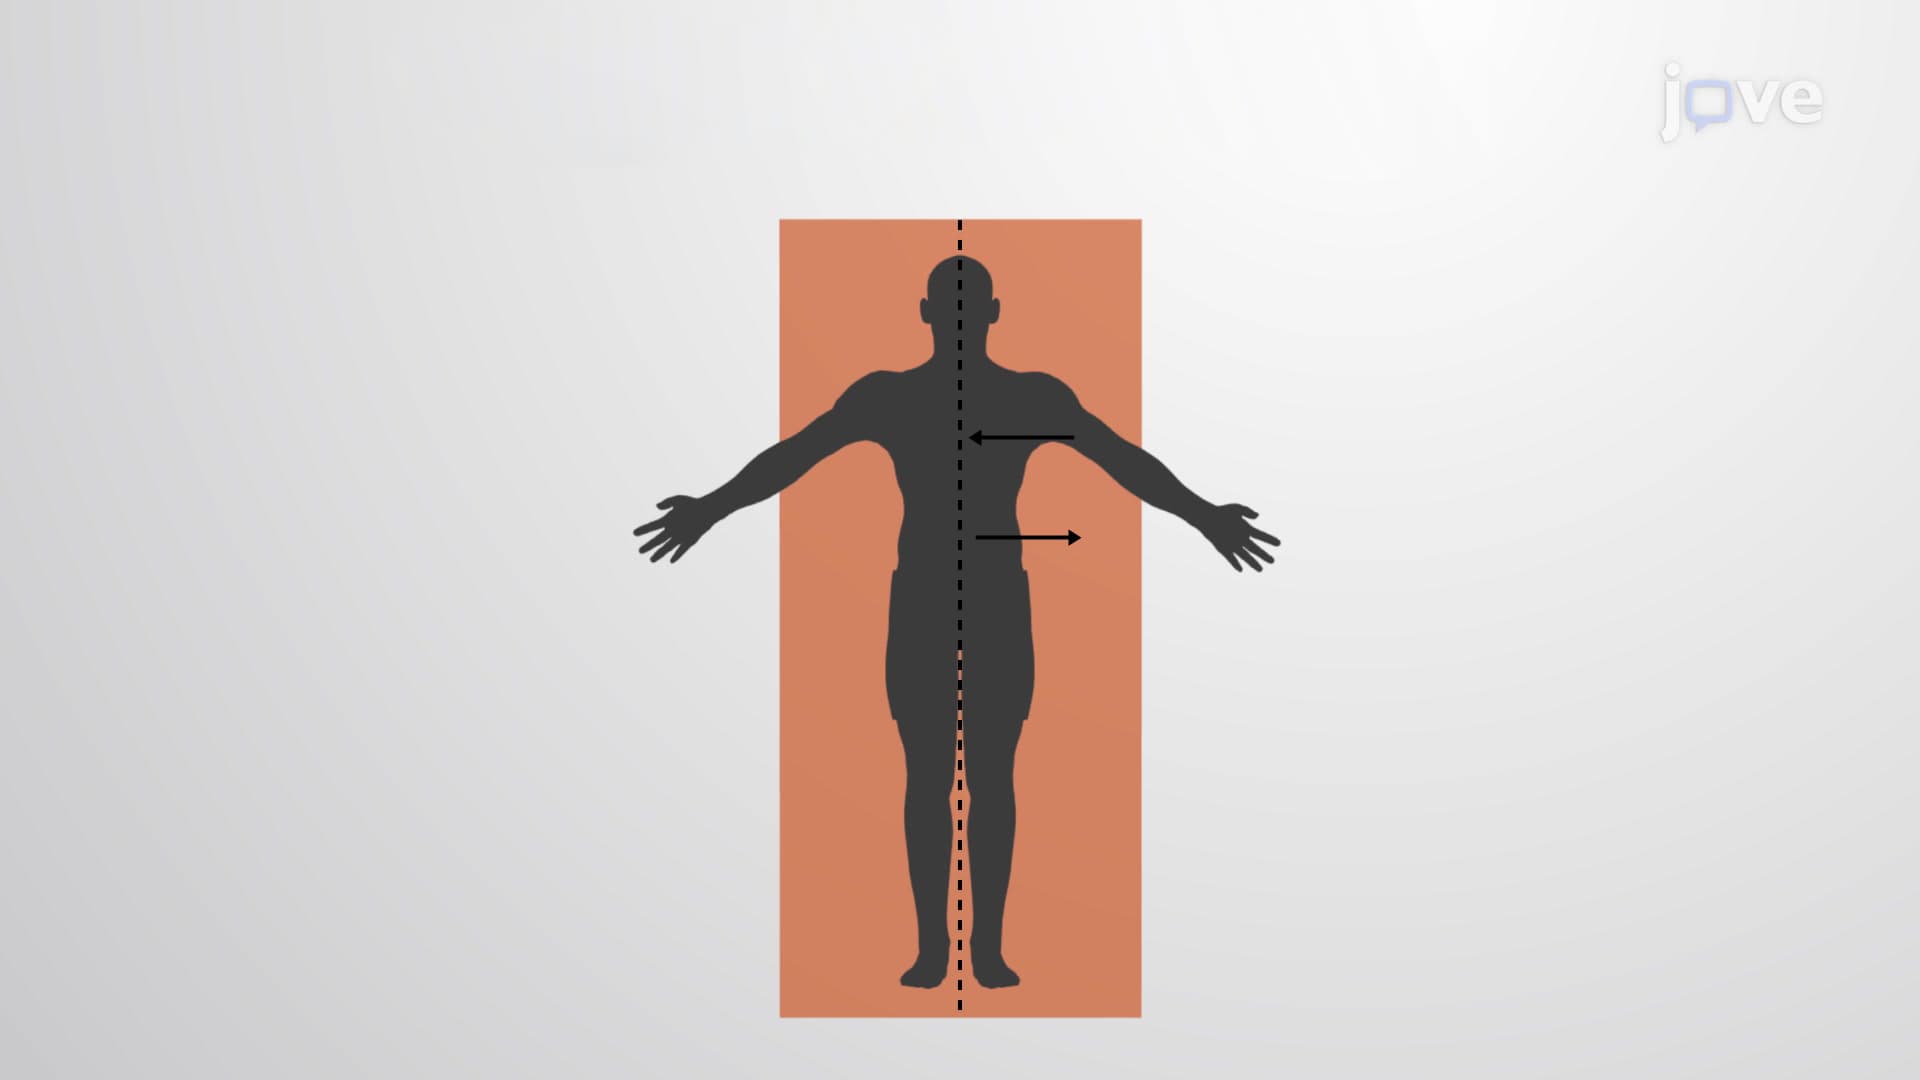
Anatomical Movements
15.1K
Anatomical movements refer to the various actions or motions that can be performed by the body's joints and muscles. These movements are described using specific terms to provide a standardized way of discussing and understanding the range of motion at different joints.
Here are some common anatomical movements:
Flexion and extension motions are in the sagittal (anterior–posterior) plane of motion. These movements take place at the shoulder, hip, elbow, knee, wrist,...
Here are some common anatomical movements:
Flexion and extension motions are in the sagittal (anterior–posterior) plane of motion. These movements take place at the shoulder, hip, elbow, knee, wrist,...
15.1K
 01:18
Equation of Motion: Rotation About a Fixed Axis
502
Consider a flywheel, having an uneven mass distribution, rotating steadily around a fixed axis. As this rotation occurs, the center of mass of the flywheel traces a circular path. Understanding the acceleration of this center of mass requires observing both its tangential and normal components.
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
502
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
704
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
704
 01:25
Relative Motion Analysis using Rotating Axes
880
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
880