
通过比例-差异控制稳定鱼-藻类结合地图格子模型的时空动态
Yanhua Zhu1, Xiangyi Ma1, Jinliang Wang1
1Department of Mathematics, Beihang University, Changping, Beijing, 100191, People's Republic of China.
Journal of mathematical biology
|October 6, 2025

概括
这项研究使用合地图格子 (CMLs) 建模了-藻 (M-A) 系统. 比例差分 (PD) 控制通过防止混乱动态和确保统一分布来稳定藻类种群,这对海洋水产养殖生态系统至关重要.
科学领域:
- 海洋生态海洋生态学
- 数学生物学 数学生物学
- 水产养殖系统 水产养殖系统
背景情况:
- 藻 (M-A) 系统对于海洋水产养殖生态系统平衡至关重要.
- 藻类种群动态显著影响的生长和繁殖,反之亦然.
- 了解M-A系统动态是保持水产养殖稳定的关键.
研究的目的:
- 为MA系统开发一个空间时间分离的合地图格子 (CMLs) 模型.
- 在MA系统模型中分析稳定性和分叉 (翻转和图灵).
- 调查比例差分 (PD) 控制对MA系统动态和稳定性的影响.
主要方法:
- 结合地图格子 (CMLs) 建模,包括自我扩散和交叉扩散.
- 线性稳定性分析和分叉理论用于分类固定点和确定分叉条件.
- 数字模拟以探索时间动态,时空模式和PD控制的影响.
主要成果:
- CMLs模型揭示了丰富的时间动态和来自五种不同的机制的时空模式.
- 引入了PD控制,成功地延迟了翻转分叉,并防止了藻类密度中的多周期振荡和混乱.
- 控制PD减少了图灵不稳定区域,并调节了图灵模式类型,促进了藻类的均分布.
结论:
- 开发的CMLs模型提供了对M-A系统动态和稳定性的洞察.
- 控制PD是一种有效的策略,可以稳定藻类种群,防止M-A系统中的生态系统不稳定.
- 这项研究通过先进的建模和控制策略,有助于保持稳定和生产力的海洋水产养殖生态系统.

相关概念视频
 01:07
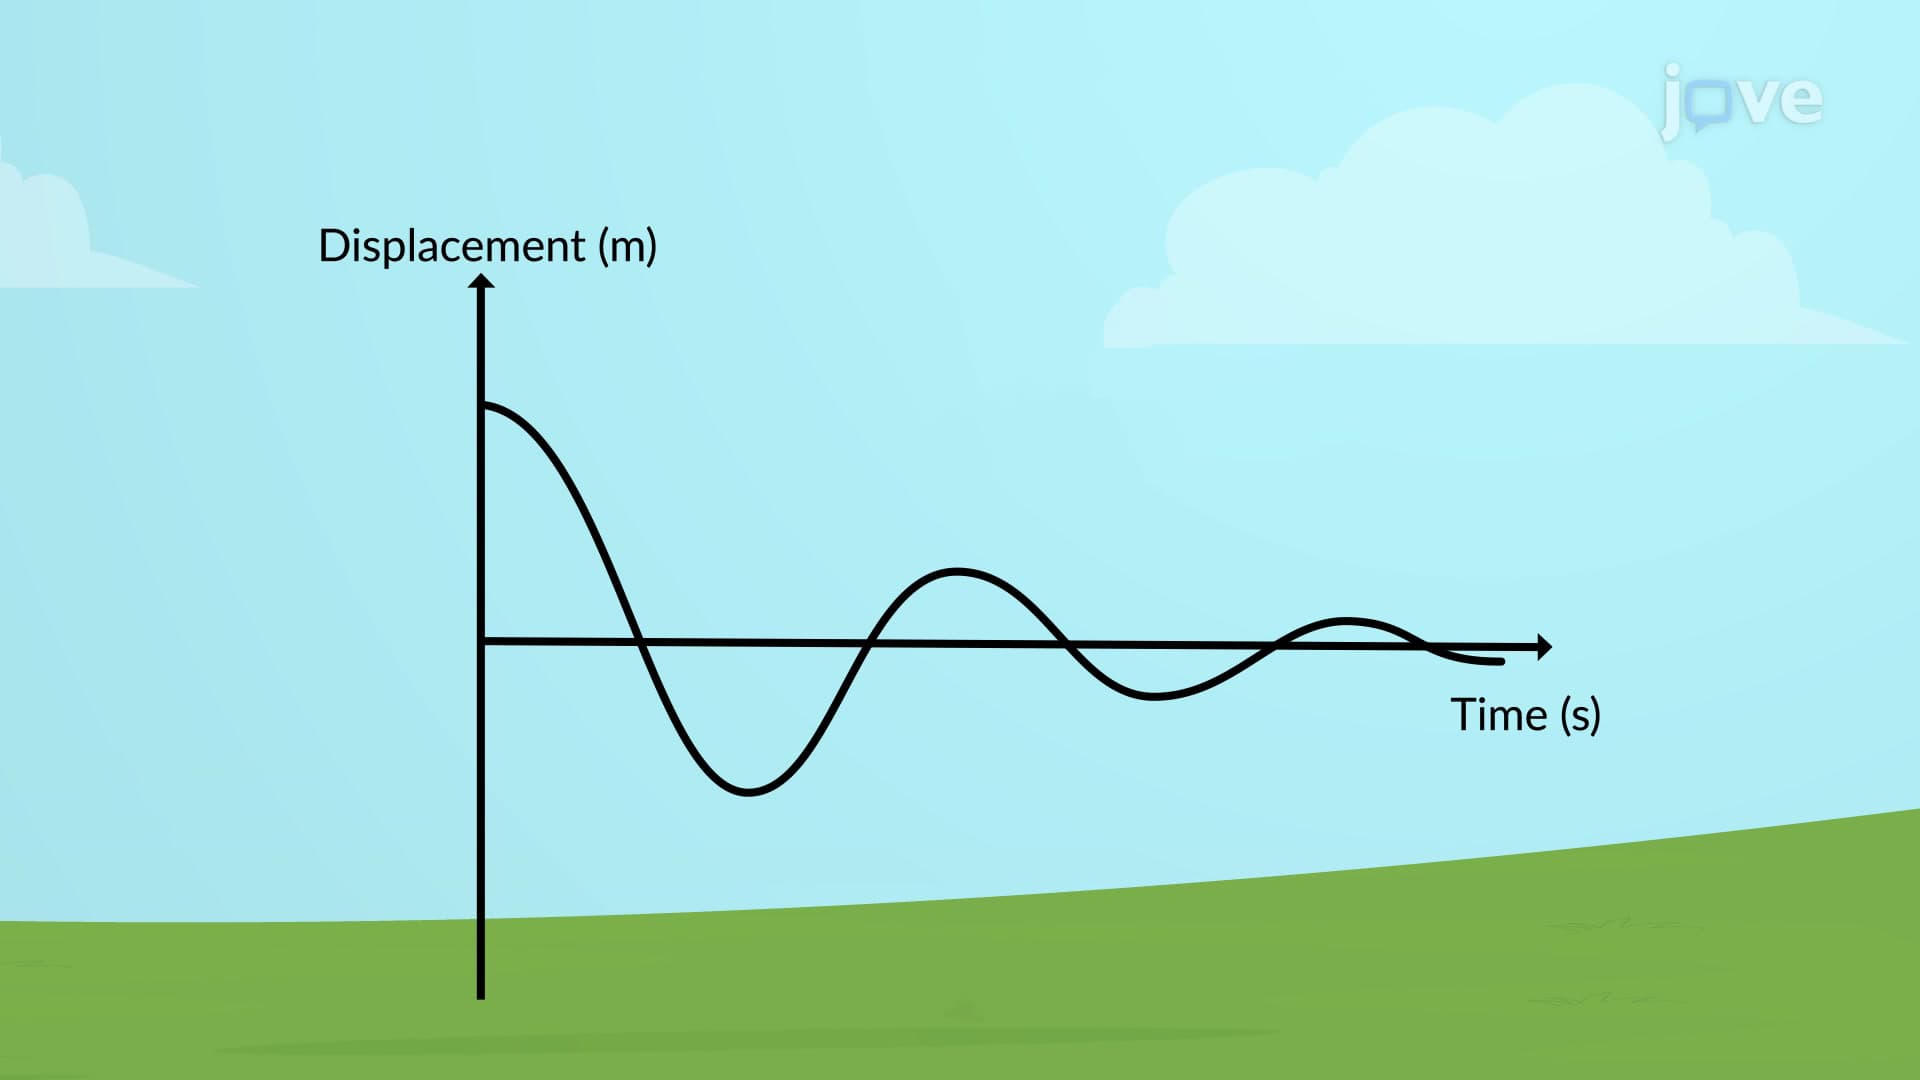
Damped Oscillations
6.8K
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
6.8K
 01:21
Linear Approximation in Time Domain
343
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
343
 01:20
Types of Damping
7.5K
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
7.5K
 01:21
Design Example: Creating a Hydraulic Model of a Dam Spillway
674
Scaled hydraulic models of dam spillways provide a practical way to replicate and study the intricate flow dynamics of these structures. Often built to a 1:15 ratio, these models allow for observing critical water behavior, such as velocity distribution, flow patterns, and energy dissipation.
674
 01:20
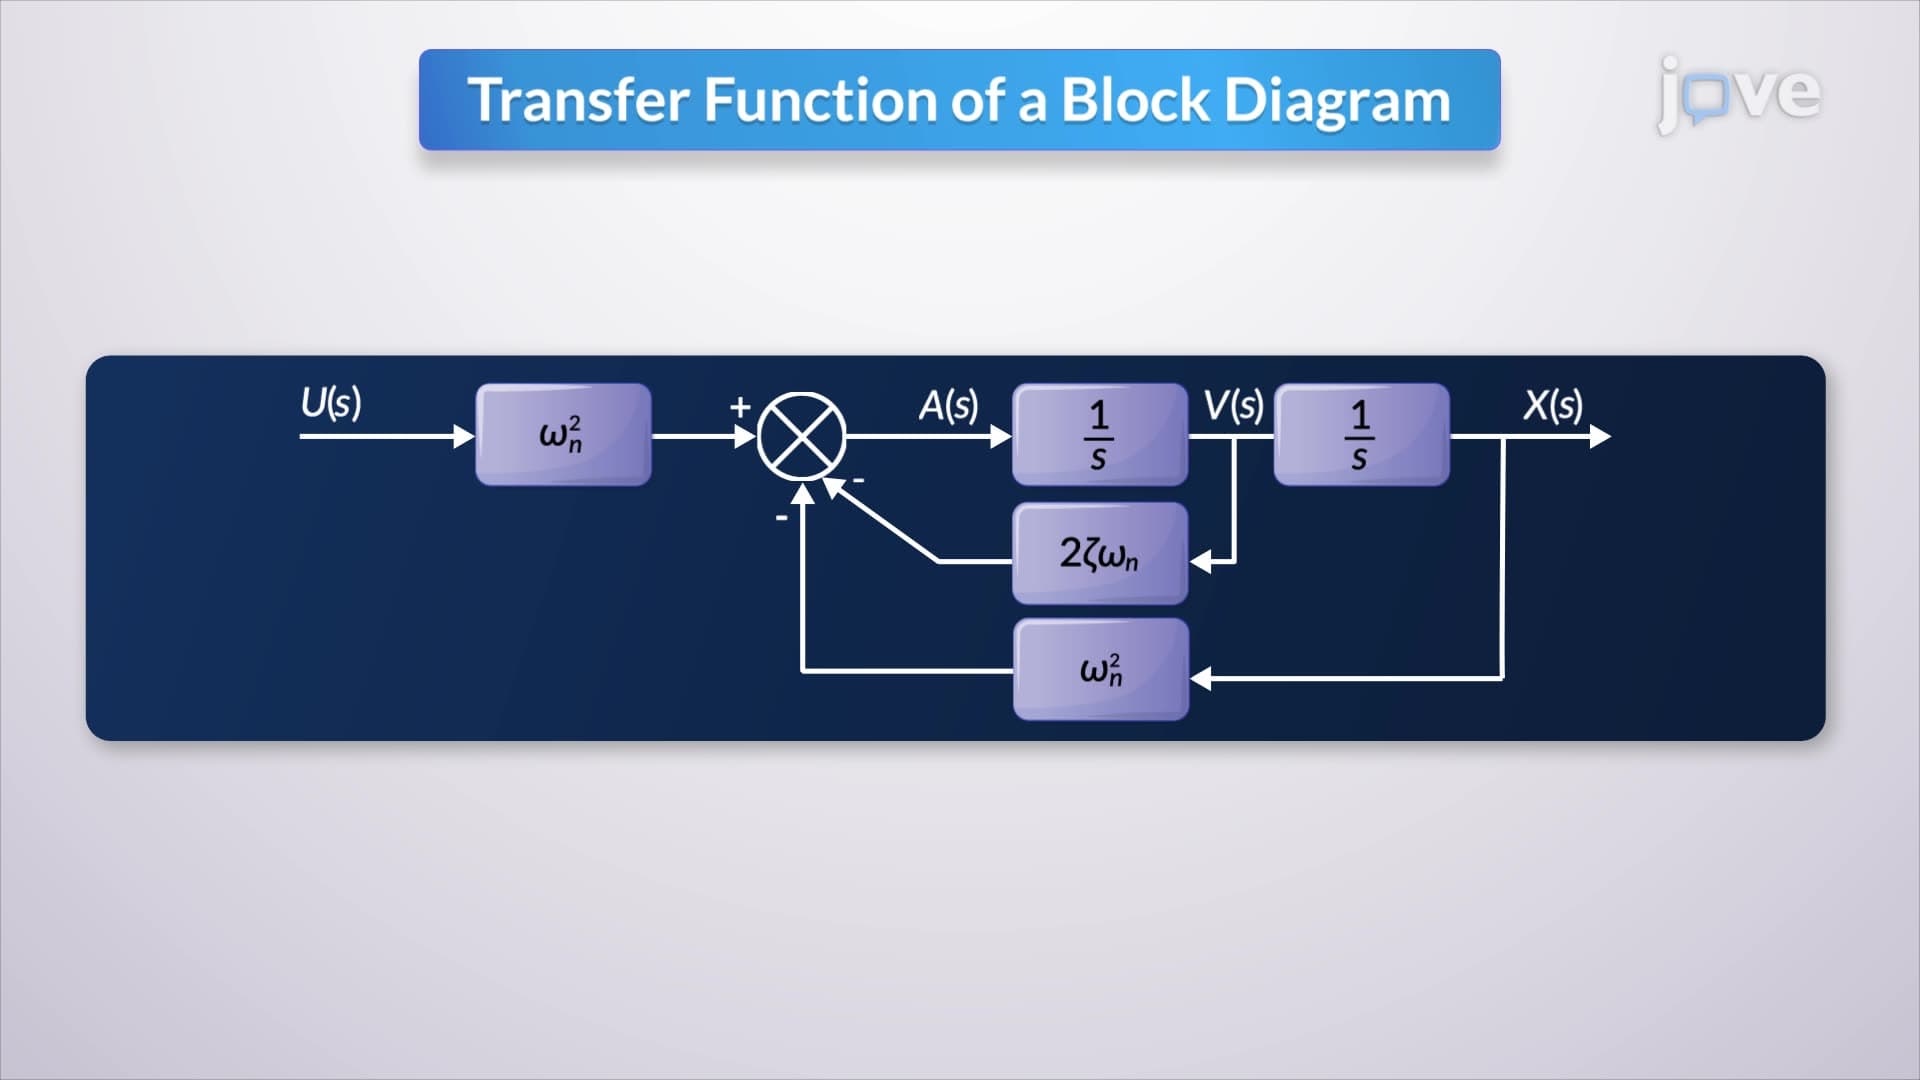
Relation between Mathematical Equations and Block Diagrams
2.9K
In a spring-mass-damper system, the second-order differential equation describes the dynamic behavior of the system. When transformed into the Laplace domain under zero initial conditions, this equation can be effectively analyzed and manipulated. The transformation into the Laplace domain converts differential equations into algebraic equations, simplifying the process of isolating the output.
2.9K
 01:07
Time-Domain Interpretation of PD Control
371
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
371