学习等离子体动力学和强大的降级轨迹,在TCV进行预测-首先实验
Allen M Wang1,2, Alessandro Pau3, Cristina Rea4
1Plasma Science and Fusion Center, Massachusetts Institute of Technology, Cambridge, MA, USA. awang@psfc.mit.edu.
Nature communications
|October 6, 2025

概括
科学家们使用科学机器学习 (SciML) 开发了一种神经状态空间模型 (NSSM),用于预测和控制托卡马克减速过程中的等离子体动态,改善核聚变能源操作并避免不稳定.
科学领域:
- 核聚变能源的研究.
- 血物理学的等离子体物理学
- 科学机器学习 (SciML) 是指科学机器学习.
背景情况:
- 托卡马克降级阶段很难模拟,容易发生等离子体不稳定.
- 现有的方法难以预测和减轻这些不稳定性,冒着运营中断的风险.
研究的目的:
- 使用SciML开发一个用于tokamak等离子体动态的预测模型.
- 设计控制策略,避免等离子体不稳定性极限.
- 为了证明模型在现实世界核聚变实验中的有效性.
主要方法:
- 开发了一个神经状态空间模型 (NSSM),结合了基于物理和数据的方法.
- 在311 Tokamak à Configuration Variable (TCV) 脉冲的数据集上训练了NSSM.
- 应用强化学习 (RL) 来优化血轨迹的稳定性.
- 在TCV通过高性能实验验证实了NSSM.
主要成果:
- 该NSSM成功地从一个适度的数据集中学习了等离子体动态,包括与反应堆相关的高性能模式.
- 在RL指导的轨迹中,运营指标在统计学上有显著的改善.
- 一个预测-第一个实验显示了NSSM对受控外推的能力,将血电流增加了20%.
结论:
- 开发的SciML方法通过提供对不确定性的稳定性来增强托卡马克控制.
- 这种方法证明了SciML对推进核聚变能源实验的实际相关性.
- 该NSSM为更加稳定和高效的托卡马克运营铺平了道路.
相关概念视频
 01:07
End Point Prediction: Gran Plot
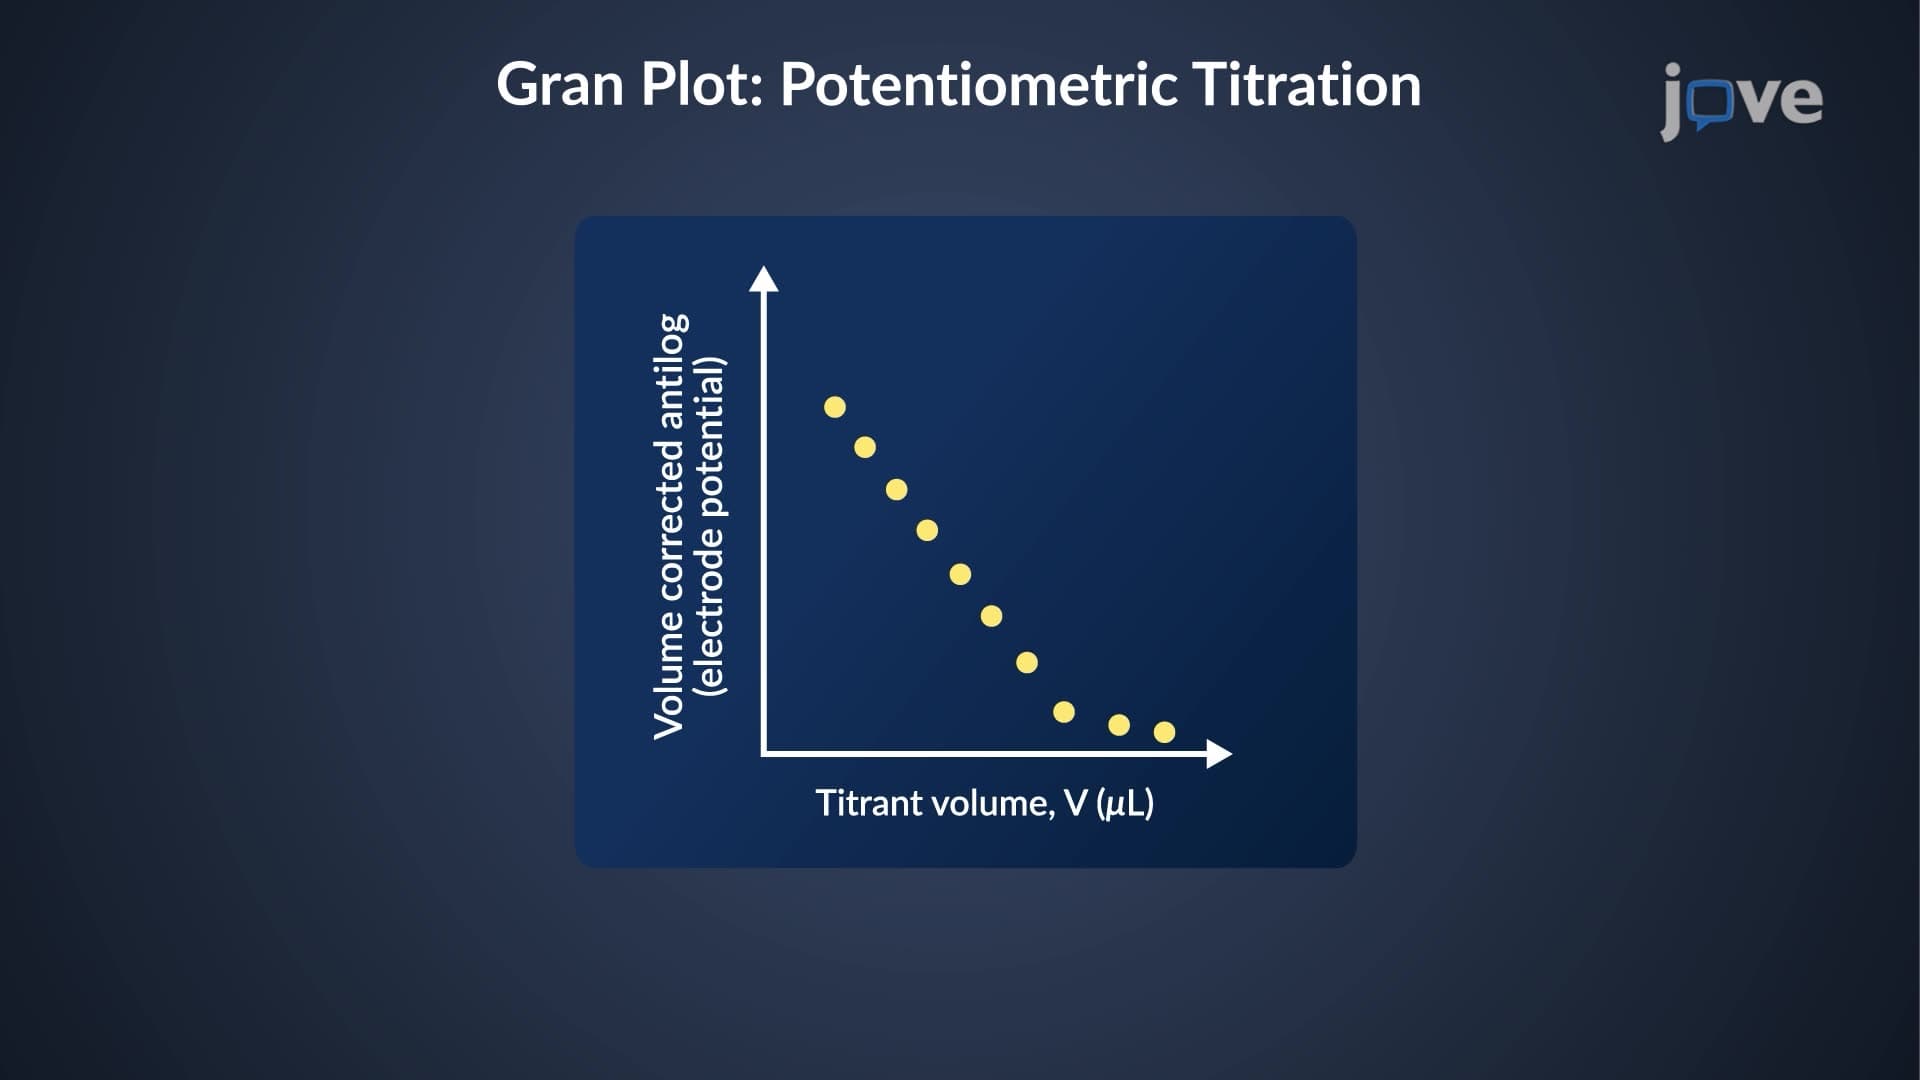
A Gran plot is used to predict the equivalence volume or endpoint of a potentiometric or acid-base titration without reaching the endpoint. Typically, titration data is collected as a function of the titrant's volume up to a point less than the equivalence volume and then transformed into a linear format. The straight line is extended to the x-axis, indicating the necessary titrant volume to achieve the equivalence point.
For potentiometric titration, the Gran plot is created by plotting the...
For potentiometric titration, the Gran plot is created by plotting the...
 01:21
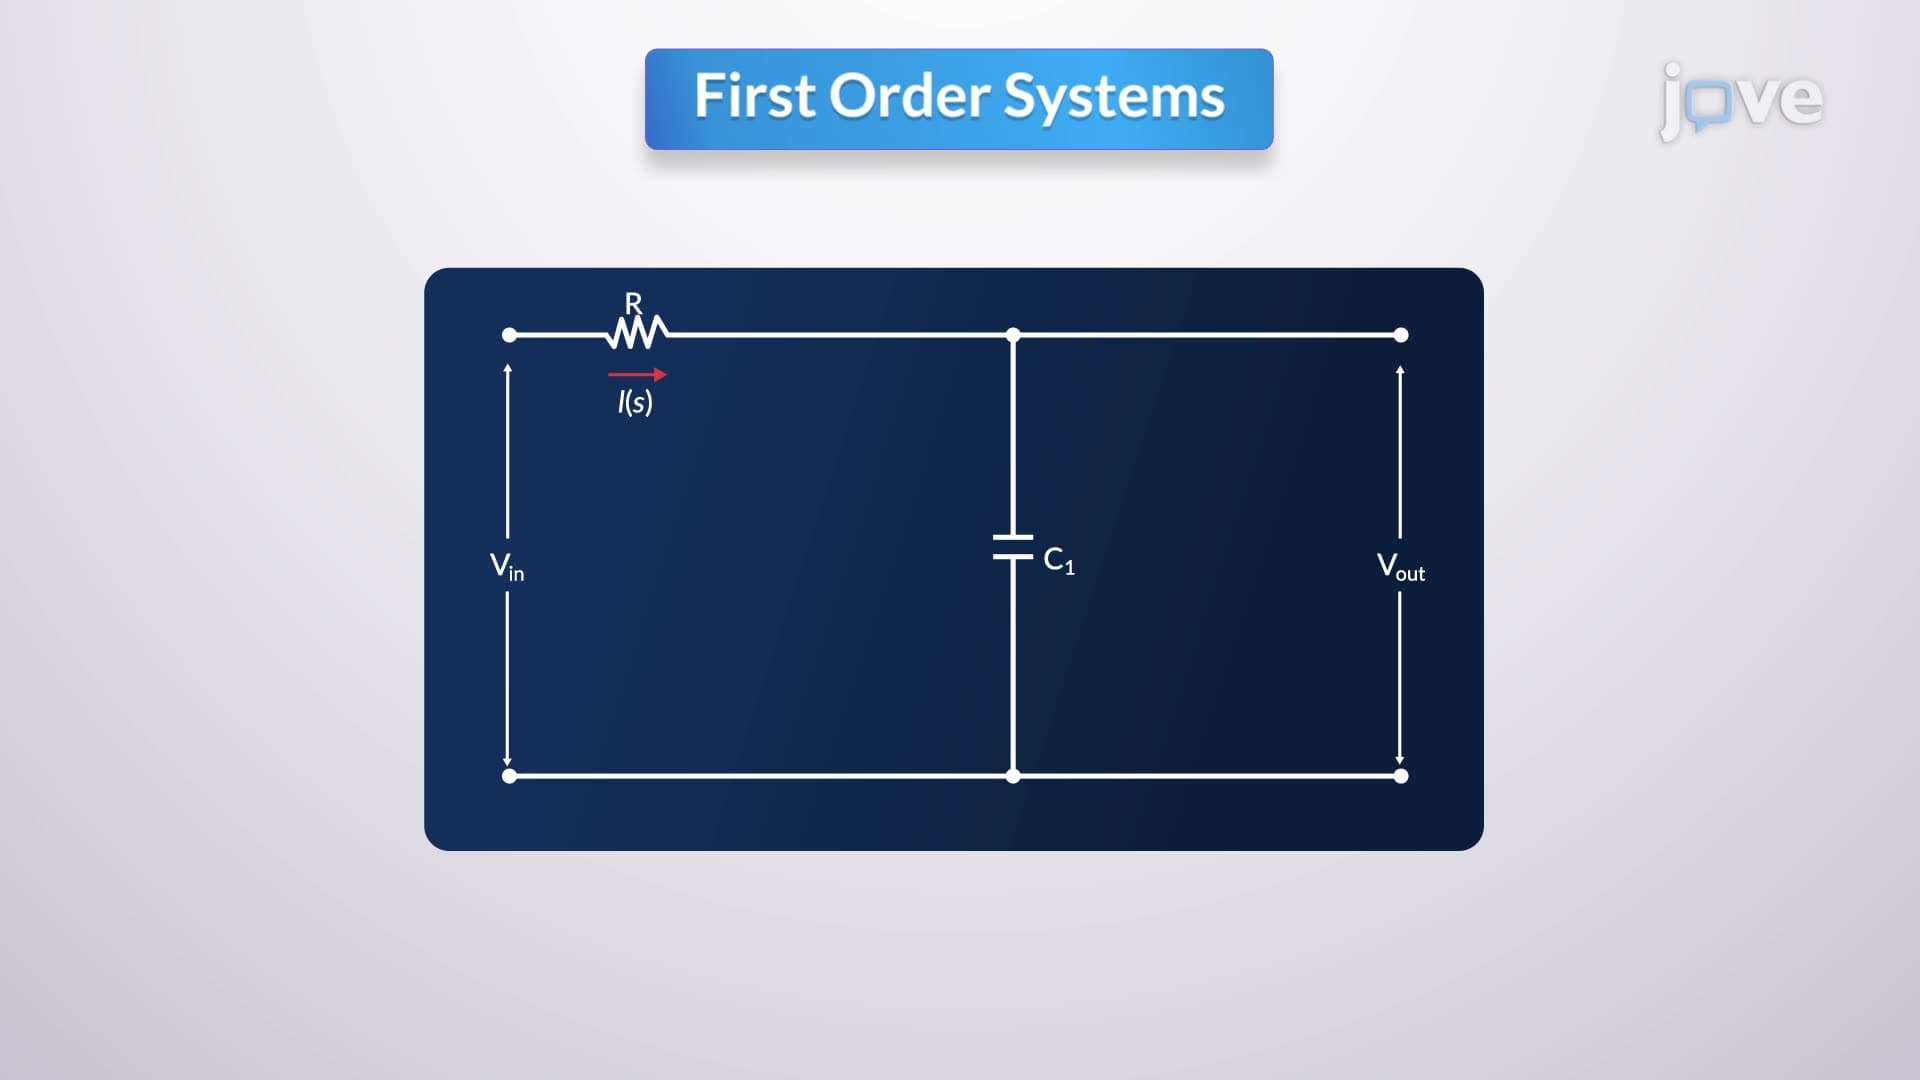
First Order Systems
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:13
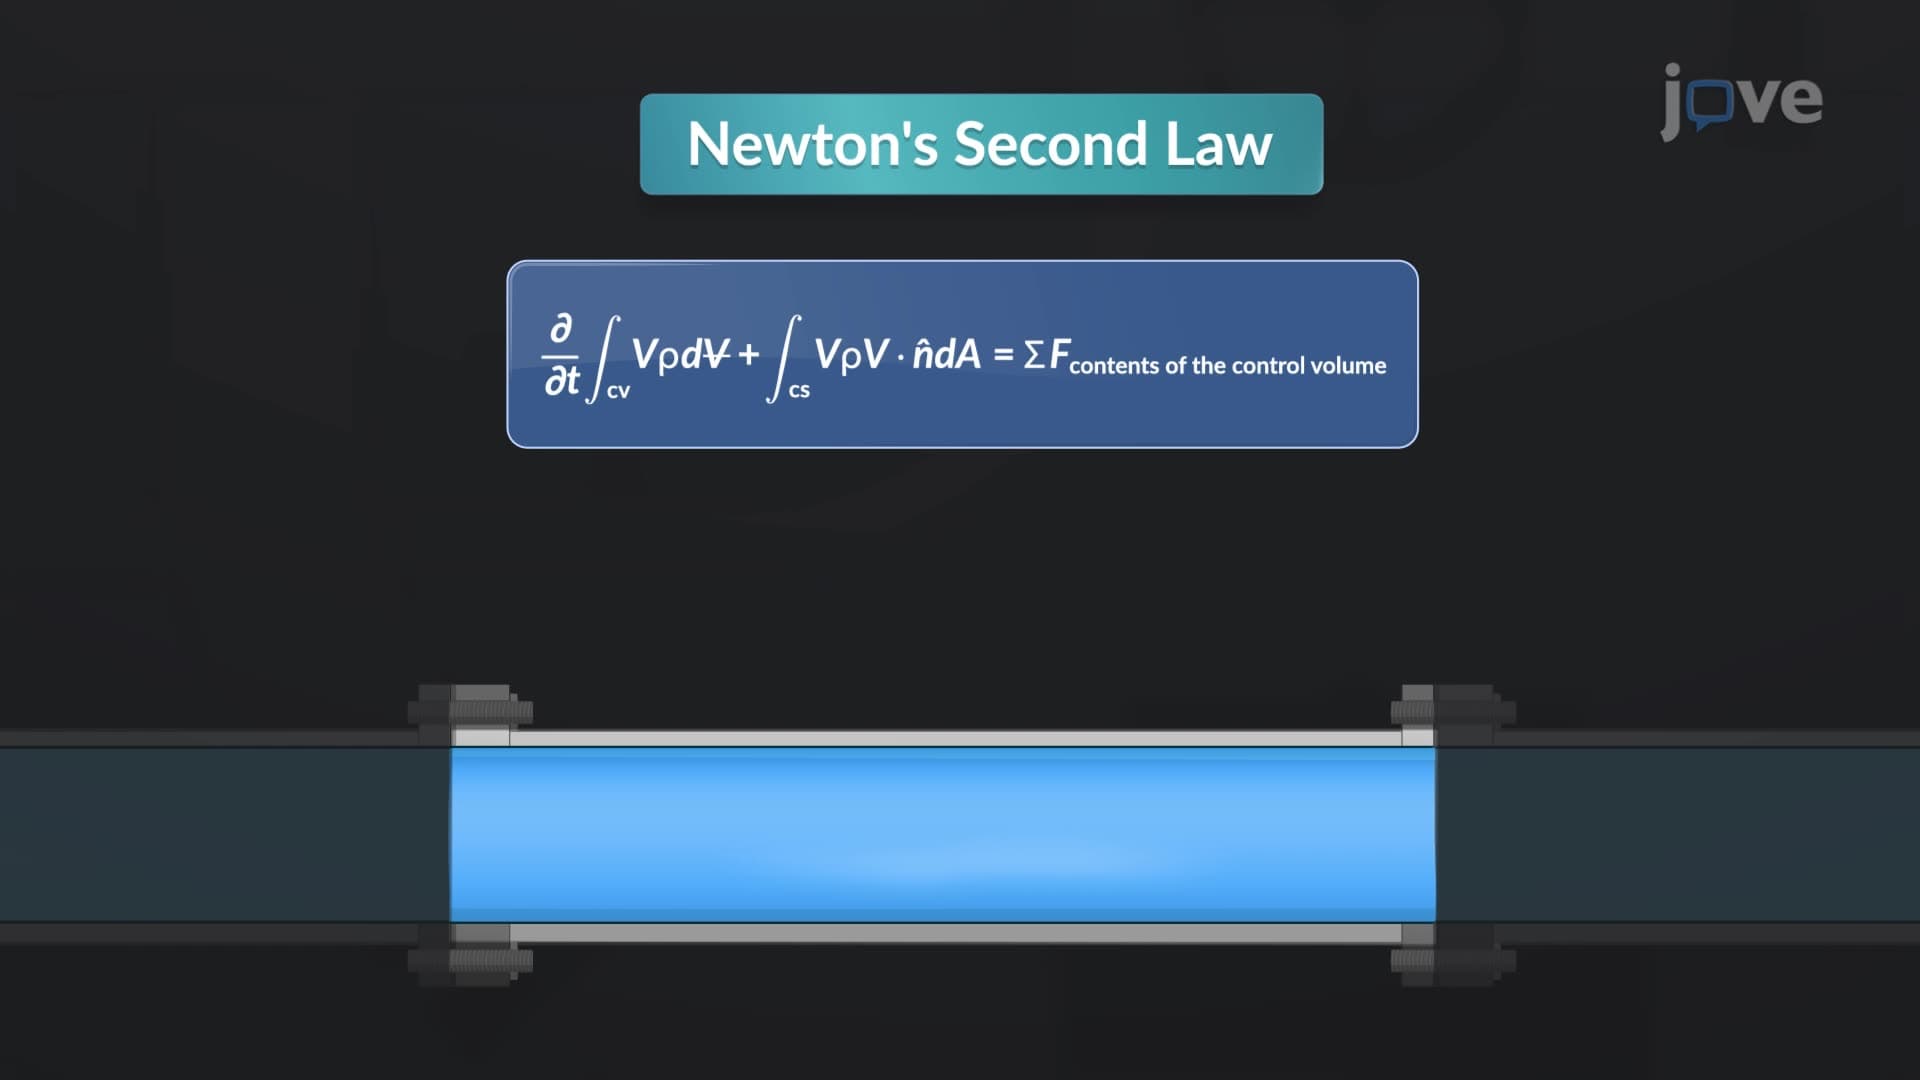
Linear Momentum in Control Volume
Newton's second law is applied to obtain the linear momentum in a control volume in a fluid system. According to this law, the rate of change of linear momentum is equal to the sum of external forces acting on the system. When a control volume matches the fluid system at a specific moment, the forces acting on both are identical. Reynolds transport theorem helps explain this by breaking down the system's linear momentum into two components: the rate of change of linear momentum within the...
 01:24
Rapidly Varying Flow
Rapidly varying flow (RVF) in open channels is characterized by abrupt changes in flow depth over a short distance, with the rate of depth change relative to distance often approaching unity. These flows are inherently complex due to their transient and multi-dimensional nature, making exact analysis difficult. However, approximate solutions using simplified models provide valuable insights into their behavior.Key Features of Rapidly Varying FlowRVF is commonly observed in scenarios involving...
 01:26
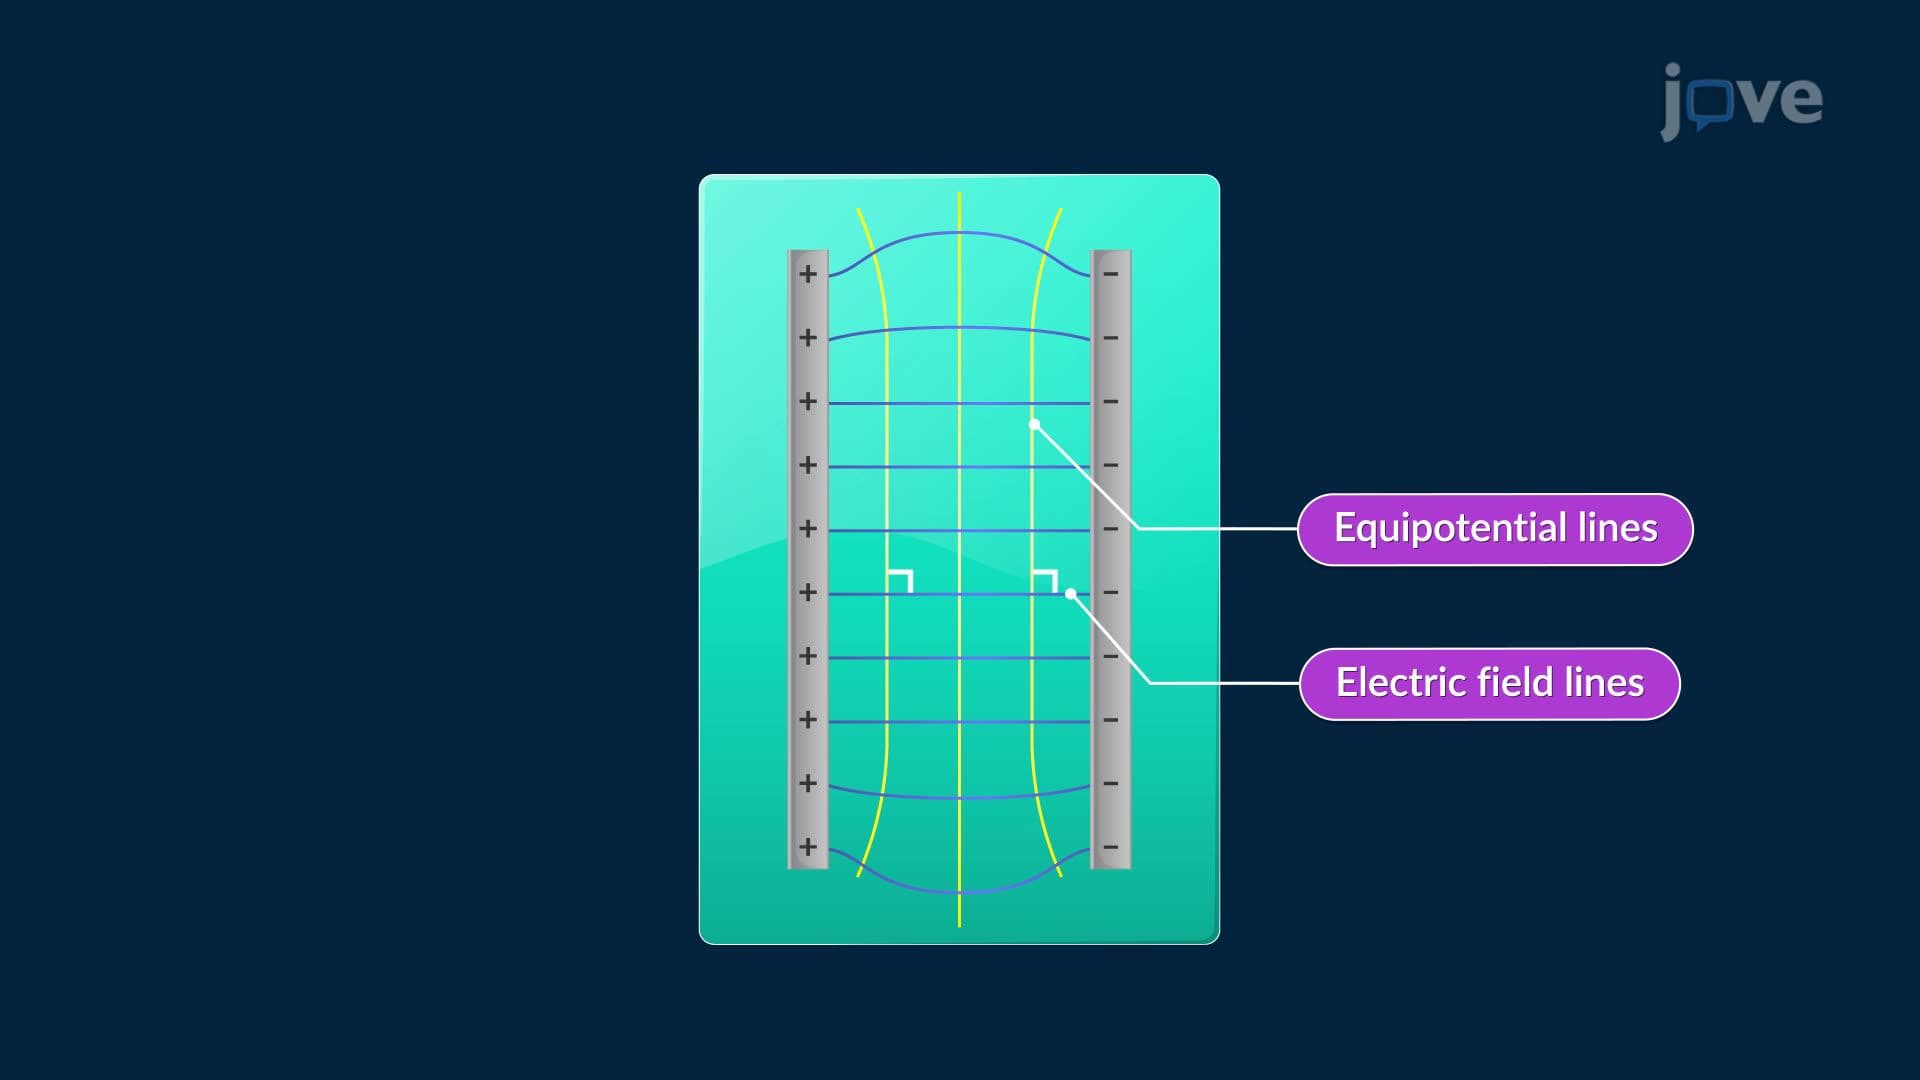
Orthogonal Trajectories
Orthogonal trajectories describe the geometric relationship between two families of curves that intersect each other at right angles. One illustrative case involves a family of parabolas that open sideways along the x-axis. These curves share a common shape but differ by a scaling parameter, resulting in a set of curves that all pass through the origin and widen at different rates.Determining Orthogonal TrajectoriesTo identify the orthogonal trajectories for these parabolas, the first step...
 01:30
Vector Functions and Motion: Problem Solving
Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...