

在低光条件下,用于无人机视图对象检测的并行联合编码
Liwen Liu1, Bo Zhou1, Qiqin Li1
1Institute of Electronic and Electrical Engineering, Civil Aviation Flight University of China, Guanghan, China.
Frontiers in artificial intelligence
|October 8, 2025

概括
这项研究引入了一种用于夜间无人机物体检测的新型并行神经网络. 该模型增强了低光图像,提高了检测准确度,在具有挑战性的条件下为空中监视提供了可靠的解决方案.
科学领域:
- 计算机视觉 计算机视觉
- 人工智能的人工智能
- 机器人技术 机器人技术 机器人技术
背景情况:
- 在低光和噪音条件下,无人机对象检测的准确性显著下降.
- 现有的算法在照明不足的情况下扎,从而损害了监控能力.
研究的目的:
- 开发一个高效和强大的并行神经网络,用于在夜间环境中进行无人机视图对象检测.
- 为了同时提高图像质量和改善在不利照明下对象检测的准确性.
主要方法:
- 在图像增强和物体检测模块之间具有双向梯度传播的共同进化框架.
- 集成Zero-DCE++用于自适应照明调节和轻量级YOLOv5用于实时检测.
- 引入空间自适应特征调制和高/低频自适应特征增强块,以优化特征提取.
主要成果:
- 与传统的YOLOv5.5相比,拟议的方法在VisDrone2019 (夜间) 和无人机车辆 (夜间) 数据集的平均平均精度 (mAP) 中取得了显著的改进.
- 在极度低光和高噪音场景中表现出增强的性能,mAP@0.5:0.95的改进分别为3.13%和3.1%,mAP@0.5的改进分别为6.3%和2%.
- 平行模型在提高特征表示稳定性和检测准确性方面被证明是有效的.
结论:
- 开发的并行神经网络为夜间无人机视觉监控提供了高效可靠的解决方案.
- 图像增强和对象检测的联合优化在具有挑战性的低光条件下显著提高了性能.
- 该模型的架构增强了功能感知和语义表示,以改善无人机监视.
相关概念视频
 02:16
Light Acquisition
9.4K
In order to produce glucose, plants need to capture sufficient light energy. Many modern plants have evolved leaves specialized for light acquisition. Leaves can be only millimeters in width or tens of meters wide, depending on the environment. Due to competition for sunlight, evolution has driven the evolution of increasingly larger leaves and taller plants, to avoid shading by their neighbors with contaminant elaboration of root architecture and mechanisms to transport water and nutrients.
9.4K
 01:05
Difference from Background: Limit of Detection
8.0K
The limit of detection (LOD) is the smallest amount of analyte that can be distinguished from the background noise. The LOD value corresponds to the concentration at which the analyte signal is three times larger than the standard deviation of the blank signal. Below this value, the analyte signal cannot be differentiated from the background noise. It is calculated by dividing the calibration slope by 3 times the standard deviation of the blank signals.
The LOD indicates the presence or absence...
The LOD indicates the presence or absence...
8.0K
 01:15
Depth Perception and Spatial Vision
1.8K
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
1.8K
 01:20
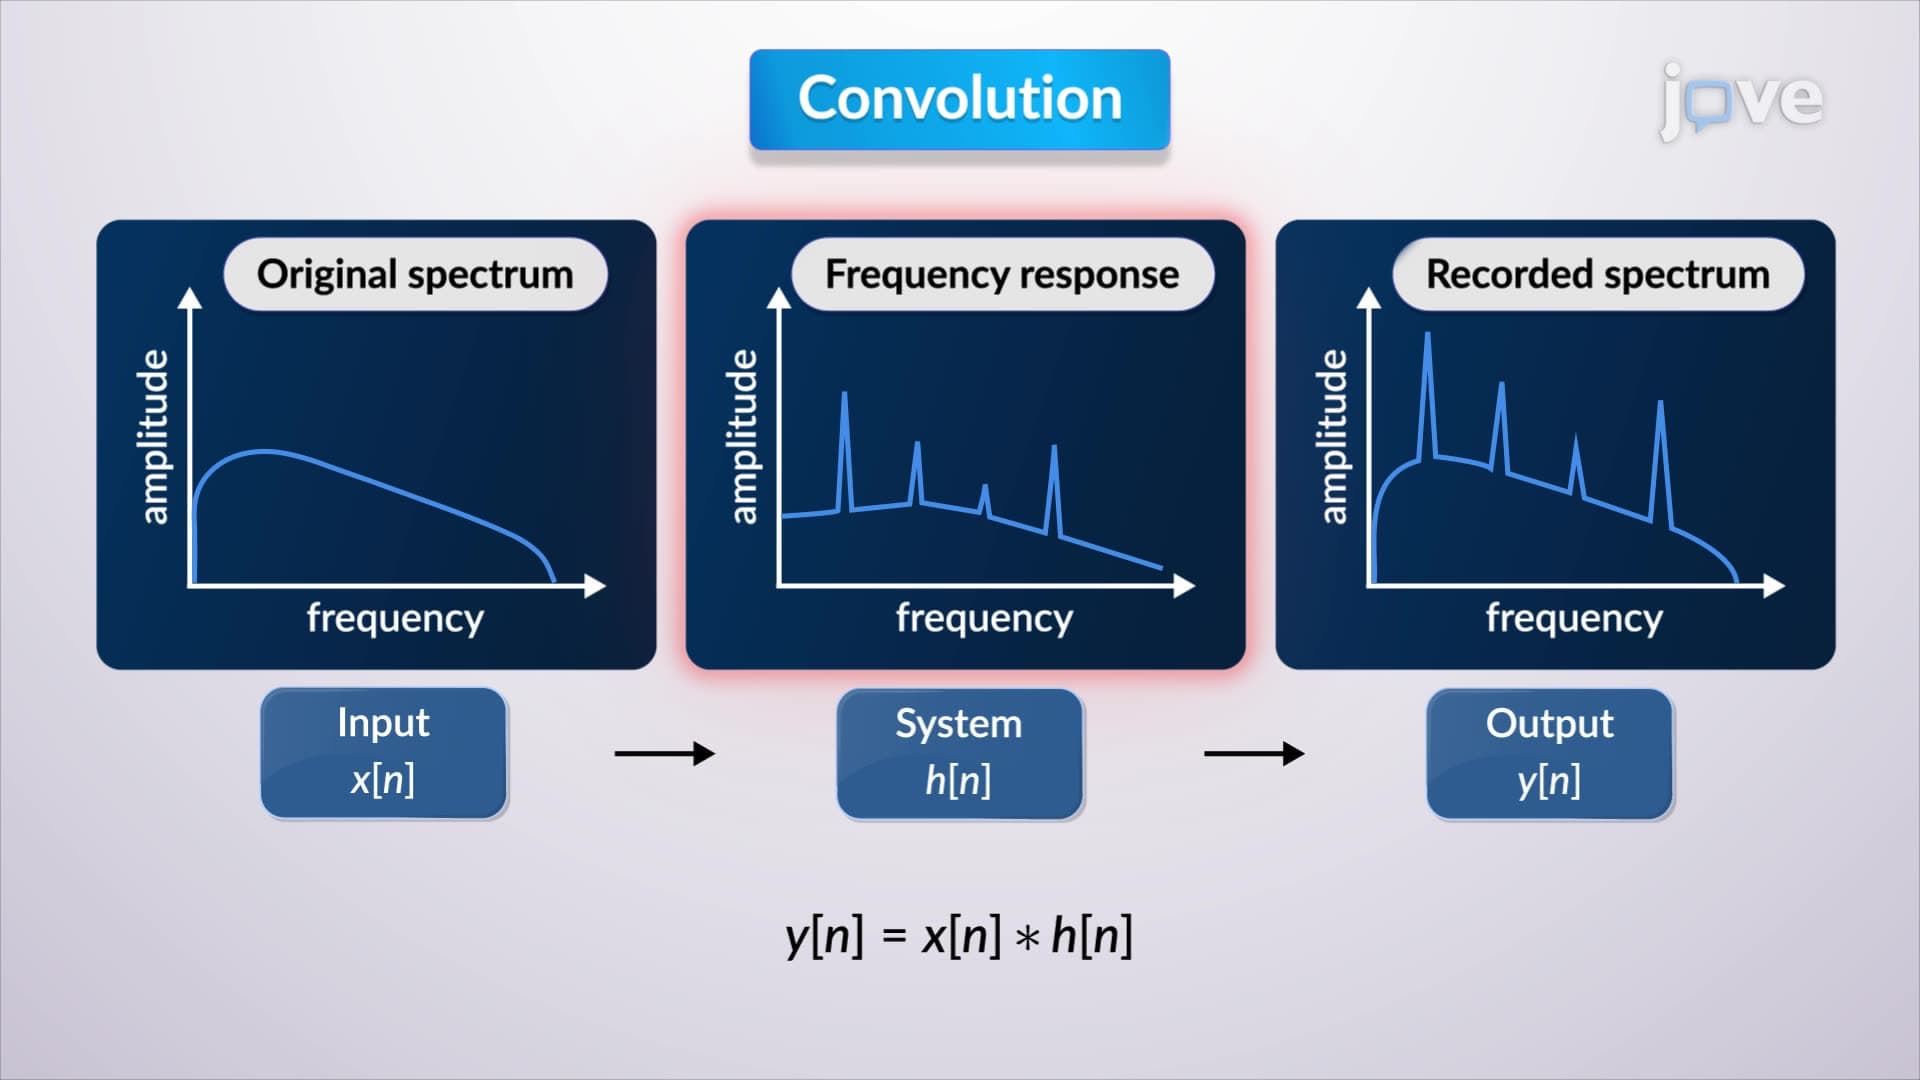
Deconvolution
543
Deconvolution, also known as inverse filtering, is the process of extracting the impulse response from known input and output signals. This technique is vital in scenarios where the system's characteristics are unknown, and they must be inferred from the observable signals.
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
543
 01:22
Force Classification
2.3K
Forces play a crucial role in the study of physics and engineering. They are essential in describing the motion, behavior, and equilibrium of objects in the physical world. Forces can be classified based on their origin, type, and direction of action.
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
2.3K
 01:27
Uniform Depth Channel Flow
527
Uniform depth channel flow keeps fluid depth consistent along channels such as irrigation canals. In natural channels, such as rivers, approximate uniform flow is often assumed. This condition occurs when the channel’s bottom slope matches the energy slope, balancing potential energy lost from gravity with head loss due to shear stress. This balance prevents depth changes along the channel length, resulting in a steady, uniform flow.Uniform flow in open channels with a constant cross-section...
527