相关实验视频
Updated: Jan 15, 2026
16:14
Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
14.1K
对于入境航班的4D轨迹预测
1Civil Aviation Ombudsman Training College, Civil Aviation Flight University of China, Guanghan, China.
Frontiers in neurorobotics
|October 8, 2025

概括
本研究引入了一种用于4D轨迹预测的新型混合模型,显著减少累积错误并提高预测准确性. 该方法提高了复杂的时空数据的计算效率和概括性.
科学领域:
- * 地理空间分析和人工智能
- *用于轨迹预测的先进算法
背景情况:
- *现有的4D轨迹预测方法面临着累积错误,复杂的时空特征和计算局限性的挑战.
- *精确建模动态运动对于各种应用至关重要.
研究的目的:
- * 开发一种高精度,可靠的4D轨道预测方法.
- * 克服当前模型在准确性,效率和概括性方面的局限性.
主要方法:
- *开发了一种混合模型,SVMD-DBO-RCBAM,集成了顺序变量模态分解 (SVMD),泥虫优化 (DBO) 和ResNet-CBAM.
- *主要创新包括频域特征脱,动态参数优化和增强的时空特征提取.
主要成果:
- * 在单步预测中达到0.0377的低经度平均绝对误差 (MAE),比基线模型提高38.5%.
- *在多步预测中,经度R2达到0.9844,累计错误率减少72.9%.
- * 证明了高精度和稳定性,预测误差四分区间范围 (IQR) 低于传统模型的10%.
结论:
- * 拟议的SVMD-DBO-RCBAM模型在4D轨迹预测方面提供了卓越的性能.
- *该方法有效地解决累积错误,并增强复杂的时空动态的建模.
- *结果表明,预测准确度,稳定性和概括能力的显著改善.
相关概念视频
 01:26
Orthogonal Trajectories
6
Orthogonal trajectories describe the geometric relationship between two families of curves that intersect each other at right angles. One illustrative case involves a family of parabolas that open sideways along the x-axis. These curves share a common shape but differ by a scaling parameter, resulting in a set of curves that all pass through the origin and widen at different rates.Determining Orthogonal TrajectoriesTo identify the orthogonal trajectories for these parabolas, the first step...
6
 01:24
Absolute Motion Analysis- General Plane Motion
536
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
536
 01:30
Derivatives of Inverse Trigonometric Functions
30
A ship tracking an approaching aircraft relies on geometric measurements to find out the aircraft’s position relative to the observer. By measuring the slant distance to the aircraft and the angle of elevation, the horizontal and vertical components of the distance can be obtained using trigonometric relationships. This geometric approach provides a basis for analyzing how the observed angle changes as the aircraft moves closer to the ship.To examine the mathematical behavior of the angle...
30
 01:07
End Point Prediction: Gran Plot
1.1K
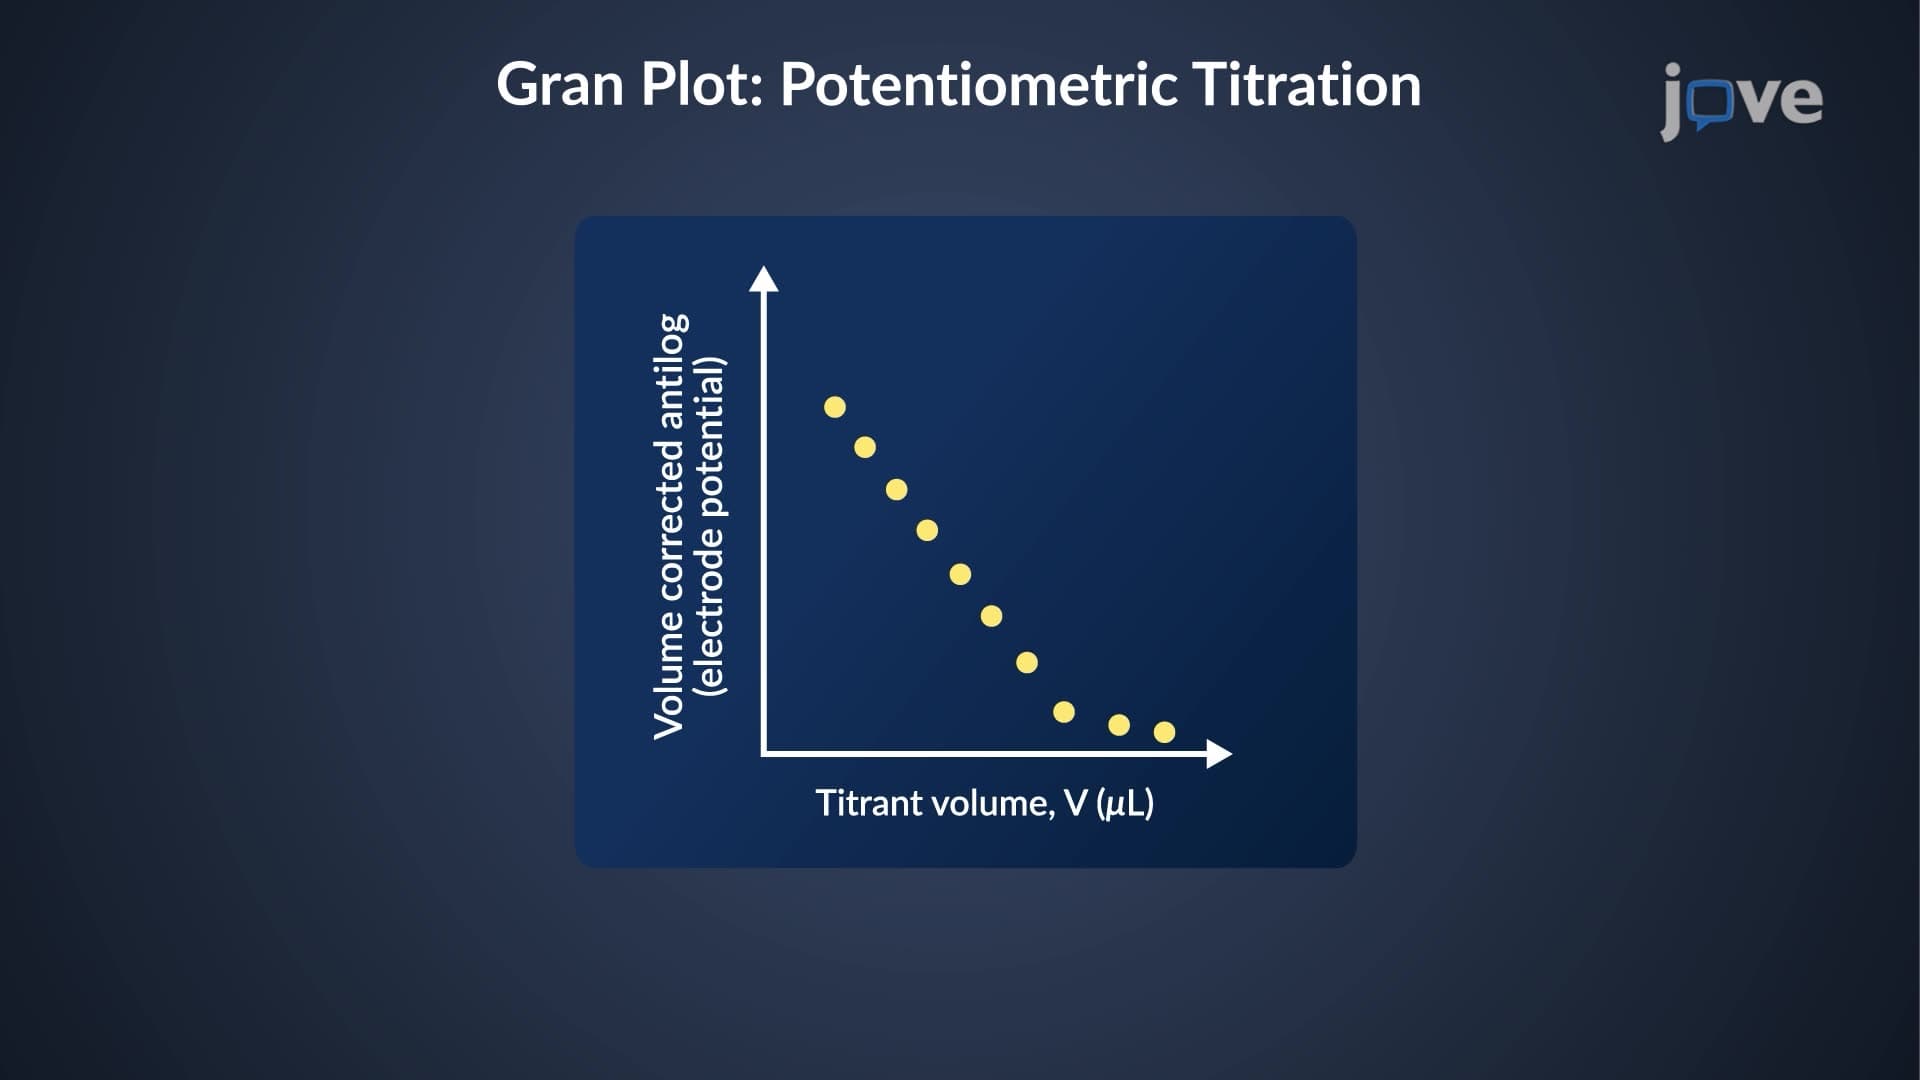
A Gran plot is used to predict the equivalence volume or endpoint of a potentiometric or acid-base titration without reaching the endpoint. Typically, titration data is collected as a function of the titrant's volume up to a point less than the equivalence volume and then transformed into a linear format. The straight line is extended to the x-axis, indicating the necessary titrant volume to achieve the equivalence point.
For potentiometric titration, the Gran plot is created by plotting...
For potentiometric titration, the Gran plot is created by plotting...
1.1K
 01:29
Application of Linearization and Approximation
37
A drone flying through complex terrain often relies on more than one sensing method to estimate small changes in altitude. Along with direct measurements, air pressure provides a useful indirect indicator of vertical movement. Atmospheric pressure decreases as altitude increases, and this relationship is commonly described using an exponential model. Although accurate, converting pressure measurements into altitude values requires calculations that are too complex to perform repeatedly during...
37
 01:24
Relative Motion Analysis - Velocity
691
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
691