

对于实时车辆状态估计和改善道路安全的TS模糊方法
Mohamed Saber1, Mohamed Ouahi2, Saad Motahhir3
1Laboratory of Applied Sciences and Emerging Technologies, National School of Applied Sciences, BP 72, My Abdallah Avenue Km. 5 Imouzzer Road, Fez, Morocco. mohamed.saber1@usmba.ac.ma.
Scientific reports
|October 8, 2025

概括
这项研究引入了一种新的Takagi-Sugeno (T-S) 模糊观察器,用于实时估计车辆动态和道路状况. 通过提高驾驶辅助系统的准确性和计算效率,先进的观察器提高了汽车安全性.
科学领域:
- 控制系统工程 控制系统工程
- 汽车工程 汽车工程
- 模糊逻辑系统 模糊逻辑系统
背景情况:
- 安全驾驶需要准确估计车辆动态和道路特性.
- 目前的方法,如比例多元积分观察器 (PMIO) 和模糊未知输入观察器 (FUIO),在实时应用方面存在局限性.
- 先进的驾驶辅助系统 (ADAS) 需要强大而高效的状态估计.
研究的目的:
- 开发一个计算效率高和强大的Takagi-Sugeno (T-S) 模糊功能观察器.
- 为了实时估计未测量的车辆状态 (侧滑角度,曲率,角位移) 和道路曲率.
- 克服嵌入式汽车系统现有观察员的局限性.
主要方法:
- 在观察者设计中利用了利亚普诺夫-克拉索夫斯基稳定理论.
- 用线性矩阵不等式 (LMI) 来进行参数优化.
- 开发了一个Takagi-Sugeno (T-S) 模糊的功能观察者架构.
主要成果:
- 拟议的TS模糊观察员与全序观察员 (FO),PMIO和FUIO相比,表现出更高的准确性和更快的趋同.
- 实现显著降低计算成本,确保实时可行性.
- 循环中的处理器 (PIL) 验证证实了其实际适用性.
结论:
- 新的TS模糊功能观察器为实时车辆状态估计提供了计算效率高和强大的解决方案.
- 它的性能优势使其适合集成到ADAS中,以提高驾驶安全.
- 该研究证实了观察员的新性和减少事故风险的实际潜力.
相关概念视频
 01:27
State Space Representation
528
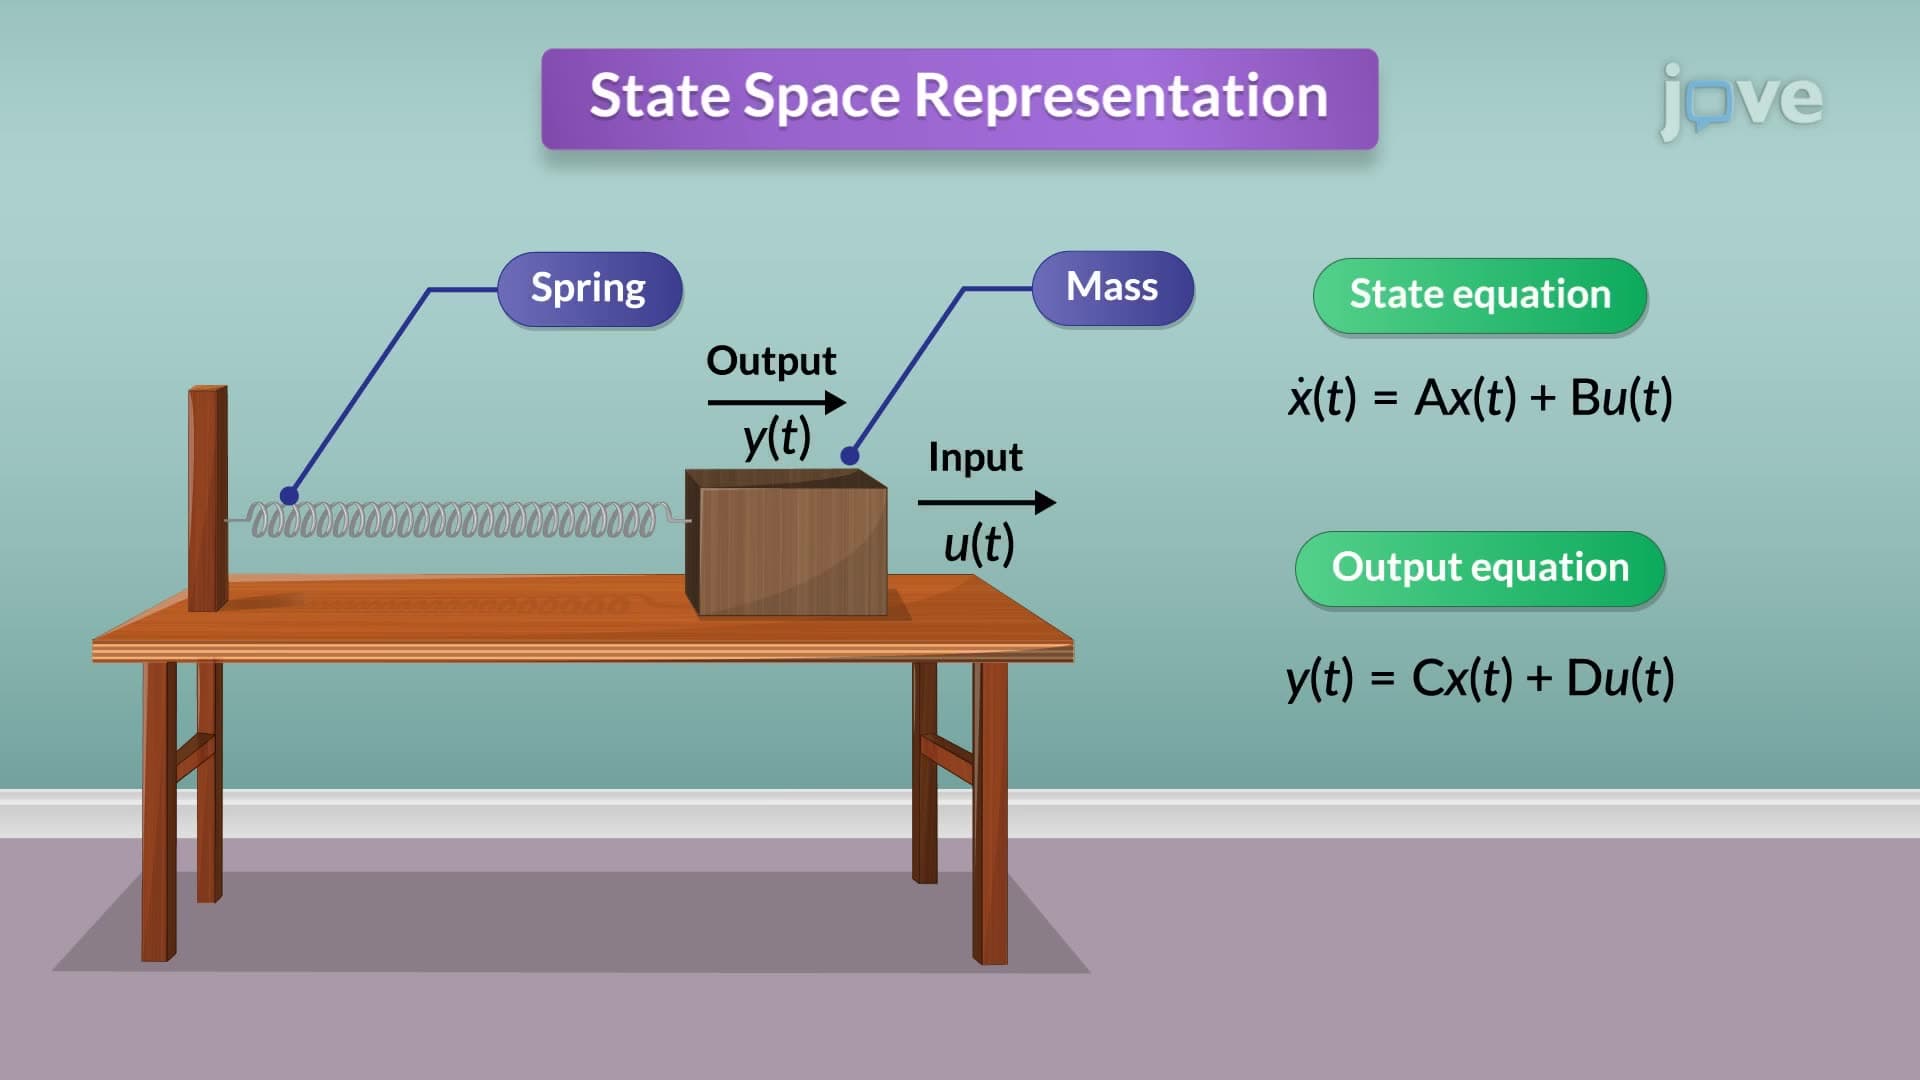
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
528
 01:26
Trapezoidal Rule
4
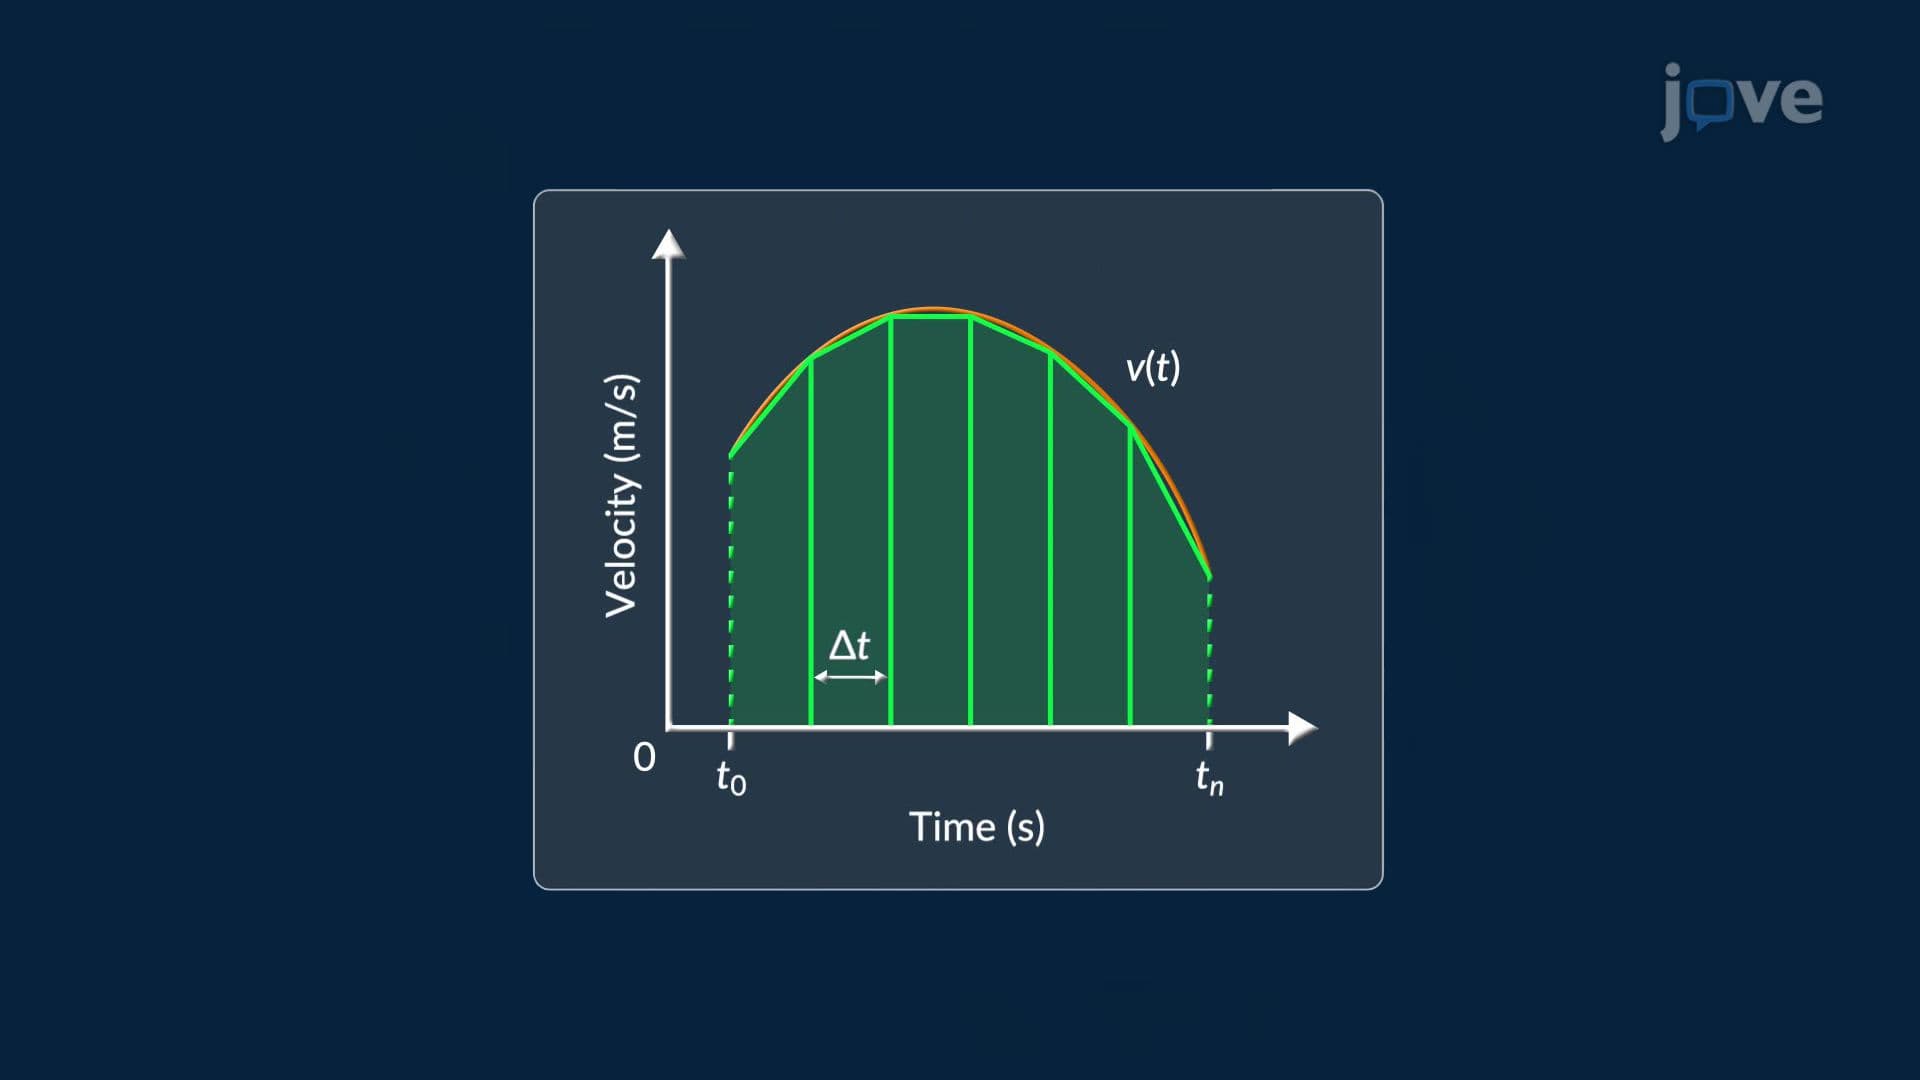
Estimating the distance traveled by a vehicle using its recorded velocity over time is a common problem in physics and engineering. When velocity data is available at discrete time intervals, rather than as a continuous function, numerical integration methods such as the trapezoidal rule are often employed to approximate the total displacement.The trapezoidal rule works by dividing the total time interval into several equal segments. Within each segment, the recorded velocities at the endpoints...
4
 01:29
Sight Distance in a Vertical Curve
317
Sight distance on vertical curves is critical in roadway design. It ensures drivers can see far enough ahead to identify and respond to hazards effectively. This directly impacts safety, driver comfort, and the overall efficiency of the transportation network.Vertical curves are classified into crest and sag curves based on their geometry. For crest curves, sight distance is determined by the line of sight between a driver's eye and a small object on the road's surface. Design parameters for...
317
 01:22
Multi-input and Multi-variable systems
389
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence of...
In the absence of...
389
 01:17
Design Example: Alignment of a Road Line Using GIS
331
The alignment of a road line using Geographic Information Systems (GIS) is a critical process in civil engineering, combining advanced technology with practical decision-making. This methodology begins with the collection of geospatial data, including information on land cover, geomorphology, drainage patterns, slope, and contour details. Such data is typically acquired through satellite imagery and GIS tools, offering a comprehensive understanding of the terrain.Once the data is gathered, it...
331
 01:21
State Space to Transfer Function
559
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
559