

基于离散自适应滑动模式算法的单相全桥逆变器控制,具有错误补偿
Yun Zhang1, Zhenyu Tang2, Fenghui Xu3
1School of Rail Transportation, Shandong Jiao Tong University, Jinan, China.
PloS one
|October 10, 2025

概括
这项研究简化了单相全桥逆变器控制,通过调整直流-直流逆变电路策略. 一种自适应的离散滑动模式控制方法显著减少了聊天,并提高了系统的准确性和防干扰能力.
科学领域:
- 电气工程 电气工程
- 控制系统 控制系统
- 电力电子 电力电子 电力电子
背景情况:
- 单相全桥逆变器在功率电子中至关重要.
- 传统的控制方法往往受到复杂性和喋喋不休的困扰.
- 提高反干扰和控制精度对于逆变器性能至关重要.
研究的目的:
- 为单相全桥逆变器提出简化和增强的控制策略.
- 为了减少控制过程的复杂性,并提高系统的反干扰能力.
- 为了尽量减少聊天和提高控制准确性,使用适应性方法.
主要方法:
- 在单相全桥逆变器和两个buck电路之间建立的控制过程等价性.
- 采用了用于实时输出电压跟踪的DC-DC电路控制策略.
- 一种新的自适应离散滑动模式控制 (SMC) 方法,采用动态增益调整.
- 滑动模式带宽,动范围和收步骤的数学证明.
主要成果:
- 拟议的方法简化了控制过程,并增强了反干扰.
- 适应式SMC通过动态调整接近速度来显著减少聊天.
- 滑动模式带宽从O(T) 减少到O(T^3),提高了控制精度.
- 证明了优越的电压跟踪速度,降低了稳定状态误差,并增强了干扰排斥.
结论:
- 拟议的控制策略为单相全桥逆变器控制提供了一种简化和有效的方法.
- 适应式离散滑动模式控制通过减少喋喋不休并提高准确性来显著提高性能.
- 该方法为需要精确电压跟踪和干扰排斥的应用提供了强大的解决方案.
更多相关视频
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
12.1K
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
9.1K
相关概念视频
 01:24
PI Controller: Design
1.2K
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
1.2K
 01:07
Time-Domain Interpretation of PD Control
371
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
371
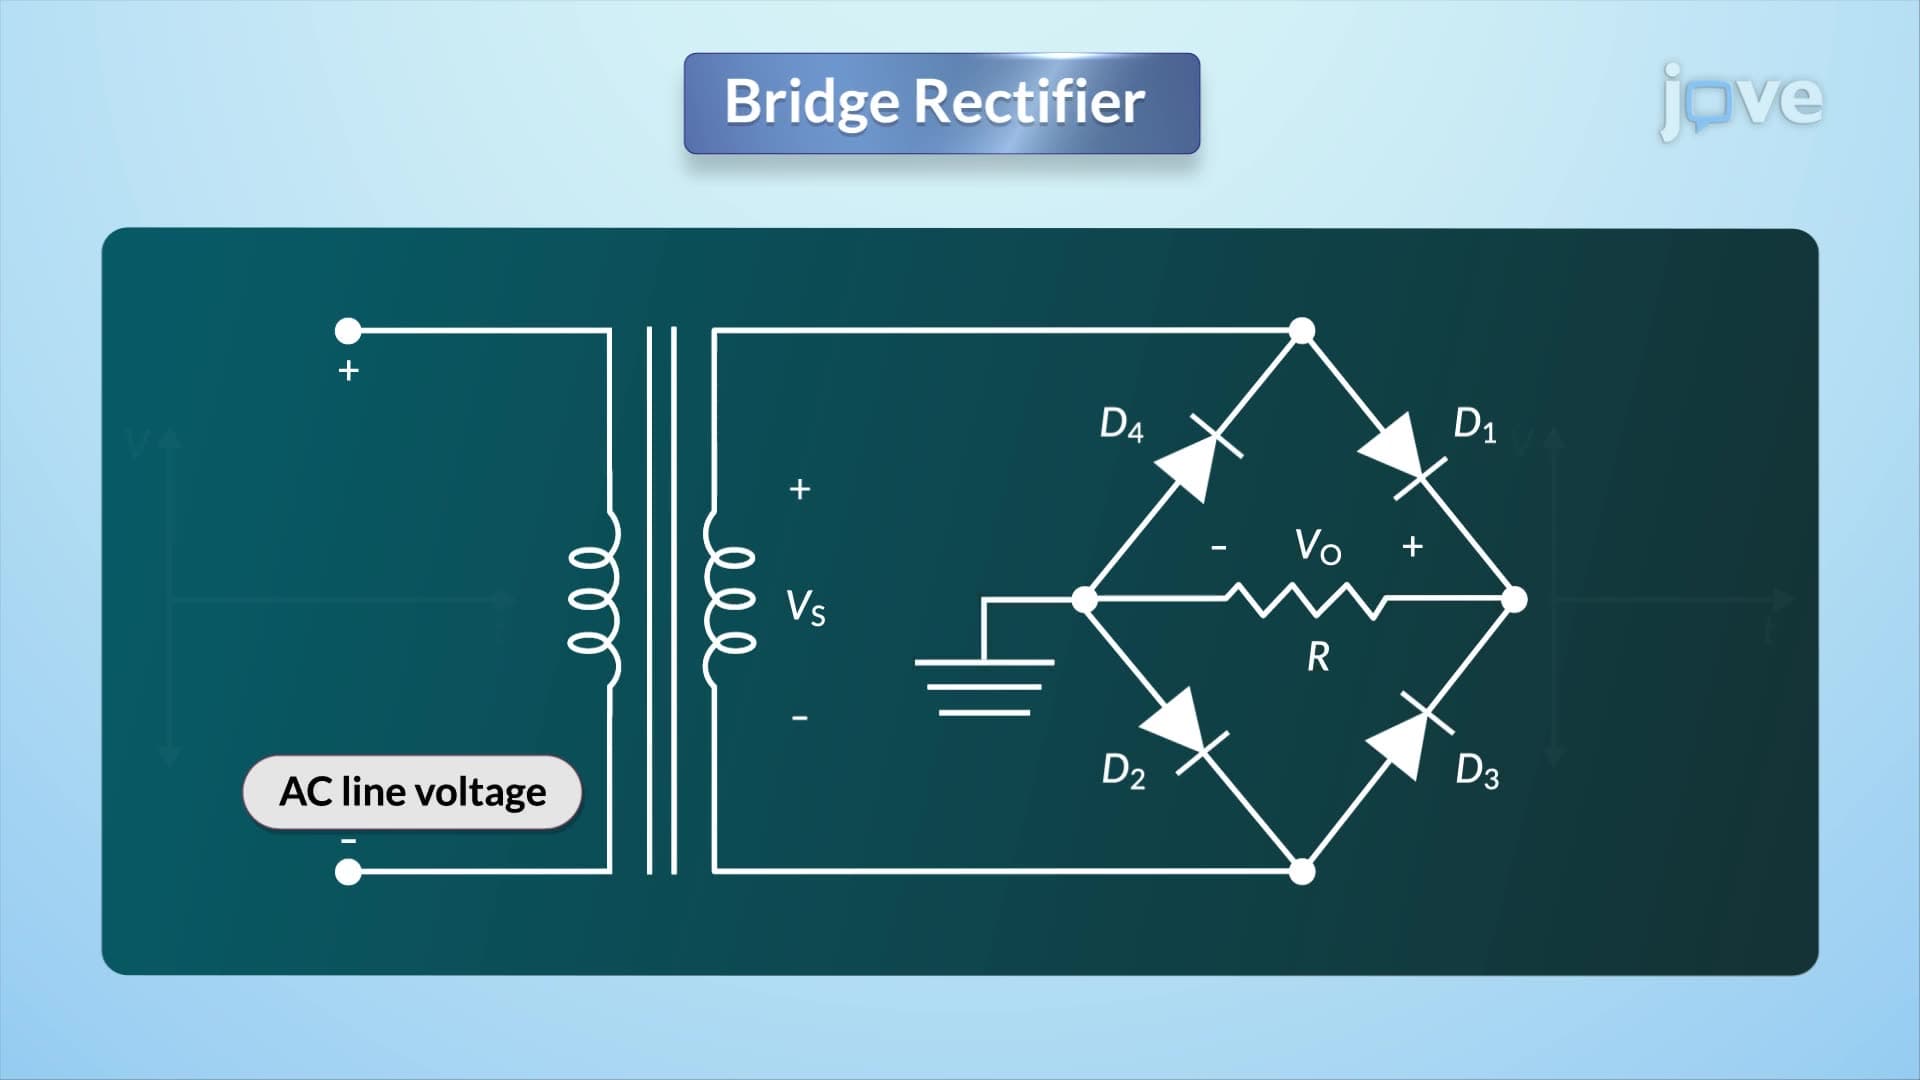 01:24
Bridge rectifier
1.5K
The bridge rectifier is essential in electronics for efficiently converting alternating current (AC) to direct current (DC). Comprised of four diodes configured in a bridge layout, this rectifier effectively processes both the positive and negative halves of the AC waveform, making it superior to half-wave and full-wave center-tapped rectifiers in terms of voltage regulation and output stability.
Operationally, the bridge rectifier allows current flow through two of its diodes during each...
Operationally, the bridge rectifier allows current flow through two of its diodes during each...
1.5K
 01:30
Control of Power Flow
672
There are several methods to control power flow in power systems:
672
 01:26
PD Controller: Design
622
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
622
 01:22
Controller Configurations
352
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
352