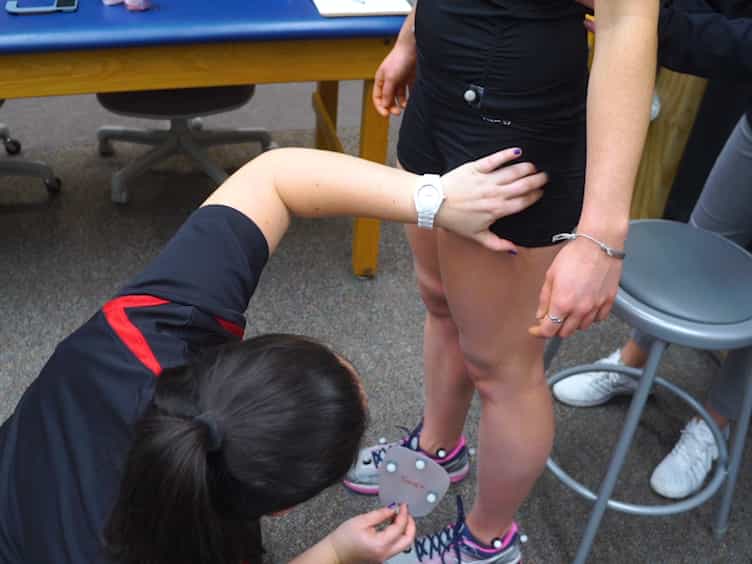
动态建模的干稳定性在运行通过关节-膝盖三对六个弹的弹
Hidaka Asai1,2, Tomoyuki Noda1, Jun Morimoto1,2
1Brain Robot Interface, ATR Computational Neuroscience Labs, Kyoto, Japan.
Bioinspiration & biomimetics
|October 15, 2025

概括
这项研究引入了一种新的跑步动态模型,证明协调的腿部肌肉可以在没有复杂的反的情况下稳定干位置. 这一发现为腿类机器人设计和康复提供了洞察力.
科学领域:
- 生物力学 生物力学
- 机器人技术 机器人技术 机器人技术
- 动态系统 动态系统
背景情况:
- 现有的弹质量机动车型往往忽略了干动力学或需要在线反以保持稳定性.
- 生物和机器人系统表明,肌肉协调,包括双节肌肉,可以通过更简单的控制器实现稳定.
研究的目的:
- 开发一个数学动态模型,验证协调的肌肉动作在运动过程中稳定了干位置.
- 研究单关节和双关节肌肉协调在腿部稳定的作用.
主要方法:
- 提出了一种带着干和六个弹模拟关节膝关节肌肉协调的平面运动模型.
- 使用恒定的着陆角和角来控制步态.
- 使用Floquet乘数器进行自我稳定性的数值分析.
主要成果:
- 动态模型实现了稳定的运行,只使用恒定的触地和角度.
- 数字分析证实了协调弹的各种刚性参数的自我稳定性.
- 证明了通过肌肉协调来稳定干位置的数学证据.
结论:
- 肌肉协调,结合双关节肌肉,可以本质上稳定行驶过程中干角.
- 为设计有腿机器人和评估康复策略提供了基础.

相关概念视频
 01:14
Stability of structures
481
In mechanical engineering, the stability of systems under various forces is critical for designing durable and efficient structures. One fundamental way to explore these concepts is by analyzing systems like two rods connected at a pivot point, O, with a torsional spring of spring constant k at the pivot point. This system is similar in appearance to a scissor jack used to change tires on a car. In this case, the arms of the linkage (equivalent to the rods in this system) are entirely vertical,...
481
 01:21
Rigid Body Equilibrium Problems - II
7.9K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.9K
 00:49
Rigid Body Equilibrium Problems - I
5.4K
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
5.4K
 01:30
Three-Dimensional Force System
2.8K
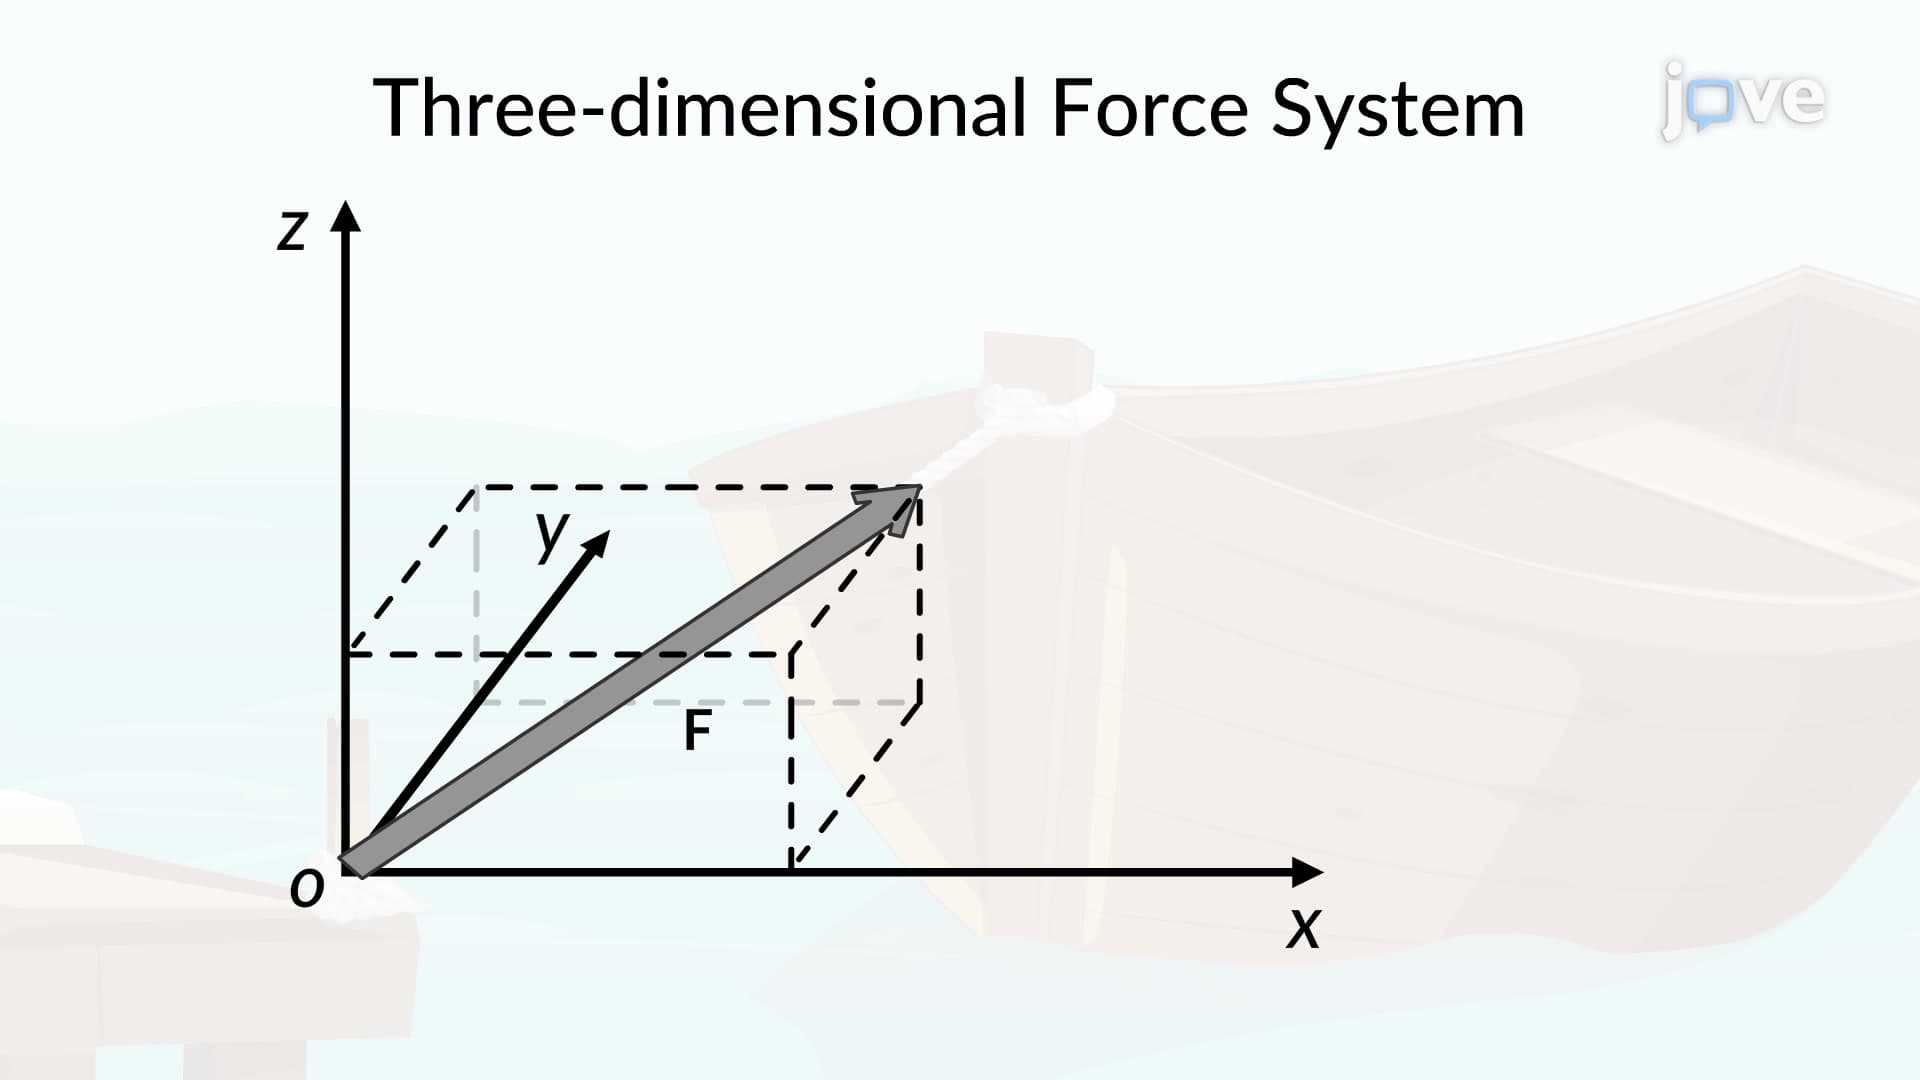
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
2.8K
 01:23
Euler's Formula to Columns: Problem Solving
931
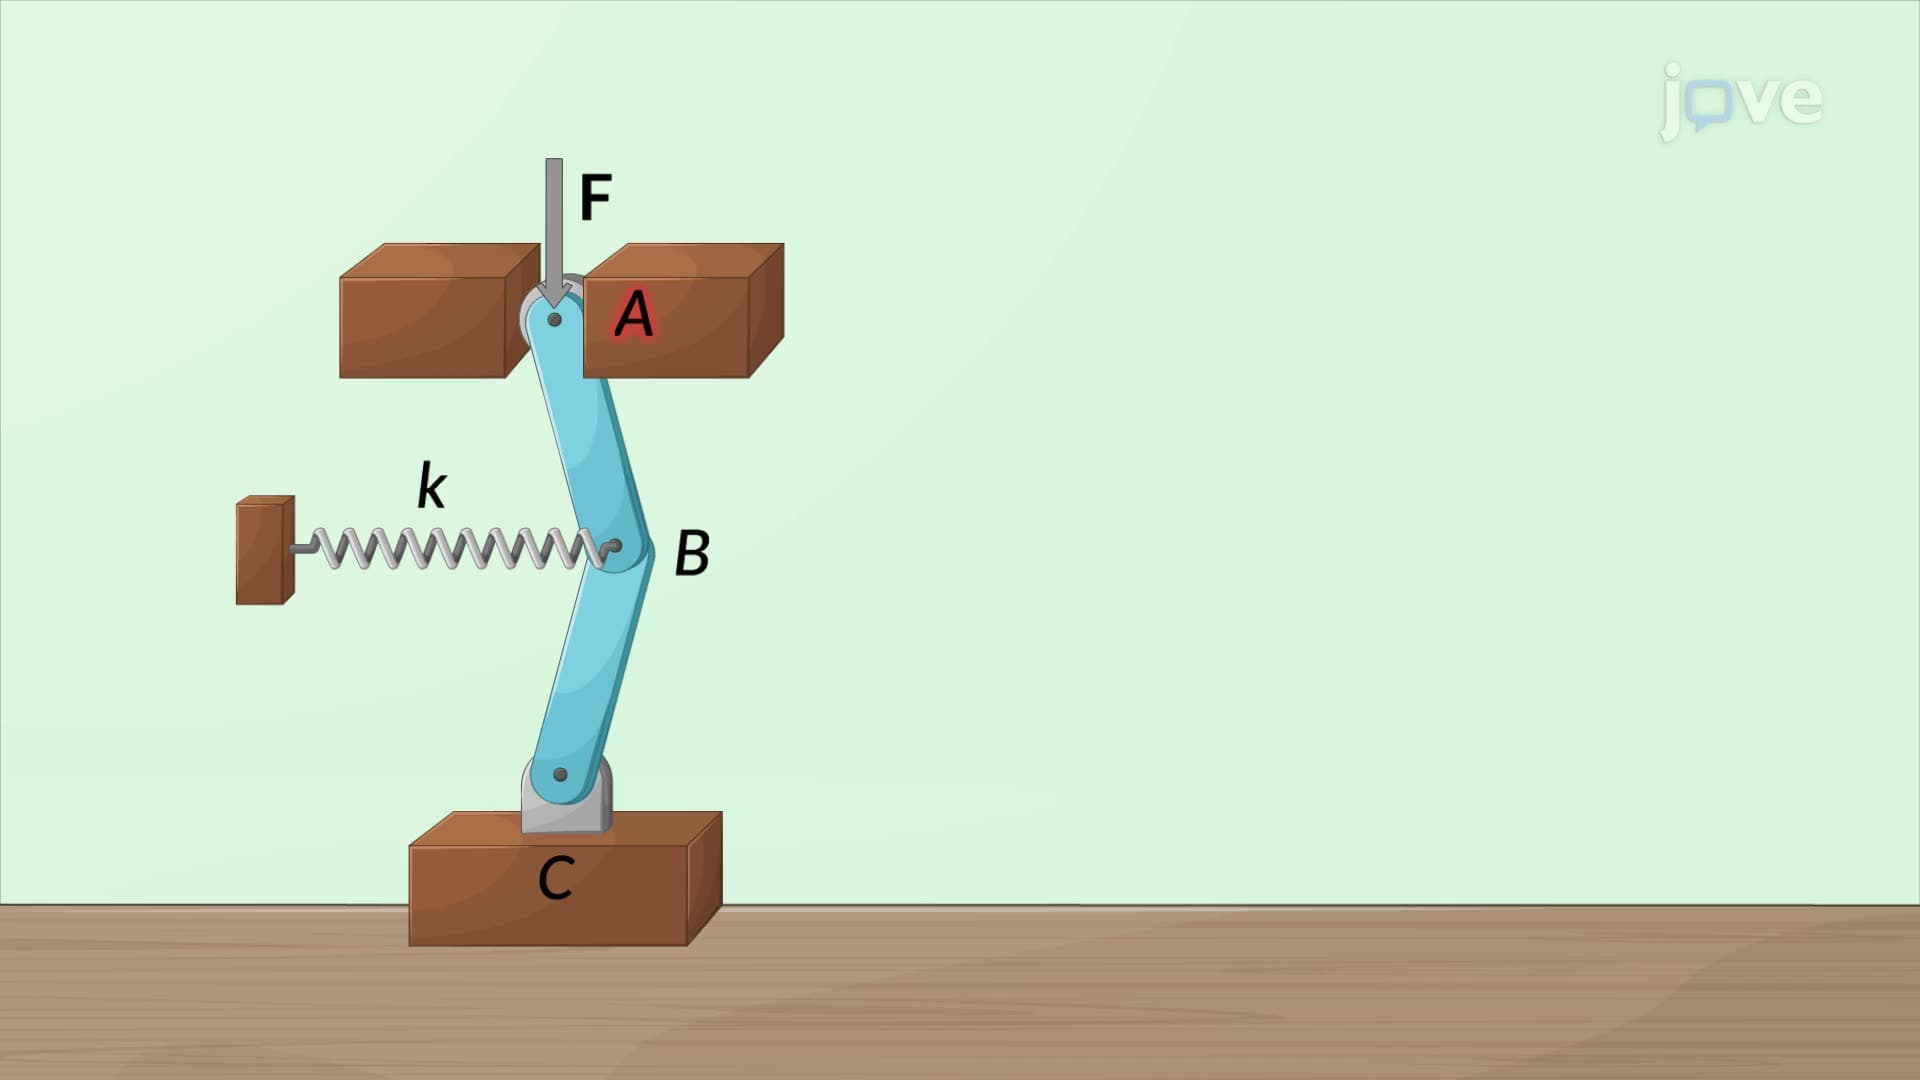
Euler's formula is used in structural engineering to determine the buckling load of columns under various conditions. However, when dealing with systems that incorporate both rigid elements and elastic components, such as springs, the analysis requires a finer approach to determine the critical load. The problem described involves two rigid bars connected at a pivot point with a spring attached and a vertical load applied at one end.
The system comprises two vertical rigid bars, AB and BC, of...
The system comprises two vertical rigid bars, AB and BC, of...
931
 01:30
Three-Dimensional Force System:Problem Solving
1.3K
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
1.3K