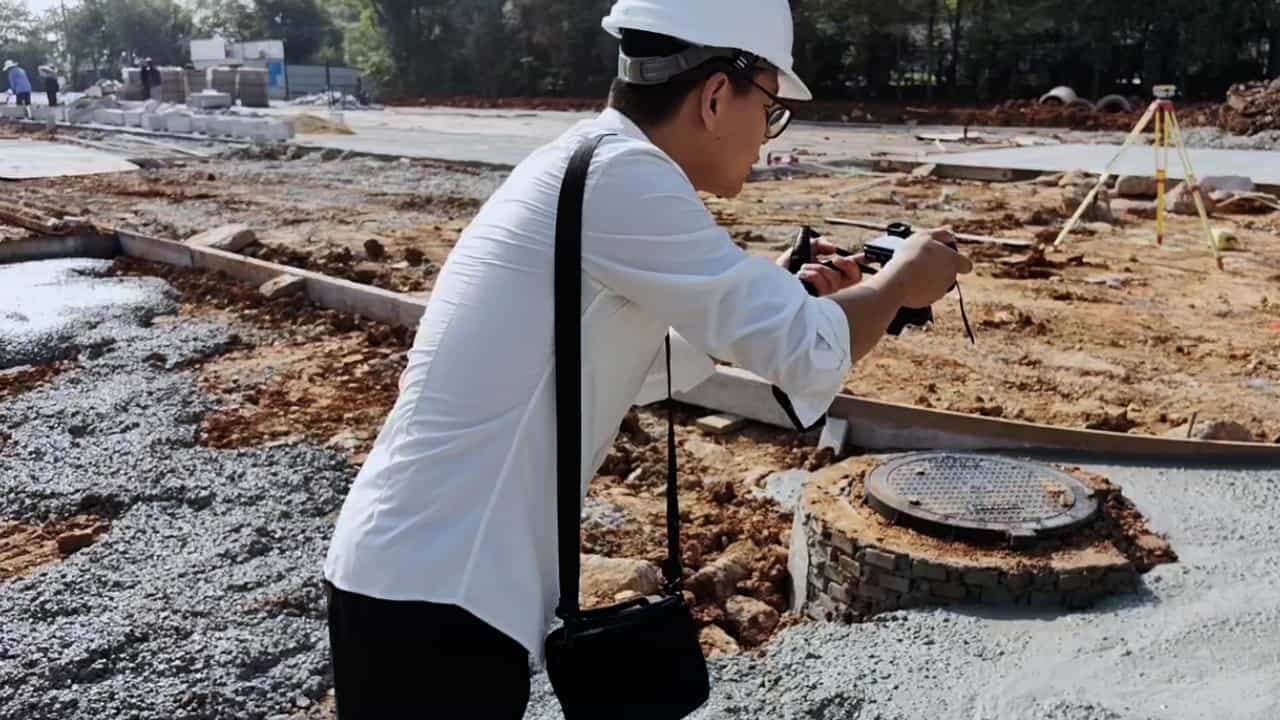

基于增强的ORB和YOLOv11的车下全景图像的轴型识别技术的研究
Xiaofan Feng1, Lu Peng1, Yu Tang2
1Research Institute of Highway Ministry of Transport, 8 Xitucheng Road, Beijing 100088, China.
Sensors (Basel, Switzerland)
|October 16, 2025

概括
这项研究引入了一种新的全景成像系统,用于在收费站识别卡车轴类型. 该技术使用增强的ORB和YOLOv11进行准确,快速的车辆分类,改善道路管理.
科学领域:
- 计算机视觉 计算机视觉
- 运输工程 运输工程
- 机器学习 机器学习
背景情况:
- 国家政策规定了严格的卡车尺寸和重量限制,需要为收费管理准确的轴类型识别.
- 目前用于区分驱动和驱动轴的现有方法在准确性,设备复杂性和图像证据方面存在局限性.
- 有效的车辆分类对于收费站运营和遵守法规至关重要.
研究的目的:
- 开发用于车辆底盘的快速准确的全景图像检测技术.
- 为了克服轴型识别和图像保留当前方法的局限性.
- 提供一个便携且易于部署的系统,用于现场识别轴.
主要方法:
- 使用区域阵列摄像头开发了一个便携式车辆底盘图像采集系统,以便快速部署.
- 增强的ORB与FeatureBooster (FB) 模块和关键技术被用于高质量的全景图像拼接.
- YOLOv11算法通过ORB和FB功能进行了微调,用于轴类型识别.
主要成果:
- 增强的ORB算法与FB模块增加了特征匹配到151 ± 18.
- 综合的YOLOv11,ORB和FB方法实现了高性能指标:mAP@50为0.989和mAP@50:95为0.780.
- 该系统在夜间场景中表现出强的性能,mAP@50为0.977和mAP@50:95为0.743.
结论:
- 拟议的全景图像检测技术在车辆轴类型识别方面取得了重大进展.
- 该系统的可移植性,快速部署和高精度为收费站提供了有效的技术支持.
- 这项技术解决了符合运输政策的有效和可靠的轴识别需求.
相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
876
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
876
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
695
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
695
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
752
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
752
 02:16
Light Acquisition
9.4K
In order to produce glucose, plants need to capture sufficient light energy. Many modern plants have evolved leaves specialized for light acquisition. Leaves can be only millimeters in width or tens of meters wide, depending on the environment. Due to competition for sunlight, evolution has driven the evolution of increasingly larger leaves and taller plants, to avoid shading by their neighbors with contaminant elaboration of root architecture and mechanisms to transport water and nutrients.
9.4K
 01:19
Azimuths and Bearings
579
Azimuths and bearings are essential concepts in surveying, providing methods to express the direction of a line relative to a meridian. Azimuths refer to the clockwise angle measured from the north end of a reference meridian to the given line, ranging from zero to 360 degrees. This method gives a comprehensive directional reference within a full 360-degree circle, making it a straightforward way to communicate direction in various fields, including navigation, cartography, and...
579
 01:26
Orthogonal Trajectories
6
Orthogonal trajectories describe the geometric relationship between two families of curves that intersect each other at right angles. One illustrative case involves a family of parabolas that open sideways along the x-axis. These curves share a common shape but differ by a scaling parameter, resulting in a set of curves that all pass through the origin and widen at different rates.Determining Orthogonal TrajectoriesTo identify the orthogonal trajectories for these parabolas, the first step...
6