

基于PSO算法的移动机器人本地化,本地最小值避免了健身功能
Božidar Bratina1, Dušan Fister1, Suzana Uran1
1Faculty of Electrical Engineering and Computer Science, University of Maribor, Koroška cesta 46, SI-2000 Maribor, Slovenia.
Sensors (Basel, Switzerland)
|October 29, 2025

概括
这项研究引入了一种新的粒子集群优化与避免局部最小值 (PSO-ALM) 算法,用于强大的移动机器人本地化. 通过防止本地化错误,PSO-ALM提高了准确性,在现实实验中表现优于其他方法.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
- 优化算法 优化算法
背景情况:
- 准确的移动机器人定位对于导航至关重要.
- 现有的方法,如测距和标准优化算法,由于环境干扰和局部最小值,可能会出现错误.
- 半人形移动机器人Pepper的本地化需要对现实世界的应用程序提供强大的解决方案.
研究的目的:
- 为强大的移动机器人本地化提出一种新的粒子群集优化与避免局部最小值 (PSO-ALM) 算法.
- 通过防止算法被局部最小值困住来提高本地化准确性.
- 通过对各种基准算法进行模拟和现实世界的实验来验证拟议的方法.
主要方法:
- 为PSO-ALM开发一种新的适应性功能,包括连续解决方案之间的完整性检查.
- 使用LIDAR数据实现PSO-ALM算法来定位Pepper移动机器人.
- 与标准粒子优化 (PSO),口量测量,遗传算法 (GA),GA-ALM,金优化 (GEO) 和GEO-ALM进行比较分析.
主要成果:
- 在LIDAR测量中,PSO-ALM算法证明了对LIDAR测量的干扰干扰的强大性能.
- 与标准PSO相比,PSO-ALM显著提高了定位准确性,并且提供了与GA和GEO算法相比的或更好的结果,特别是在初始旅行后.
- 避免局部最小值 (ALM) 扩展在防止优化算法陷入局部最小值的过程中被证明是有效的,PSO-ALM产生了最好的整体结果.
结论:
- 拟议的PSO-ALM方法允许移动机器人的准确和实时全球定位.
- 新的健身功能有效地防止算法误判机器人的位置,通过惩罚无意义的解决方案.
- PSO-ALM提供了一致和可预测的时间复杂性,使其适合于实际的机器人应用.

相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
693
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
693
 01:19
Root-Locus Method
470
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
470
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
282
Mechanistic models play a crucial role in algorithms for numerical problem-solving, particularly in nonlinear mixed effects modeling (NMEM). These models aim to minimize specific objective functions by evaluating various parameter estimates, leading to the development of systematic algorithms. In some cases, linearization techniques approximate the model using linear equations.
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
282
 01:03
Centroid of a Body: Problem Solving
1.8K
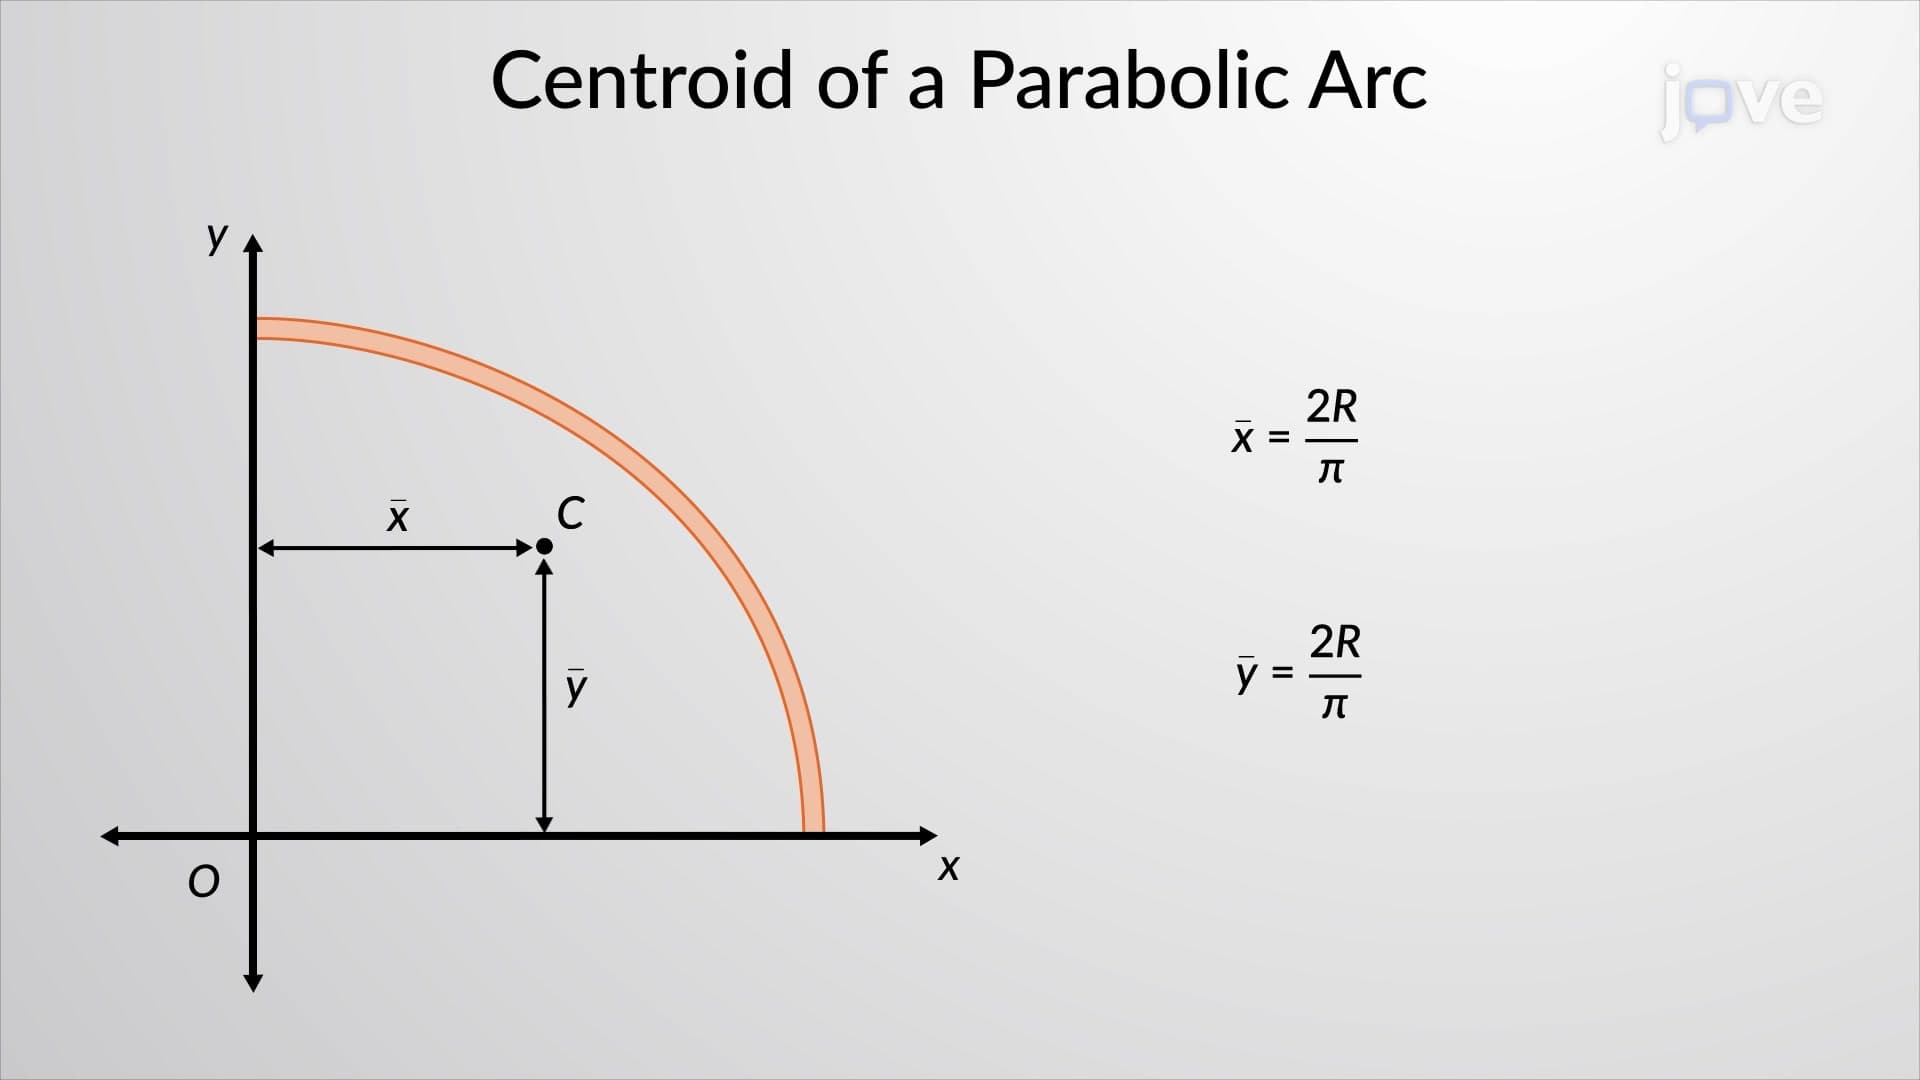
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.8K
 01:12
Reduced Mass Coordinates: Isolated Two-body Problem
2.3K
In classical mechanics, the two-body problem is one of the fundamental problems describing the motion of two interacting bodies under gravity or any other central force. When considering the motion of two bodies, one of the most important concepts is the reduced mass coordinates, a quantity that allows the two-body problem to be solved like a single-body problem. In these circumstances, it is assumed that a single body with reduced mass revolves around another body fixed in a position with an...
2.3K
 01:30
Three-Dimensional Force System:Problem Solving
1.3K
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
1.3K