
时间延迟坐标中的不变量,用于独特的动态系统识别
Jonah Botvinick-Greenhouse1, Robert Martin2, Yunan Yang3
1Cornell University, Center for Applied Mathematics, Ithaca, New York 14853, USA.
Physical review letters
|October 31, 2025

概括
时间延迟坐标中的不变量可以识别系统动态,在与多个可观测物相结合时解决模糊性. 这种方法可以在物理系统中实现可靠的系统识别,即使数据混乱或杂.
科学领域:
- 动态系统和混沌理论
- 非线性动力学是一种非线性动力学.
- 统计物理 统计物理
背景情况:
- 不变量测量对于分析复杂的物理系统至关重要,因为直接轨迹分析是不可行的.
- 在状态坐标中的传统不变量测量通常无法独特地识别系统动态.
- 混乱和噪音对传统的动态系统分析构成重大挑战.
研究的目的:
- 证明时间延迟坐标中的不变量可以独特地识别系统动态.
- 通过使用不变量测量来解决系统识别中的剩余模两可.
- 在实际的物理系统中提供一个可靠的系统识别框架.
主要方法:
- 使用系统可观测的时间延迟嵌入来制定不变量测量.
- 结合来自多个延迟的不变测量与不同的可观测值.
- 分析与可观测的信息性和延迟参数 (m,t) 相关的理论保证和限制.
主要成果:
- 时间延迟坐标中的不变量测量可以识别到拓连接的动态.
- 通过将多个延迟和可观测的测量结果结合起来来实现独特的系统识别.
- 该方法的有效性通过物理实例得到验证,证明了强大的系统识别.
结论:
- 时间延迟坐标嵌入提供了一种强大的方法,通过不变的措施来实现独特的系统识别.
- 多个可观察值和延迟的组合克服了单一测量方法的局限性.
- 这种方法为分析复杂和杂的物理系统提供了实用工具.

相关概念视频
 01:23
Linear time-invariant Systems
859
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
859
 01:31
Classification of Systems-II
452
Continuous-time systems have continuous input and output signals, with time measured continuously. These systems are generally defined by differential or algebraic equations. For instance, in an RC circuit, the relationship between input and output voltage is expressed through a differential equation derived from Ohm's law and the capacitor relation,
452
 01:28
Stability
368
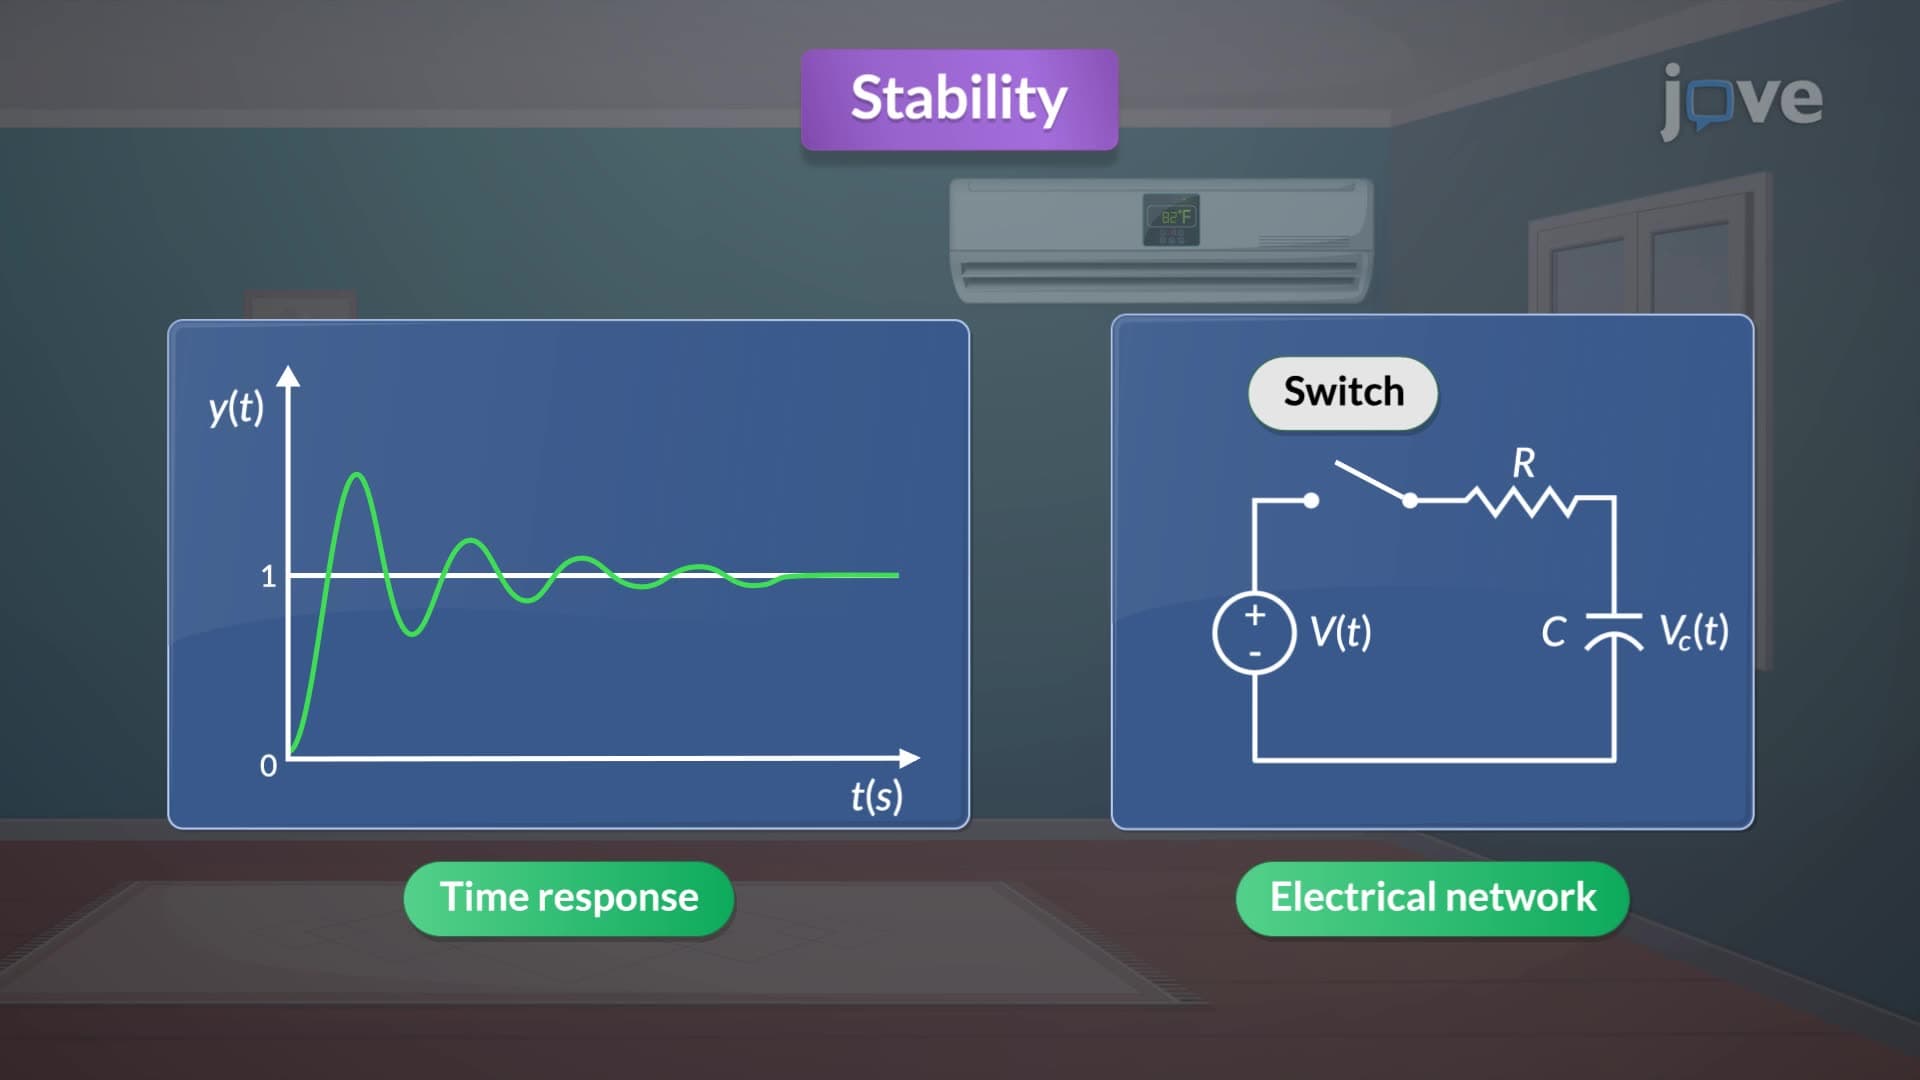
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
368
 01:21
Linear Approximation in Time Domain
334
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
334
 01:21
First Order Systems
387
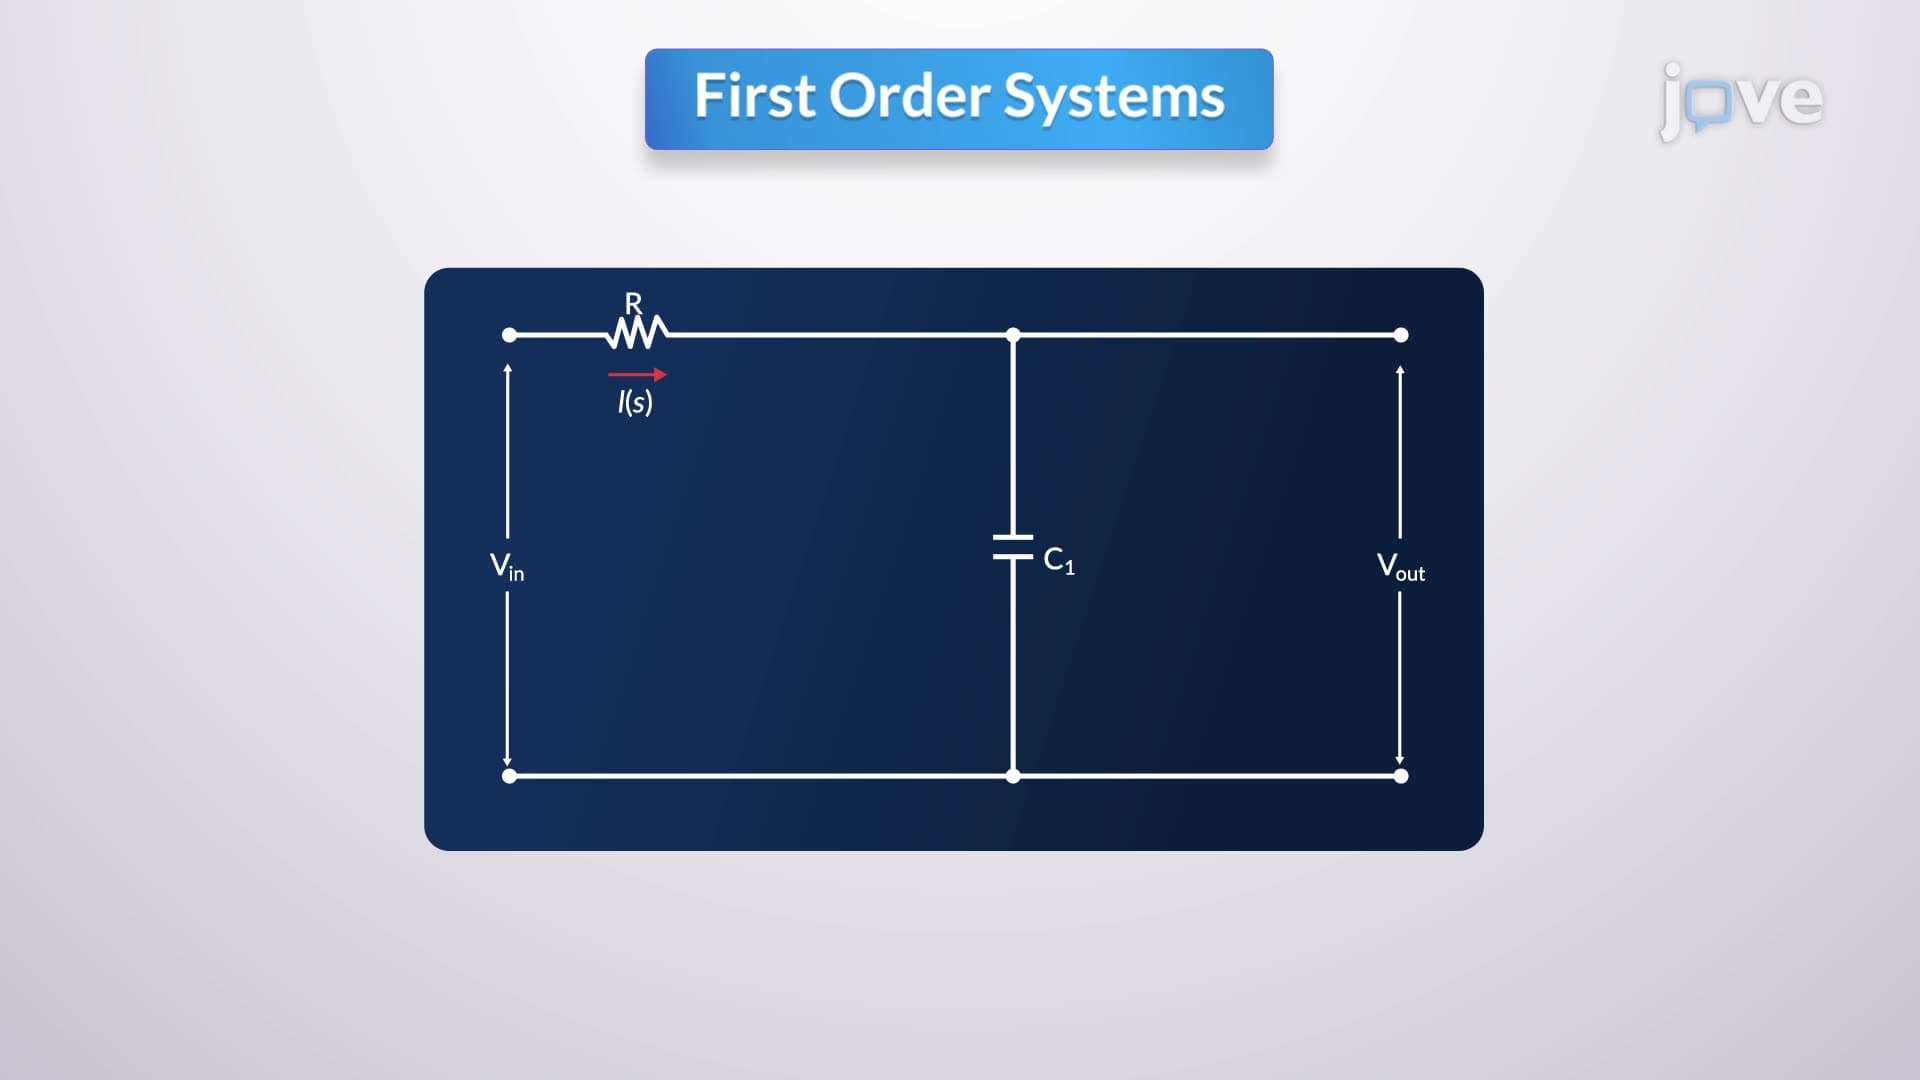
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
387
 01:24
BIBO stability of continuous and discrete -time systems
877
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
877