非自主级凸凸微分方程:在光学光模型中的均稳定性或双稳定性的条件
J Dueñas1,2, C Núñez2,3, R Obaya2,3
1Departamento de Matemática Aplicada, Universidad de Valladolid, Escuela de Ingeniería Informática de Valladolid, P de Belén 15, 47011 Valladolid, Spain.
Chaos (Woodbury, N.Y.)
|November 4, 2025

概括
这项研究探讨了使用非自主Bonifacio-Lugiato模型的光学超光学动态. 我们发现该系统表现出基于输入函数的双稳定性或均稳定性.
科学领域:
- 非线性动力学是一种非线性动力学.
- 量子光学是一种量子光学.
- 光学工程是指光学工程.
背景情况:
- 波尼法西奥-卢吉亚托模型描述了光学超光,这是一种涉及连贯光发射的现象.
- 了解这些系统的长期动态对于开发先进光学设备至关重要.
- 之前的研究集中在自主版本上,使得非自主动态的探索较少.
研究的目的:
- 为了研究非自主Bonifacio-Lugiato模型的长期动态.
- 为了分析系统对依赖时间的输入函数的响应, Λ ((t).
- 在光学超光中确定双稳定性和均稳定性的条件.
主要方法:
- 使用标量普通微分方程进行数学建模.
- 对凸自主函数和时间依赖输入的分析.
- 应用非自主分叉方法和快慢系统分析.
主要成果:
- 当输入的 Λ (t) 处于特定的间隔内时,双位性通常会发生.
- 导出了双稳定性的必要条件和充分条件.
- 确定统一的稳定性是当这些条件不满足时的一般反应.
- 在缓慢的时间尺度上分析周期性输入,确认均稳定性或双稳定性.
结论:
- 系统的稳定性 (均或双稳定) 关键取决于时间依赖输入函数的特征.
- 非自主分叉理论为理解复杂的光学动态提供了一个框架.
- 这项研究为潜在的应用提供了对控制光学超光的见解.
相关概念视频
 01:04
Oscillations about an Equilibrium Position
6.6K
Stability is an important concept in oscillation. If an equilibrium point is stable, a slight disturbance of an object that is initially at the stable equilibrium point will cause the object to oscillate around that point. For an unstable equilibrium point, if the object is disturbed slightly, it will not return to the equilibrium point. There are three conditions for equilibrium points—stable, unstable, and half-stable. A half-stable equilibrium point is also unstable, but is named so...
6.6K
 01:24
BIBO stability of continuous and discrete -time systems
877
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
877
 01:23
Stability of Equilibrium Configuration
771
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
771
 01:13
Stability of Equilibrium Configuration: Problem Solving
973
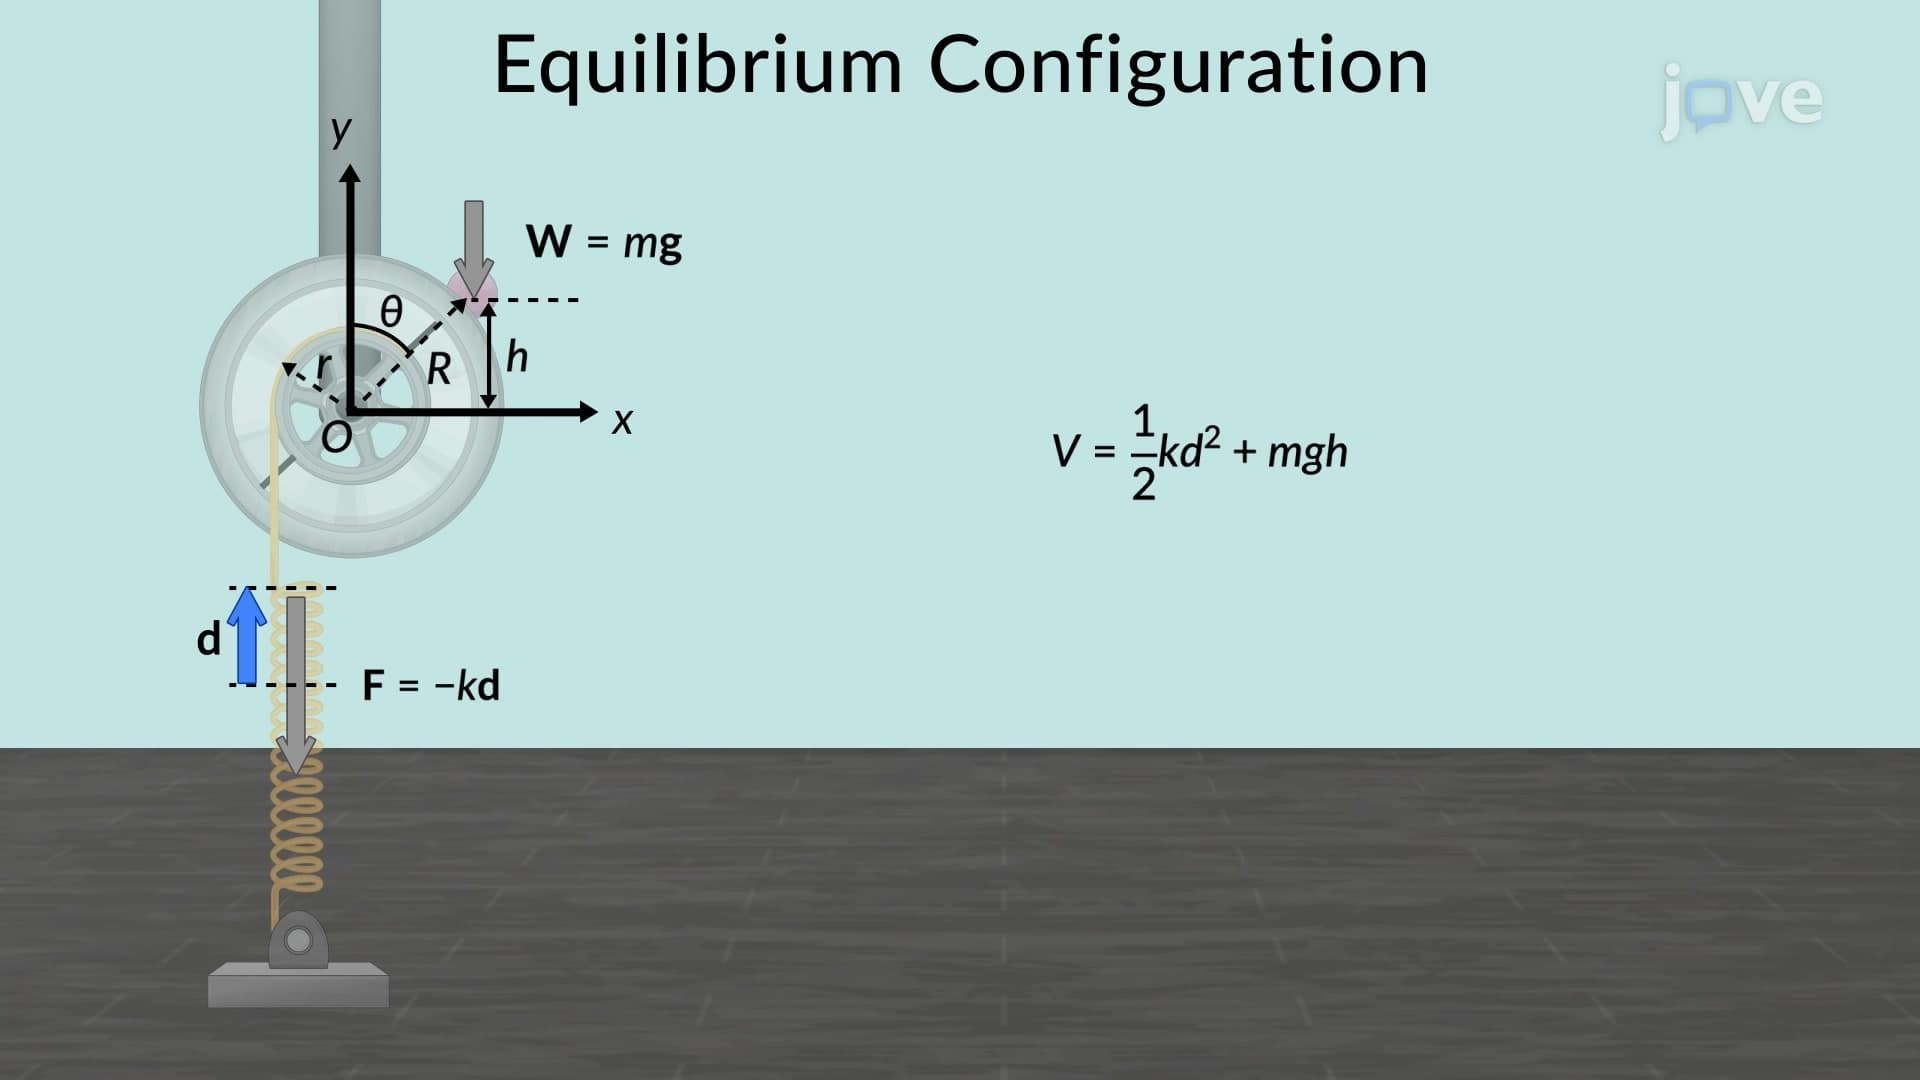
The stability of equilibrium configurations is an important concept in physics, engineering, and other related fields. In simple terms, it refers to the tendency of an object or system to return to its equilibrium position after being disturbed. The stability of an equilibrium configuration can be analyzed by considering the potential energy function of the system and examining its behavior near the equilibrium point.
Problem-solving in the context of the stability of equilibrium configuration...
Problem-solving in the context of the stability of equilibrium configuration...
973
 01:24
One-Degree-of-Freedom System
796
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
796
 01:28
Stability
368
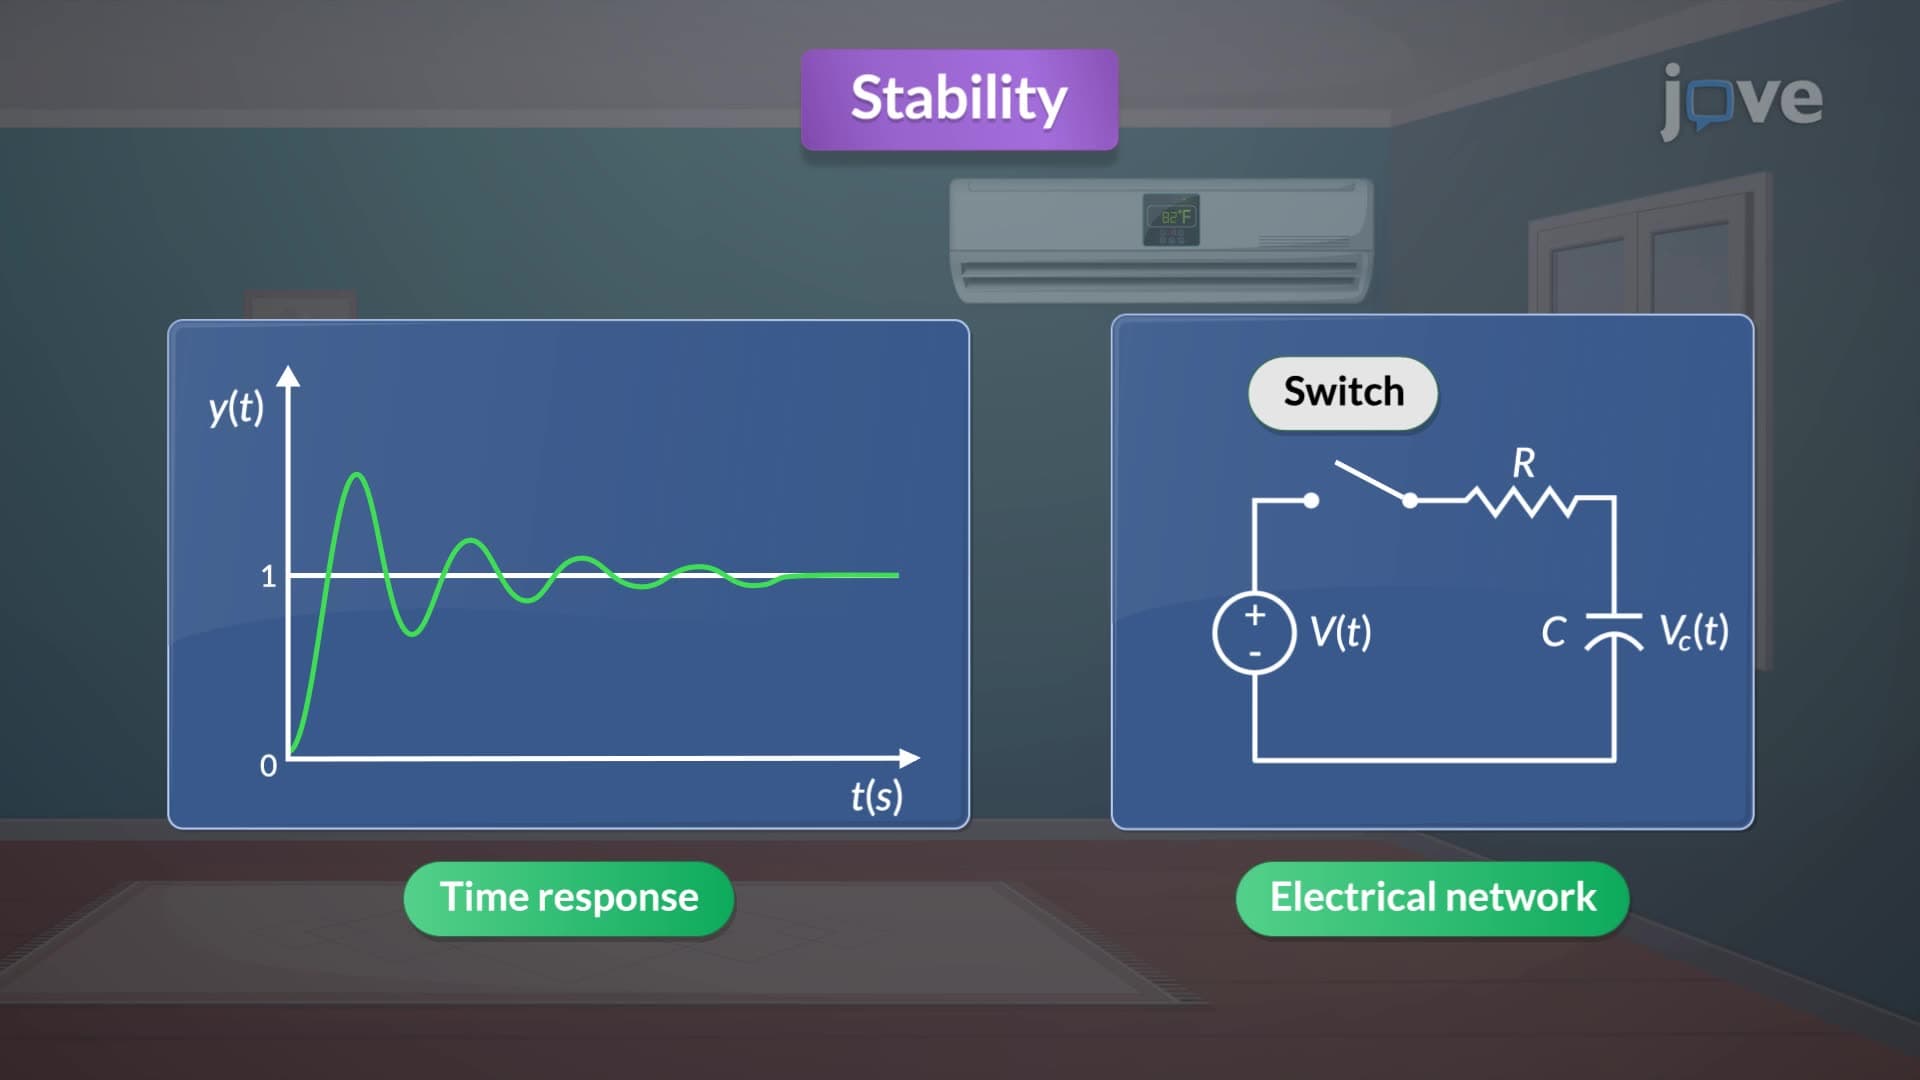
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
368