相关实验视频
Updated: Jan 12, 2026

10:09

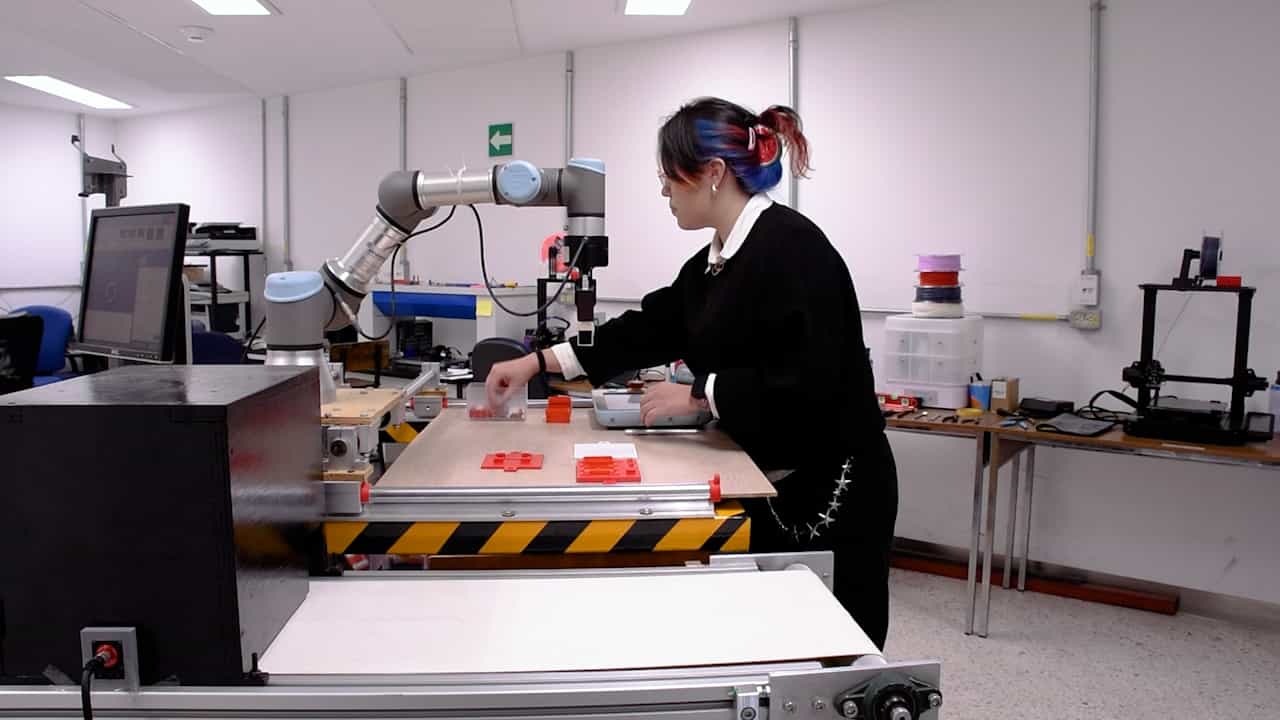
Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
7.0K
一个精确预定义的时间收屏障RNN,用于在未知边界噪声下协同控制双臂机器人的位置和方向
IEEE transactions on cybernetics
|November 7, 2025

概括
这项研究引入了双臂机器人的新控制方案,允许精确控制终端效应器位置. 一个新的神经网络确保了即使在噪声下也能快速,准确地融合,验证了其在现实应用中的有效性.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 人工智能的人工智能
背景情况:
- 双臂机器人需要精确的控制来完成诸如对象操纵等任务.
- 现实世界中的机器人系统面临着噪音和时间限制的挑战.
- 现有的控制方法可能不符合严格的性能要求.
研究的目的:
- 为双臂机器人提出一种新的协作位置和方向控制方案 (CPOCS).
- 制定控制策略,确保高精度的位置控制,同时保持方向.
- 解决实时控制挑战,包括未知边界噪声和严格的时间响应.
主要方法:
- 引入一个精确的预定义时间的融合屏障循环神经网络 (PCB-RNN).
- 为PCB-RNN.N.开发一种新的断片式屏障进化公式.
- 理论分析以证明在各种条件下趋同能力.
- 在双臂机器人平台上进行模拟和物理实验.
主要成果:
- 拟议的CPOCS实现了高精度的终端效应器定位.
- 在未知边界噪声下,PCB-RNN精确地证明了预定义时间收 (PPTC).
- 通过广泛的模拟和实验验证控制方案的有效性.
- 在融合速度和准确性方面,PCB-RNN的性能优于现有的循环神经网络.
结论:
- 新的CPOCS是有效的双臂机器人控制.
- 该PCB-RNN提供先进的PPTC功能,对噪声强大.
- 提出的方法为实际的机器人控制应用提供了可靠的解决方案.

相关概念视频
 01:24
One-Degree-of-Freedom System
792
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
792
 01:24
Sequence Networks of Rotating Machines
477
A Y-connected synchronous generator, grounded through a neutral impedance, is designed to produce balanced internal phase voltages with only positive-sequence components. The generator's sequence networks include a source voltage that is exclusively in the positive-sequence network. The sequence components of line-to-ground voltages at the generator terminals illustrate this configuration.
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
477
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
689
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
689
 01:17
Open and closed-loop control systems
1.5K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.5K
 01:23
Linear time-invariant Systems
856
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
856
 01:16
Statically Indeterminate Problem Solving
675
Statically indeterminate problems are those where statics alone can not determine the internal forces or reactions. Consider a structure comprising two cylindrical rods made of steel and brass. These rods are joined at point B and restrained by rigid supports at points A and C. Now, the reactions at points A and C and the deflection at point B are to be determined. This rod structure is classified as statically indeterminate as the structure has more supports than are necessary for maintaining...
675