
改进了基于多细胞超体顶部建模和双层优化智能汽车的强大模型预测轨迹跟踪控制
Xiaoyu Wang1,2, Guowei Dou2, Te Chen2
1School of Mechanical and Electrical Engineering, Suzhou Polytechnic University, Suzhou 215000, China.
Sensors (Basel, Switzerland)
|November 13, 2025

概括
这项研究引入了一种改进的可靠模型预测控制 (RMPC) 用于车辆轨迹跟踪. RMPC方法提高了对模型参数不确定性的控制精度和稳定性,提高了安全性.
科学领域:
- 汽车工程 汽车工程
- 控制系统理论 控制系统理论
- 机器人技术 机器人技术 机器人技术
背景情况:
- 车辆轨迹跟踪对于自动驾驶至关重要.
- 模型参数的不确定性对控制系统性能构成重大挑战.
- 传统模型预测控制 (MPC) 可以对这些扰动敏感.
研究的目的:
- 提出一个改进的强大的模型预测控制 (RMPC) 方法.
- 为了解决车辆轨迹跟踪控制中的模型参数扰动问题.
- 提高车辆控制系统的稳定性和实时性能.
主要方法:
- 使用了两度自由度的车辆模型和Serret Frenet错误模型.
- 采用多细胞超立方体顶点建模来表示参数不确定性.
- 实现了双层优化,具有有限时间域优化和终端约束.
- 整合了利亚普诺夫理论来设计一个控制不变集合.
主要成果:
- 峰值侧向偏差从1.0米减少到0.2米.
- 汇聚的航向偏差在2度以内.
- 与传统的MPC相比,平均和根平均平方控制错误显著减少.
- 在参数扰动下表现出良好的稳定性和实时性能.
结论:
- 拟议的RMPC方法有效地处理车辆模型参数扰动.
- 在复杂的道路条件和车辆状态转换中,RMPC提供了卓越的性能.
- 这种方法提高了车辆轨迹跟踪控制的可靠性和安全性.


相关概念视频
 01:24
One-Degree-of-Freedom System
792
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
792
 01:22
Planar Rigid-Body Motion
956
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
956
 01:06
Virtual Work for a System of Connected Rigid Bodies
714
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
714
 01:17
Kinematic Equations - II
12.9K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
12.9K
 01:18
Kinematic Equations - III
10.2K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
10.2K
 01:03
Centroid of a Body: Problem Solving
1.8K
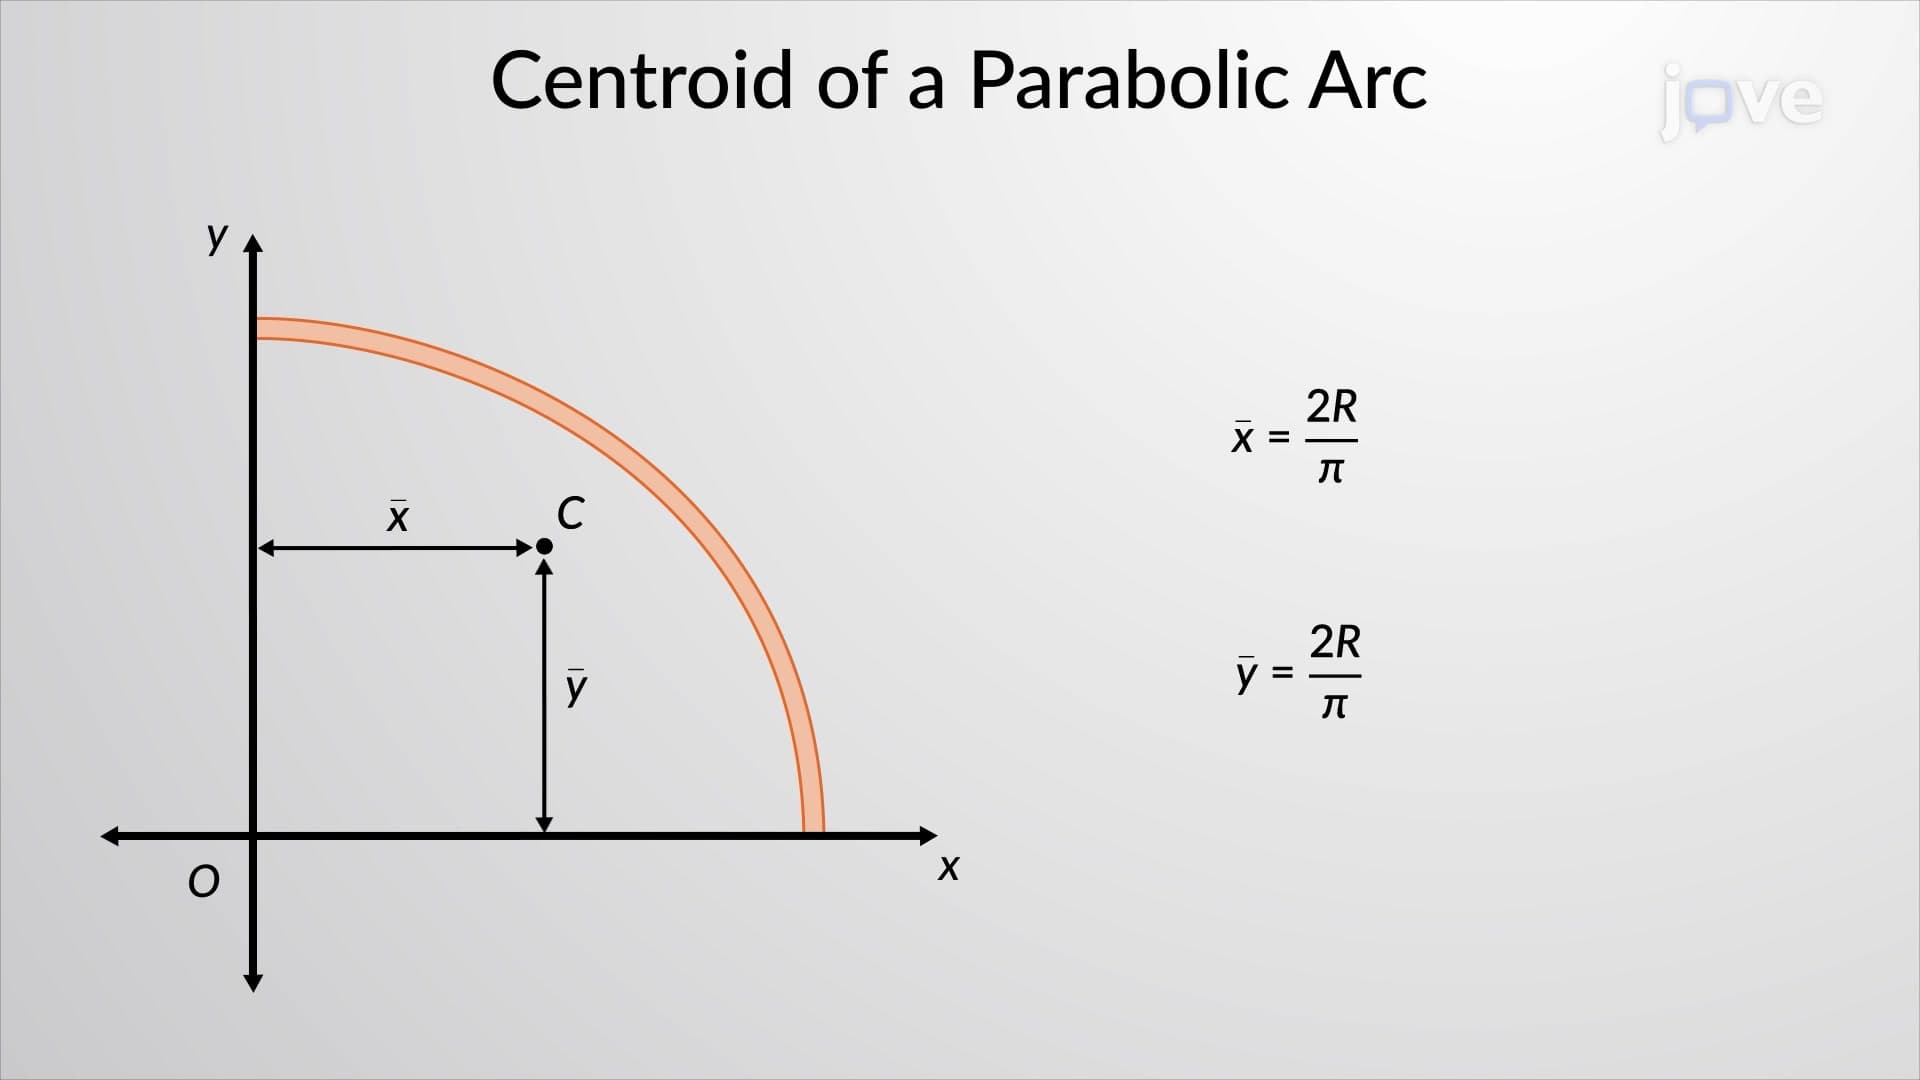
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.8K