

基于模糊神经网络的并排无人直升机的强有力的后退控制扩展了观察员状态的观察员状态
Suiyuan Shen1, Mingle Zhang1, Mengyao Li1
1College of Engineering, South China Agricultural University, Guangzhou, Guangdong 510642, PR China.
ISA transactions
|November 14, 2025

概括
本研究介绍了无人直升机的新型控制策略,通过使用模糊神经网络增强的扩展状态观察员与强大的后退控制 (FNNESO-RBSC) 来提高稳定性,以管理复杂的不确定性.
科学领域:
- 无人驾驶飞行器 (UAV) 控制系统
- 机器人和自动化机器人与自动化
- 航空航天工程 航空航天工程
背景情况:
- 无人驾驶直升机面临着严重的定位和姿态不稳定性,原因是由于质量-惯性变化和空气动力学干扰而带来的不确定性.
- 现有的控制方法很难有效地弥补这些动态和复杂的环境因素.
研究的目的:
- 开发一个先进的控制策略,模糊神经网络增强的扩展状态观察器与强大的后退控制 (FNNESO-RBSC),以减轻并排无人直升机的不确定性.
- 在具有挑战性的操作条件下改善无人直升机的定位和姿态稳定性.
主要方法:
- 在扩展状态观察器 (ESO) 中集成模糊神经网络 (FNN),以准确估计时间变化的总干扰.
- 实施强有力的后退控制法,动态补偿估计的干扰.
- 通过硬件在循环 (HIL) 模拟进行验证.
主要成果:
- 与传统的主动干扰拒绝控制 (ADRC) 和基于ESO的自适应神经网络有限时间融合滑动模式控制 (ANNESO-FTCSMC) 相比,FNNESO-RBSC控制器展示了优越的干扰拒绝能力.
- 在各种操作场景中实现了增强的稳定性和更高的轨迹跟踪精度.
- 在无人直升机中显著改善了定位和姿态稳定性.
结论:
- 拟议的FNNESO-RBSC战略通过有效解决复杂的合不确定性,在控制无人直升机方面取得了重大进展.
- 该方法为提高无人直升机飞行控制系统的稳定性和性能提供了强大而准确的解决方案.
更多相关视频
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
12.1K
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
2.1K
相关概念视频
 01:17
Open and closed-loop control systems
1.5K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.5K
 01:26
Feedback control systems
681
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
681
 01:24
One-Degree-of-Freedom System
792
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
792
 01:27
State Space Representation
509
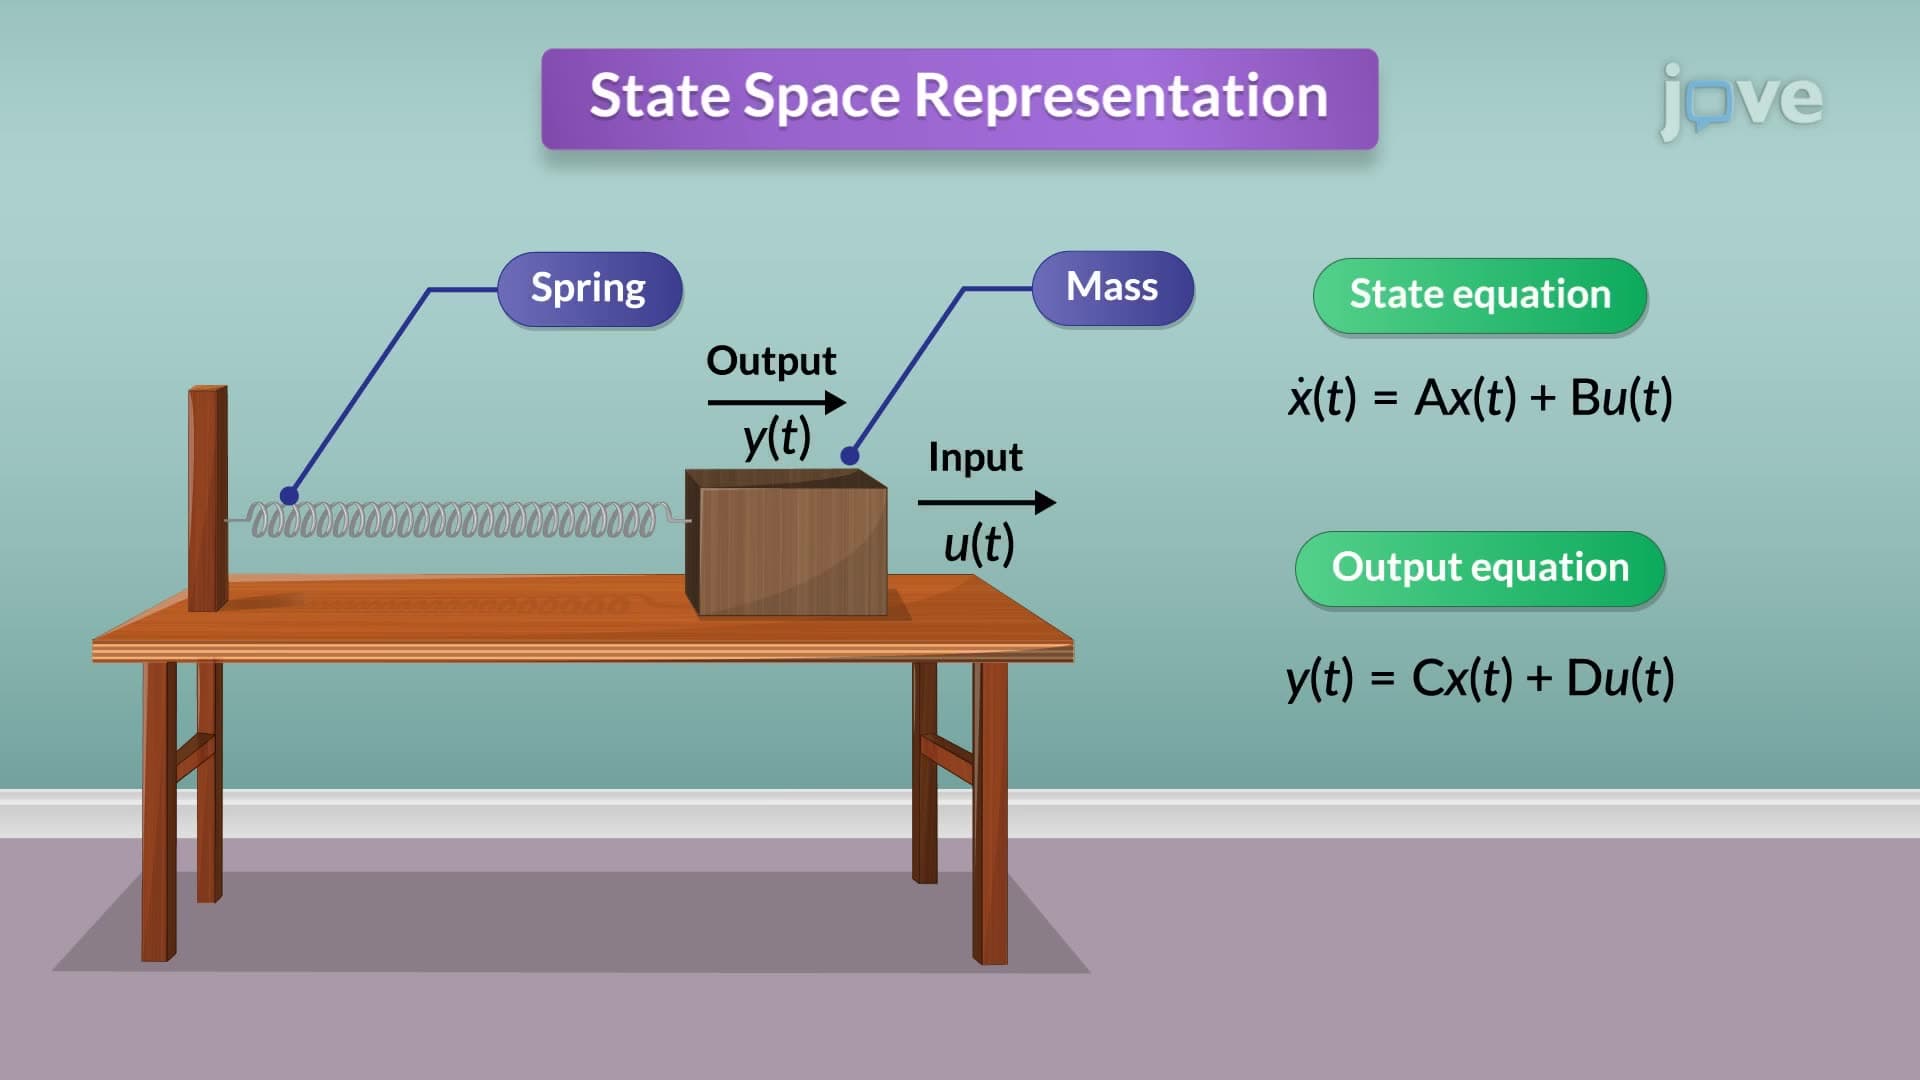
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
509
 01:19
PID Controller
634
Proportional-Integral-Derivative (PID) controllers are widely used in various control systems to enhance stability and performance. In a thermostat, it adjusts heating or cooling based on the temperature difference between the actual and desired levels. They are often used in automotive speed systems, effectively managing sudden speed changes while maintaining a constant speed under varying conditions. On the other hand, PI controllers, commonly employed in voltage regulation, enhance stability...
634
 01:21
State Space to Transfer Function
548
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
548