

惯性对无序的库拉莫托模型异步状态的影响
Yagmur Kati1,2, Ralf Toenjes1, Benjamin Lindner1,2
1Humboldt-Universität zu Berlin, Department of Physics, Newtonstrasse 15, 12489 Berlin, Germany.
Physical review. E
|November 18, 2025

概括
惯性显著影响无序的库拉莫托模型的异步状态. 中间振荡器质量最大限度地减少了相关性时间,并平整了功率光谱,类似于白噪声.
科学领域:
- 复杂的系统复杂的系统.
- 非线性动力学是一种非线性动力学.
- 统计物理学的统计物理.
背景情况:
- 库拉莫托模型是研究合振荡器系统同步的标准框架.
- 了解惯性的影响对于描述现实世界的网络动态至关重要.
研究的目的:
- 为了研究惰性的作用在一个无序的库拉莫托模型的异步状态.
- 开发和验证一个模拟方案,用于分析惯性库拉莫托网络中的波动统计.
主要方法:
- 一个代模拟方案的扩展,包括振荡器惯性.
- 计算自我一致的波动统计数据,包括网络噪声和单个振荡器的功率光谱.
- 与直接网络模拟进行比较,以验证代方案.
主要成果:
- 代模拟方案准确地捕捉了异步动态.
- 观察到一个意想不到的效果:相关性时间和利亚普诺夫光谱在中间振荡器质量时呈现最小值.
- 在这种中间质量下,功率光谱变得更平,类似于白噪声.
结论:
- 惯性在无序的库拉莫托网络的异步动态中起着至关重要的作用.
- 相关时间的确定最小值表明在中间惯性时有一个独特的动态状态.
- 这些发现提供了对惯性系统中的网络噪声和振荡器行为的见解.
相关概念视频
 01:14
Moment of Inertia
18.7K
The comparability between linear and angular velocities, linear and angular accelerations, and the kinematic equations of translational and rotational motion can be extended to the concept of inertia.
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
18.7K
 01:09
Conservation of Angular Momentum
15.8K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Considering a system that consists of n tiny particles, the angular momentum of any tiny particle may change, but the system's total angular momentum would remain constant. The principle of conservation of angular momentum only considers the net external torque acting on the system. While there are internal forces exerted by different particles within the system that also produce...
15.8K
 01:19
Euler Equations of Motion
582
Imagine a rigid body that is rotating at an angular velocity of ω within an inertial frame of reference. Along with this, picture a second rotating frame that is attached to the body itself. This frame moves along with the body and possesses an angular velocity of Ω. The total moment about the center of mass is calculated by adding the rate of change of angular momentum about the center of mass in relation to the rotating frame and the cross-product of the body's angular velocity...
582
 01:11
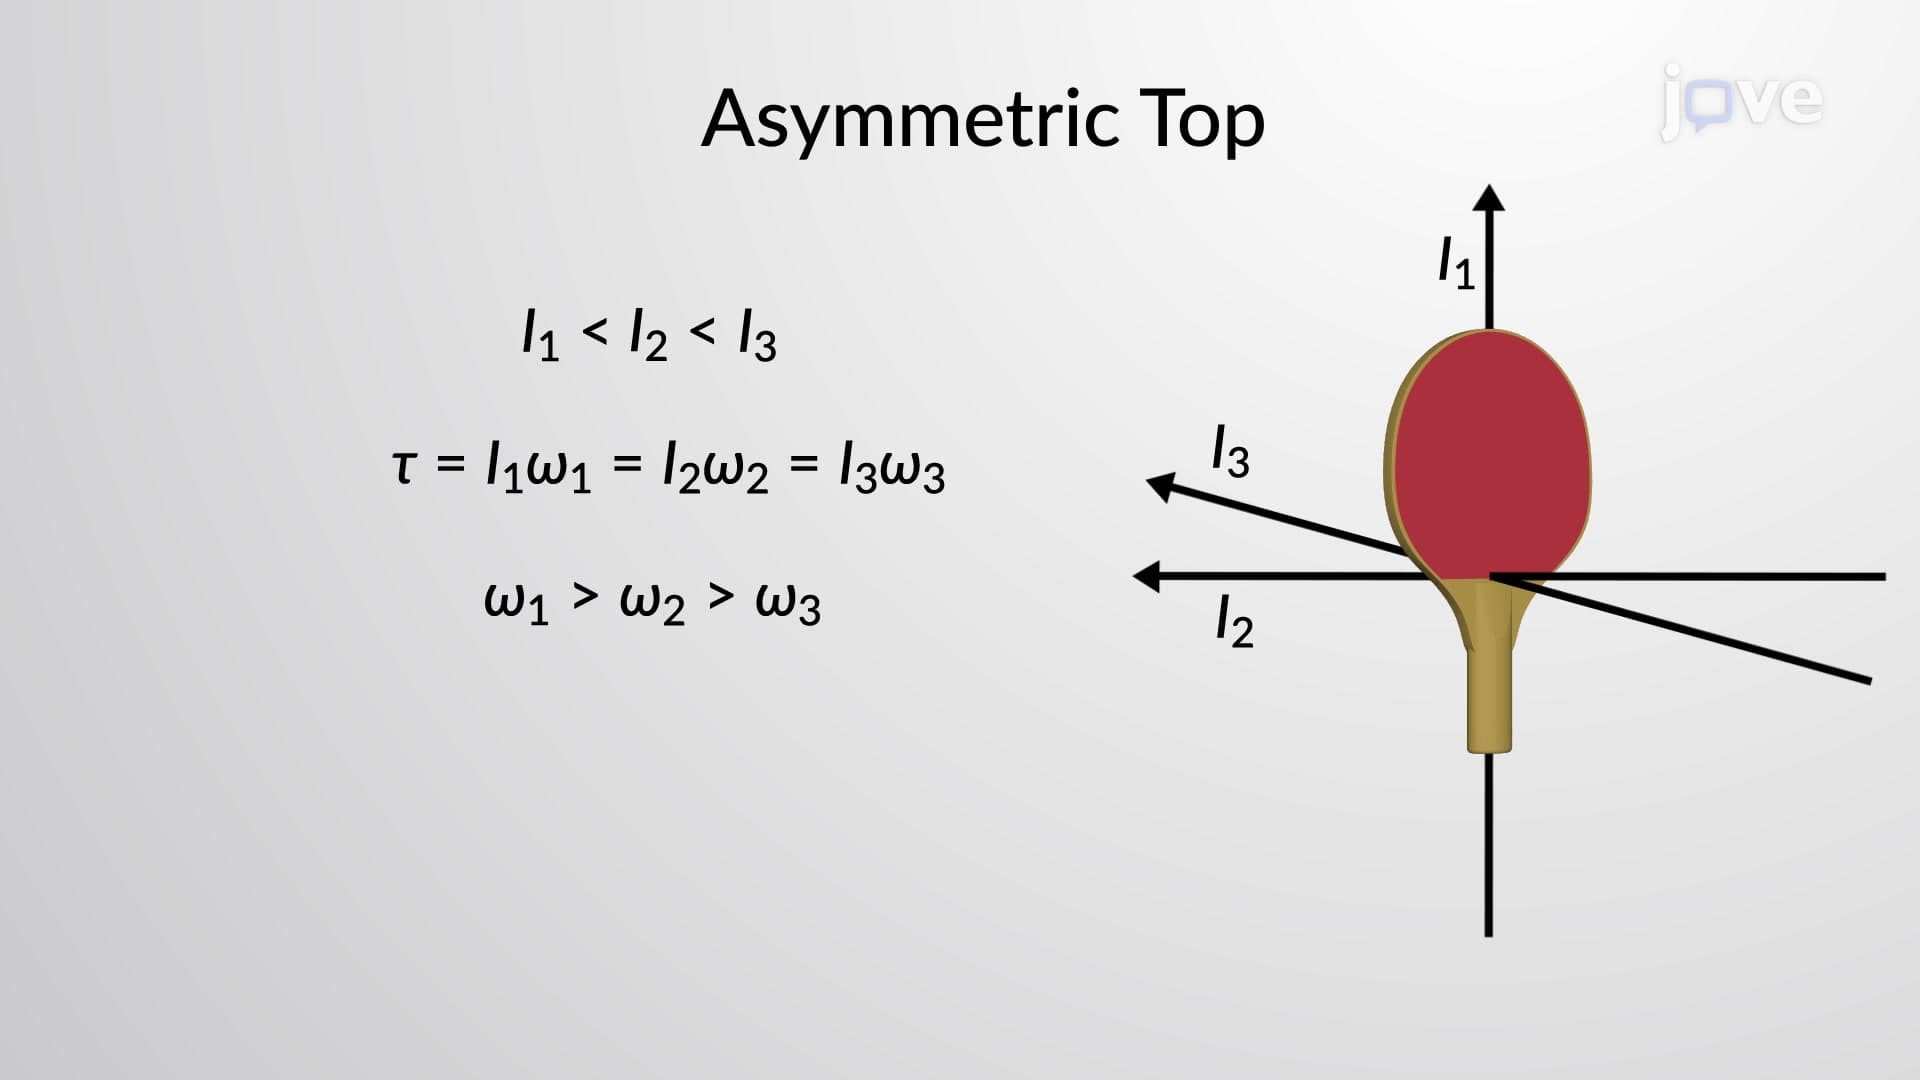
Rotation of Asymmetric Top
1.5K
By definition, a spherically symmetric body has the same moment of inertia about any axis passing through its center of mass. This situation changes if there is no spherical symmetry. Since most rigid bodies are not spherically symmetric, these require special treatment.
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
1.5K
 01:07
Damped Oscillations
6.7K
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
6.7K
 01:24
Inertia Tensor
1.1K
The concept of the inertia tensor is employed to depict the mass distribution and rotational inertia of a solid or rigid object. This tensor is expressed through a three-by-three matrix. Each component within this matrix corresponds to varying moments of inertia about specific axes.
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
1.1K