

连续变速限制下的短期驾驶速度预测:使用广域轨迹数据的可解释深度学习方法
Junhua Wang1, Yiwei Ren1, Ting Fu1
1The Key Laboratory of Road and Traffic Engineering, Ministry of Education, Tongji University, Shanghai 201804, China; College of Transportation, Tongji University, 4800 Cao'an Highway, Shanghai 201804, China.
Accident; analysis and prevention
|November 18, 2025

概括
本研究引入了一种深度学习模型,用于预测可变速度限制 (VSL) 下的驾驶员速度. 重型车辆始终减速,而轻型车辆在较低的VSL中更适应,车道位置显著影响了响应.
科学领域:
- 运输工程 运输工程
- 人工智能的人工智能
- 交通安全 交通安全 交通安全
背景情况:
- 当前变速极限 (VSL) 研究往往缺乏现实世界的微观轨迹数据.
- 了解VSL下的驾驶员行为对于交通安全和效率至关重要.
研究的目的:
- 开发一个可解释的深度学习框架,用于在连续VSL控制下预测短期驾驶速度.
- 量化分析驾驶员行为和时空特征对VSL响应的影响.
主要方法:
- 利用了2.2公里高速公路段的宽带车辆轨迹数据,其中有两个连续的VSL标志.
- 开发了一个卷积神经网络 - 双向长期短期记忆 (CNN-BiLSTM) 模型,结合了多视图时空注意力机制 (MSTAM).
主要成果:
- 在VSL下,重型车辆持续减速;轻型车辆根据VSL水平和车道位置表现出不同的反应.
- 左车道的司机比右车道的司机更迅速,更果断地做出反应.
- 第二个VSL标志显示出比第一个更高的监管效率,MSTAM模型的表现优于基线CNN-BiLSTM.
结论:
- 拟议的MSTAM模型准确地预测驾驶员的速度,并捕捉时空注意力模式,提供对适应性驾驶员反应的见解.
- 调查结果支持加强VSL部署和特定车道的速度控制策略,以改善交通管理.


相关概念视频
 01:29
Evaluating Limits by Direct Substitution
145
In the analysis of functions that represent continuous physical phenomena, it is often necessary to determine the output value as the input approaches a specific point. When a combination of algebraic terms defines the function and exhibits no discontinuities or abrupt changes near the point of interest, the limit of the function can be evaluated directly. This process, known as direct substitution, involves replacing the variable in the expression with the value it approaches.Direct...
145
 01:30
Introduction to Limits
178
A limit describes the value a function approaches as its input moves closer to a particular point. Even when a function is undefined at a specific value, limits allow us to analyze its behavior near that point. This concept is fundamental in calculus and essential for understanding continuity, derivatives, and integrals.Mathematically, a function f(x) has a limit L at x = a if its values L approach x as x gets arbitrarily close to a. This is written as:This notation expresses that the function...
178
 01:24
Relative Motion Analysis - Velocity
676
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
676
 01:03
Prediction Intervals
3.1K
The interval estimate of any variable is known as the prediction interval. It helps decide if a point estimate is dependable.
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
3.1K
 01:10
Relative Motion Analysis - Acceleration
785
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
785
 01:07
End Point Prediction: Gran Plot
1.1K
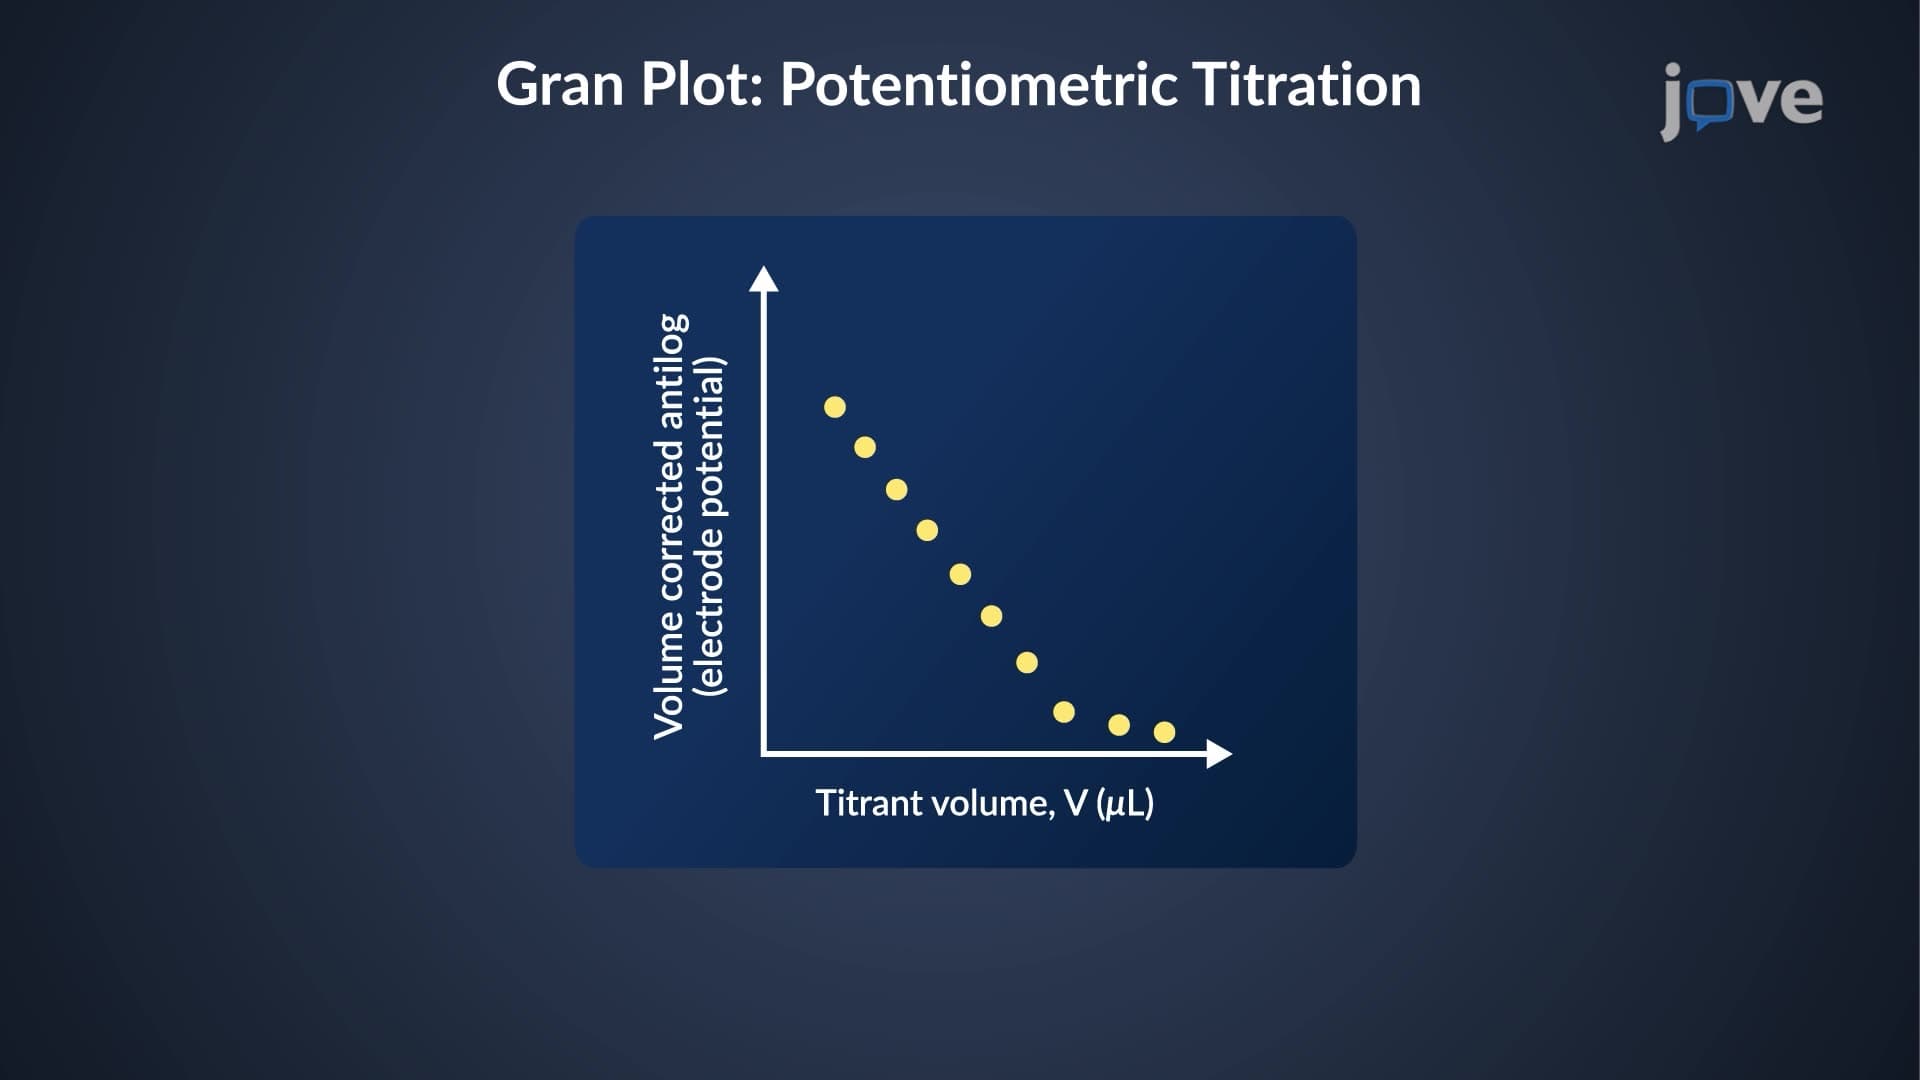
A Gran plot is used to predict the equivalence volume or endpoint of a potentiometric or acid-base titration without reaching the endpoint. Typically, titration data is collected as a function of the titrant's volume up to a point less than the equivalence volume and then transformed into a linear format. The straight line is extended to the x-axis, indicating the necessary titrant volume to achieve the equivalence point.
For potentiometric titration, the Gran plot is created by plotting...
For potentiometric titration, the Gran plot is created by plotting...
1.1K