

在具有双向反系统中的结合灾难
Liliaokeawawa Cothren1, Raissa M D'Souza2,3, Elizabeth Bradley3,4
1Department of Electrical, Computer, and Energy Engineering, University of Colorado Boulder, Bouder, Colorado 80309, USA.
Chaos (Woodbury, N.Y.)
|November 19, 2025

概括
合系统之间的相互作用可能导致同时发生的灾难. 灾难的类型 (同步,反同步,共识或反共识) 取决于系统动态和合,例如合作或竞争.
科学领域:
- 复杂系统科学 复杂系统科学
- 数学建模的数学建模
- 动态系统理论 动态系统理论
背景情况:
- 灾难性事件在各种科学学科中普遍存在,包括生态学和金融学.
- 了解系统相互作用对这些灾难的影响对于预测和缓解至关重要.
研究的目的:
- 研究两个双向合子系统之间的相互作用,每个都有-节点分叉,如何导致同时发生灾难.
- 将不同类型的合灾难分类,并确定影响它们出现的因素.
主要方法:
- 分析两个双向合的子系统,呈现S形分叉曲线.
- 开发一种分析/图形方法来绘制参数空间中的合灾难.
- 合类别的分类为合作,竞争和掠夺.
主要成果:
- 确定了四种类型的合灾难:同步,反同步,共识和反共识.
- 证明这些行为的表现取决于内在子系统动态和合机制.
- 使用开发的方法论,描述了哪些合类支持不同类型的合灾难.
结论:
- 系统相互作用显著影响灾难性事件,导致像同步或共识这样的现象.
- 子系统动态和合类型之间的相互作用决定了出现的灾难性行为.
- 开发的方法提供了一个框架,用于分析和预测各种领域的合灾难.

相关概念视频
 01:24
Effects of feedback
943
Feedback in control systems plays a critical role in shaping various operational parameters, extending beyond simple error reduction to influence stability, bandwidth, gain, impedance, and sensitivity. Understanding these effects requires examining a basic feedback system characterized by defined input, output, error, and feedback signals.
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
943
 01:26
Feedback control systems
657
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
657
 01:23
Root Loci for Positive-Feedback Systems
306
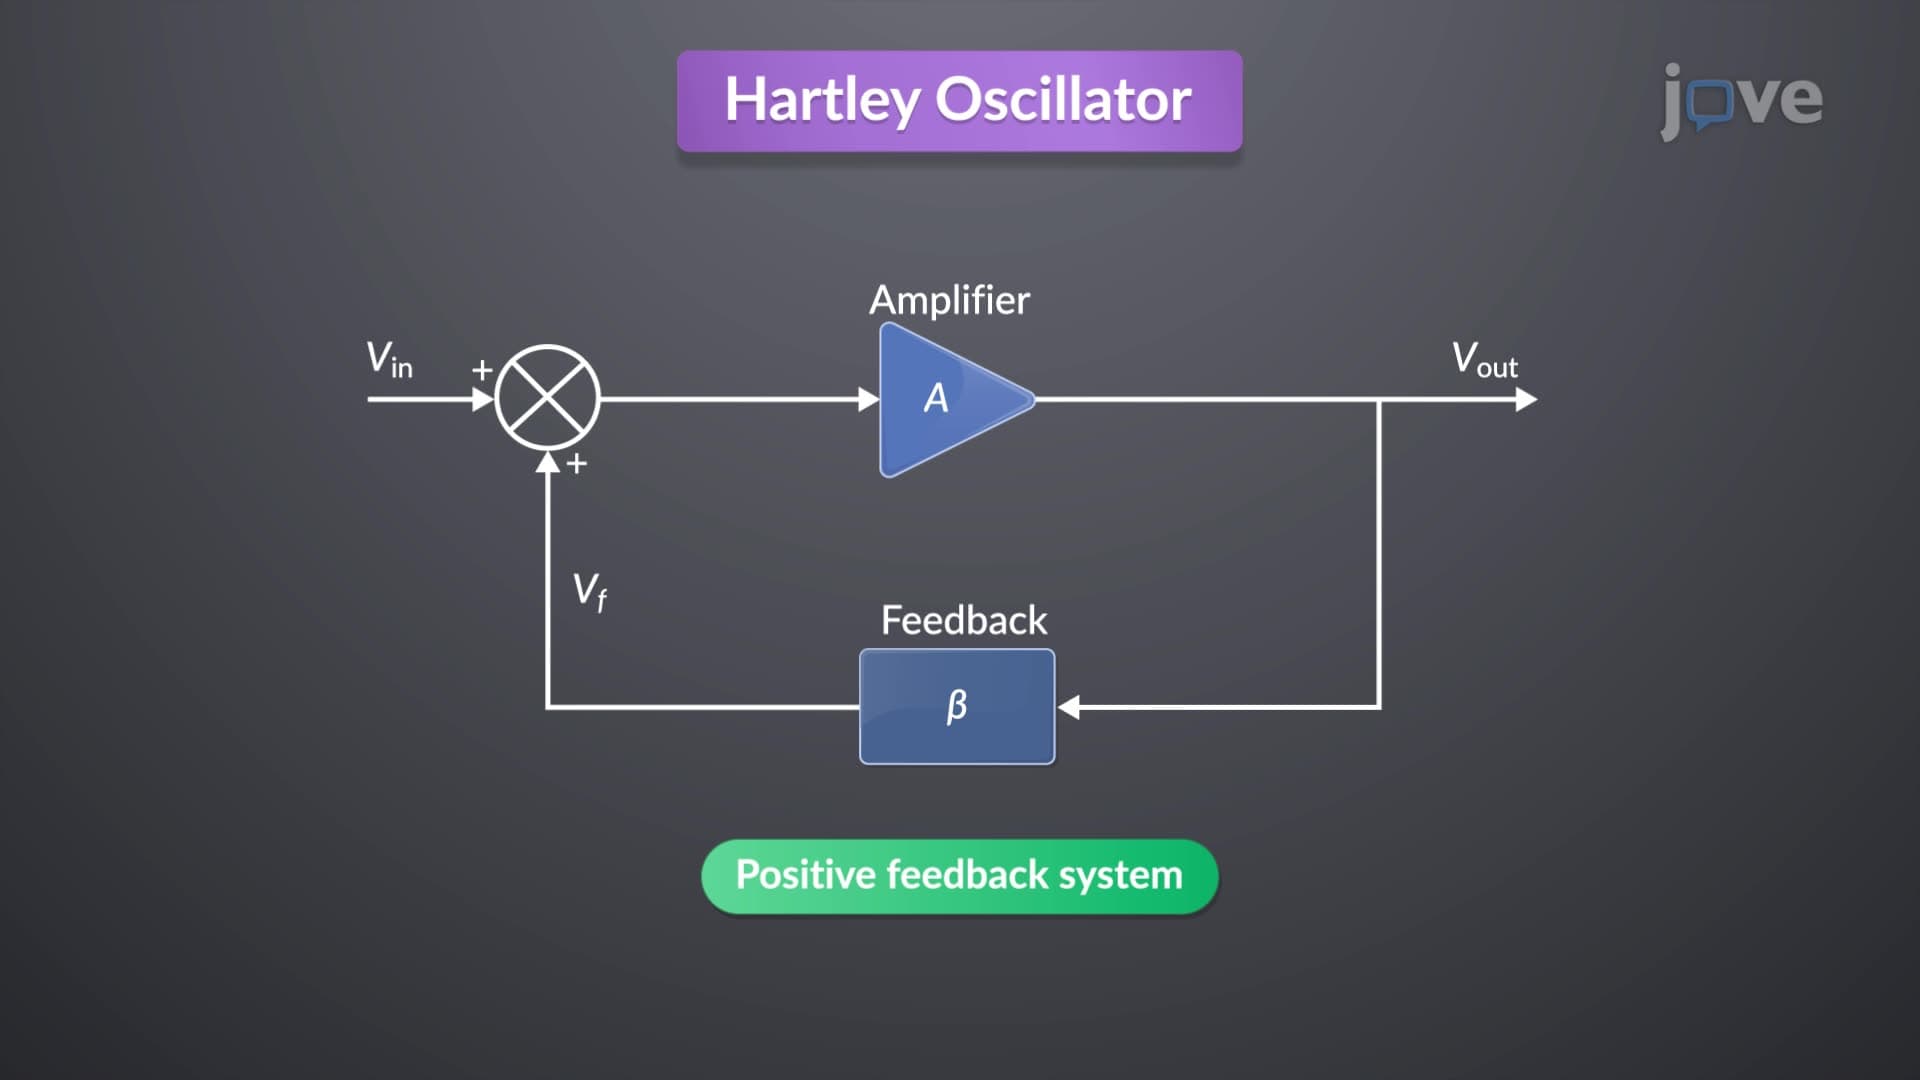
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
306
 01:26
Classification of Systems-I
528
Linearity is a system property characterized by a direct input-output relationship, combining homogeneity and additivity.
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
528
 01:22
Multi-input and Multi-variable systems
366
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence of...
In the absence of...
366
 01:18
Second Order systems II
364
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
364